Self-Explaining Social Robots: An Explainable Behavior Generation Architecture for Human-Robot Interaction
Related Experiment Video
Updated: Sep 23, 2025
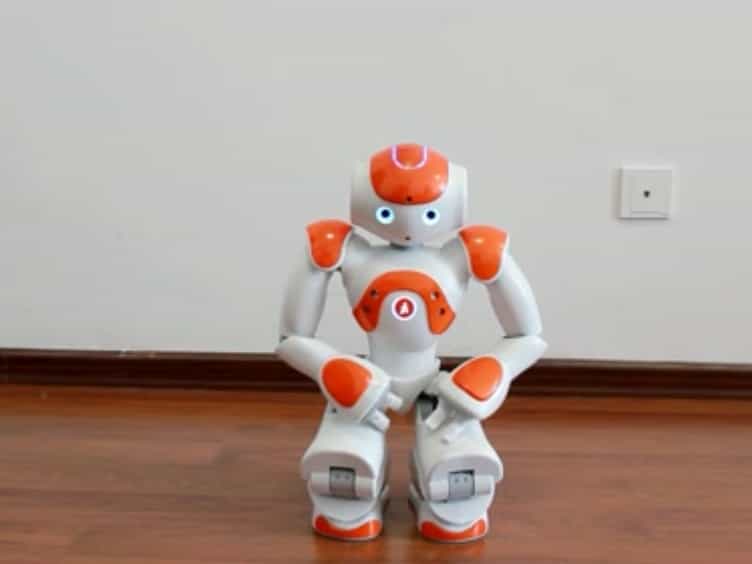
SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Sonja Stange1, Teena Hassan2, Florian Schröder1
1Social Cognitive Systems Group, Faculty of Technology, Bielefeld University, Bielefeld, Germany.

Abstract:
In recent years, the ability of intelligent systems to be understood by developers and users has received growing attention. This holds in particular for social robots, which are supposed to act autonomously in the vicinity of human users and are known to raise peculiar, often unrealistic attributions and expectations. However, explainable models that, on the one hand, allow a robot to generate lively and autonomous behavior and, on the other, enable it to provide human-compatible explanations for this behavior are missing. In order to develop such a self-explaining autonomous social robot, we have equipped a robot with own needs that autonomously trigger intentions and proactive behavior, and form the basis for understandable self-explanations. Previous research has shown that undesirable robot behavior is rated more positively after receiving an explanation. We thus aim to equip a social robot with the capability to automatically generate verbal explanations of its own behavior, by tracing its internal decision-making routes. The goal is to generate social robot behavior in a way that is generally interpretable, and therefore explainable on a socio-behavioral level increasing users' understanding of the robot's behavior. In this article, we present a social robot interaction architecture, designed to autonomously generate social behavior and self-explanations. We set out requirements for explainable behavior generation architectures and propose a socio-interactive framework for behavior explanations in social human-robot interactions that enables explaining and elaborating according to users' needs for explanation that emerge within an interaction. Consequently, we introduce an interactive explanation dialog flow concept that incorporates empirically validated explanation types. These concepts are realized within the interaction architecture of a social robot, and integrated with its dialog processing modules. We present the components of this interaction architecture and explain their integration to autonomously generate social behaviors as well as verbal self-explanations. Lastly, we report results from a qualitative evaluation of a working prototype in a laboratory setting, showing that (1) the robot is able to autonomously generate naturalistic social behavior, and (2) the robot is able to verbally self-explain its behavior to the user in line with users' requests.
More Related Videos
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
 05:47
Evidence-based Knowledge Synthesis and Hypothesis Validation: Navigating Biomedical Knowledge Bases via Explainable AI and Agentic Systems
Published on: June 13, 2025
Related Concept Videos
 01:28
Automatic Processing and Automatic Social Behavior
 02:16
Stereotype Content Model
 01:16
Non-equilibrium in the Cell
 01:13
Nonconscious Mimicry
 01:28
Causes of Social Behavior III: Biological and Environmental Influences
 02:10
Social Scripts