A multimodal tactile dataset for texture classification on uneven surfaces using a 6-DoF robotic arm
Related Experiment Videos
Soheil Khatibi1, Frederico Luiz Martins de Sousa2, Mateus Nazario Coelho2
1Department of Electrical and Computer Engineering, University of Waterloo, Waterloo, ON, Canada.

Abstract:
This article presents a comprehensive tactile dataset designed to facilitate the perception and classification of textures on uneven surfaces. The data was collected using a 6-DoF Lite6 robotic manipulator equipped with a BioIn-Tacto multimodal sensing module. The data acquisition process consists of two main phases. First, an initial probing procedure is conducted to acquire 12 reference points on the curved surface. During this phase, the sensor's Inertial Measurement Unit (IMU) orientation is recorded precisely when the embedded barometer registers contact pressure, accurately capturing the surface normal. Subsequently, the robotic arm performs dynamic exploration by sliding the sensor along the generated trajectory, maintaining consistent contact with the surface. The dataset comprises multi-modal measurements from 12 distinct materials (including various fabrics, wood, leather, and plastics) mounted on curved geometries, with 25 exploratory episodes recorded per texture. The hardware captures nine-degrees-of-freedom Magnetic, Angular Rate, and Gravity (MARG) data alongside deep-pressure readings from a barometer encased in polyurethane rubber. This dataset has substantial reuse potential for researchers developing machine learning models and AI-driven sensorimotor policies for tactile texture classification in realistic environments. Furthermore, as it complements a previous dataset collected with a 4-DoF robot on identical surfaces, it can be used for cross-embodiment research, enabling the community to benchmark sensor performance and evaluate the impact of kinematic constraints on robotic tactile perception.
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
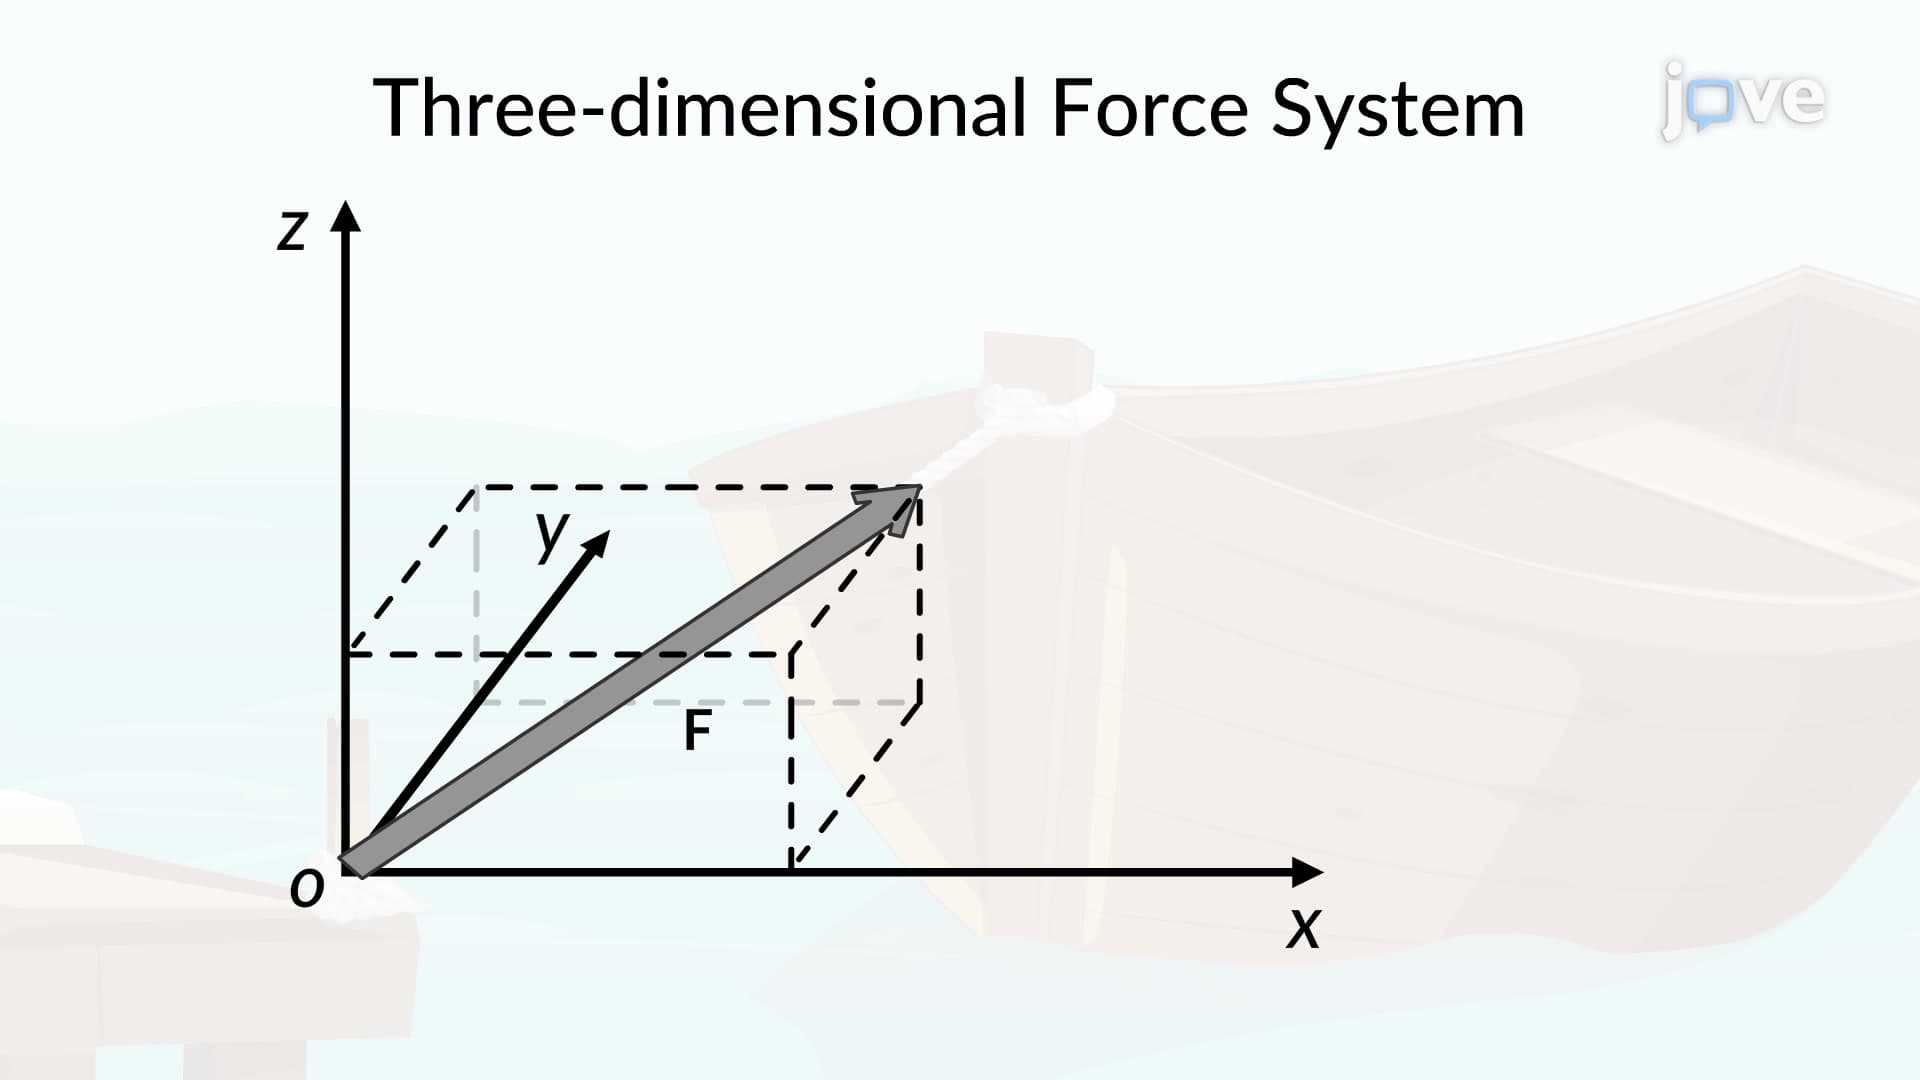
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System
 01:09
Functional Classification of Joints
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An immobile...
 01:27
Tactile and Chemical Senses