DiT-SLAM: Real-Time Dense Visual-Inertial SLAM with Implicit Depth Representation and Tightly-Coupled Graph Optimization
Related Experiment Video
Updated: Sep 22, 2025
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
Mingle Zhao1,2, Dingfu Zhou2,3, Xibin Song2,3
1Institute of Remote Sensing and Geographic Information System, Peking University, Beijing 100871, China.

Abstract:
Recently, generating dense maps in real-time has become a hot research topic in the mobile robotics community, since dense maps can provide more informative and continuous features compared with sparse maps. Implicit depth representation (e.g., the depth code) derived from deep neural networks has been employed in the visual-only or visual-inertial simultaneous localization and mapping (SLAM) systems, which achieve promising performances on both camera motion and local dense geometry estimations from monocular images. However, the existing visual-inertial SLAM systems combined with depth codes are either built on a filter-based SLAM framework, which can only update poses and maps in a relatively small local time window, or based on a loosely-coupled framework, while the prior geometric constraints from the depth estimation network have not been employed for boosting the state estimation. To well address these drawbacks, we propose DiT-SLAM, a novel real-time Dense visual-inertial SLAM with implicit depth representation and Tightly-coupled graph optimization. Most importantly, the poses, sparse maps, and low-dimensional depth codes are optimized with the tightly-coupled graph by considering the visual, inertial, and depth residuals simultaneously. Meanwhile, we propose a light-weight monocular depth estimation and completion network, which is combined with attention mechanisms and the conditional variational auto-encoder (CVAE) to predict the uncertainty-aware dense depth maps from more low-dimensional codes. Furthermore, a robust point sampling strategy introducing the spatial distribution of 2D feature points is also proposed to provide geometric constraints in the tightly-coupled optimization, especially for textureless or featureless cases in indoor environments. We evaluate our system on open benchmarks. The proposed methods achieve better performances on both the dense depth estimation and the trajectory estimation compared to the baseline and other systems.

Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:05
Collisions in Multiple Dimensions: Introduction
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:30
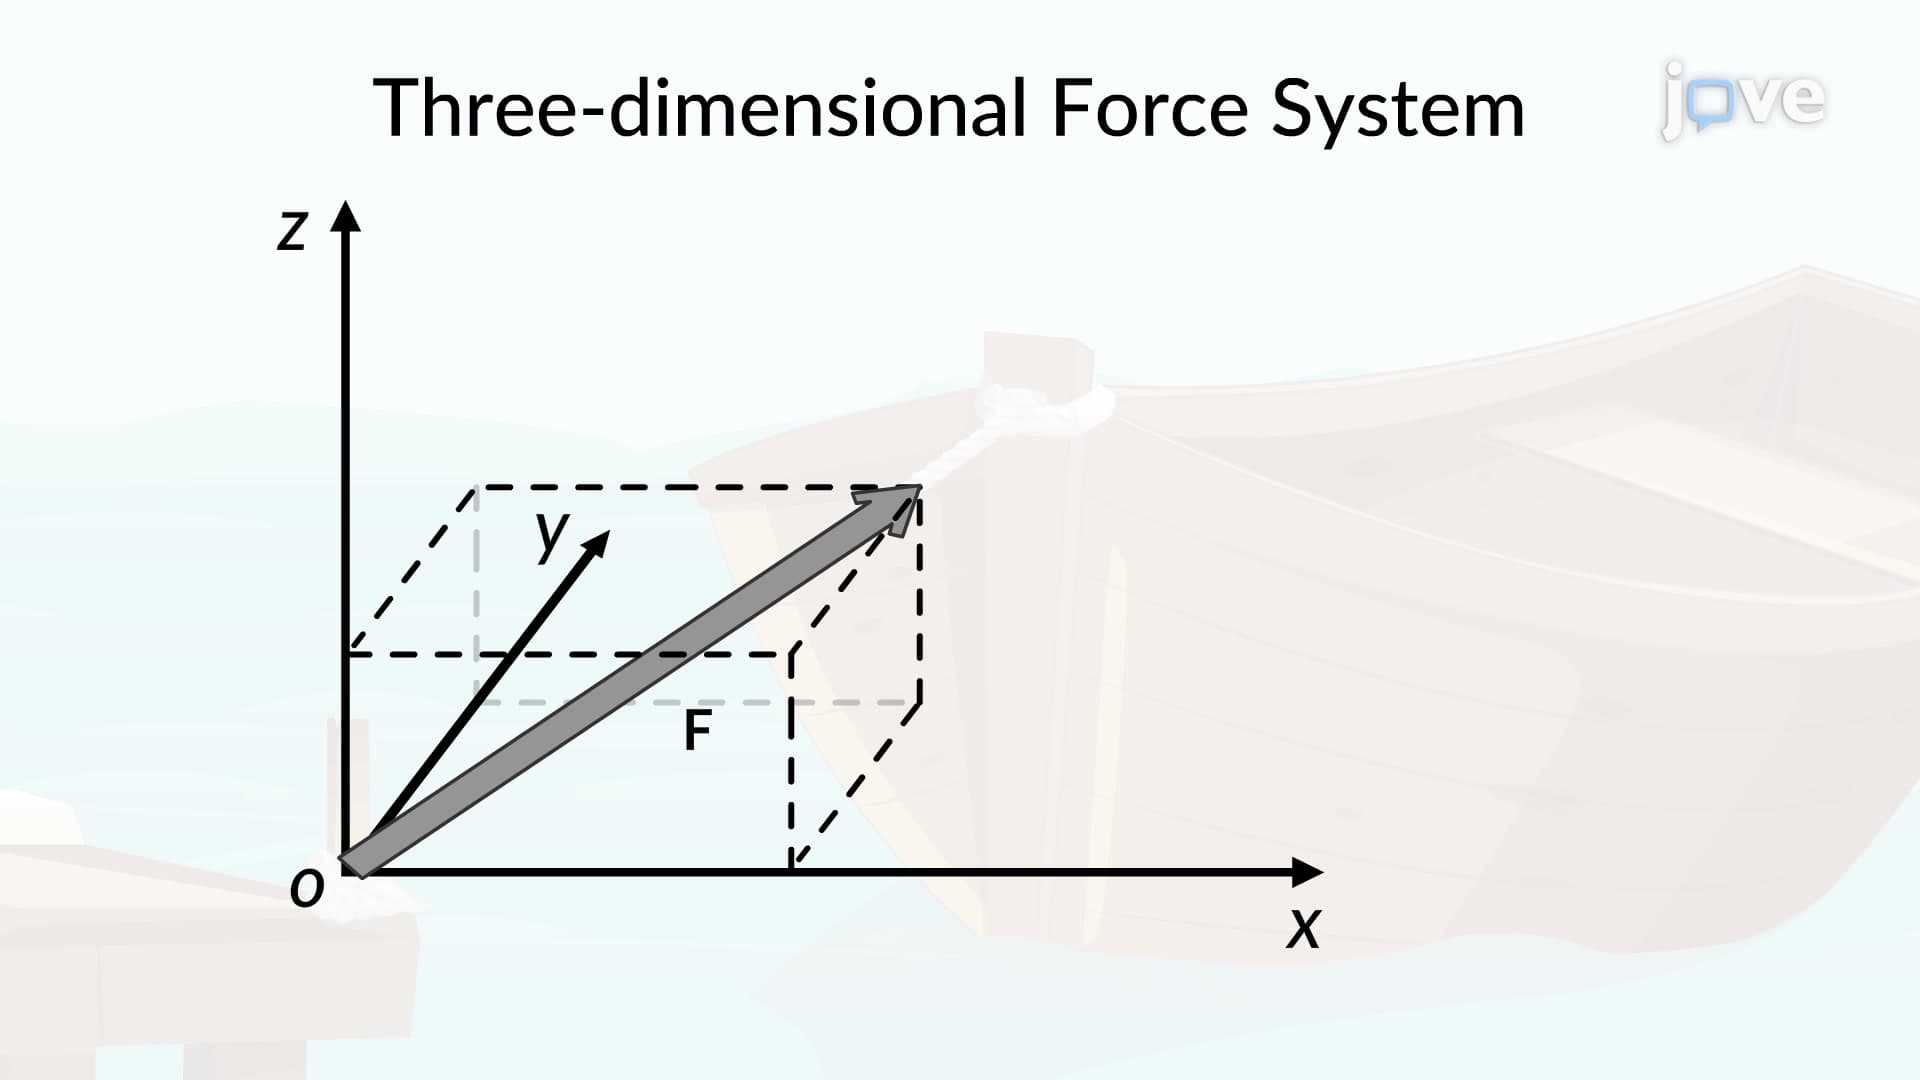
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:30
Three-Dimensional Force System