Related Experiment Video
Updated: Sep 21, 2025
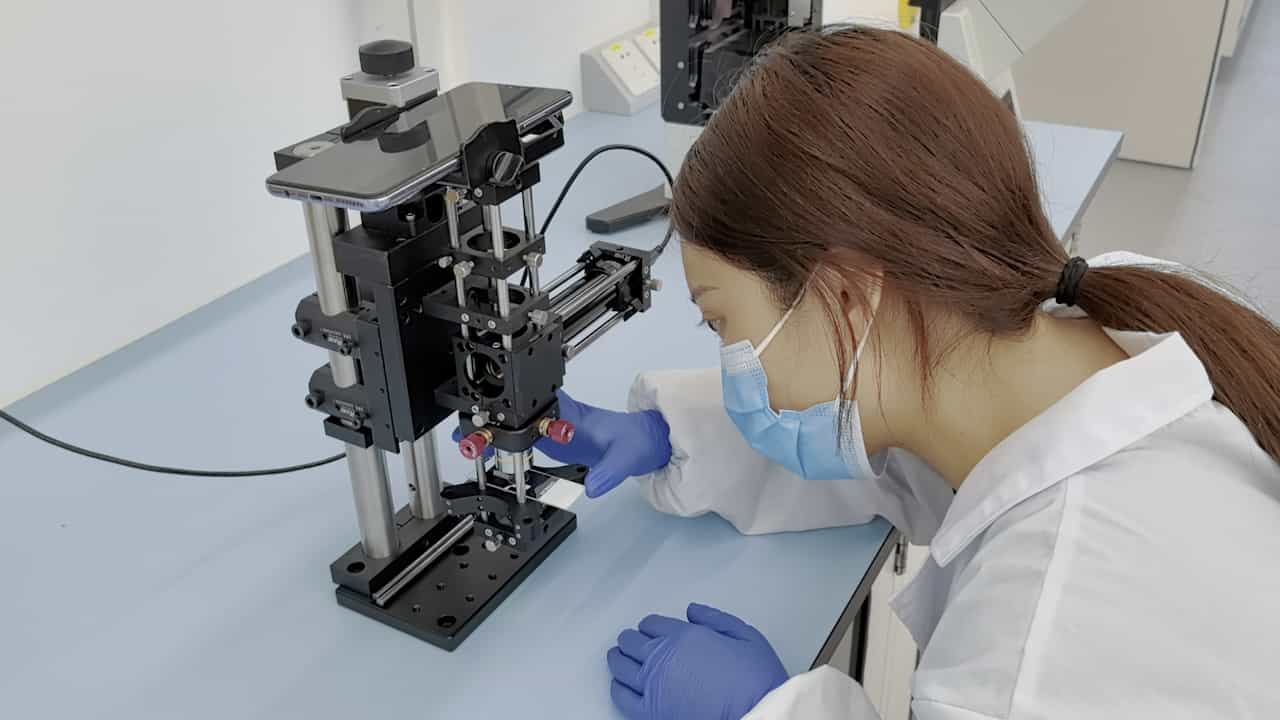

DNA Virus Detection System Based on RPA-CRISPR/Cas12a-SPM and Deep Learning
Published on: May 10, 2024
Real-Time Vehicle Classification and Tracking Using a Transfer Learning-Improved Deep Learning Network
Bipul Neupane1, Teerayut Horanont2, Jagannath Aryal3
1Advanced Geospatial Technology Research Unit, Sirindhorn International Institute of Technology, 131 Moo 5, Tiwanon Road, Bangkadi, Mueang Pathum Thani 12000, Pathum Thani, Thailand.

Abstract:
Accurate vehicle classification and tracking are increasingly important subjects for intelligent transport systems (ITSs) and for planning that utilizes precise location intelligence. Deep learning (DL) and computer vision are intelligent methods; however, accurate real-time classification and tracking come with problems. We tackle three prominent problems (P1, P2, and P3): the need for a large training dataset (P1), the domain-shift problem (P2), and coupling a real-time multi-vehicle tracking algorithm with DL (P3). To address P1, we created a training dataset of nearly 30,000 samples from existing cameras with seven classes of vehicles. To tackle P2, we trained and applied transfer learning-based fine-tuning on several state-of-the-art YOLO (You Only Look Once) networks. For P3, we propose a multi-vehicle tracking algorithm that obtains the per-lane count, classification, and speed of vehicles in real time. The experiments showed that accuracy doubled after fine-tuning (71% vs. up to 30%). Based on a comparison of four YOLO networks, coupling the YOLOv5-large network to our tracking algorithm provided a trade-off between overall accuracy (95% vs. up to 90%), loss (0.033 vs. up to 0.036), and model size (91.6 MB vs. up to 120.6 MB). The implications of these results are in spatial information management and sensing for intelligent transport planning.

Related Concept Videos
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 02:07
Improving Translational Accuracy
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:31
Classification of Systems-II
 01:30
Classification of Signals
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
 01:12
Observational Learning