Adaptive 2-bits-triggered neural control for uncertain nonlinear multi-agent systems with full state constraints
Related Experiment Video
Updated: Sep 8, 2025

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Zicong Chen1, Jianhui Wang2, Tao Zou2
1School of Automation, Guangdong University of Technology, Guangzhou, 510006, China.

Abstract:
This paper investigates an adaptive 2-bits-triggered neural control for a class of uncertain nonlinear multi-agent systems (MASs) with full state constraints. Considering the limitations of practical physical devices and operating conditions, MASs may suffer performance degradation or even crash while the system states are not restricted. With this in mind, combined with barrier Lyapunov function (BLF), an adaptive neural consensus control is developed to guarantee that the state constraints of all followers are not violated. Further, the conversion relationship between the state constraints of MASs and the synchronization error constraints is clarified more precisely, which could improve the synchronization performance of MASs. In addition, considering both trigger threshold setting and control signal transmission bits issues, a 2-bit trigger strategy is proposed to maximize the utilization of MASs bandwidth resources. Theoretical analysis shows that all signals are uniformly ultimately bounded. And the simulation results demonstrate its effectiveness.


Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:21
State Space to Transfer Function
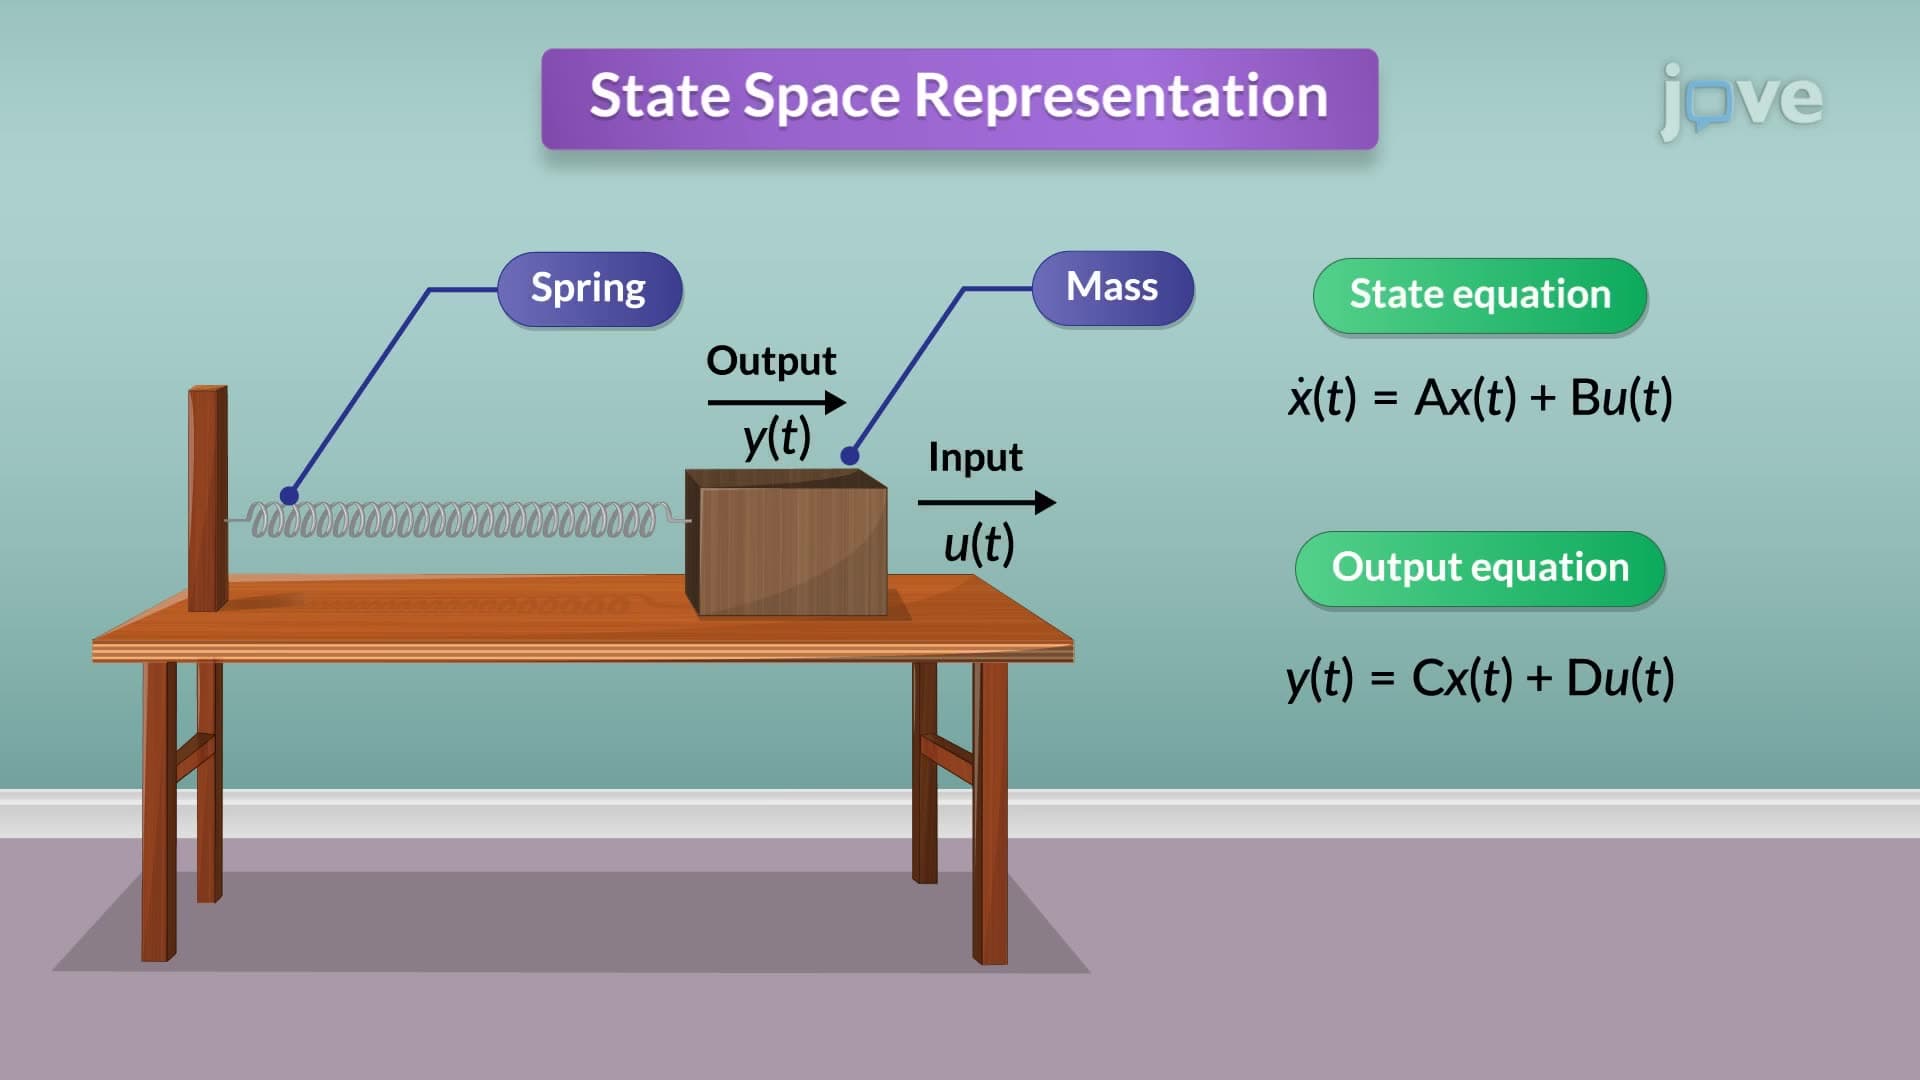
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: