Compact World Anchors: Registration Using Parametric Primitives as Scene Description
Related Experiment Video
Updated: Sep 8, 2025
Coral Reef Arks: An In Situ Mesocosm and Toolkit for Assembling Reef Communities
Published on: January 6, 2023

Abstract:
We present a registration method relying on geometric constraints extracted from parametric primitives contained in 3D parametric models. Our method solves the registration in closed-form from three line-to-line, line-to-plane or plane-to-plane correspondences. The approach either works with semantically segmented RGB-D scans of the scene or with the output of plane detection in common frameworks like ARKit and ARCore. Based on the primitives detected in the scene, we build a list of descriptors using the normals and centroids of all the found primitives, and match them against the pre-computed list of descriptors from the model in order to find the scene-to-model primitive correspondences. Finally, we use our closed-form solver to estimate the 6DOFtransformation from three lines and one point, which we obtain from the parametric representations of the model and scene parametric primitives. Quantitative and qualitative experiments on synthetic and real-world data sets demonstrate the performance and robustness of our method. We show that it can be used to create compact world anchors for indoor localization in AR applications on mobile devices leveraging commercial SLAM capabilities.
Related Concept Videos
 01:03
Anchoring Junctions
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:07
Gravitational Potential Energy for Extended Objects
 01:07
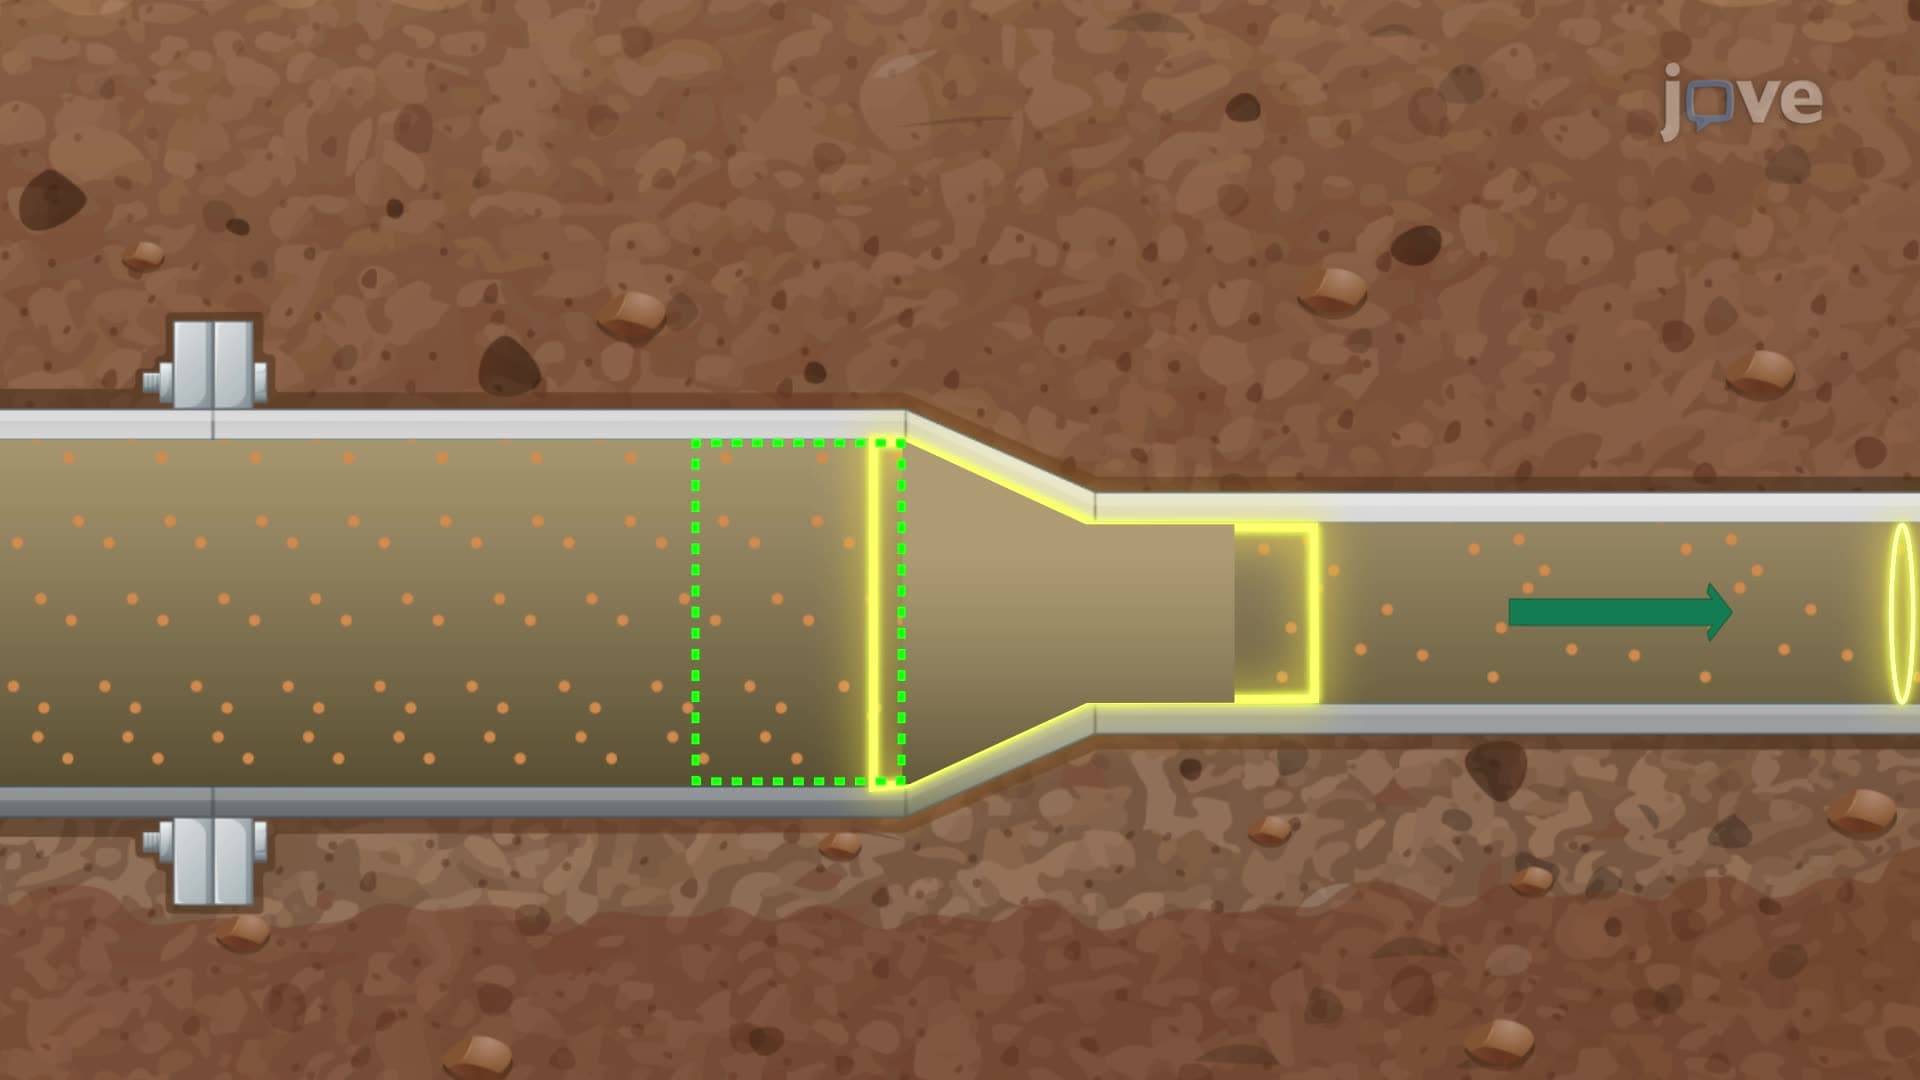
Conservation of Mass in Fixed, Nondeforming Control Volume
In the case of a sewer pipe, which can be modeled...
 01:20
Plastic Deformation in Circular Shafts
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...