Related Experiment Video
Updated: Sep 7, 2025

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Modeling and Simulation of Robotic Grasping in Simulink Through Simscape Multibody
Maria Pozzi1, Gabriele Maria Achilli2, Maria Cristina Valigi2
1Department of Information Engineering and Mathematics, University of Siena, Siena, Italy.

Abstract:
Grasping and dexterous manipulation remain fundamental challenges in robotics, above all when performed with multifingered robotic hands. Having simulation tools to design and test grasp and manipulation control strategies is paramount to get functional robotic manipulation systems. In this paper, we present a framework for modeling and simulating grasps in the Simulink environment, by connecting SynGrasp, a well established MATLAB toolbox for grasp simulation and analysis, and Simscape Multibody, a Simulink Library allowing the simulation of physical systems. The proposed approach can be used to simulate the grasp dynamics in Simscape, and then analyse the obtained grasps in SynGrasp. The devised functions and blocks can be easily customized to simulate different hands and objects.
More Related Videos
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:12
Modeling and Similitude
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Free-body Diagrams: Problem Solving
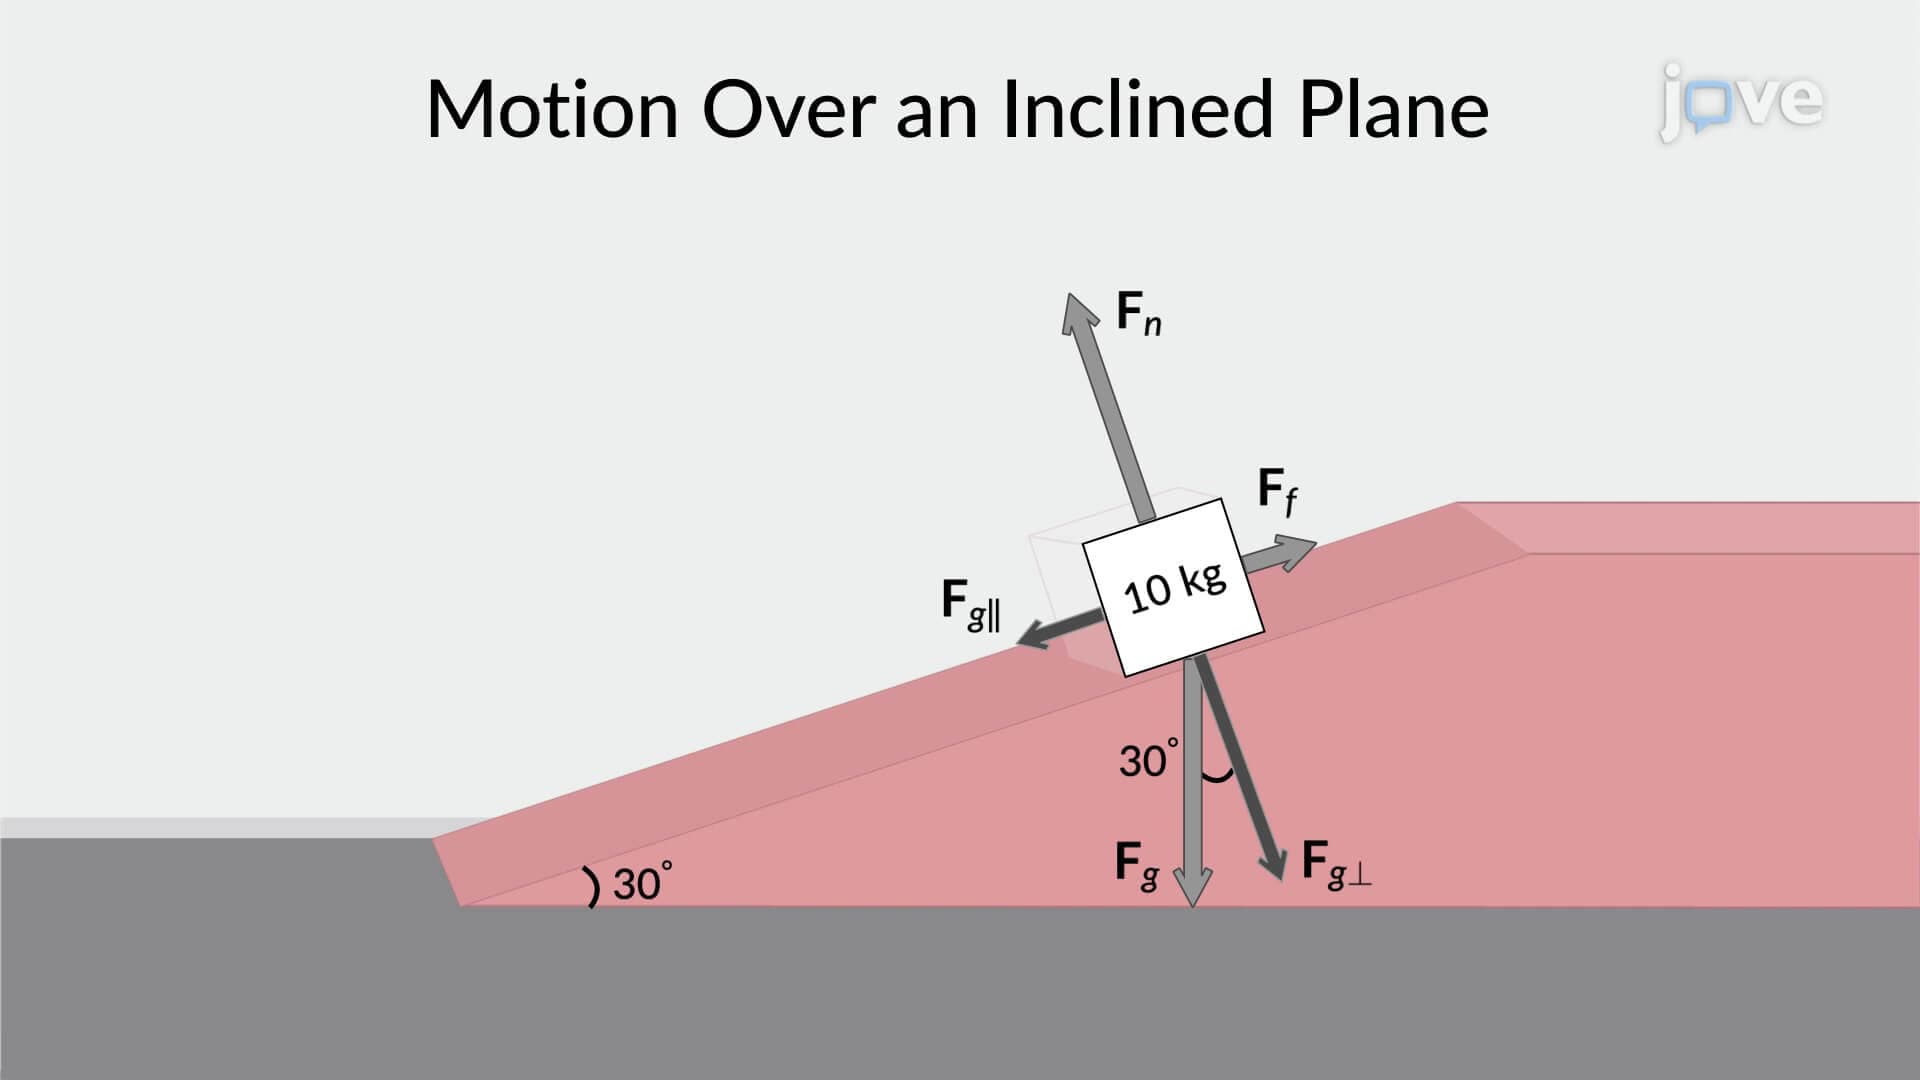
For example, consider a block with a mass of 10 kg released on an inclined plane at an angle of 30° to the horizontal, where...
 01:23
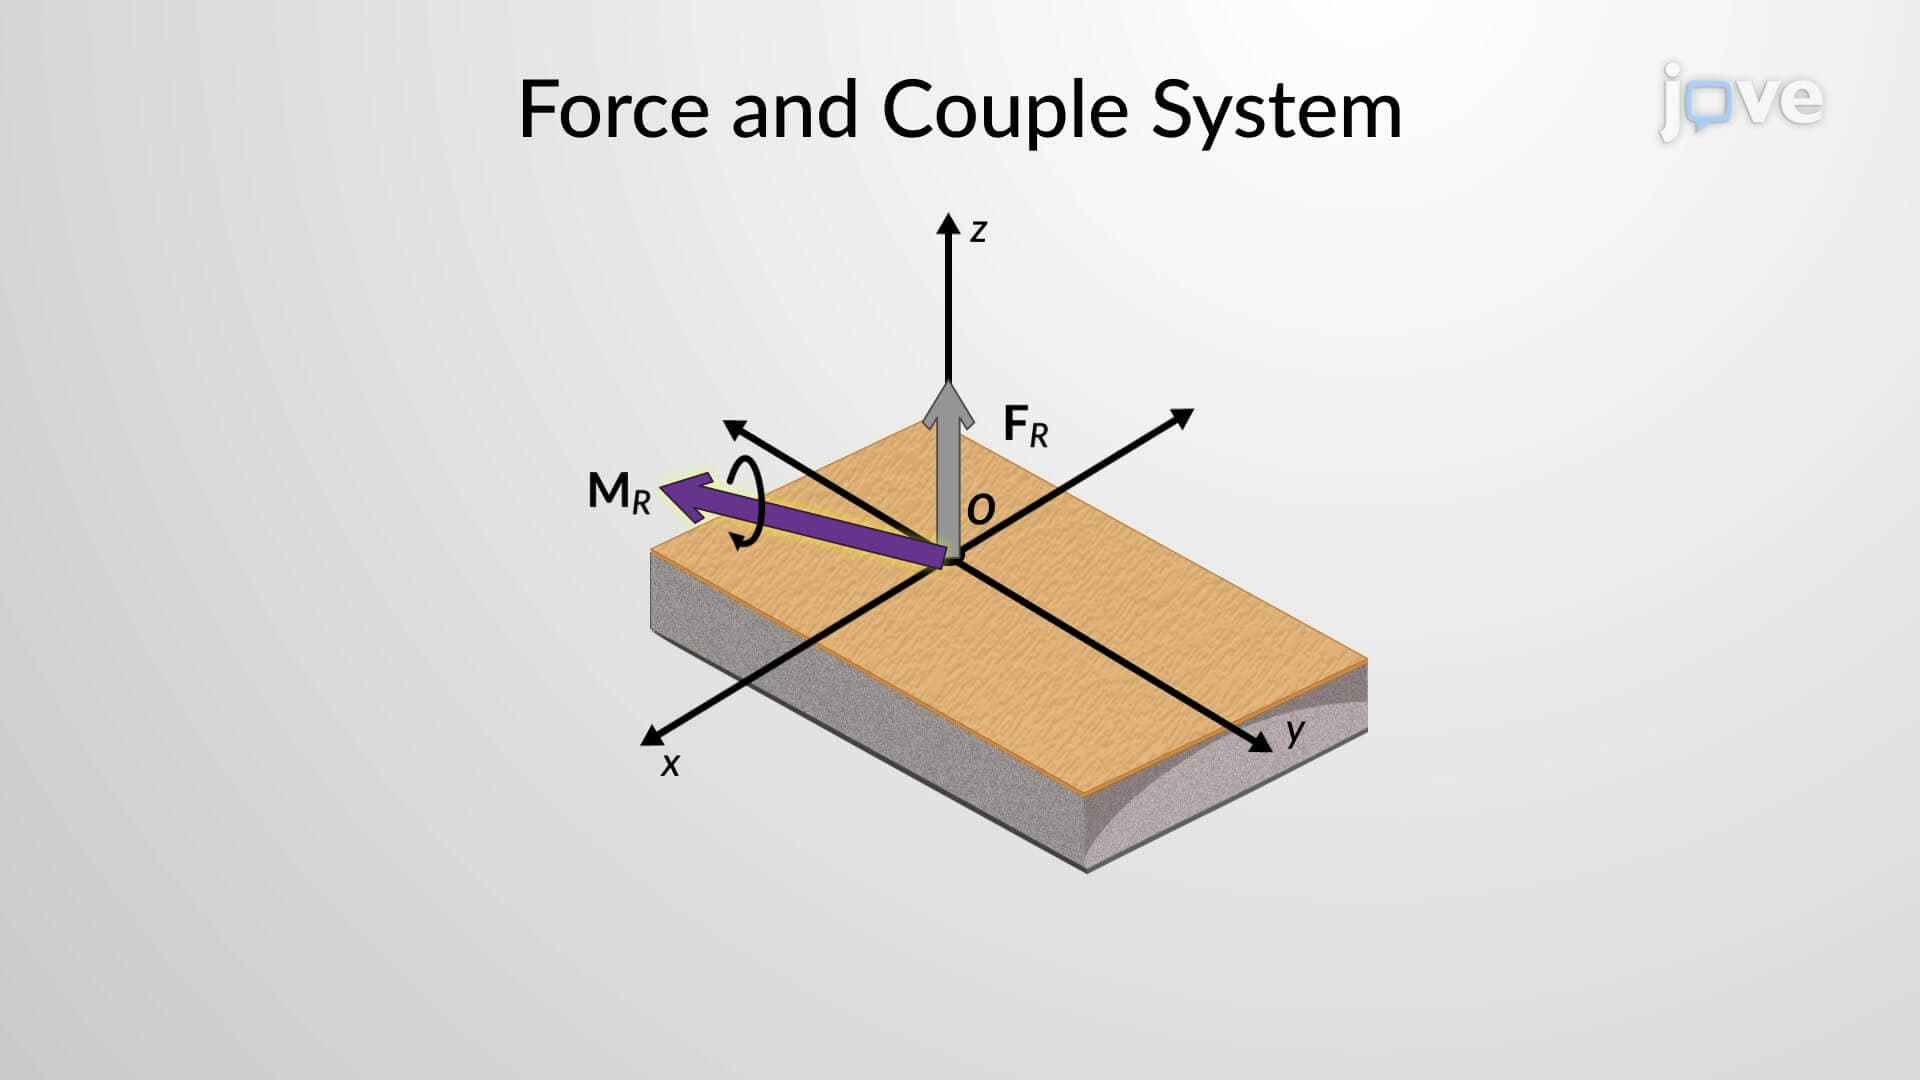
Simplification of a Force and Couple System: II