Related Experiment Video
Updated: Sep 7, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Design of a Dual-Loop Controller with Two Voltage-Dependent Current Compensators for an LLC-Based Charger
Ujjwal Pratik1, Muhammad Abdelraziq1, Urvi Ahluwalia1
1Electrical & Computer Engineering Department, North Carolina State University, Raleigh, USA.

Abstract:
A two-stage charger (PFC+LLC) is developed for Power Mobility Device (PMD) charging applications (i.e., power wheelchairs). The LLC topology is selected due to its ability to maintain ZVS operation over a wide range of load variations. This paper discusses the challenges of designing a dual-loop controller for an LLC-based charger with a wide operation region. It proposes modifying the inner current loop to maintain stable operation over a wide input and output range-the proposed internal loop control switches intelligently between two current controllers based on the output voltage level. A 300-W prototype is designed and tested with a resistive load. Moreover, simulation and experimental results are compared to validate the robustness and stability of the proposed controller.
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Design Example: Underdamped Parallel RLC Circuit
Starting with a fixed...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:22
Phase-lead and Phase-lag Controllers
 01:24
PI Controller: Design
 01:21
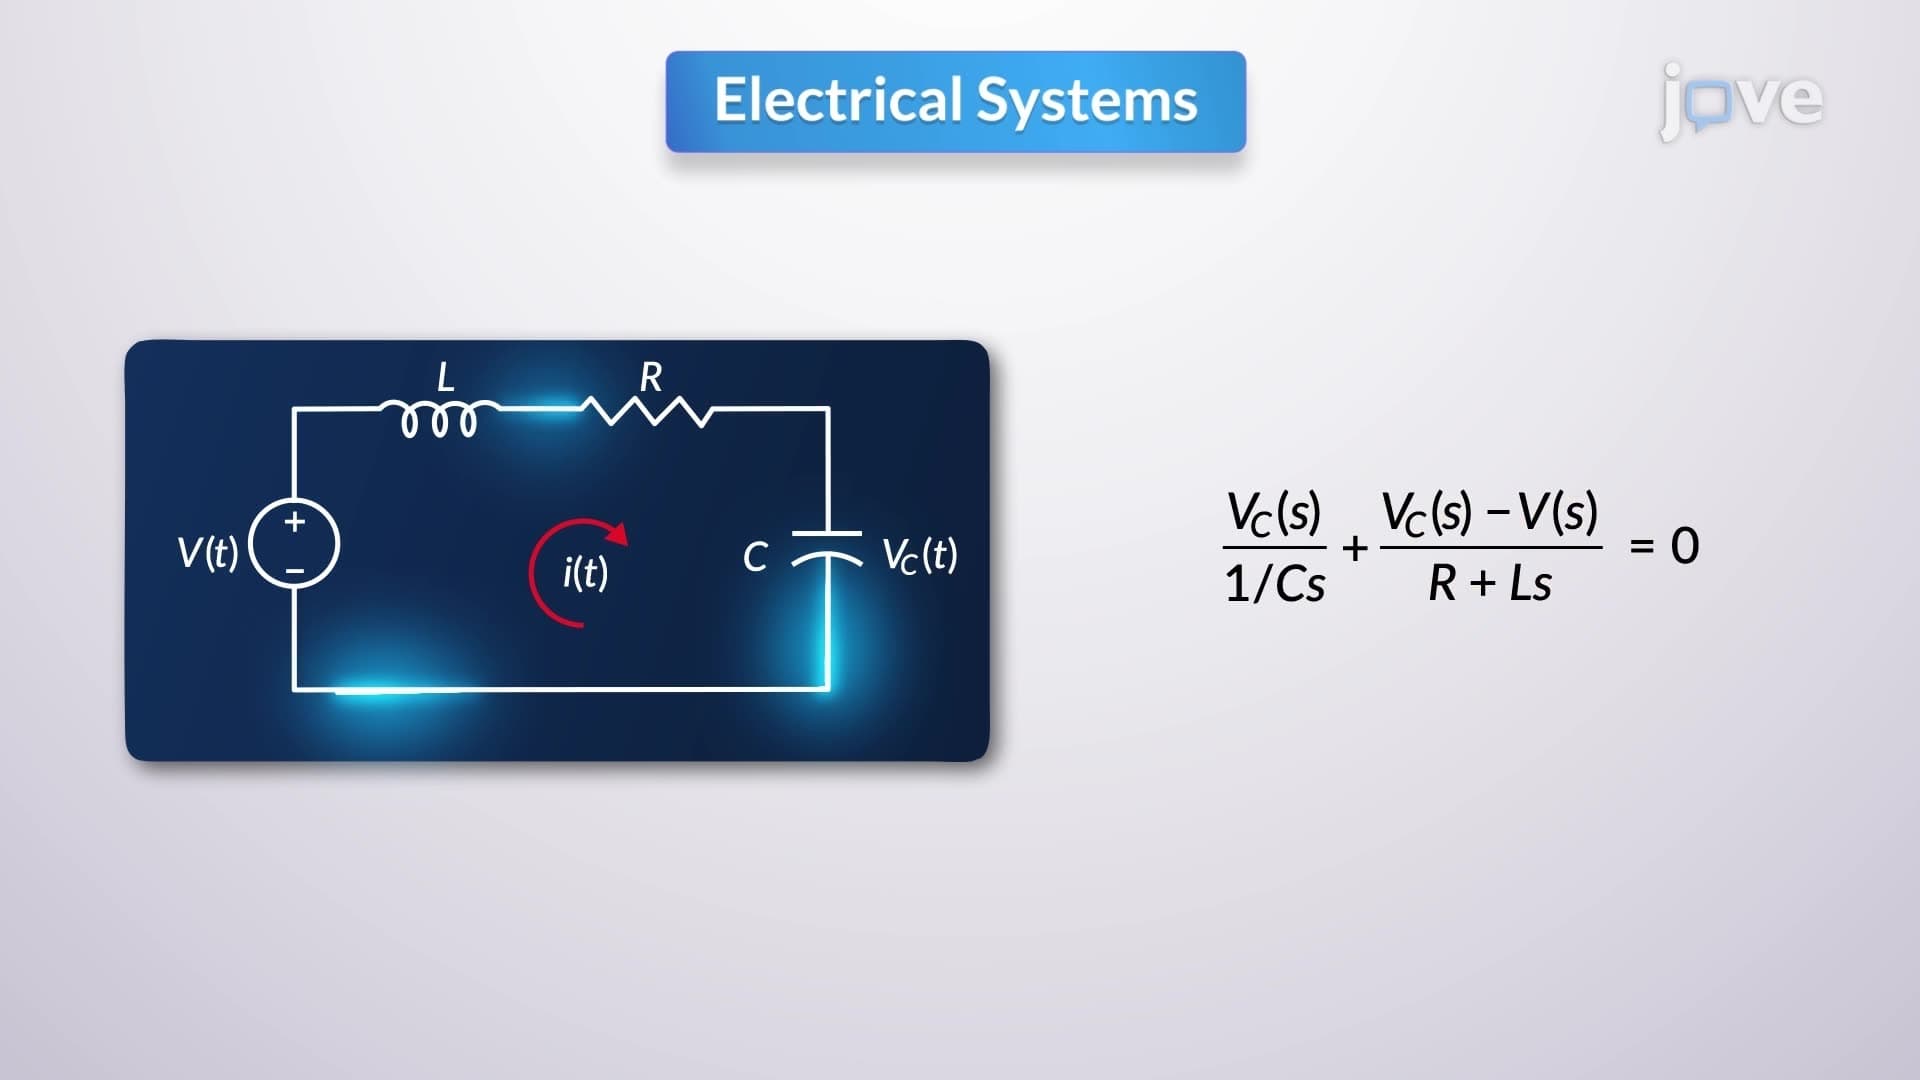
Electrical Systems
To derive the transfer function, consider...