Related Experiment Video
Updated: Sep 7, 2025

An Operant Intra-/Extra-dimensional Set-shift Task for Mice
Published on: January 22, 2016
Codimension-2 parameter space structure of continuous-time recurrent neural networks
1Cognitive Science Program, Program in Neuroscience, Department of Informatics, Luddy School of Informatics, Computing, and Engineering, Indiana University, Bloomington, IN, 47401, USA. rdbeer@iu.edu.

Abstract:
If we are ever to move beyond the study of isolated special cases in theoretical neuroscience, we need to develop more general theories of neural circuits over a given neural model. The present paper considers this challenge in the context of continuous-time recurrent neural networks (CTRNNs), a simple but dynamically universal model that has been widely utilized in both computational neuroscience and neural networks. Here, we extend previous work on the parameter space structure of codimension-1 local bifurcations in CTRNNs to include codimension-2 local bifurcation manifolds. Specifically, we derive the necessary conditions for all generic local codimension-2 bifurcations for general CTRNNs, specialize these conditions to circuits containing from one to four neurons, illustrate in full detail the application of these conditions to example circuits, derive closed-form expressions for these bifurcation manifolds where possible, and demonstrate how this analysis allows us to find and trace several global codimension-1 bifurcation manifolds that originate from the codimension-2 bifurcations.
More Related Videos
 11:18
Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
 12:27
Large-scale Reconstructions and Independent, Unbiased Clustering Based on Morphological Metrics to Classify Neurons in Selective Populations
Published on: February 15, 2017
Related Concept Videos
 01:11
Continuous -time Fourier Transform
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:31
Classification of Systems-II
 01:27
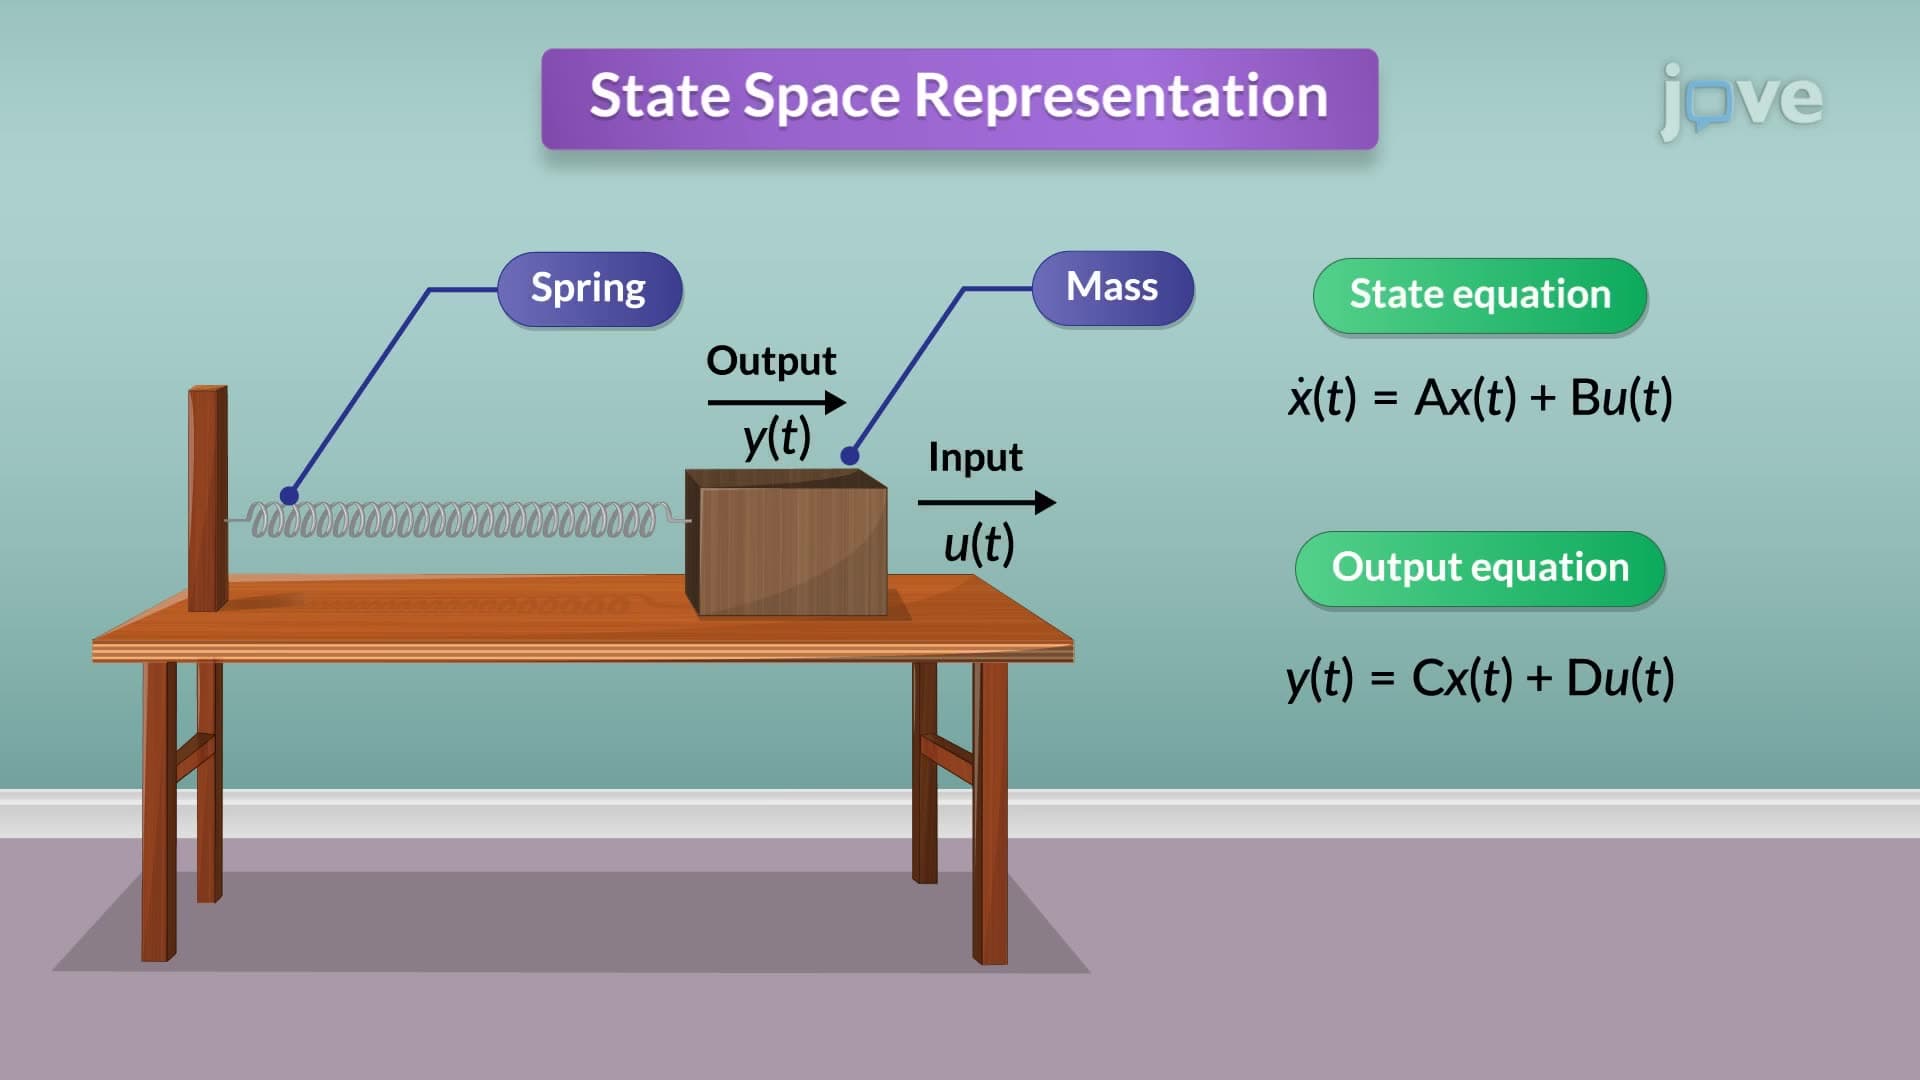
State Space Representation
Consider an RLC circuit, a...
 01:11
Sampling Continuous Time Signal
In the...
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: