Related Experiment Video
Updated: Sep 6, 2025

Automated Interactive Video Playback for Studies of Animal Communication
Published on: February 9, 2011
Toward Interpretable-AI Policies Using Evolutionary Nonlinear Decision Trees for Discrete-Action Systems

Abstract:
Black-box artificial intelligence (AI) induction methods such as deep reinforcement learning (DRL) are increasingly being used to find optimal policies for a given control task. Although policies represented using a black-box AI are capable of efficiently executing the underlying control task and achieving optimal closed-loop performance-controlling the agent from the initial time step until the successful termination of an episode, the developed control rules are often complex and neither interpretable nor explainable. In this article, we use a recently proposed nonlinear decision-tree (NLDT) approach to find a hierarchical set of control rules in an attempt to maximize the open-loop performance for approximating and explaining the pretrained black-box DRL (oracle) agent using the labeled state-action dataset. Recent advances in nonlinear optimization approaches using evolutionary computation facilitate finding a hierarchical set of nonlinear control rules as a function of state variables using a computationally fast bilevel optimization procedure at each node of the proposed NLDT. In addition, we propose a reoptimization procedure for enhancing the closed-loop performance of an already derived NLDT. We evaluate our proposed methodologies (open- and closed-loop NLDTs) on different control problems having multiple discrete actions. In all these problems, our proposed approach is able to find relatively simple and interpretable rules involving one to four nonlinear terms per rule, while simultaneously achieving on par closed-loop performance when compared to a trained black-box DRL agent. A postprocessing approach for simplifying the NLDT is also suggested. The obtained results are inspiring as they suggest the replacement of complicated black-box DRL policies involving thousands of parameters (making them noninterpretable) with relatively simple interpretable policies. The results are encouraging and motivating to pursue further applications of proposed approach in solving more complex control tasks.
More Related Videos
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
 11:53
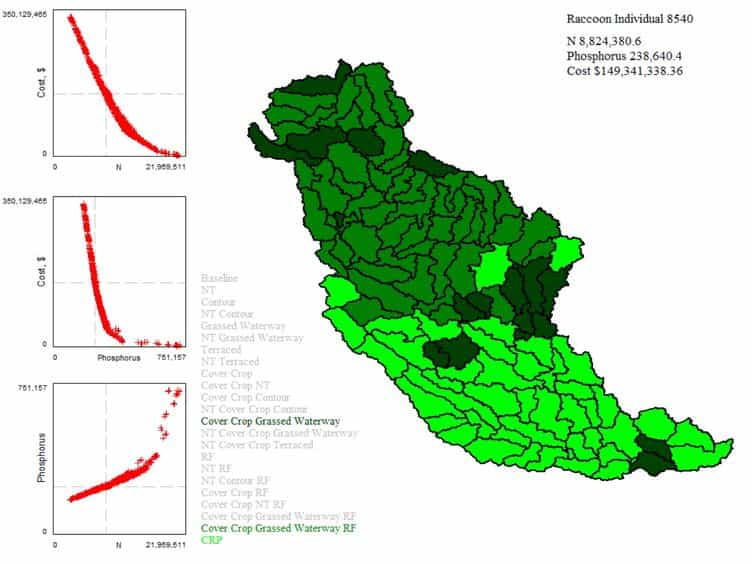
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Related Concept Videos
 01:09
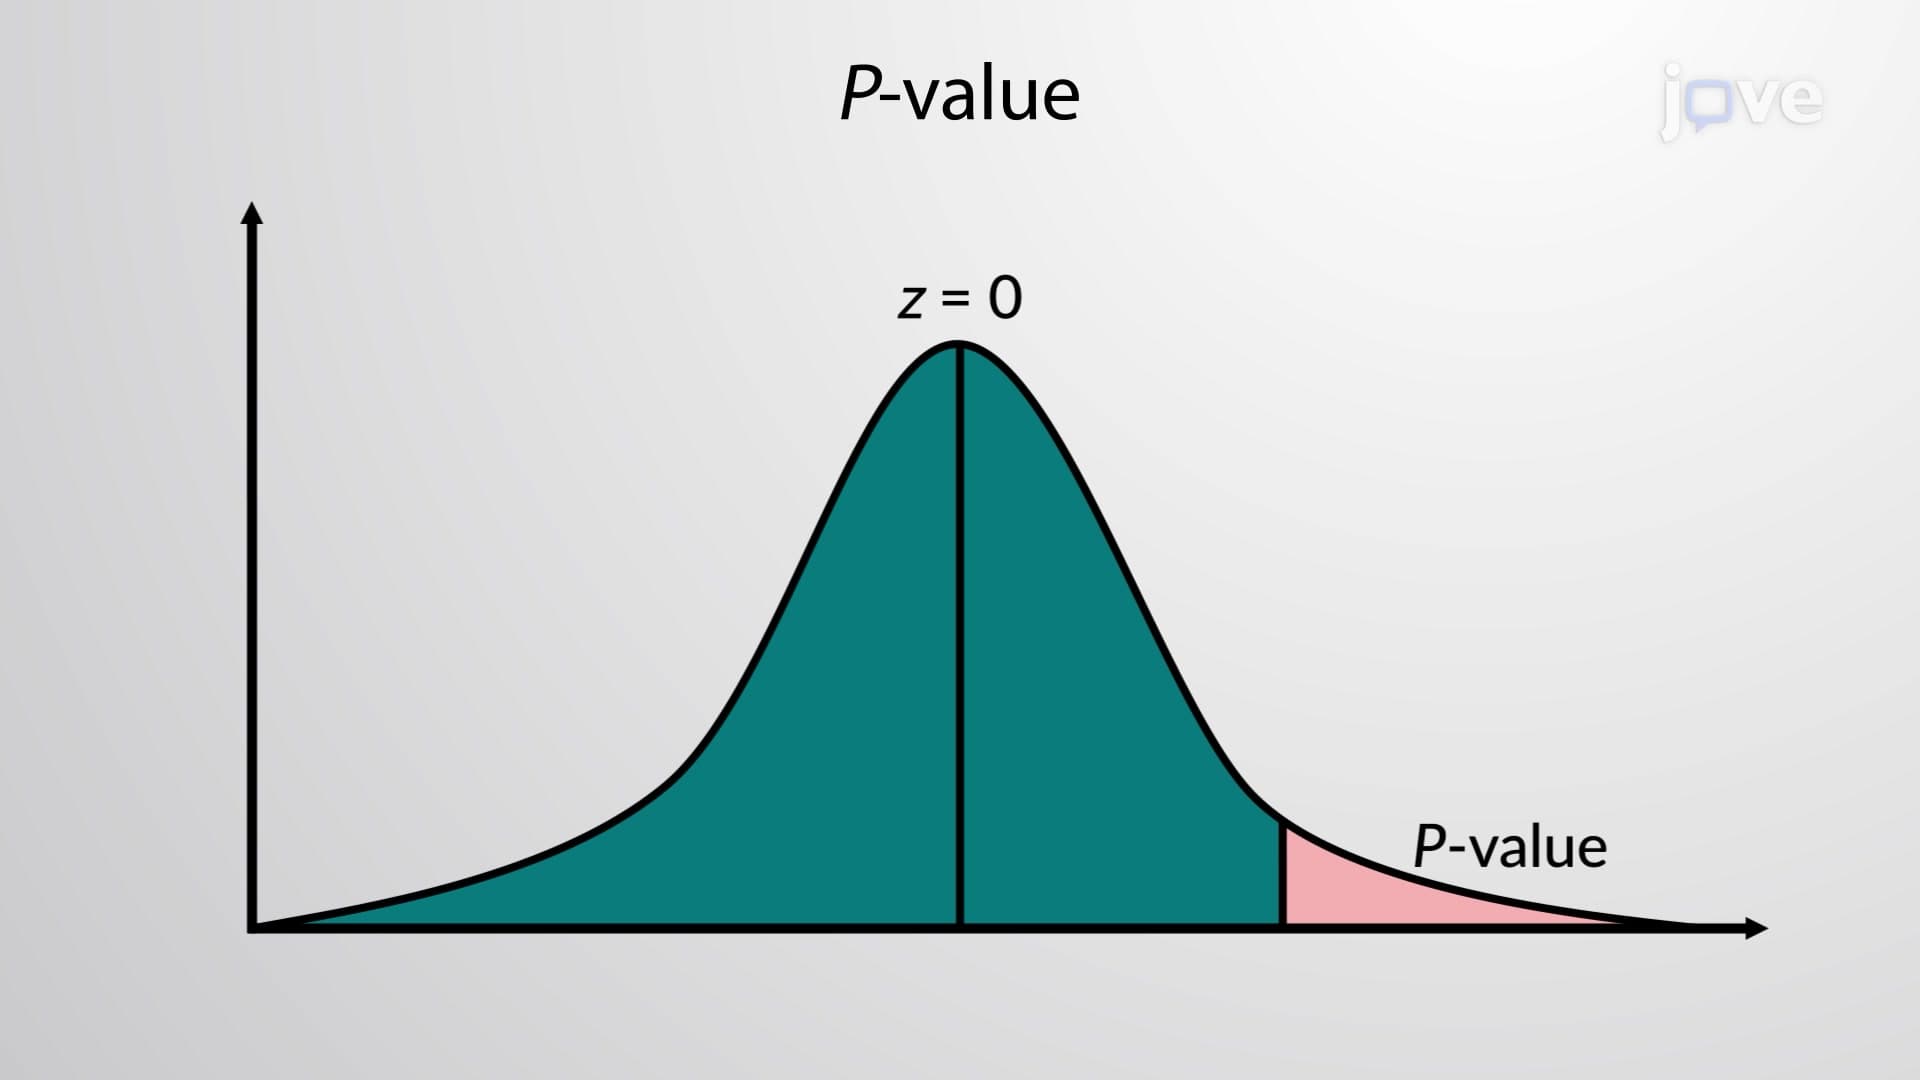
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:20
Decision Making
Automatic decision-making is fast, intuitive, and relies on gut feelings...
 01:13
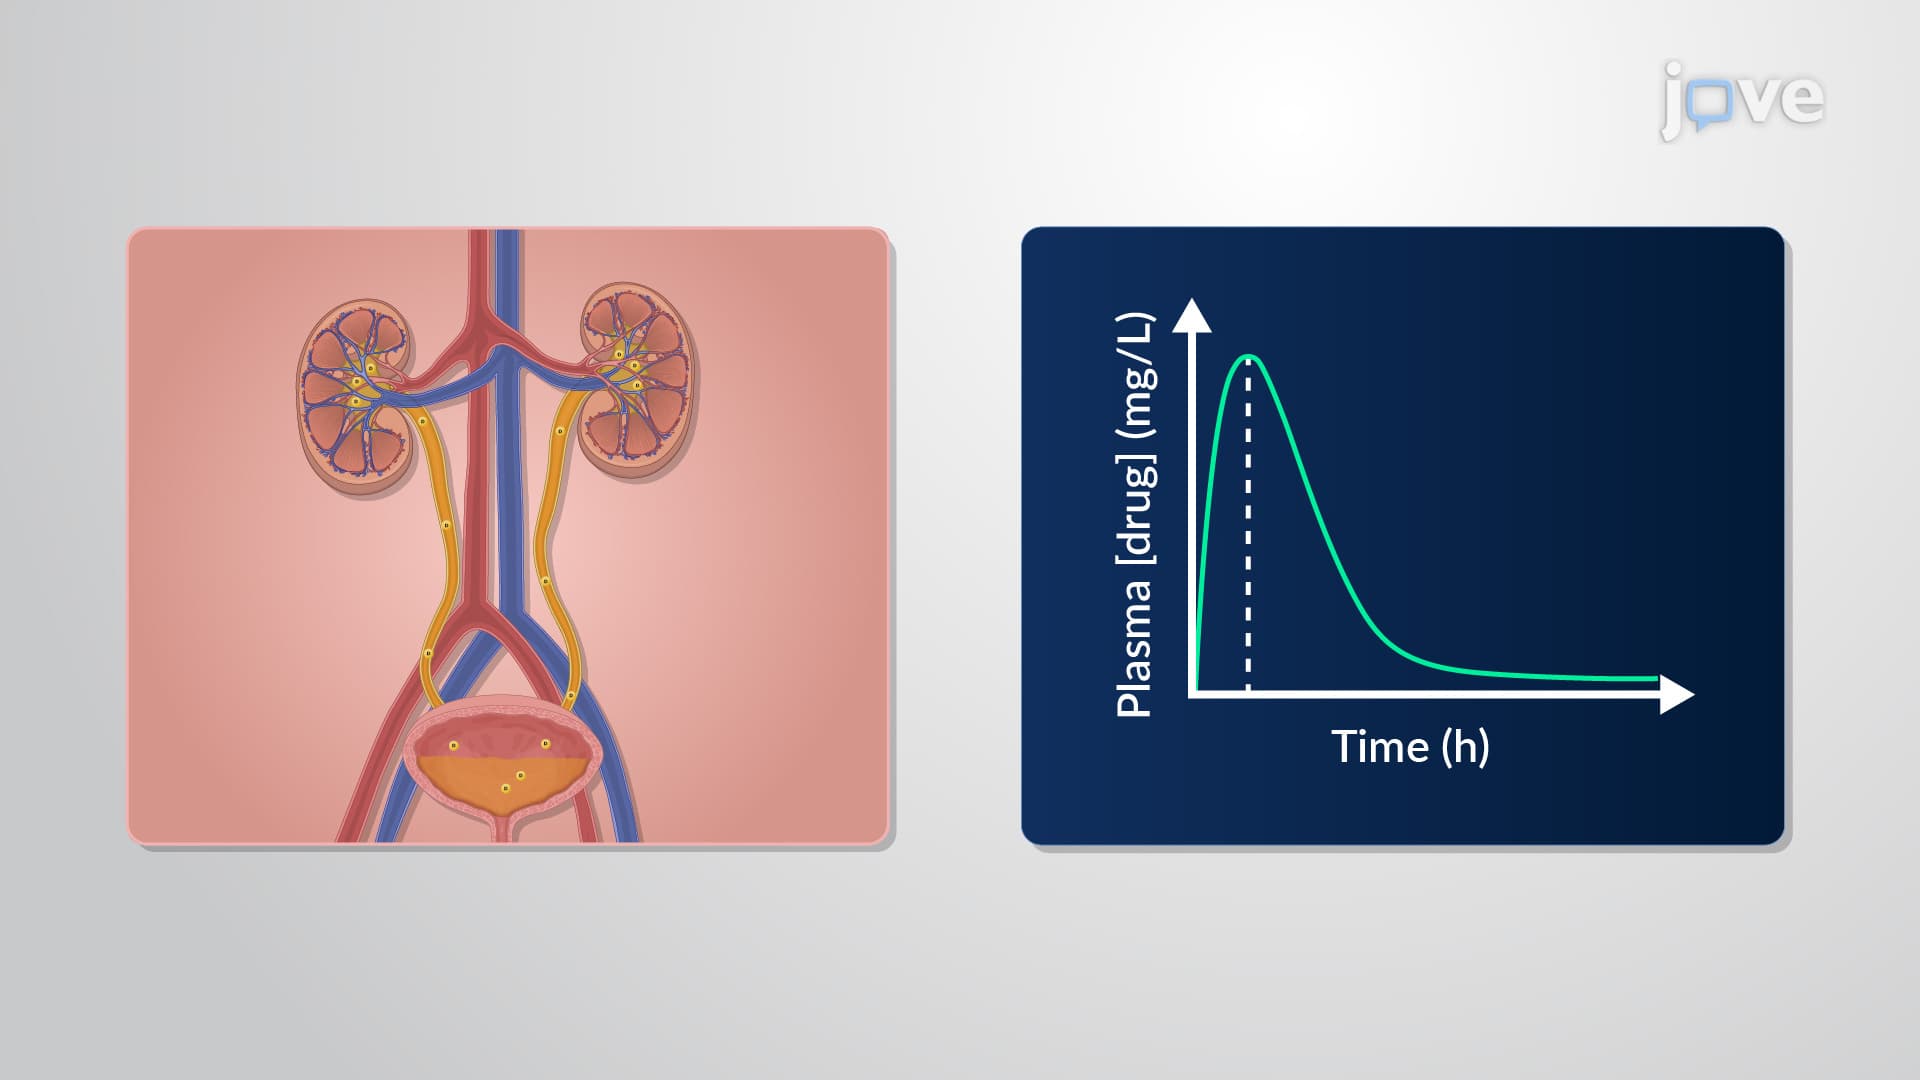
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility