Related Experiment Video
Updated: Sep 5, 2025


Author Spotlight: UAV Remote Sensing for Efficient Invasive Plant Biomass Estimation
Published on: February 9, 2024
Optimal energy efficient path planning of UAV using hybrid MACO-MEA* algorithm: theoretical and experimental approach
E Balasubramanian1, E Elangovan2, P Tamilarasan3
1Department of Mechanical Engineering, Head-Centre for Autonomous System Research, Vel Tech Rangarajan Dr Sagunthala R & D Institute of Science and Technology, Avadi, Chennai, Tamilnadu 600062 India.

Abstract:
Autonomous mission capabilities with optimal path are stringent requirements for Unmanned Aerial Vehicle (UAV) navigation in diverse applications. The proposed research framework is to identify an energy-efficient optimal path to achieve the designated missions for the navigation of UAVs in various constrained and denser obstacle prone regions. Hence, the present work is aimed to develop an optimal energy-efficient path planning algorithm through combining well known modified ant colony optimization algorithm (MACO) and a variant of A*, namely the memory-efficient A* algorithm (MEA*) for avoiding the obstacles in three dimensional (3D) environment and arrive at an optimal path with minimal energy consumption. The novelty of the proposed method relies on integrating the above two efficient algorithms to optimize the UAV path planning task. The basic design of this study is, that by utilizing an improved version of the pheromone strategy in MACO, the local trap and premature convergence are minimized, and also an optimal path is found by means of reward and penalty mechanism. The sole notion of integrating the MEA* algorithm arises from the fact that it is essential to overcome the stringent memory requirement of conventional A* algorithm and to resolve the issue of tracking only the edges of the grids. Combining the competencies of MACO and MEA*, a hybrid algorithm is proposed to avoid obstacles and find an efficient path. Simulation studies are performed by varying the number of obstacles in a 3D domain. The real-time flight trials are conducted experimentally using a UAV by implementing the attained optimal path. A comparison of the total energy consumption of UAV with theoretical analysis is accomplished. The significant finding of this study is that, the MACO-MEA* algorithm achieved 21% less energy consumption and 55% shorter execution time than the MACO-A*. moreover, the path traversed in both simulation and experimental methods is 99% coherent with each other. it confirms that the developed hybrid MACO-MEA* energy-efficient algorithm is a viable solution for UAV navigation in 3D obstacles prone regions.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Maximum Power Transfer
By substituting the entire circuit with...
 01:23
Maximum Power Flow and Line Loadability
 01:37
Energy to Drive Translocation
Generally, polypeptides are unfolded by two distinct...
 01:14
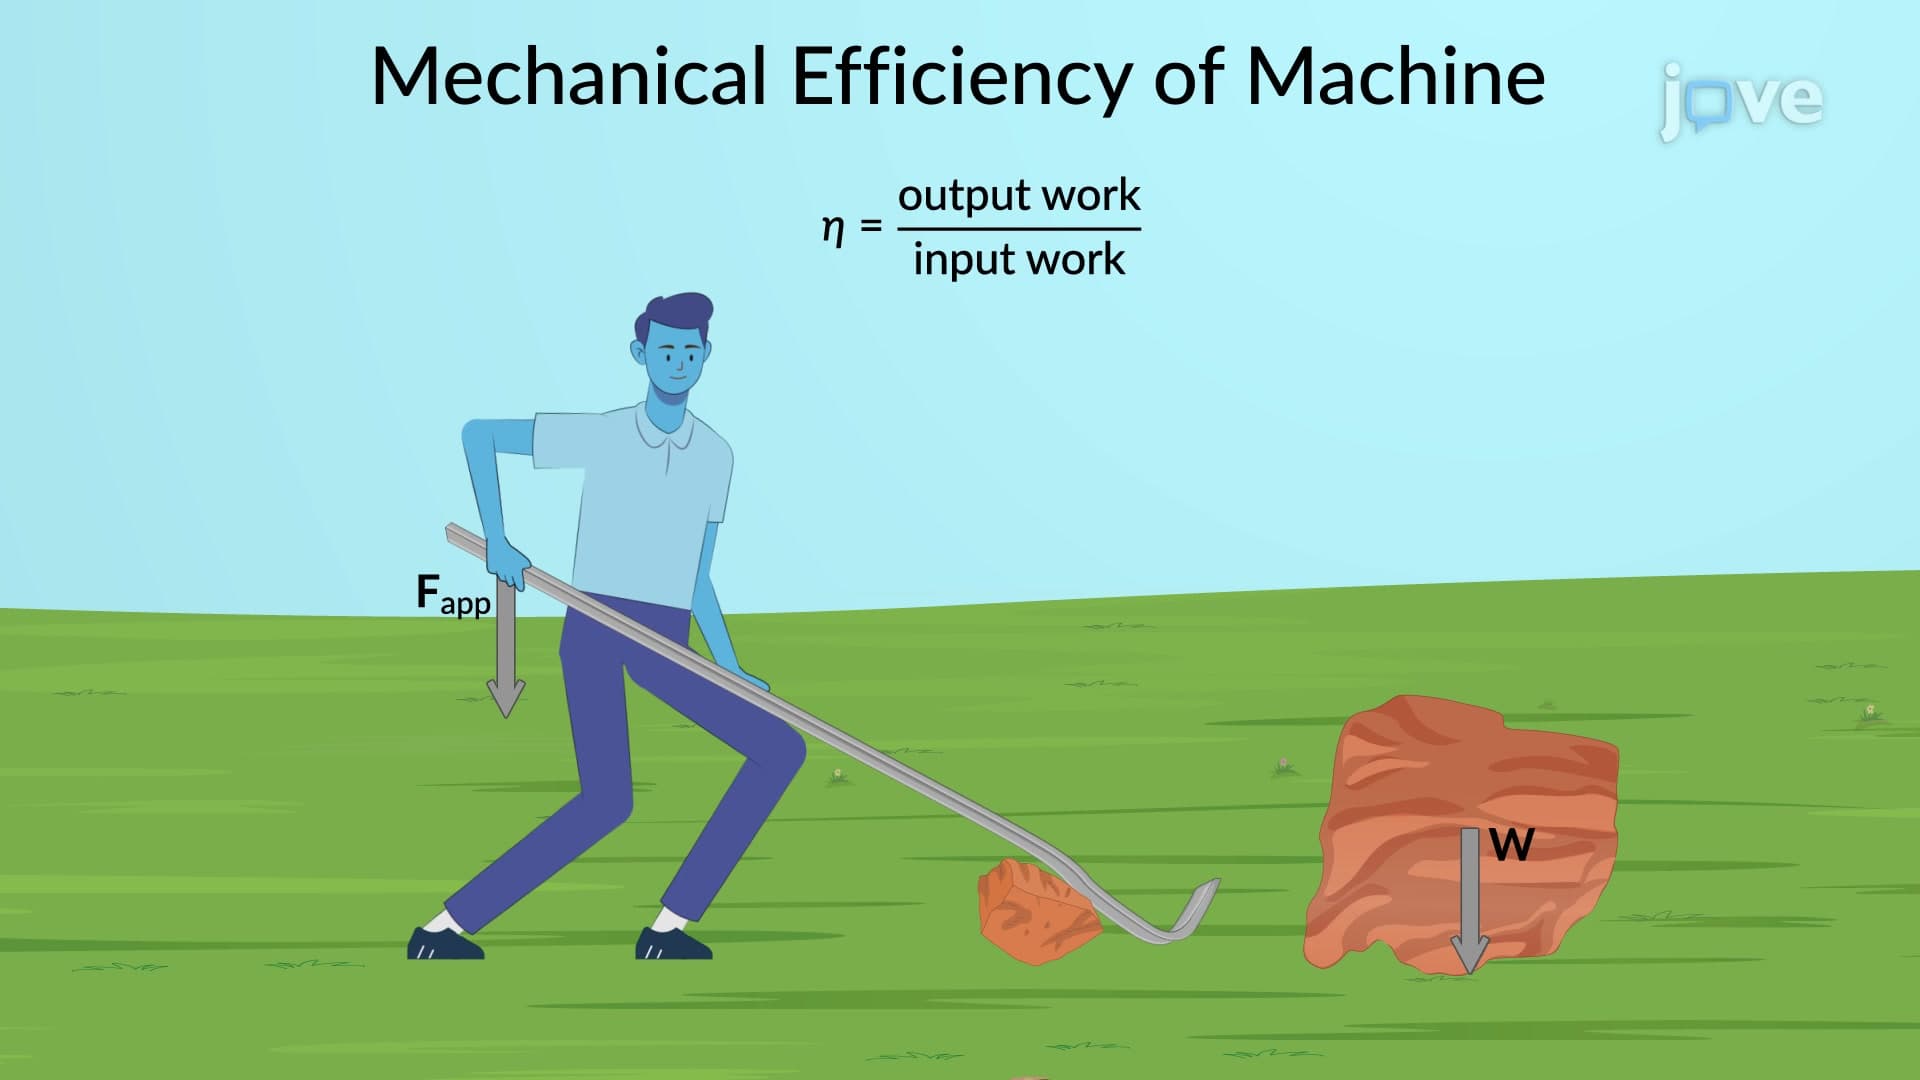
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:23
Plane Potential Flows
Uniform...