Related Experiment Video
Updated: Sep 5, 2025


Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Output feedback full-order sliding mode control for a three-tank system
Akihiko Hosokawa1, Yusei Mitsuhashi1, Kazuki Satoh1
1Department of Intelligent Systems Engineering, College of Engineering, Ibaraki University, 4-12-1 Nakanarusawa, Hitachi, Ibaraki 316-8511, Japan.

Abstract:
A robust output feedback nonlinear control method is proposed for output tracking of an uncertain three-tank system by using only the level sensor of the target tank. By using a coordinate transformation, we first transform the system model into a canonical form with uncertainties. The canonical system's state variables are estimated by a higher-order sliding mode differentiator based on the measurement of the target tank's liquid level. Then based on the estimated state variables, a continuous full-order sliding mode controller is constructed which can eliminate the effects of both the additive and multiplicative uncertainties. Rigorous analysis is carried out to clarify the control performance. And the effectiveness of the proposed method is verified by experimental studies on the Inteco Multi-tank system.
Related Concept Videos
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:18
Second Order systems II
 01:16
Control Volume and System Representations
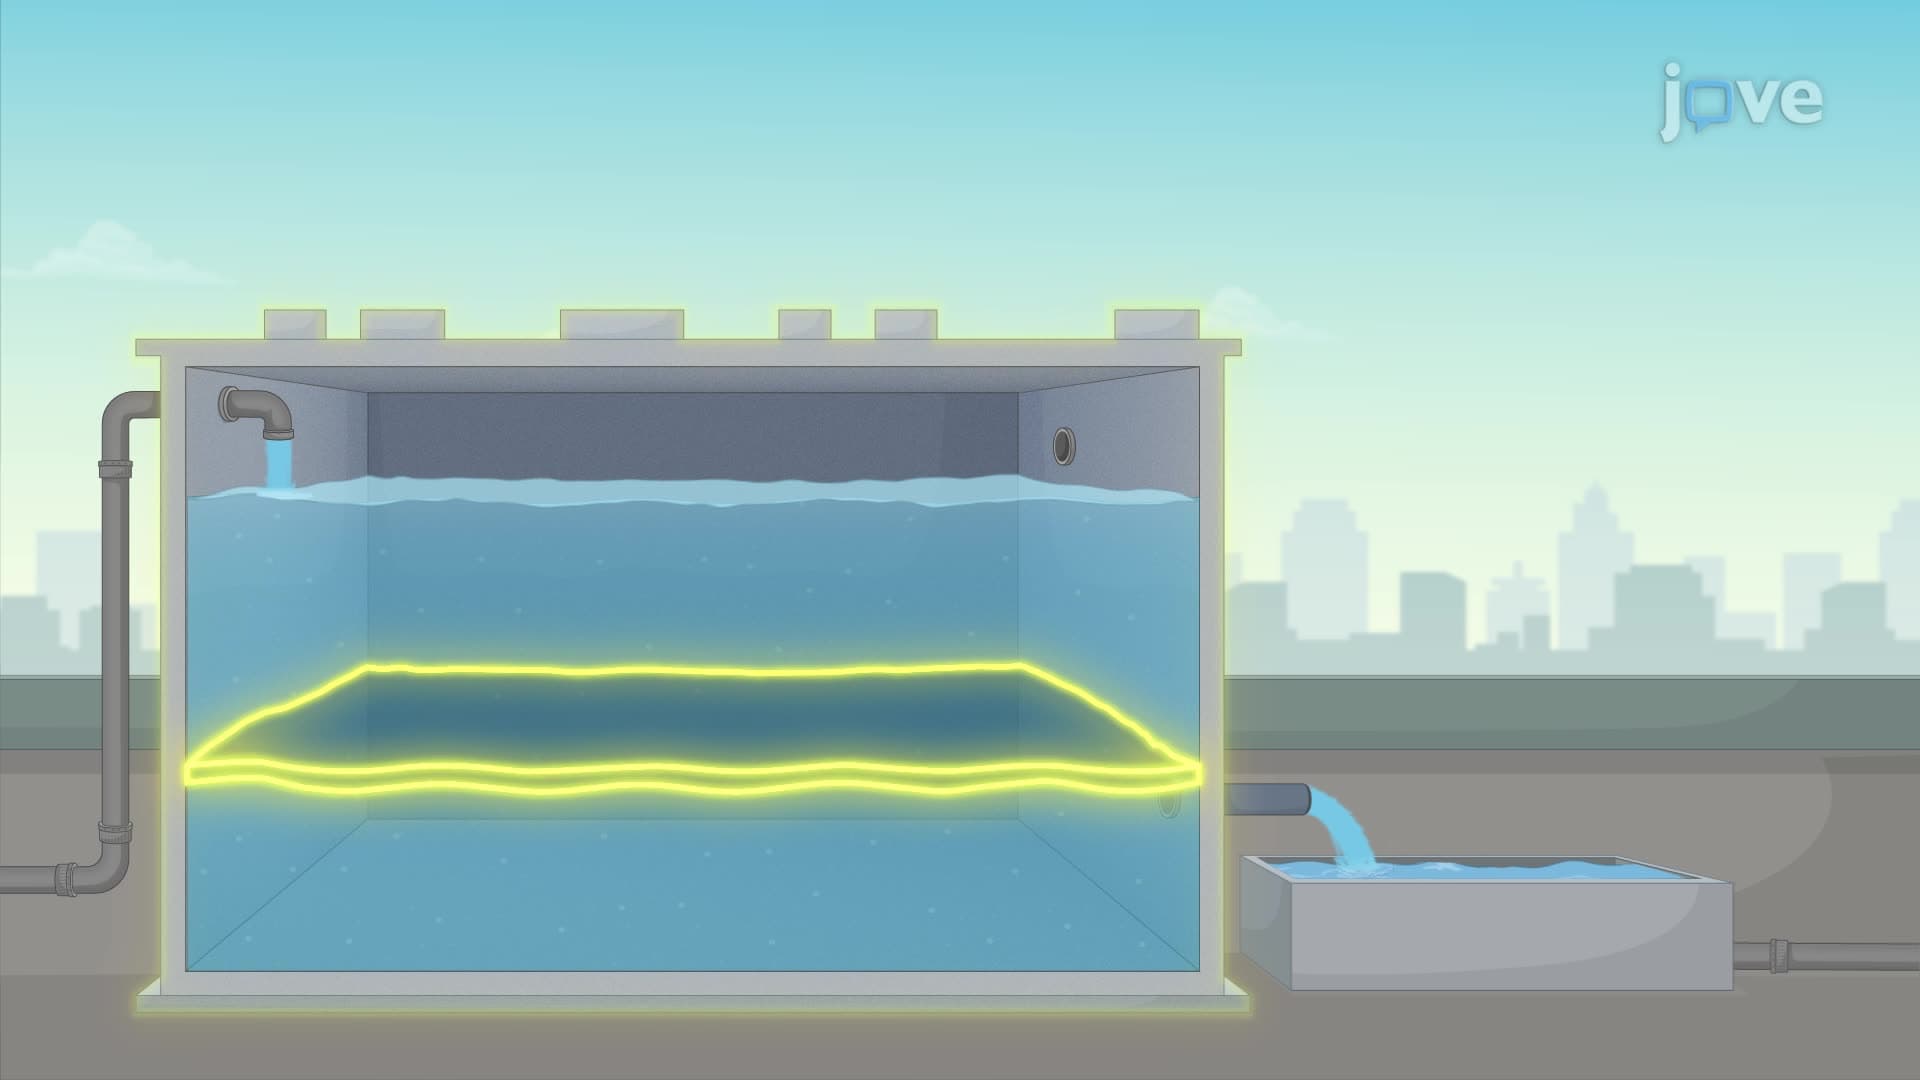
The control volume approach considers a stationary region in space through which fluid flows. This region is bounded by a control surface. For instance, in the case of water...
 01:19
PID Controller
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...