Related Experiment Video
Updated: Sep 3, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Bayesian Integration in a Spiking Neural System for Sensorimotor Control
Massimo Grillo1, Alice Geminiani2, Cristiano Alessandro3,4
1Nearlab, Department of Electronics, Information and Bioengineering, Politecnico di Milano, 20133, Milan, Italy massimo.grillo97@gmail.com.

Abstract:
The brain continuously estimates the state of body and environment, with specific regions that are thought to act as Bayesian estimator, optimally integrating noisy and delayed sensory feedback with sensory predictions generated by the cerebellum. In control theory, Bayesian estimators are usually implemented using high-level representations. In this work, we designed a new spike-based computational model of a Bayesian estimator. The state estimator receives spiking activity from two neural populations encoding the sensory feedback and the cerebellar prediction, and it continuously computes the spike variability within each population as a reliability index of the signal these populations encode. The state estimator output encodes the current state estimate. We simulated a reaching task at different stages of cerebellar learning. The activity of the sensory feedback neurons encoded a noisy version of the trajectory after actual movement, with an almost constant intrapopulation spiking variability. Conversely, the activity of the cerebellar output neurons depended on the phase of the learning process. Before learning, they fired at their baseline not encoding any relevant information, and the variability was set to be higher than that of the sensory feedback (more reliable, albeit delayed). When learning was complete, their activity encoded the trajectory before the actual execution, providing an accurate sensory prediction; in this case, the variability was set to be lower than that of the sensory feedback. The state estimator model optimally integrated the neural activities of the afferent populations, so that the output state estimate was primarily driven by sensory feedback in prelearning and by the cerebellar prediction in postlearning. It was able to deal even with more complex scenarios, for example, by shifting the dominant source during the movement execution if information availability suddenly changed. The proposed tool will be a critical block within integrated spiking, brain-inspired control systems for simulations of sensorimotor tasks.
More Related Videos
 11:54
Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
 14:47
Author Spotlight: Combined Peripheral Nerve Stimulation and Controllable Pulse Parameter Transcranial Magnetic Stimulation to Probe Sensorimotor Control and Learning
Published on: April 21, 2023
Related Concept Videos
 01:28
Integration of Synaptic Events
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:19
The Role of Ion Channels in Neuronal Computation
Sometimes a single EPSP is strong enough to induce an action potential in the postsynaptic neuron. However, multiple presynaptic inputs must often create EPSPs around the same time for the postsynaptic neuron to be sufficiently depolarized to fire an action potential....
 01:23
Propagation of Action Potentials
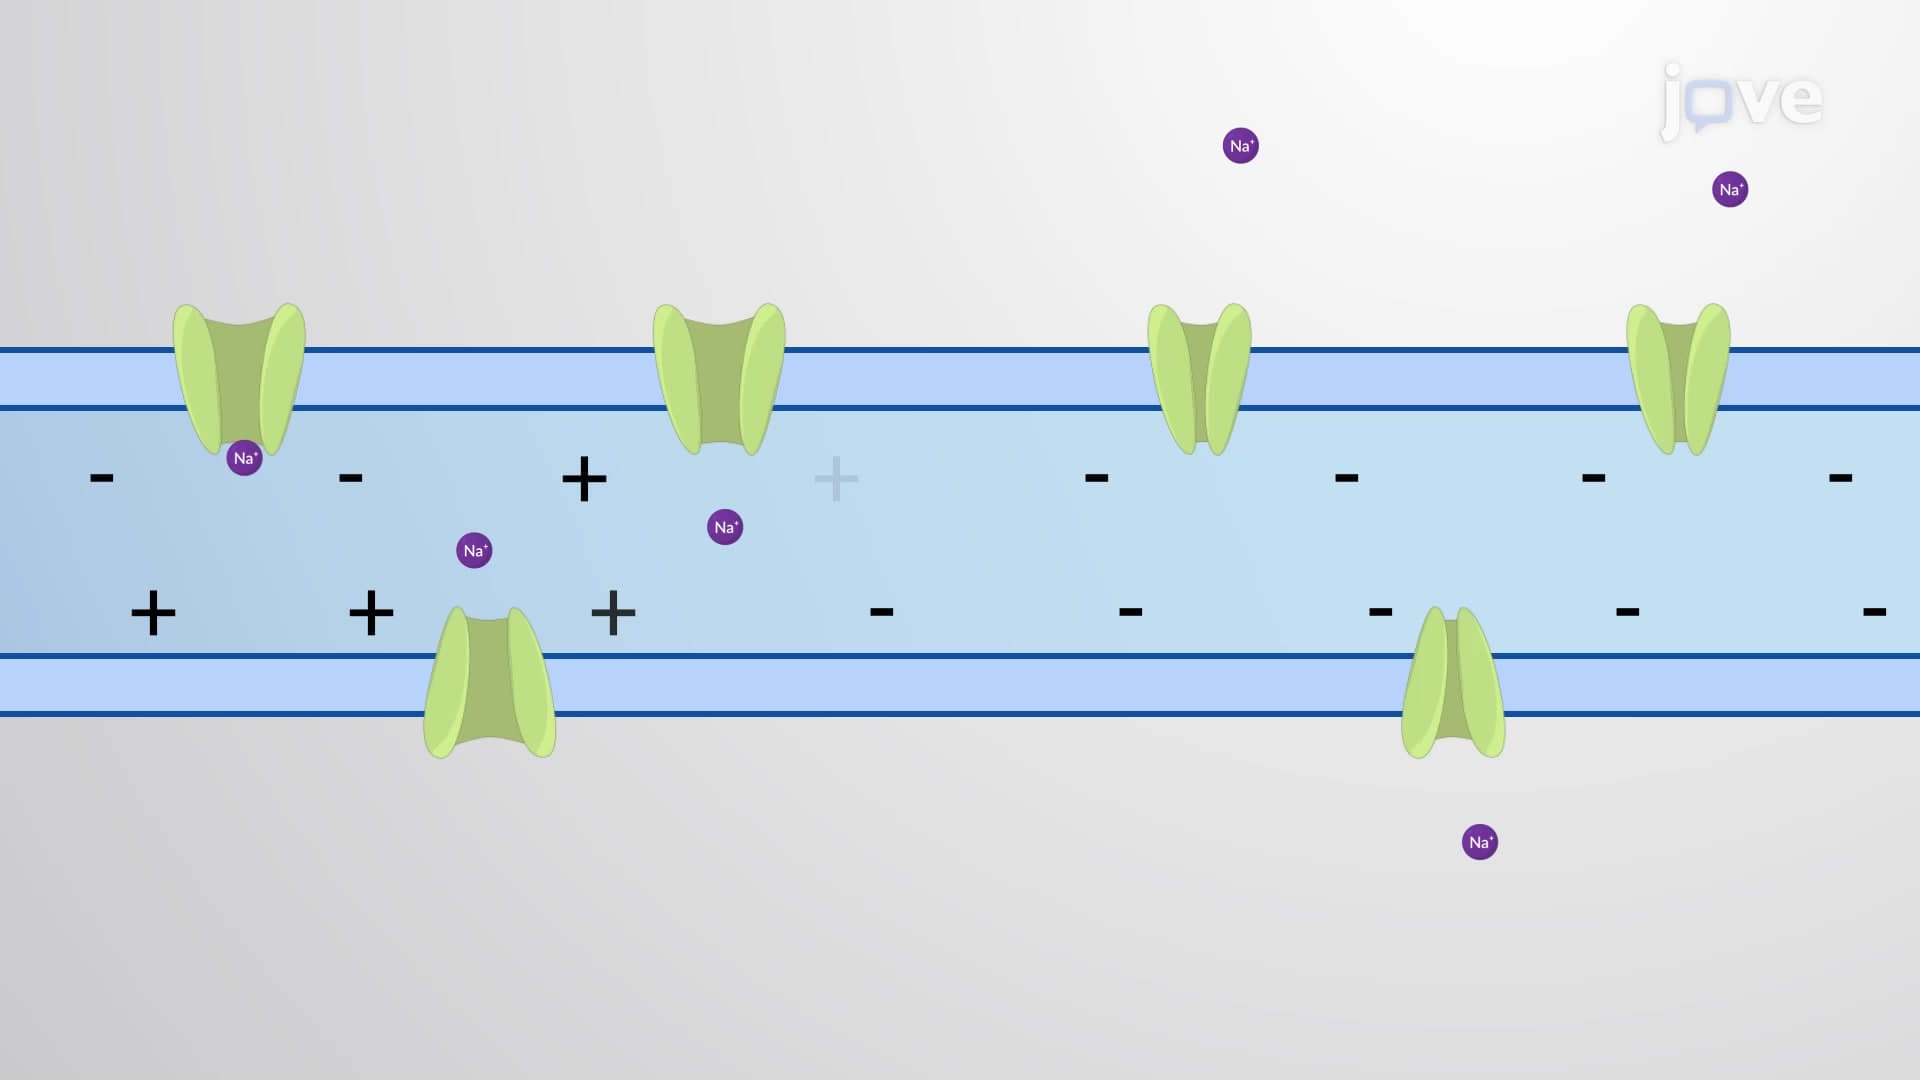
Neurons (nerve cells) have a resting membrane potential, with a slightly negative charge inside compared to outside. This is maintained by ion channels, such as sodium (Na+) and potassium (K+) channels, which control the flow of ions. When a stimulus, like a touch or a signal from another neuron, triggers the neuron, sodium channels open, allowing sodium ions to...
 01:37
Neural Regulation
 01:25
Neural Circuits
Neuronal pools are collections of nerve cells with similar functions and interact through chemical and electrical signals. These pools include both interneurons (the central neural circuit nodes that...