Supermodal Decomposition of the Linear Swing Equation for Multilayer Networks
Related Experiment Video
Updated: Sep 2, 2025
Author Spotlight: Advancing Large-Scale Neural Dynamics Through HD-MEA Technology
Published on: March 8, 2024
Kshitij Bhatta1, Amirhossein Nazerian2, Francesco Sorrentino2
1Department of Mechanical and Aerospace Engineering, Univeristy of Virginia, Charlottesvile, VA 22903, USA.

Abstract:
We study the swing equation in the case of a multilayer network in which generators and motors are modeled differently; namely, the model for each generator is given by second order dynamics and the model for each motor is given by first order dynamics. We also remove the commonly used assumption of equal damping coefficients in the second order dynamics. Under these general conditions, we are able to obtain a decomposition of the linear swing equation into independent modes describing the propagation of small perturbations. In the process, we identify symmetries affecting the structure and dynamics of the multilayer network and derive an essential model based on a 'quotient network.' We then compare the dynamics of the full network and that of the quotient network and obtain a modal decomposition of the error dynamics. We also provide a method to quantify the steady-state error and the maximum overshoot error. Two case studies are presented to illustrate application of our method.
More Related Videos
Related Concept Videos
 01:21
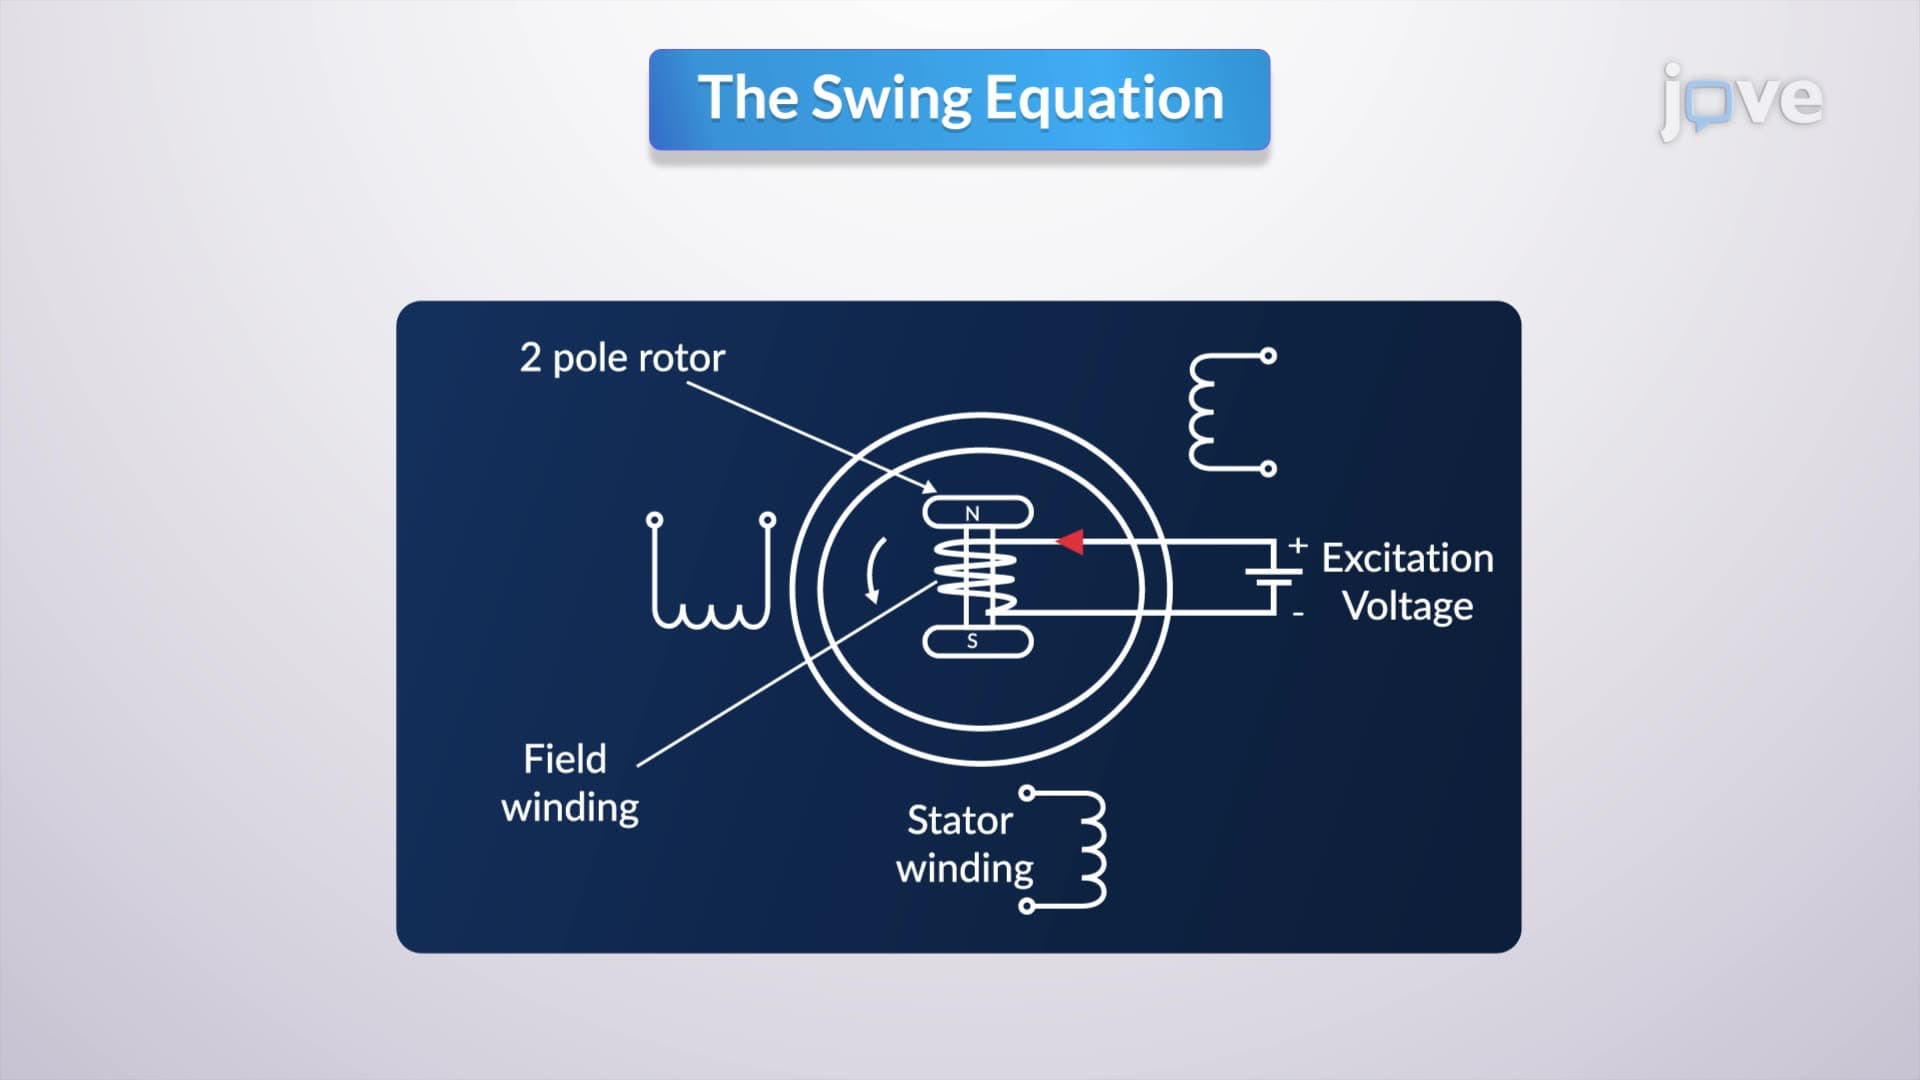
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
State Space to Transfer Function
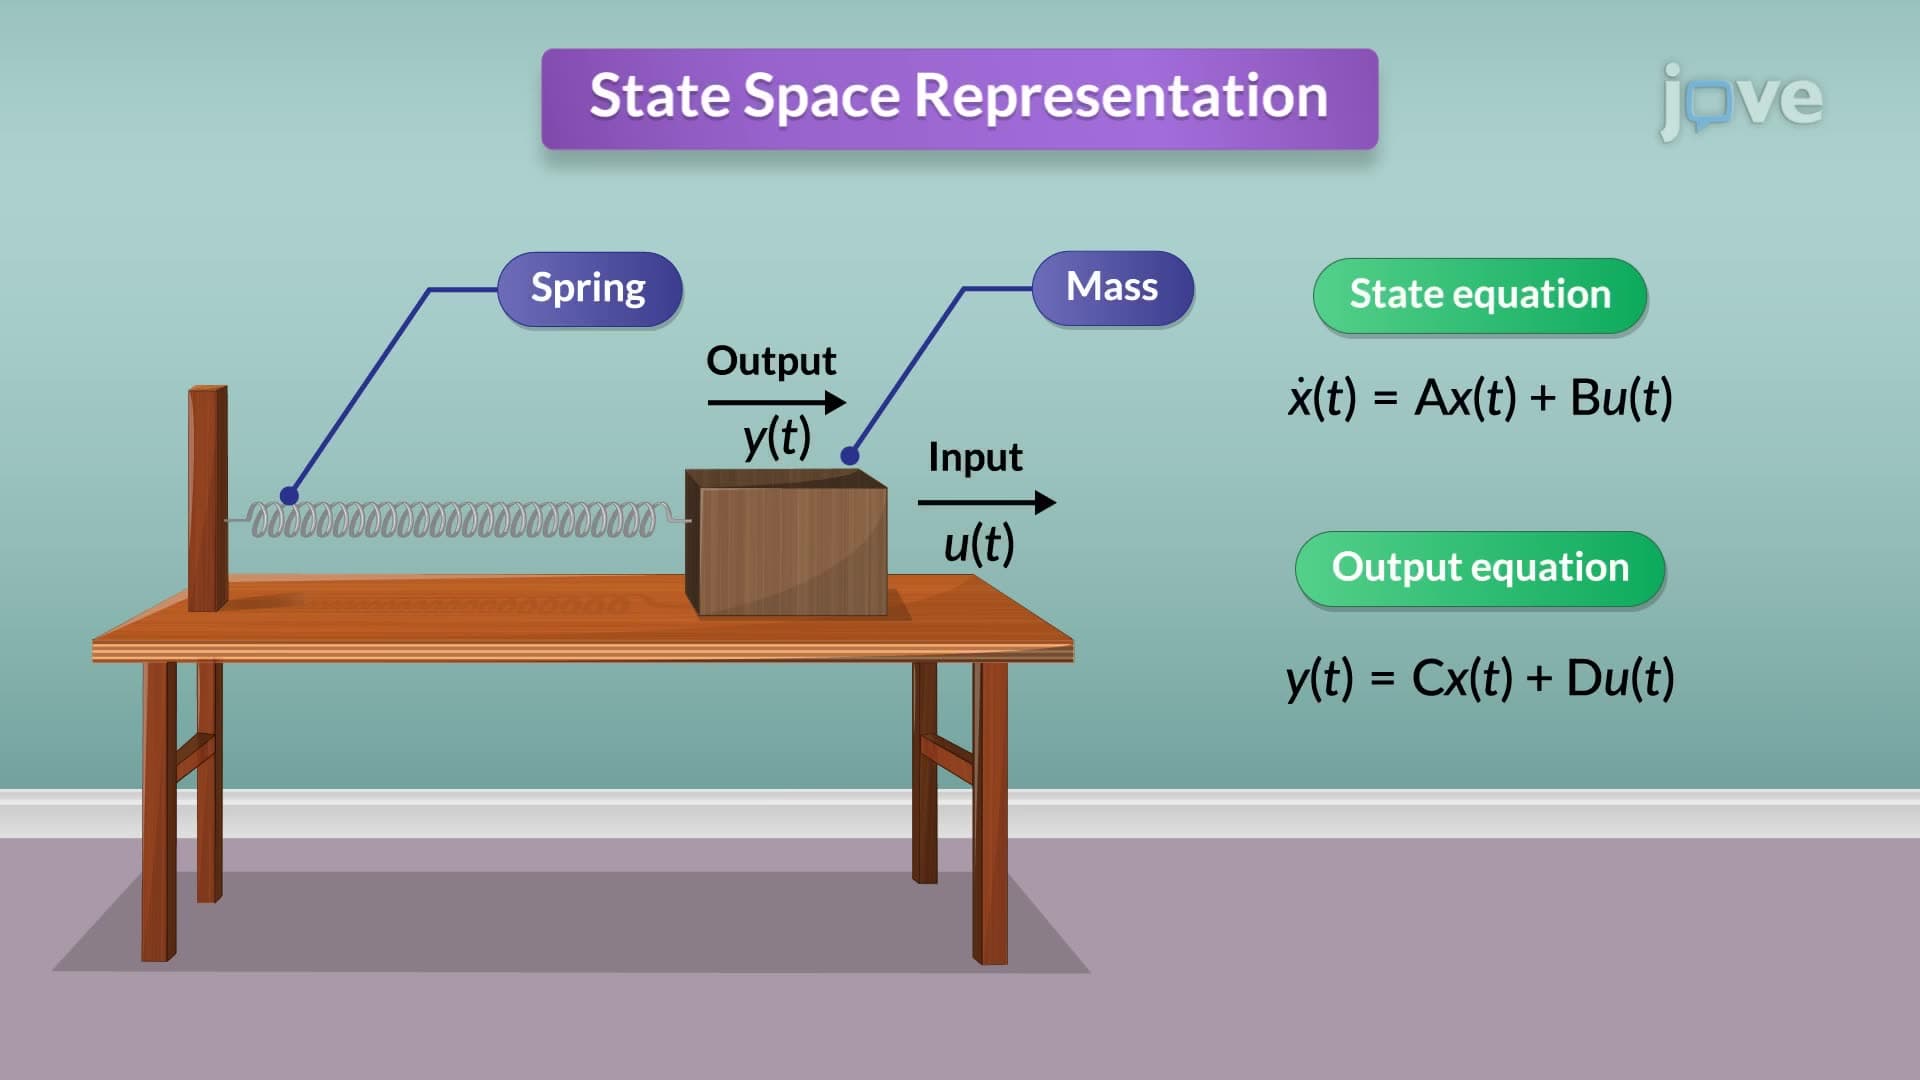
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: