Related Experiment Video
Updated: Sep 1, 2025
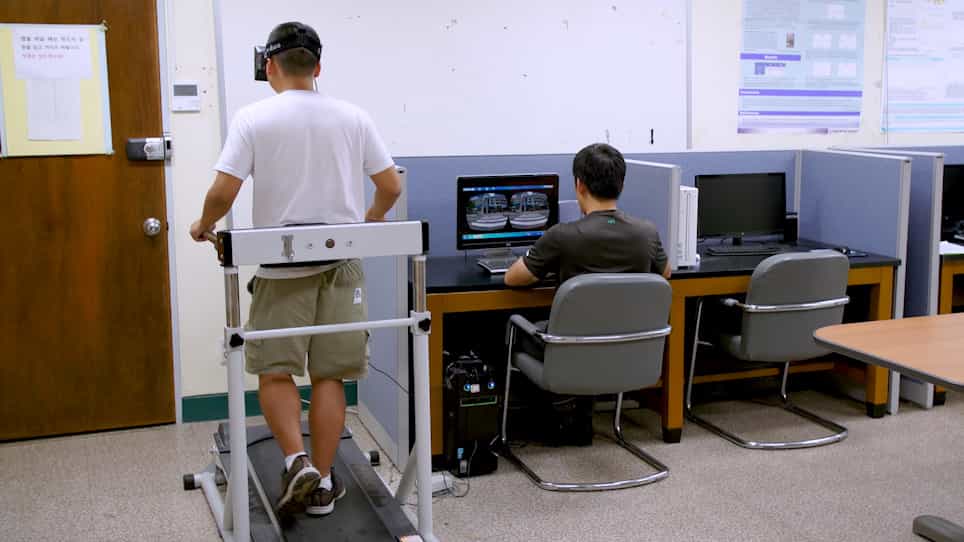

Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
Evaluation of automated emergency braking system's avoidance of pedestrian crashes at intersections under occluded
Mohamed Abdel-Aty1, Qing Cai1, Yina Wu1
1Department of Civil, Environmental and Construction Engineering, University of Central Florida, Orlando, FL 32816, USA.

Abstract:
Pedestrians' red-light crossing can present a threat to themselves and the safety at intersections, especially for the through vehicles since their speeds are higher compared to the turning vehicles. The automated emergency braking (AEB) system could actively detect pedestrians and react to avoid potential conflicts. This study contributes to evaluate the effectiveness of the AEB system under occlusion conditions. The braking algorithm was developed in the virtual simulator CARLA to control the ego vehicle. Three occlusion scenarios in which the sensor of the AEB system could not detect the pedestrian if the pedestrian is occluded by a stopping vehicle. The evaluation experiments were conducted at a typical 4-leg intersection considering different motion statuses of the ego vehicle and pedestrian. The effects of field of view (FOV) of the sensor and activation threshold of the AEB system were also explored. The study indicated that the effectiveness of the AEB system could be reduced by the occlusion time. A longer activation threshold is recommended if the pedestrian is potentially occluded for a long time. The effects of other factors such as the speed of the ego vehicle and pedestrian and scenarios were also identified.

