Related Experiment Video
Updated: Aug 30, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Adaptive Fault-Tolerant Formation Control of Heterogeneous Multi-Agent Systems under Directed Communication Topology
Shangkun Liu1,2, Bin Jiang1,2, Zehui Mao1,2
1College of Automation Engineering, Nanjing University of Aeronautics and Astronautics, Nanjing 211106, China.

Abstract:
This paper investigates the adaptive fault-tolerant formation control scheme for heterogeneous multi-agent systems consisting of unmanned aerial vehicles (UAVs) and unmanned surface vehicles (USVs) with actuator faults, parameter uncertainties and external disturbances under directed communication topology. Firstly, the dynamic models of UAVs and USVs are introduced, and a unified heterogeneous multi-agent system model with actuator faults is established. Then, a distributed fault-tolerant formation controller is proposed for the unified model of UAVs and USVs in the XY plane by using adaptive updating laws and radial basis function neural network. After that, a decentralized formation-tracking controller is designed for the altitude control system of UAVs. Based on the Lyapunov stability theory, it can be proved that the formation errors and tracking errors are uniformly ultimately bounded which means that the expected time-varying formation is achieved. Finally, a simulation study is given to demonstrate the effectiveness of the proposed scheme.
Related Concept Videos
 01:18
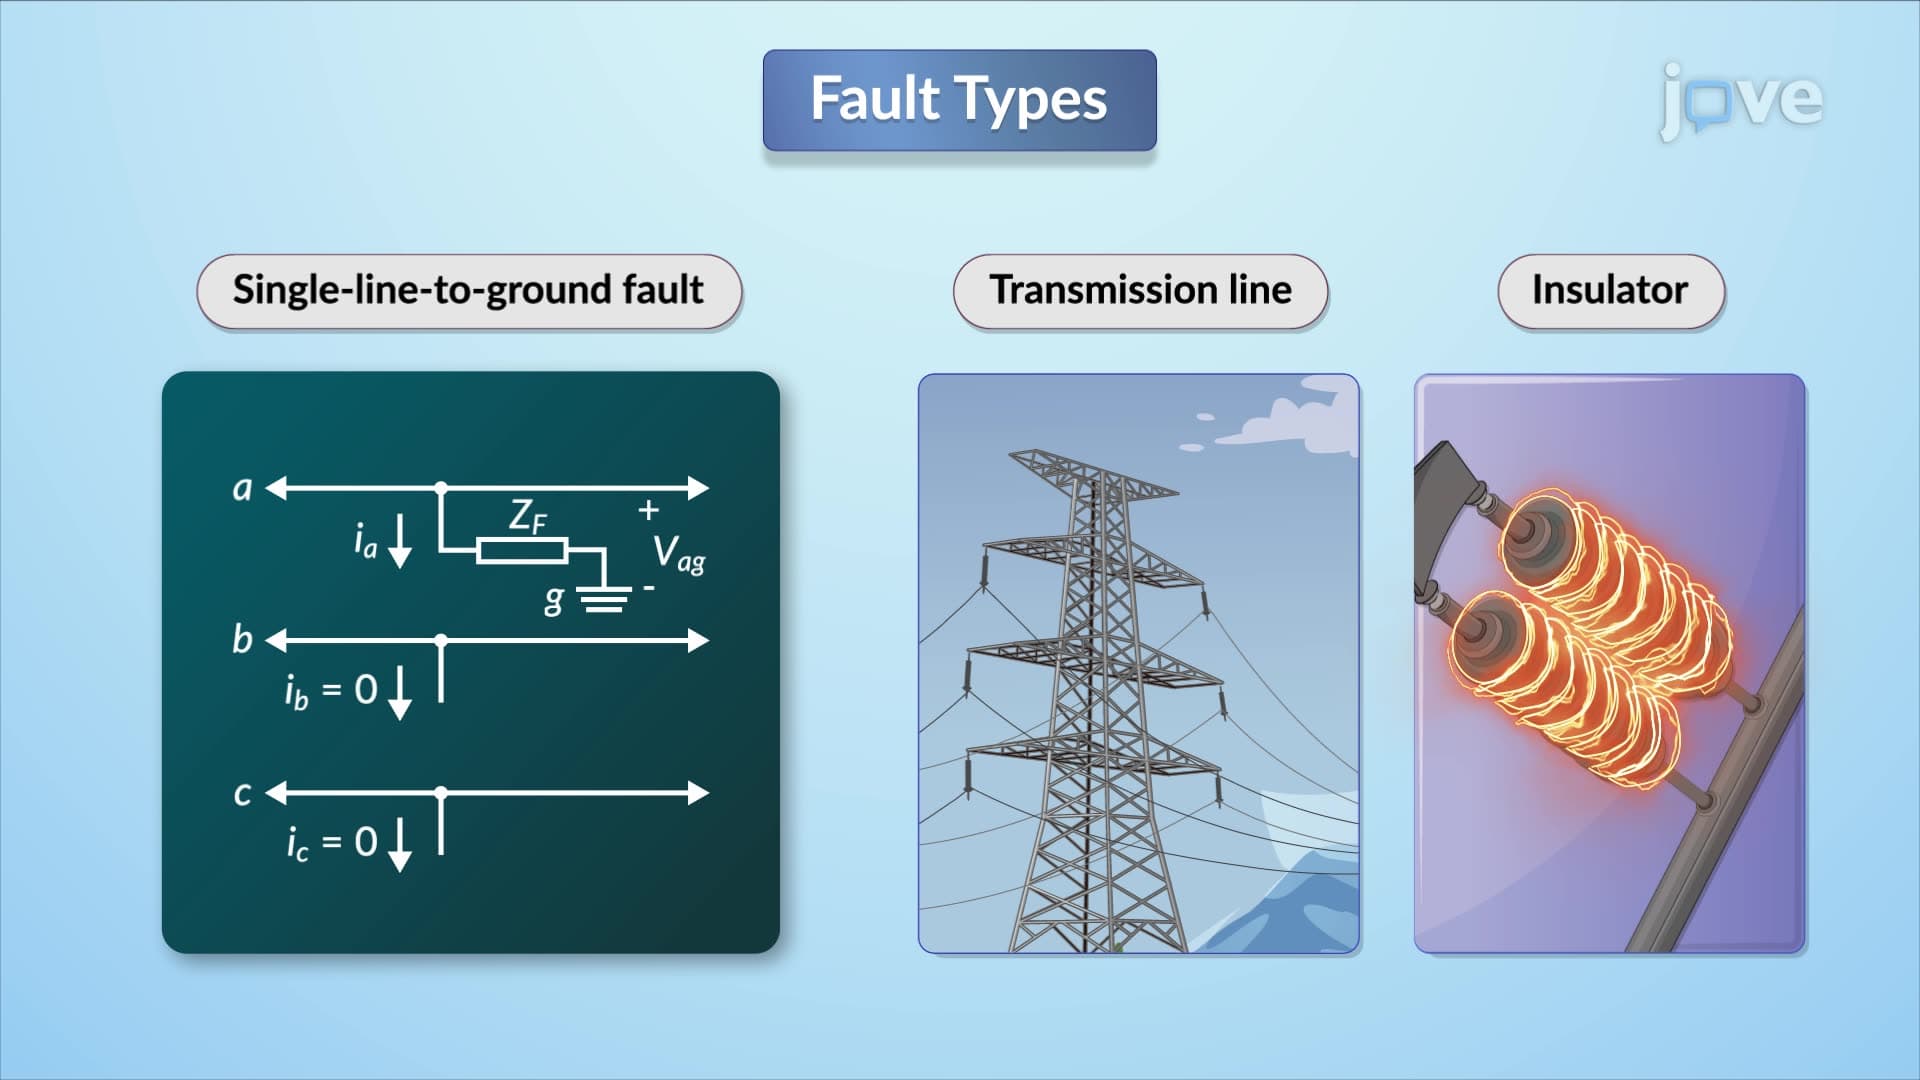
Fault Types
For line-to-line faults occurring between phases B and C, the...
 01:21
Distributed Loads: Problem Solving
 01:16
Zones of Protection
Protective zones are defined by closed dashed lines, containing one or more components. A key characteristic of these zones is the strategic placement of...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...