Related Experiment Video
Updated: Aug 29, 2025
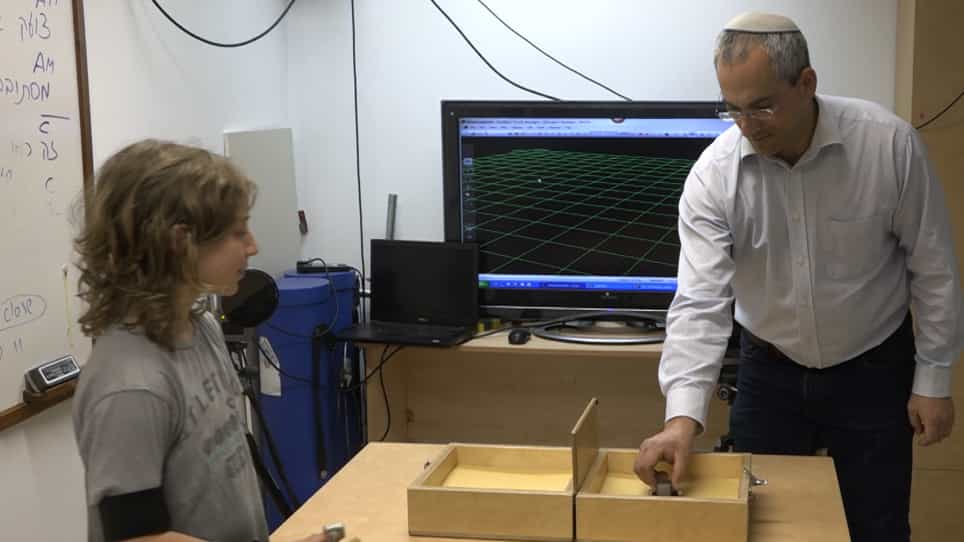
Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Cross-Modal Reconstruction for Tactile Signal in Human-Robot Interaction
1Key Laboratory of Broadband Wireless Communication and Sensor Network Technology, Ministry of Education, School of Communication and Information Engineering, Nanjing University of Posts and Telecommunications, Nanjing 210003, China.

Abstract:
A human can infer the magnitude of interaction force solely based on visual information because of prior knowledge in human-robot interaction (HRI). A method of reconstructing tactile information through cross-modal signal processing is proposed in this paper. In our method, visual information is added as an auxiliary source to tactile information. In this case, the receiver is only able to determine the tactile interaction force from the visual information provided. In our method, we first process groups of pictures (GOPs) and treat them as the input. Secondly, we use the low-rank foreground-based attention mechanism (LAM) to detect regions of interest (ROIs). Finally, we propose a linear regression convolutional neural network (LRCNN) to infer contact force in video frames. The experimental results show that our cross-modal reconstruction is indeed feasible. Furthermore, compared to other work, our method is able to reduce the complexity of the network and improve the material identification accuracy.

Related Concept Videos
 01:33
Somatosensation
 01:10
Reconstruction of Signal using Interpolation