Related Experiment Video
Updated: Aug 27, 2025

Stereo-Imaging System DLT Calibration to Capture 3D In Situ Displacements of Stretched Peripheral Nerves
Published on: January 12, 2024
Wireless Sensor Network-Based Rigid Body Localization for NLOS Parameter Estimation
Pengwu Wan1, Jian Wei1, Jin Wang1
1School of Communications and Information Engineering & School of Artificial Intelligence, Xi'an University of Posts and Telecommunications, Xi'an 710121, China.

Abstract:
In wireless sensor network (WSN)-based rigid body localization (RBL) systems, the non-line-of-sight (NLOS) propagation of the wireless signals leads to severe performance deterioration. This paper focuses on the RBL problem under the NLOS environment based on the time of arrival (TOA) measurement between the sensors fixed on the rigid body and the anchors, where the NLOS parameters are estimated to improve the RBL performance. Without any prior information about the NLOS environment, the highly non-linear and non-convex RBL problem is transformed into a difference of convex (DC) programming, which can be solved by using the concave-convex procedure (CCCP) to determine the position of the rigid body sensors and the NLOS parameters. To avoid error accumulation, the obtained NLOS parameters are utilized to refine the localization performance of the rigid body sensors. Then, the accurate position and the orientation of the rigid body in two-Dimensional space are obtained according to the relative deflection angle method. To reduce the computational complexity, the singular value decomposition (SVD) method is employed to solve the problem in three-Dimensional space. Simulation results show that the proposed method can effectively improve the performance of the rigid body localization based on the wireless sensor network in NLOS environment.
More Related Videos
 04:13
Using a Real-Time Locating System to Measure Walking Activity Associated with Wandering Behaviors Among Institutionalized Older Adults
Published on: February 8, 2019
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
Related Concept Videos
 01:21
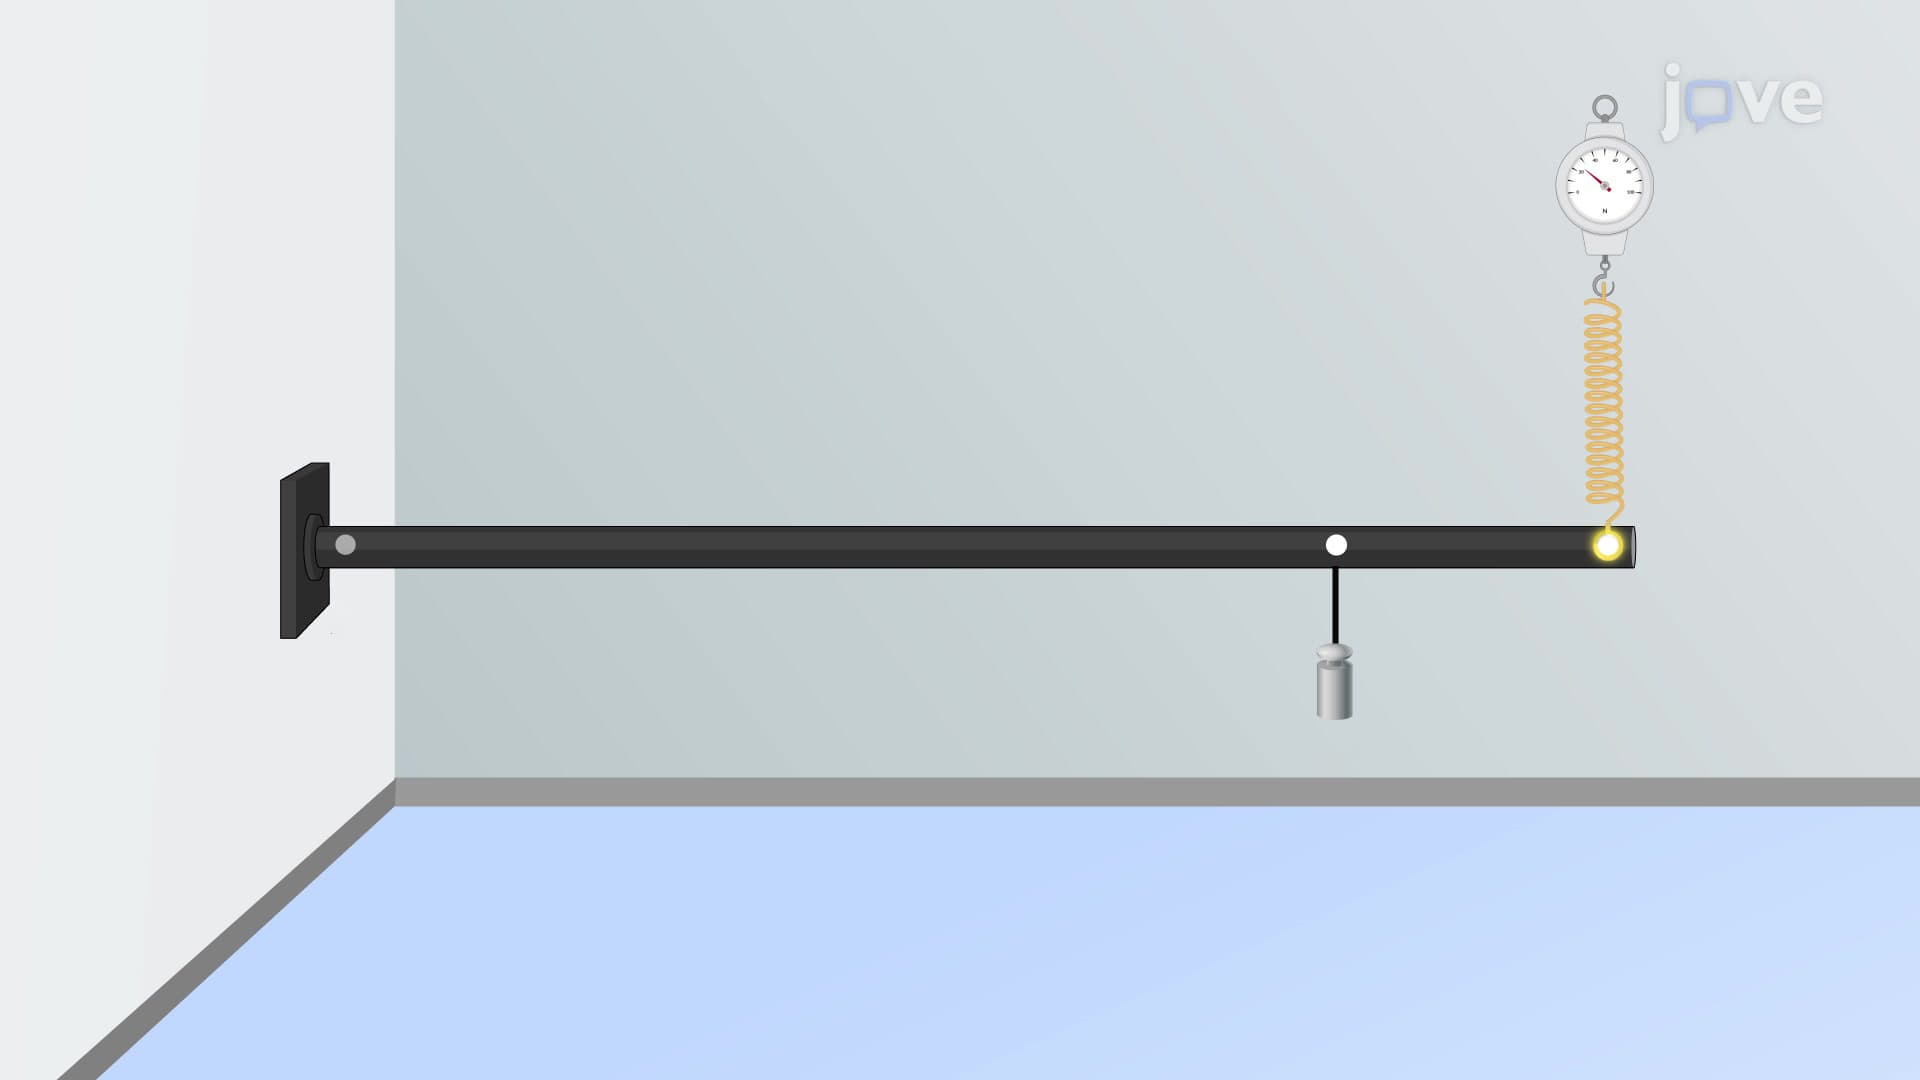
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
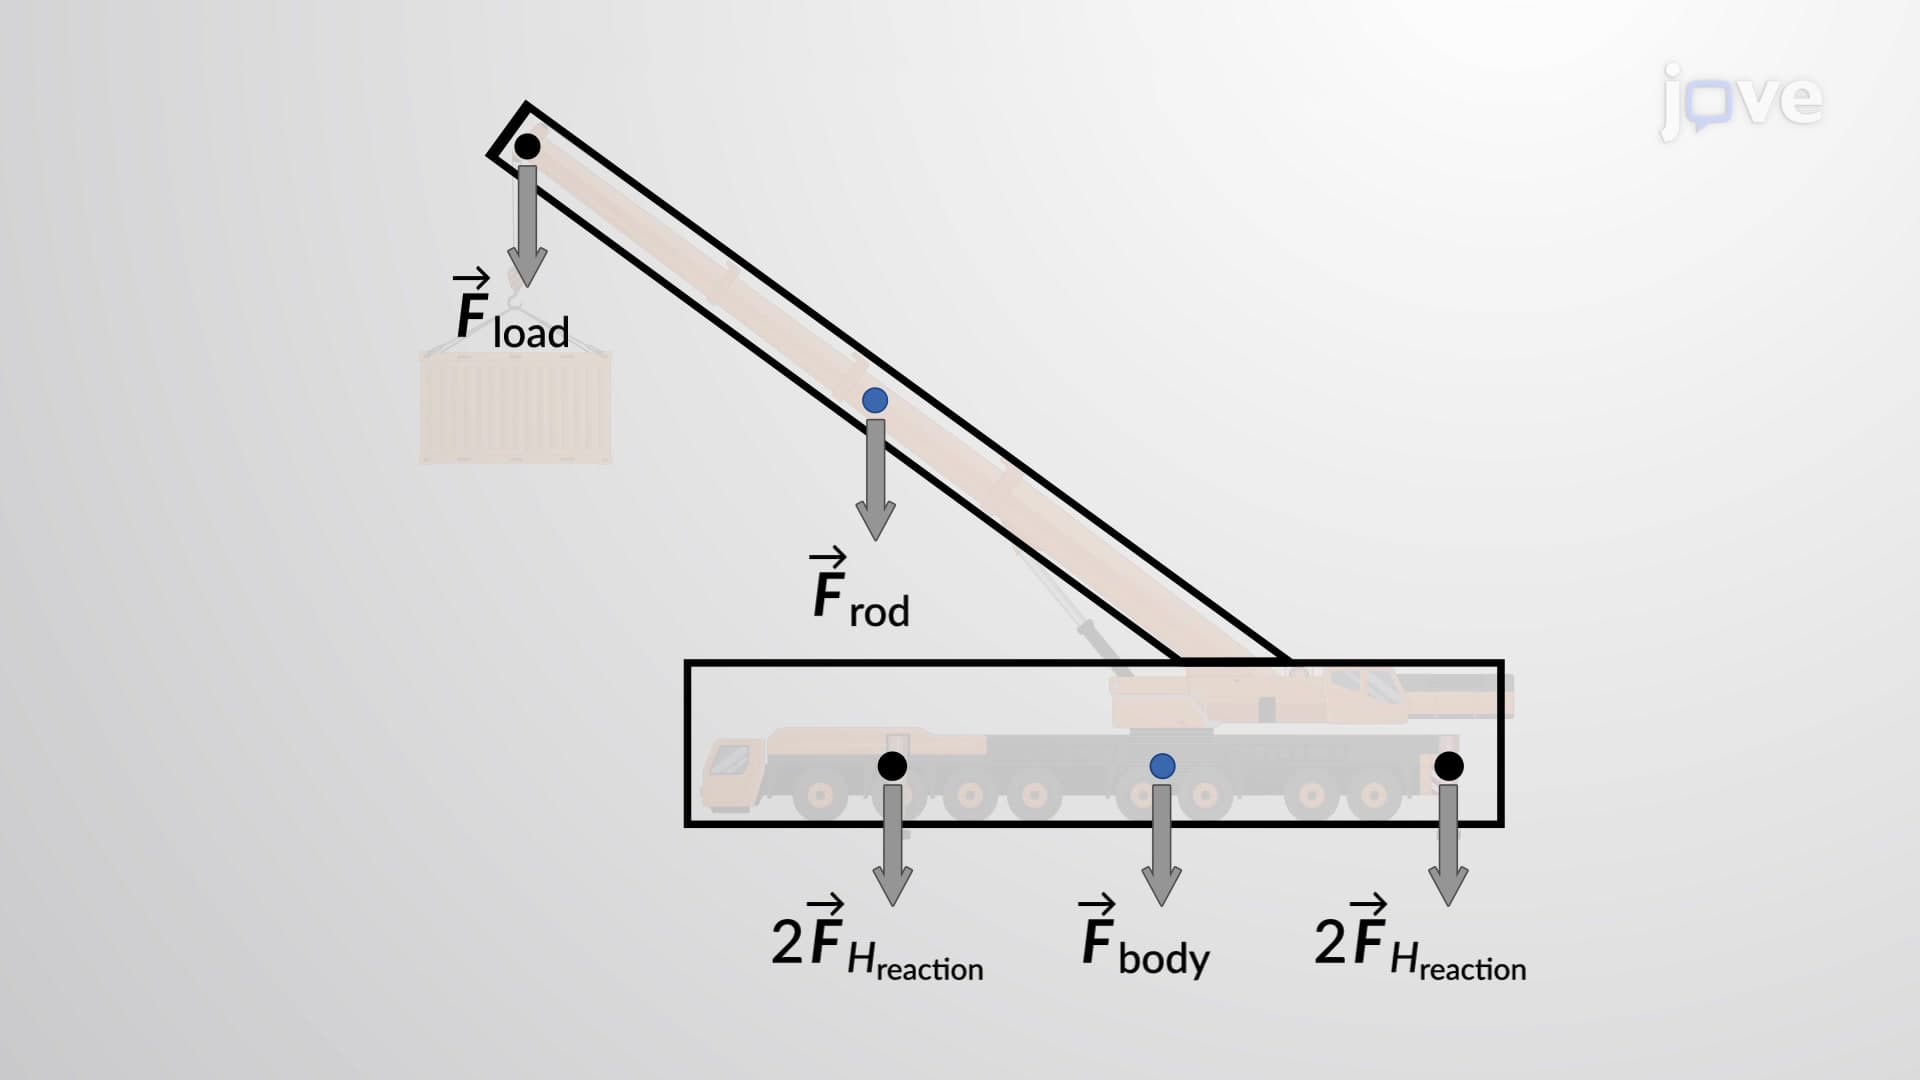
Rigid Body Equilibrium Problems - I
 01:30
Types of Global Positioning System Surveys
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...