Related Experiment Video
Updated: Aug 27, 2025

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Modeling, Simulation and Implementation of All Terrain Adaptive Five DOF Robot
Zhe Wang1, Jianwei Zhao1, Gang Zeng1
1School of Mechanical Electronic & Information Engineering, China University of Mining and Technology-Beijing, Beijing 100089, China.

Abstract:
The ability of an off-road robot to traverse obstacles determines whether the robot can complete complex environmental tasks. In order to improve the off-road ability of off-road robots, this paper proposes a new design idea, in which four hub motors are the power system of the robot, the steering system of the robot is composed of a steering machine and a stepping motor, and a five degree of freedom robot model is established. The body structure is designed according to the characteristics of arthropods. The body structure is divided into three modules, and the connecting rod is used as the joint system of the robot to connect the three parts. The body can deform when facing complex obstacles, so as to adapt to different terrains. Then the body structure is simplified, and a mathematical model is established to describe the mathematical relationship between body joint changes. In order to verify the ability of the adaptive all-terrain cross-country robot to traverse obstacles, the load-bearing experiment and obstacle-crossing simulation experiment were carried out through Adams software, and the continuous traversing performance at low obstacles and the ability to break through high obstacles were tested, respectively. The experimental results prove that the designed adaptive all-terrain off-road robot is feasible, has good carrying capacity, and has good passability in the face of low obstacles and high obstacles. Using Ansys software to perform finite element analysis on the wheel connection, the experimental results show that the strength meets the material strength requirements. Finally, a real vehicle test is carried out to verify the correctness of the simulation results.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
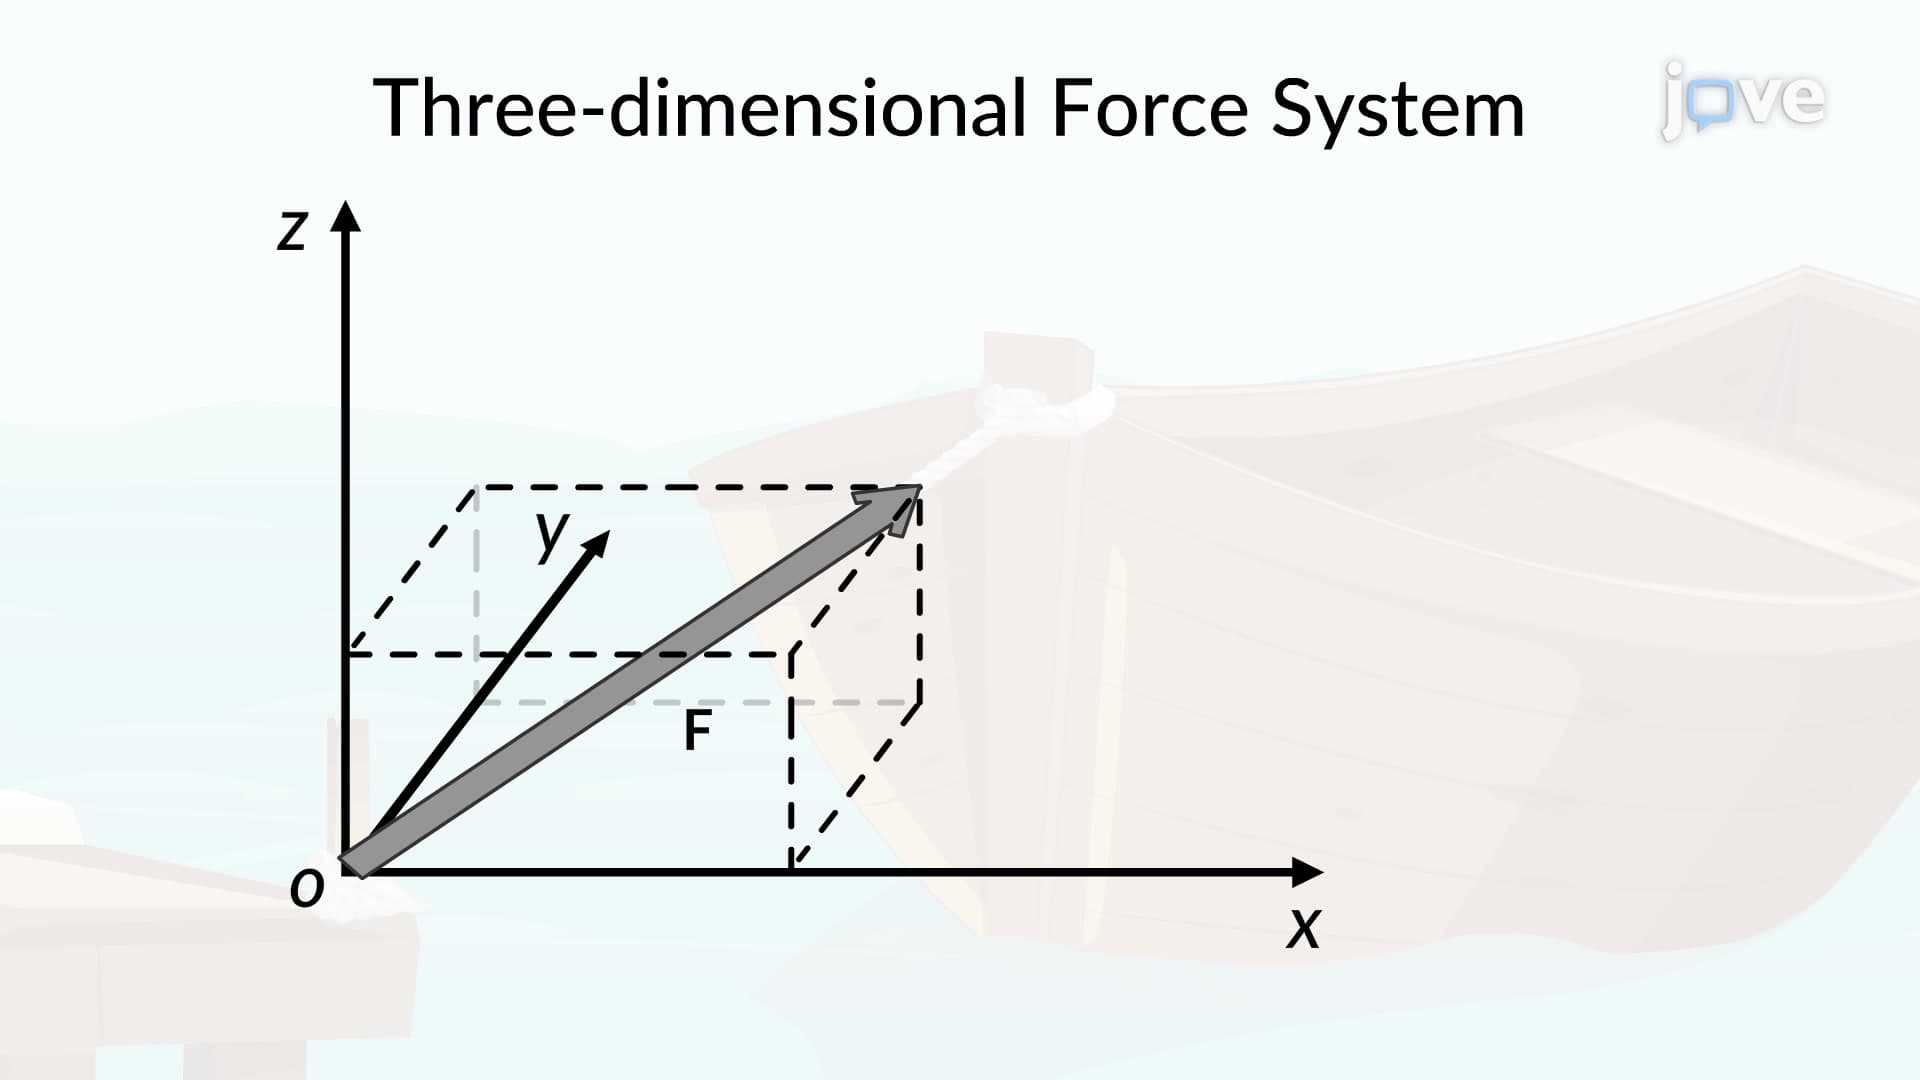 01:30
Three-Dimensional Force System
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
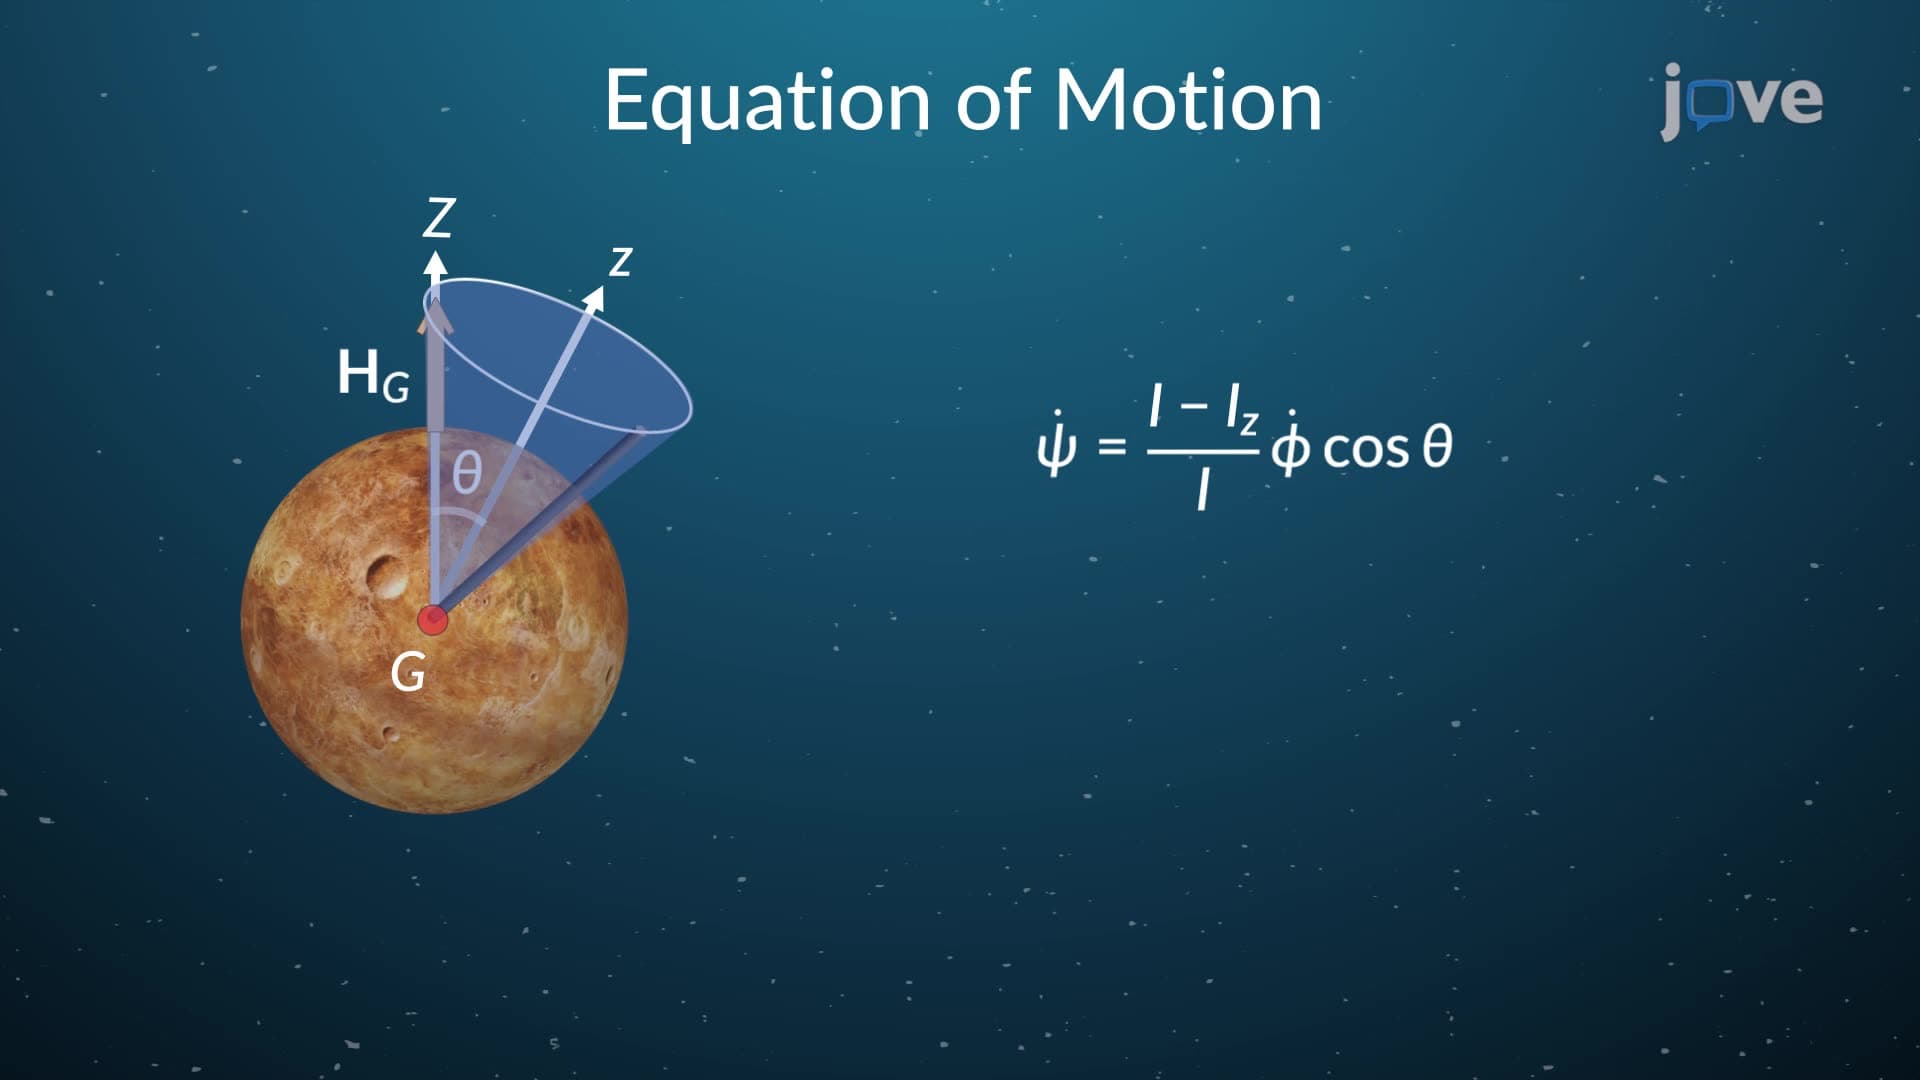 01:15
Torque Free Motion