

An Efficient Numerical Scheme for Solving a Fractional-Order System of Delay Differential Equations
1Department of Mathematics, National Defence Academy, Khadakwasala, Pune, 411023 India.

Abstract:
Fractional order systems of delay differential equations are very advantageous in analyzing the dynamics of various fields such as population dynamics, neural networking, ecology, and physiology. The aim of this paper is to present an implicit numerical scheme along with its error analysis to solve a fractional-order system of delay differential equations. The proposed method is an extension of the L1 numerical scheme and has the error estimate of , where h denotes the step size. Further, we solve various non-trivial examples using the proposed method and compare the results with those obtained by some other established methods such as the fractional Adams method and the three-term new predictor-corrector method. We observe that the proposed method is more accurate as compared to the fractional Adams method and the new predictor-corrector method. Moreover, it converges for very small values of the order of fractional derivative.
Related Concept Videos
 01:24
Difference Equation Solution using z-Transform
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
 01:18
Second Order systems II
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
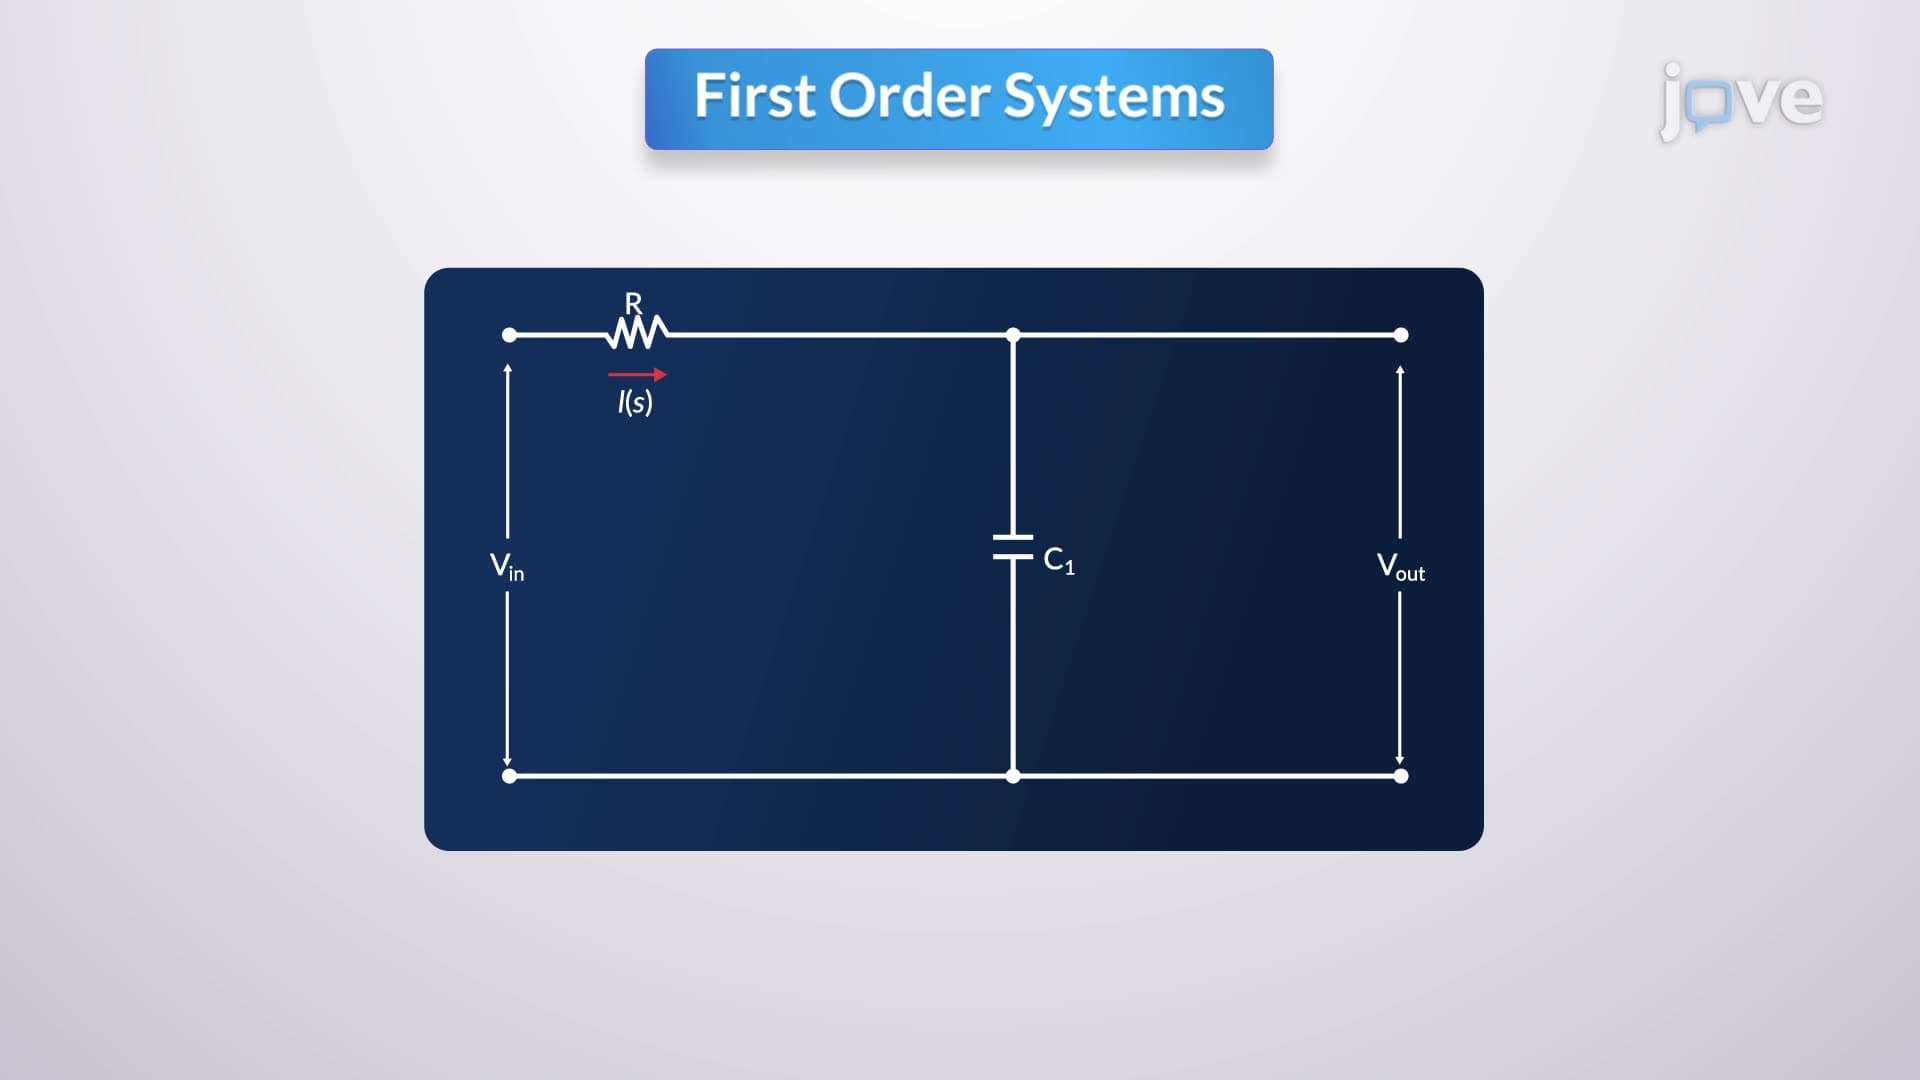
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...