Related Experiment Video
Updated: Aug 26, 2025

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Assessment of a three-axis on-rotor sensing performance for machining process monitoring: a case study
Chun Li1,2, Zhexiang Zou3,4, Kaibo Lu5
1School of Industrial Automation, Beijing Institute of Technology, Zhuhai, 519088, People's Republic of China.

Abstract:
Online monitoring of cutting conditions is essential in intelligent manufacturing, and vibrations are one of the most effective signals in monitoring machining conditions. Generally, traditional wired accelerometers should be installed on a motionless or stable platform, such as a tool holder or lathe bed, to sense vibrations. Such installation methods would cause the signals to suffer more serious noise interferences and a low signal-to-noise ratio, resulting in less sensitivity to valuable information. Therefore, this study developed a novel three-axis wireless on-rotor sensing (ORS) system for monitoring the turning process. The Micro Electromechanical System (MEMS) accelerometer sensor node can be mounted on a rotating workpiece or spindle rotor and is more sensitive in detecting the vibrations of the entire rotor system without any modification of the lathe system and interference in the cutting procedure. The processor, data acquisition, and Bluetooth Low Energy (BLE) 5.0+ modules were developed and debugged to cooperate with a piezoelectric triaxial accelerometer, with a vibration amplitude not larger than ± 16 g. A series of turning tests were conducted and the results were compared with those from the commercial wired accelerometers, which proved that the ORS system can measure the vibration signal of the rotor system more effectively and sensitively than wired accelerometers, thus demonstrating the accurate monitoring of machining parameters.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
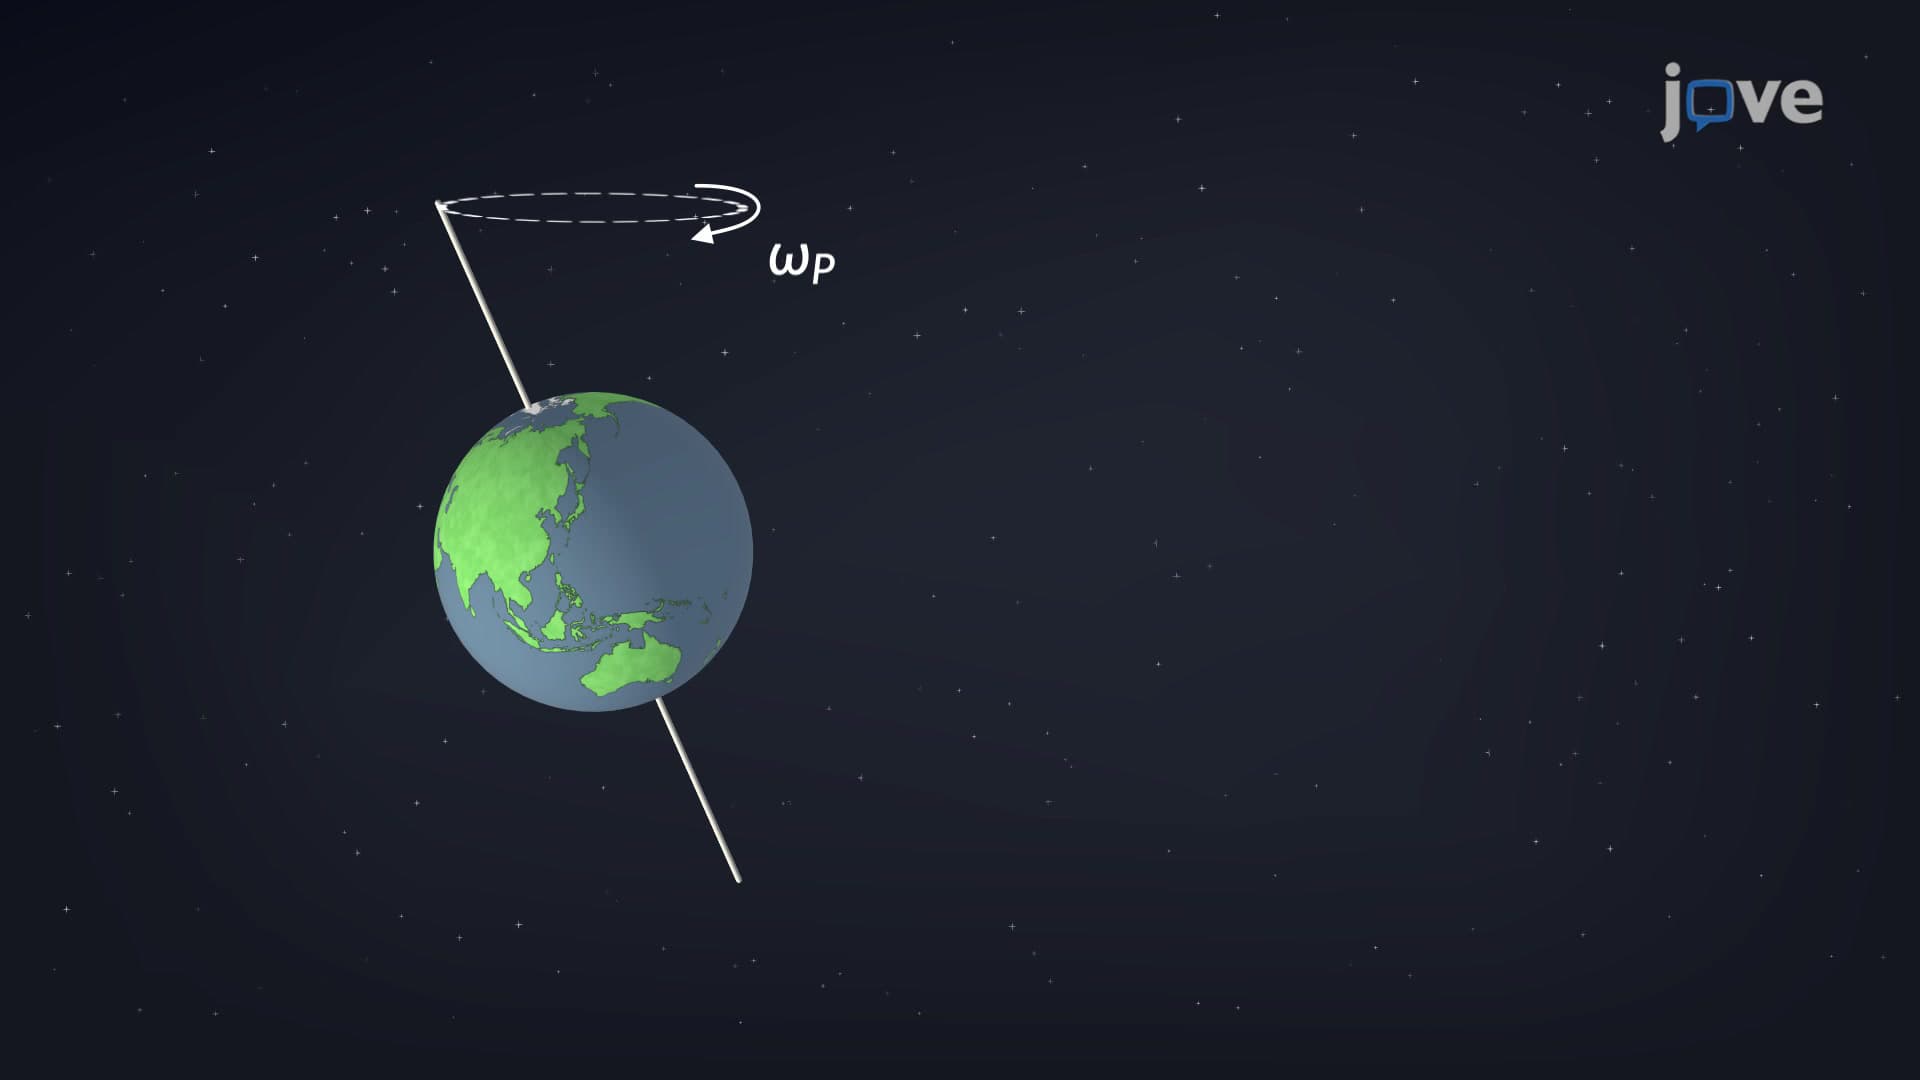
Gyroscope: Precession
 01:02
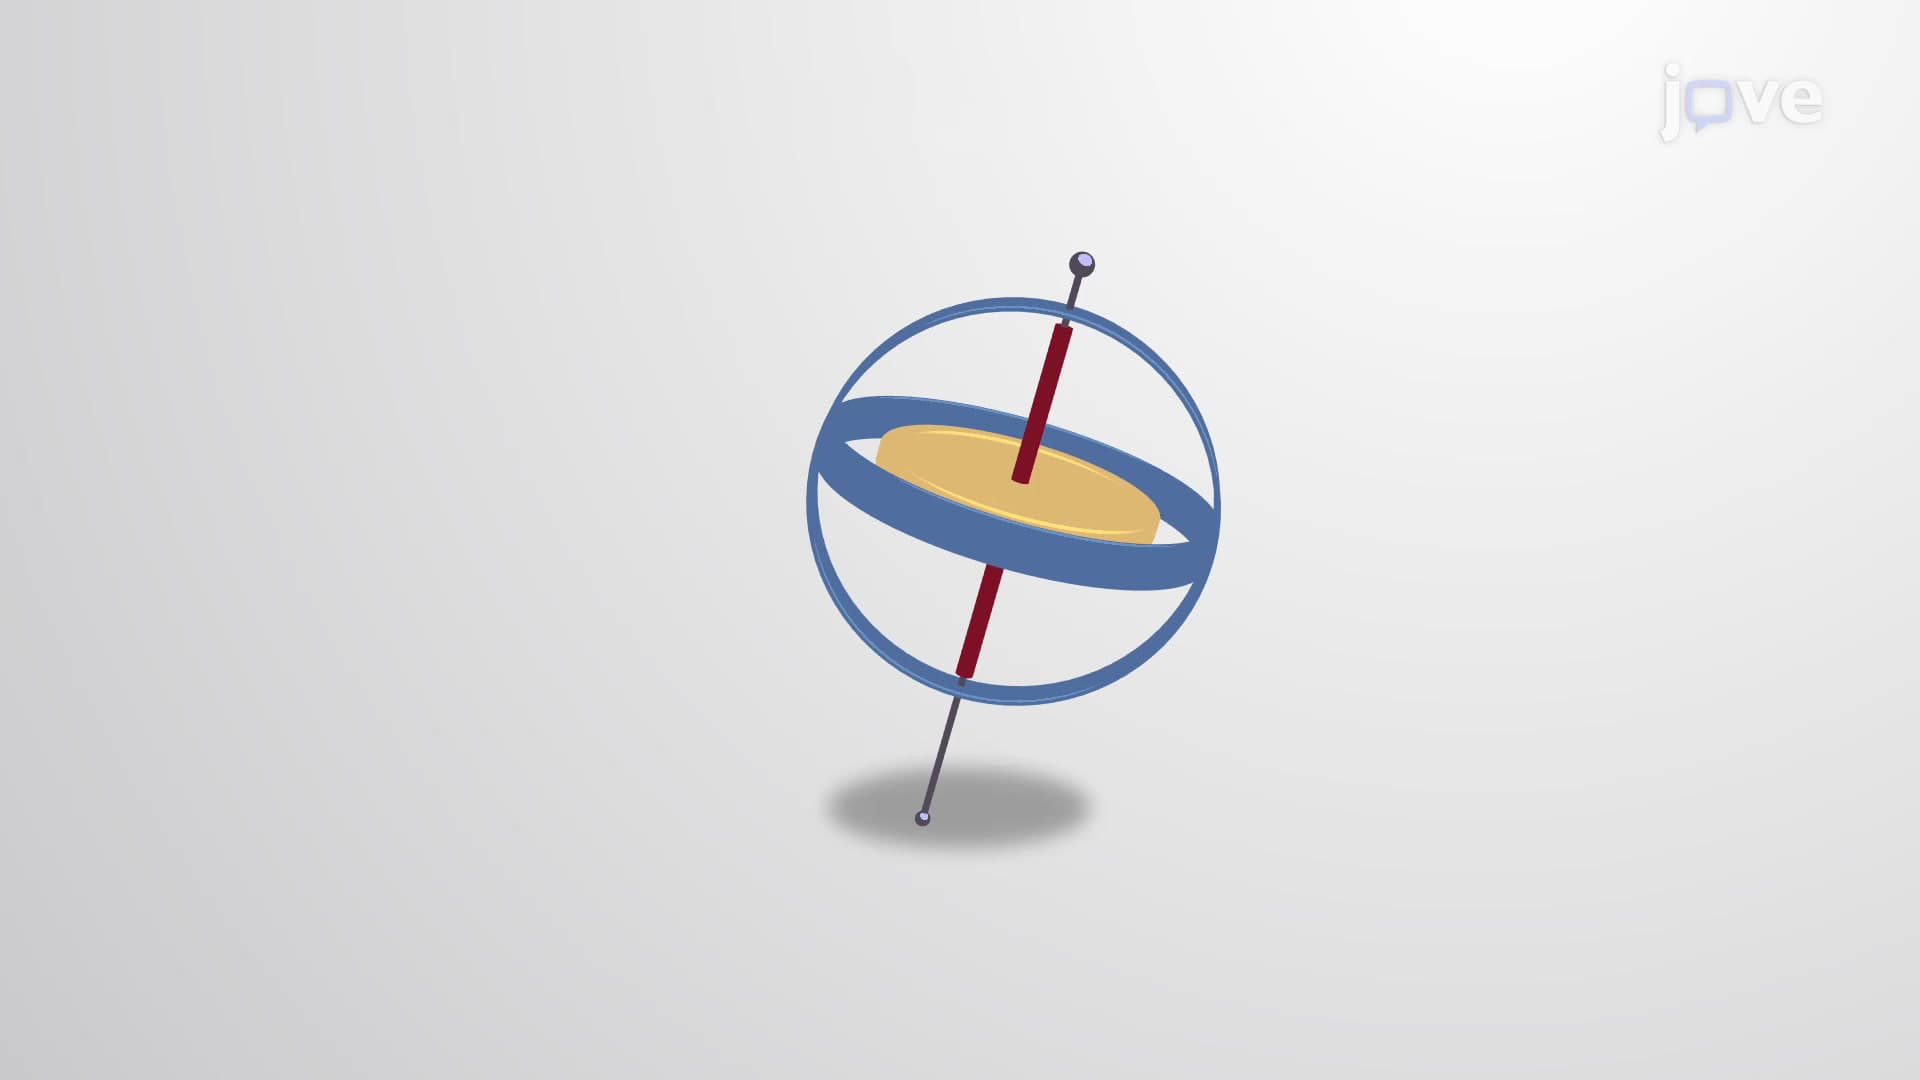
Gyroscope
 01:14
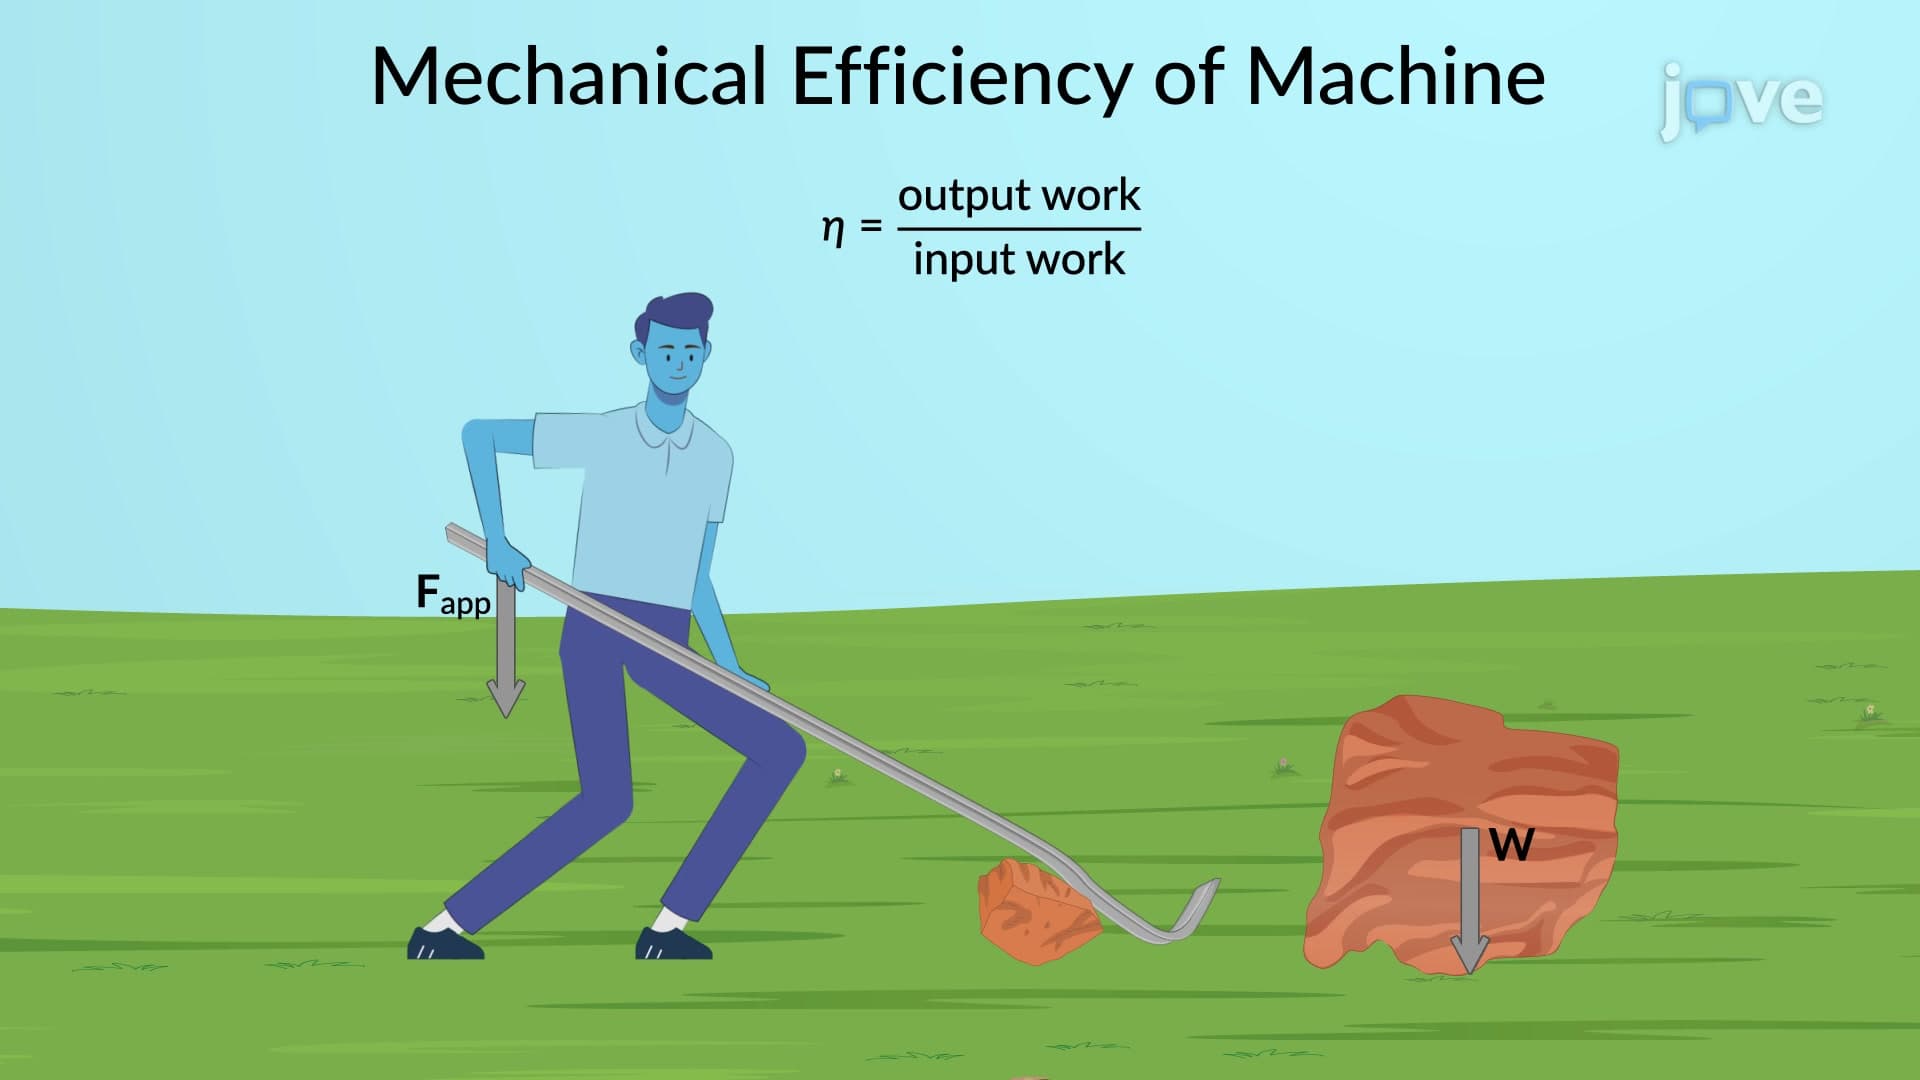
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...