Camera Motion Agnostic Method for Estimating 3D Human Poses
Related Experiment Video
Updated: Aug 23, 2025
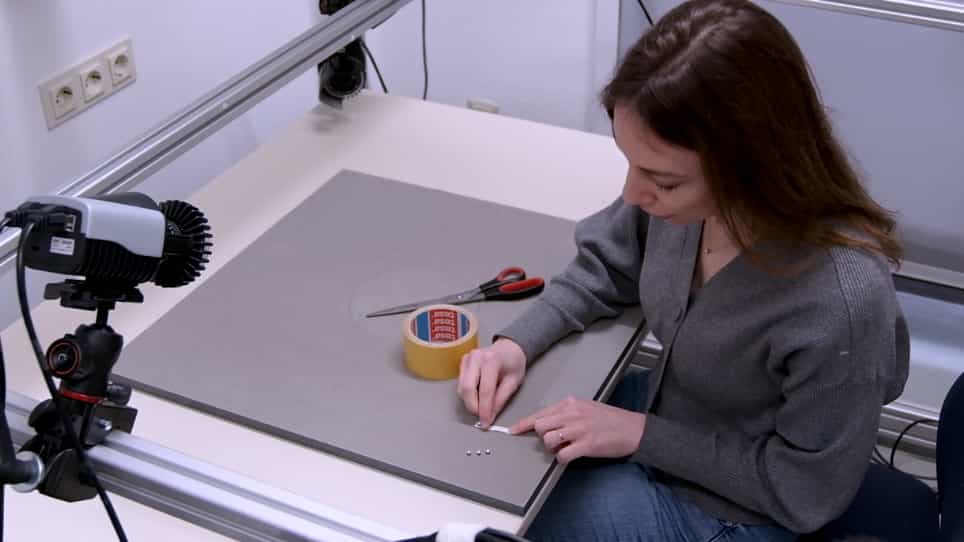
Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Seong Hyun Kim1, Sunwon Jeong2, Sungbum Park2
1Department of Electronics and Communications Engineering, Kwangwoon University, Seoul 01897, Korea.

Abstract:
Although the performance of 3D human pose and shape estimation methods has improved considerably in recent years, existing approaches typically generate 3D poses defined in a camera or human-centered coordinate system. This makes it difficult to estimate a person's pure pose and motion in a world coordinate system for a video captured using a moving camera. To address this issue, this paper presents a camera motion agnostic approach for predicting 3D human pose and mesh defined in the world coordinate system. The core idea of the proposed approach is to estimate the difference between two adjacent global poses (i.e., global motion) that is invariant to selecting the coordinate system, instead of the global pose coupled to the camera motion. To this end, we propose a network based on bidirectional gated recurrent units (GRUs) that predicts the global motion sequence from the local pose sequence consisting of relative rotations of joints called global motion regressor (GMR). We use 3DPW and synthetic datasets, which are constructed in a moving-camera environment, for evaluation. We conduct extensive experiments and prove the effectiveness of the proposed method empirically.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...