Related Experiment Video
Updated: Aug 22, 2025


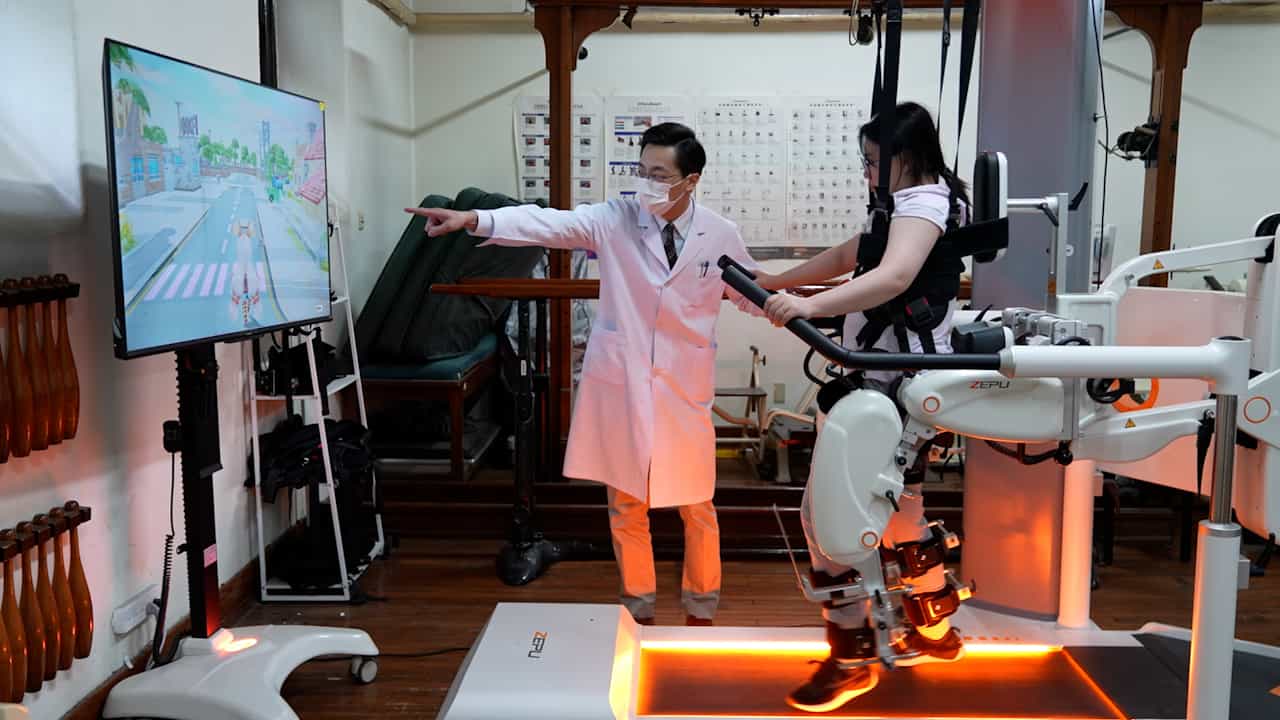
Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Modeling and Stiffness-based Continuous Torque Control of Lightweight Quasi-Direct-Drive Knee Exoskeletons for
Tzu-Hao Huang1, Sainan Zhang1, Shuangyue Yu1
1Lab of Biomechatronics and Intelligent Robotics (BIRO), Department of Mechanical and Aerospace Engineering, North Carolina State University, Raleigh, NC 27695, US.

Abstract:
State-of-the-art exoskeletons are typically limited by low control bandwidth and small range stiffness of actuators which are based on high gear ratios and elastic components (e.g., series elastic actuators). Furthermore, most exoskeletons are based on discrete gait phase detection and/or discrete stiffness control resulting in discontinuous torque profiles. To fill these two gaps, we developed a portable lightweight knee exoskeleton using quasi-direct drive (QDD) actuation that provides 14 Nm torque (36.8% biological joint moment for overground walking). This paper presents 1) stiffness modeling of torque-controlled QDD exoskeletons and 2) stiffness-based continuous torque controller that estimates knee joint moment in real-time. Experimental tests found the exoskeleton had high bandwidth of stiffness control (16 Hz under 100 Nm/rad) and high torque tracking accuracy with 0.34 Nm Root Mean Square (RMS) error (6.22%) across 0-350 Nm/rad large range stiffness. The continuous controller was able to estimate knee moments accurately and smoothly for three walking speeds and their transitions. Experimental results with 8 able-bodied subjects demonstrated that our exoskeleton was able to reduce the muscle activities of all 8 measured knee and ankle muscles by 8.60%-15.22% relative to unpowered condition, and two knee flexors and one ankle plantar flexor by 1.92%-10.24% relative to baseline (no exoskeleton) condition.

Related Concept Videos
 01:15
Torque Free Motion
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...