Related Experiment Video
Updated: Aug 22, 2025

Quantified Assessment of Infant's Gross Motor Abilities Using a Multisensor Wearable
Published on: May 17, 2024
Gait Trajectory Prediction on an Embedded Microcontroller Using Deep Learning
Mohamed Karakish1,2, Moustafa A Fouz1, Ahmed ELsawaf1
1Mechanical Engineering Department, College of Engineering and Technology, Cairo Campus, Arab Academy for Science, Technology and Maritime Transport (AASTMT), Cairo 11757, Egypt.

Abstract:
Achieving a normal gait trajectory for an amputee's active prosthesis is challenging due to its kinematic complexity. Accordingly, lower limb gait trajectory kinematics and gait phase segmentation are essential parameters in controlling an active prosthesis. Recently, the most practiced algorithm in gait trajectory generation is the neural network. Deploying such a complex Artificial Neural Network (ANN) algorithm on an embedded system requires performing the calculations on an external computational device; however, this approach lacks mobility and reliability. In this paper, more simple and reliable ANNs are investigated to be deployed on a single low-cost Microcontroller (MC) and hence provide system mobility. Two neural network configurations were studied: Multi-Layered Perceptron (MLP) and Convolutional Neural Network (CNN); the models were trained on shank and foot IMU data. The data were collected from four subjects and tested on a fifth to predict the trajectory of 200 ms ahead. The prediction was made for two cases: with and without providing the current phase of the gait. Then, the models were deployed on a low-cost microcontroller (ESP32). It was found that with fewer data (excluding the current gait phase), CNN achieved a better correlation coefficient of 0.973 when compared to 0.945 for MLP; when including the current phase, both network configurations achieved better correlation coefficients of nearly 0.98. However, when comparing the execution time required for the prediction on the intended MC, MLP was much faster than CNN, with an execution time of 2.4 ms and 142 ms, respectively. In summary, it was found that when training data are scarce, CNN is more efficient within the acceptable execution time, while MLP achieves relative accuracy with low execution time with enough data.
Related Concept Videos
 01:11
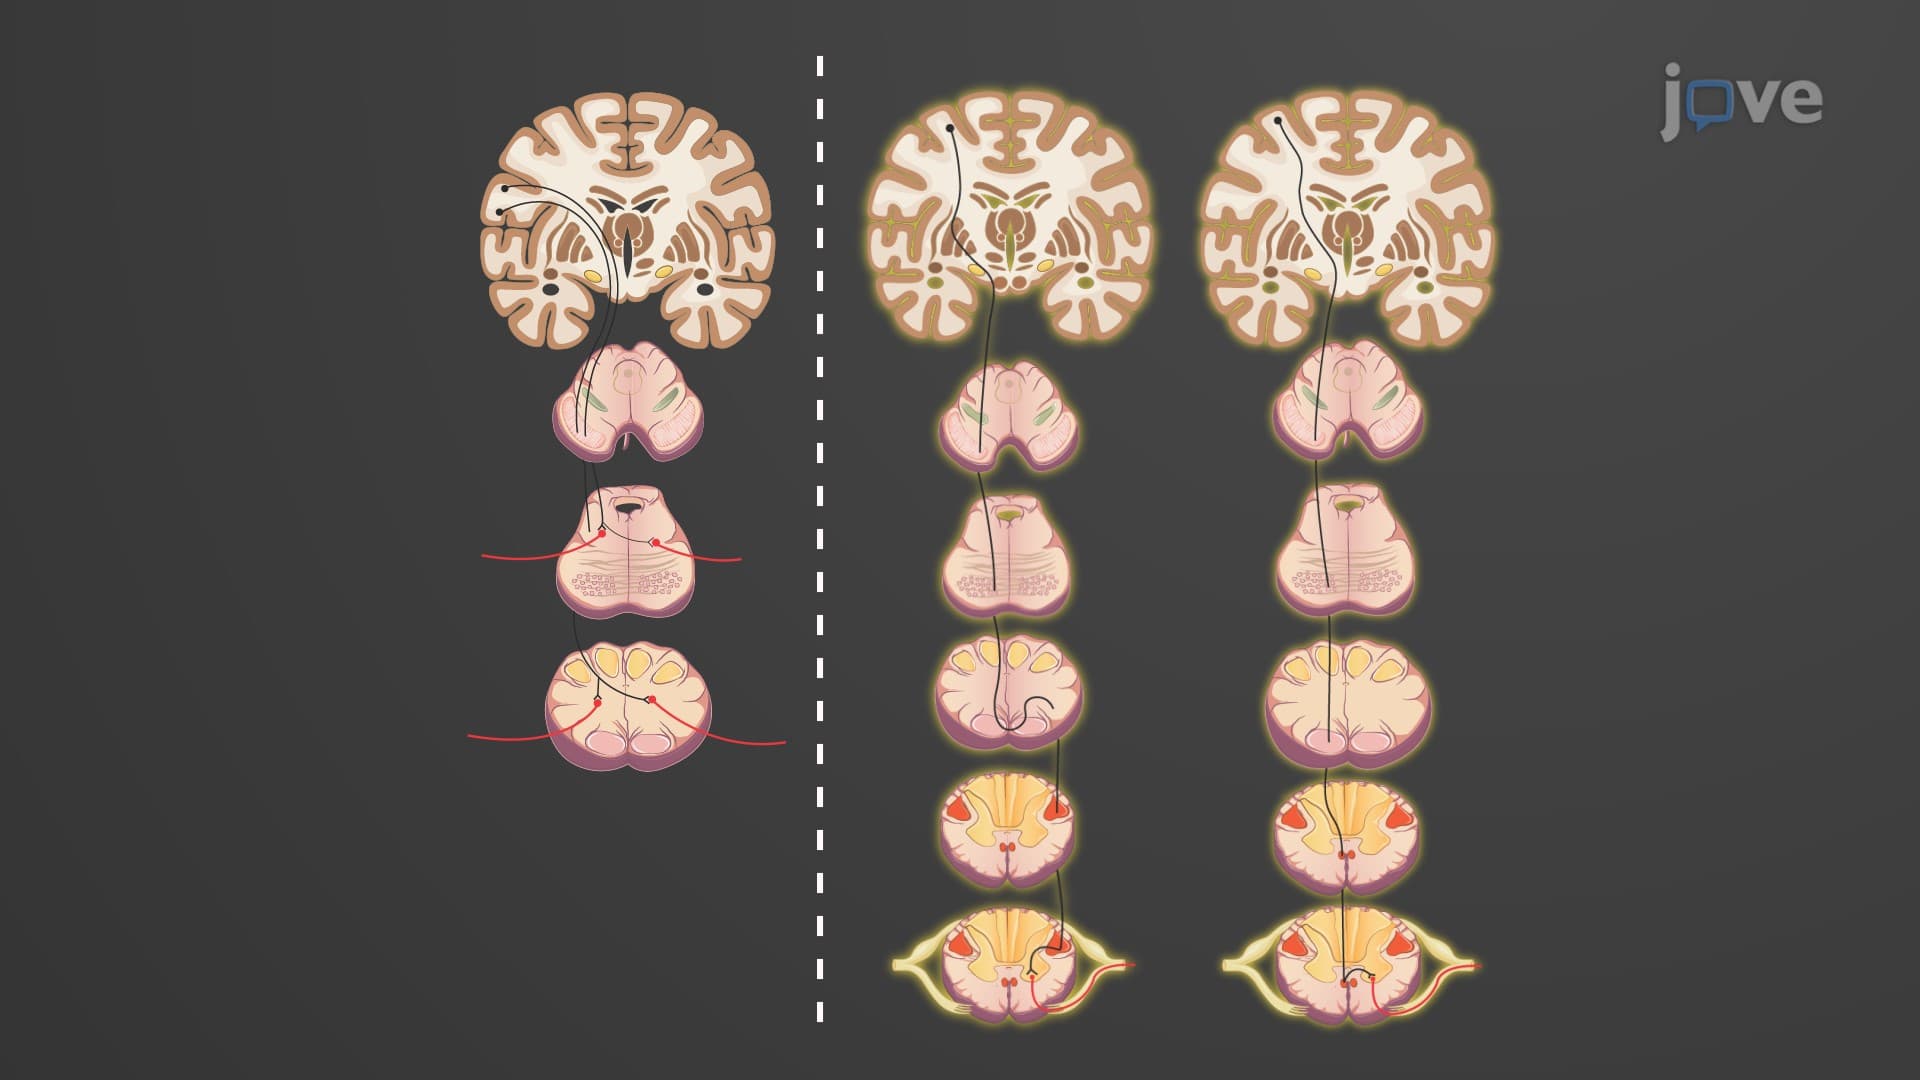
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:07
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...