Related Experiment Video
Updated: Aug 20, 2025
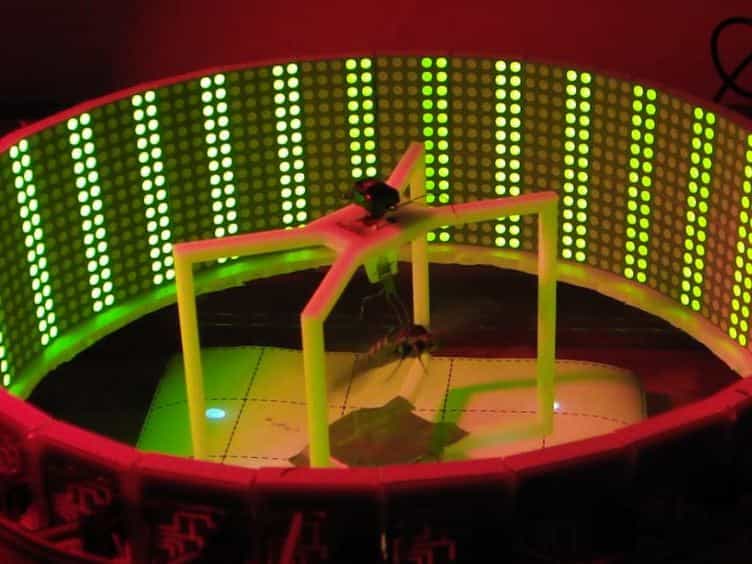

Early Metamorphic Insertion Technology for Insect Flight Behavior Monitoring
Published on: July 12, 2014
Derivative-Free Observability Analysis for Sensor Placement Optimization of Bioinspired Flexible Flapping Wing System
Bingyu Jin1, Hao Xu2, Jicheng Peng2
1College of Automation Engineering, Nanjing University of Aeronautics and Astronautics, Nanjing 210016, China.

Abstract:
Observability analysis of a bioinspired flexible flapping wing system provides a measure of how well the states of flexible flapping wing micro-aerial vehicles can be estimated from real-time measurements during high-speed flight. However, the traditional observability analysis approaches have trouble in terms of lack of quantitative analysis index, high computational complexity, low accuracy, and unavailability in stochastic systems with memory, including bioinspired flexible flapping wing systems. Therefore, a novel derivative-free observability analysis method is proposed here based on the generalized polynomial chaos expansion. By formulating a surrogate model to represent the relationship between the cumulative measurement and the random initial state, the observability coefficient matrix is calculated and the observability rank condition is stated. Consequently, several observability indices are proposed to quantity the observability of the system. Altogether, the proposed method avoids the disadvantages of the traditional approaches, especially in assessing the observability degree of each state and the effect of stochastic noise on observability. The validation of the proposed method is first provided by demonstrating the equivalence between the traditional and proposed methods and subsequently by comparing the observability of the Lorenz system calculated via three different approaches. Finally, the proposed method is applied on a bioinspired flexible wing system to optimize the placement of sensors, which is consistent with the natural configuration of campaniform sensilla on the wing of the hawkmoth.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
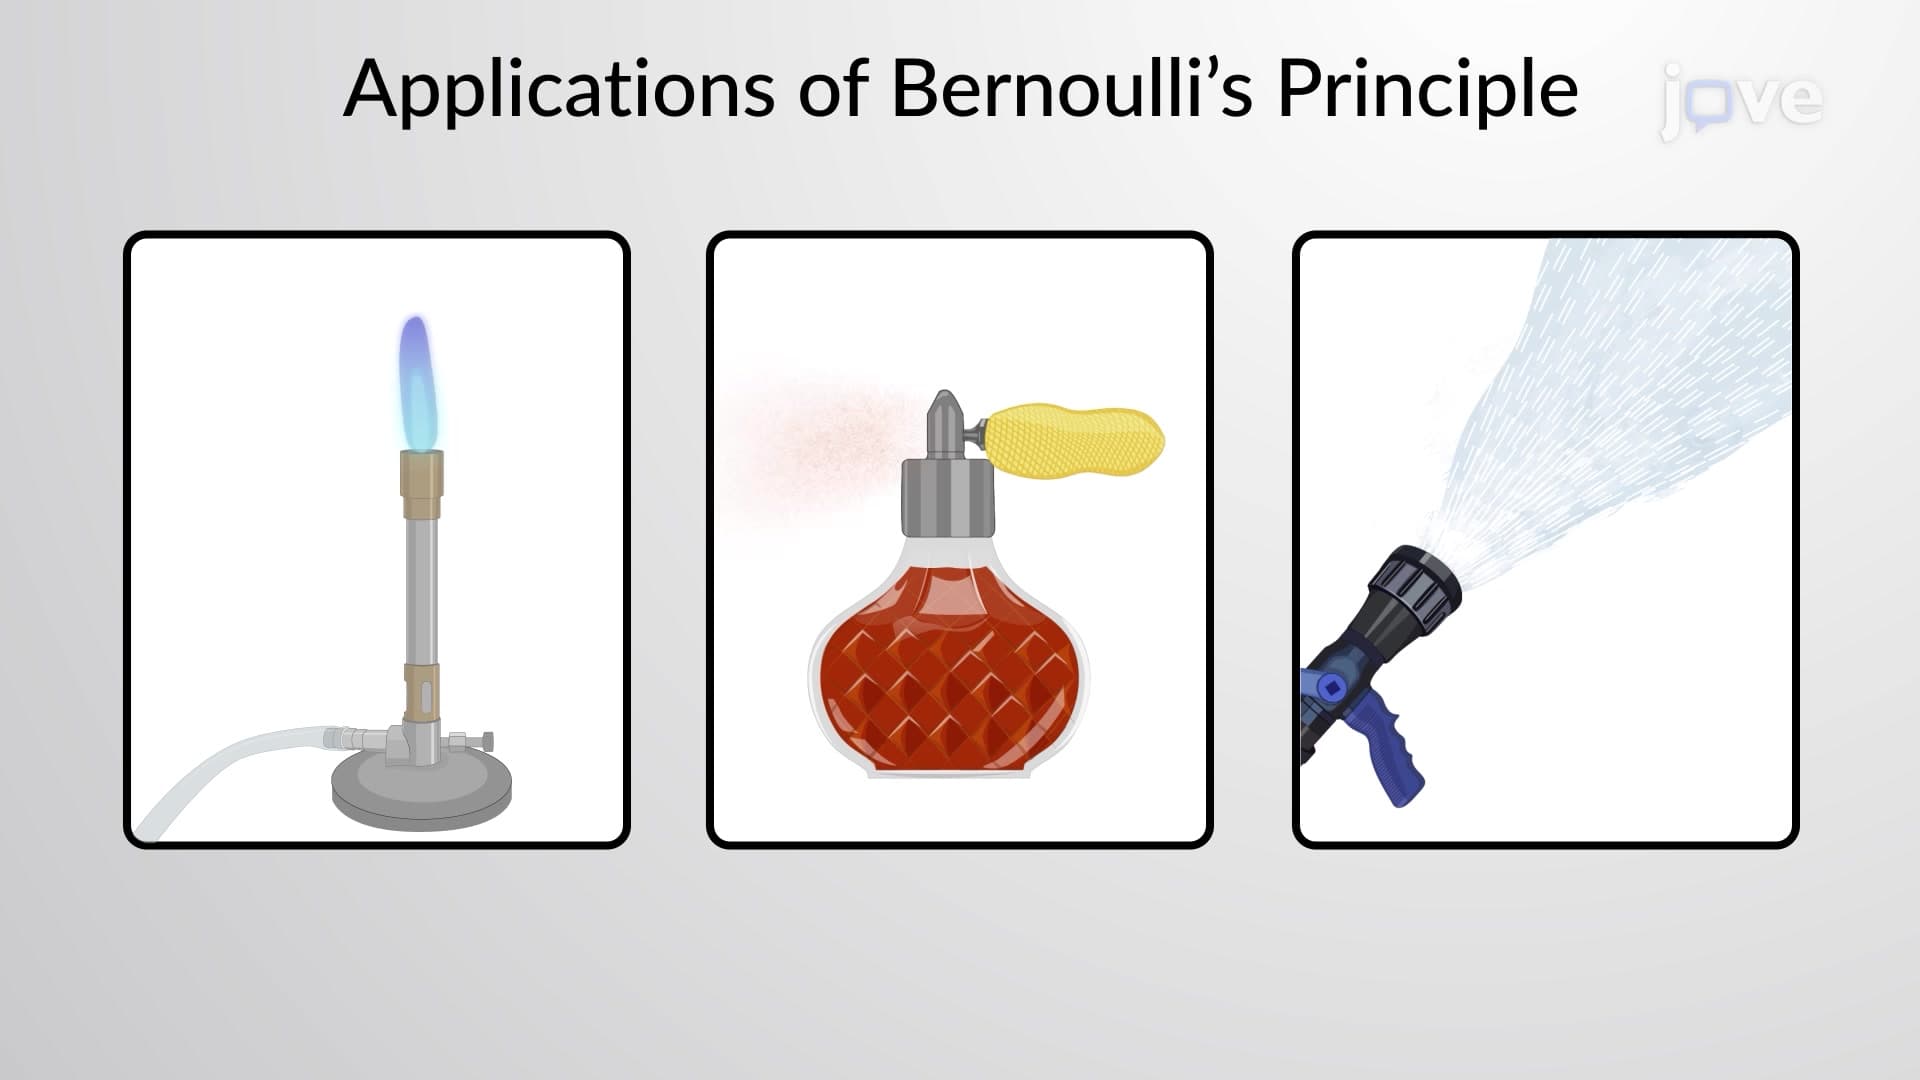
Bernoulli's Principle: Applications
Entrainment devices use a high fluid speed to create low pressures and, thus, entrain one fluid into another. Some examples of these devices are given below:
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:12
Fluid Pressure over Curved Plate of Constant Width
 01:23
Lift