Related Experiment Video
Updated: Aug 20, 2025


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
Research on Vehicle Trajectory Deviation Characteristics on Freeways Using Natural Driving Trajectory Data
Zhenhua Dai1, Cunshu Pan1, Wenlei Xiong2
1College of Traffic & Transportation, Chongqing Jiaotong University, Chongqing 400074, China.

Abstract:
Lateral driving behavior analysis is the foundation of freeway cross-section design and the focus of road safety research. However, the factors that influence vehicle lateral driving behavior have not been clearly explained. The dataset of the natural driving trajectory of freeways is used in this study to analyze vehicle lateral driving behavior and trajectory characteristics. As vehicle trajectory characteristic indicators, parameters such as preferred trajectory deviation and standard deviation are extracted. The effects of lane position, speed, road safety facilities, and vehicle types on freeway trajectory behavior are investigated. The results show that lane width and lane position significantly impact vehicle trajectory distribution. As driving speed increases, the lateral distance between vehicles in the inner lane and the guardrail tends to increase. In contrast, vehicles in the outside lane will stay away from the road edge line, and vehicles in the middle lane will stay away from the right lane dividing line when the speed increases. Statistical analysis shows that the preferred trajectory distribution of the same vehicle type in different lane positions is significantly different among groups (Cohen's d > 0.7). In the same lane, the lateral position characteristics of the center of mass of different vehicle types are basically the same (Cohen's d < 0.35). This work aims to explain what variables cause trajectory deviation behaviors and how to design traffic safety facilities (guardrail and shoulder) and lane width to accommodate various vehicle types and design speeds.
Related Concept Videos
 01:27
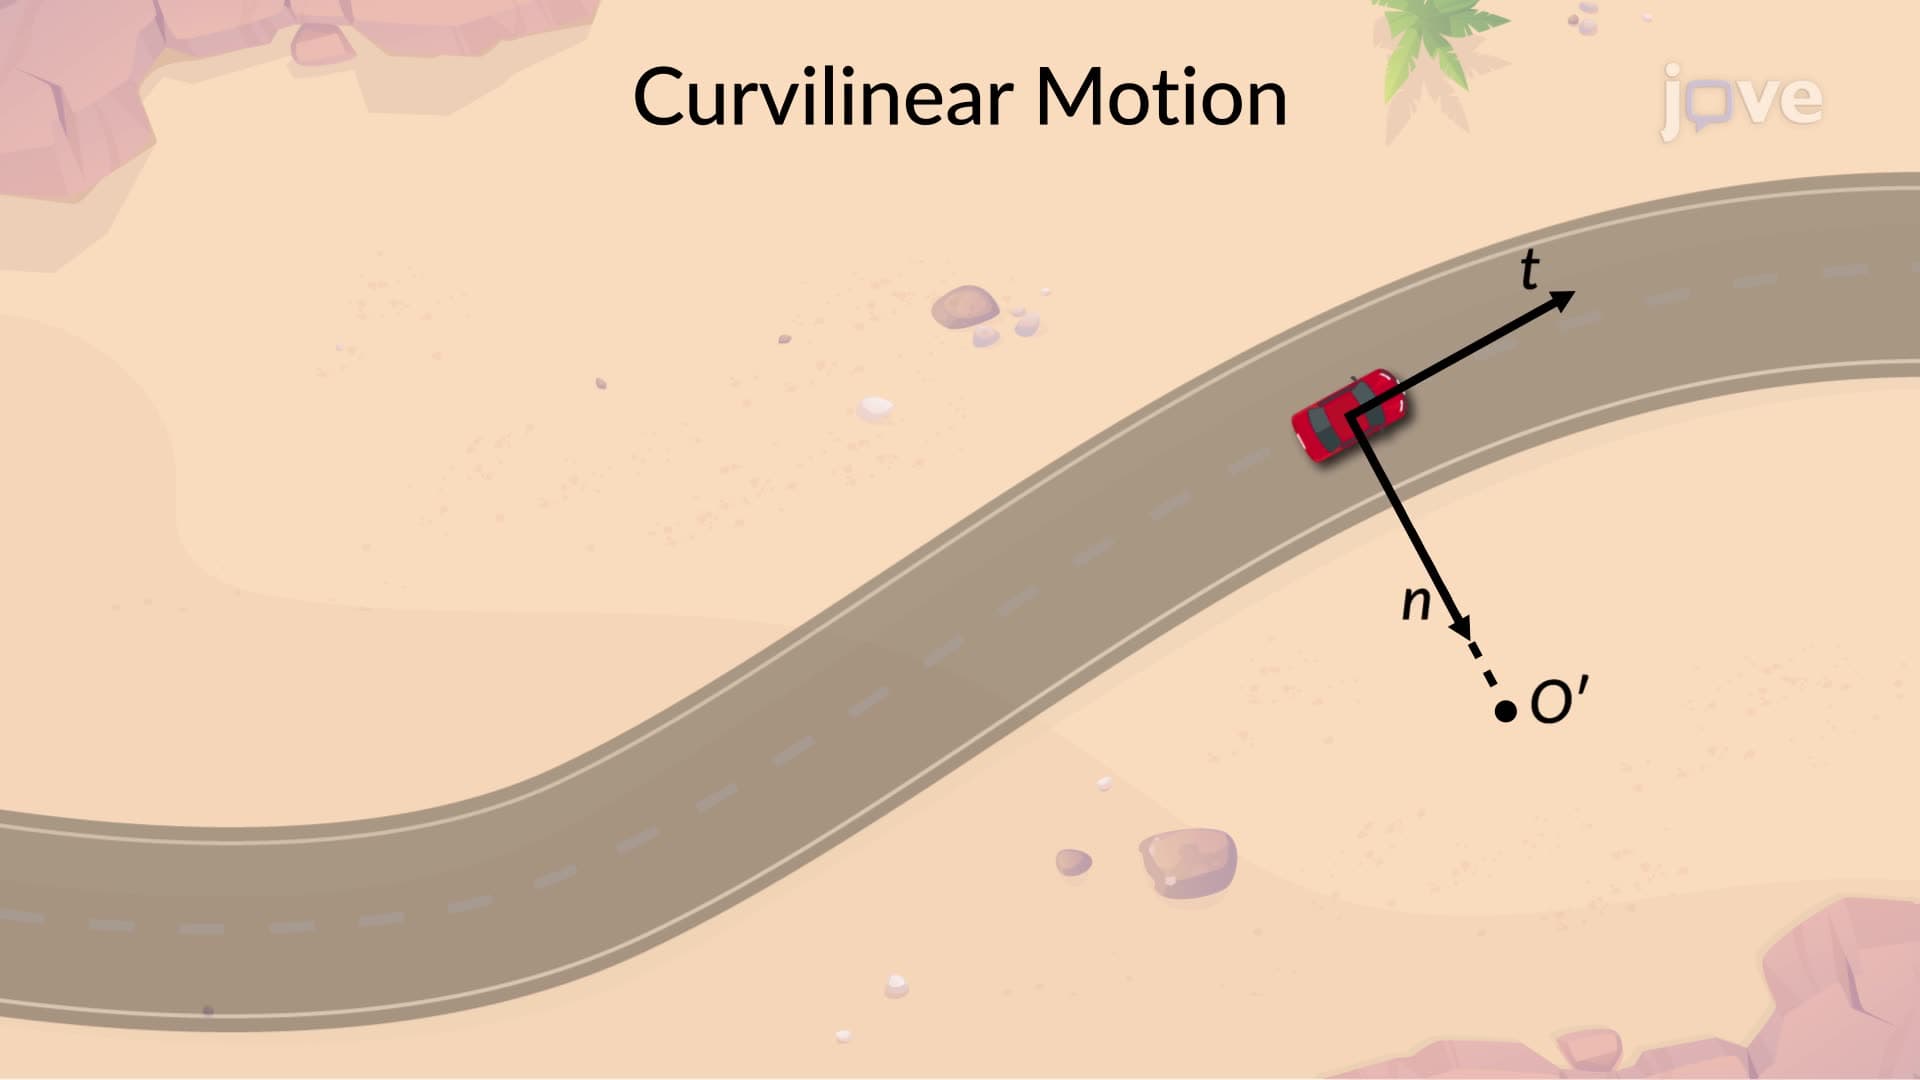
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:10
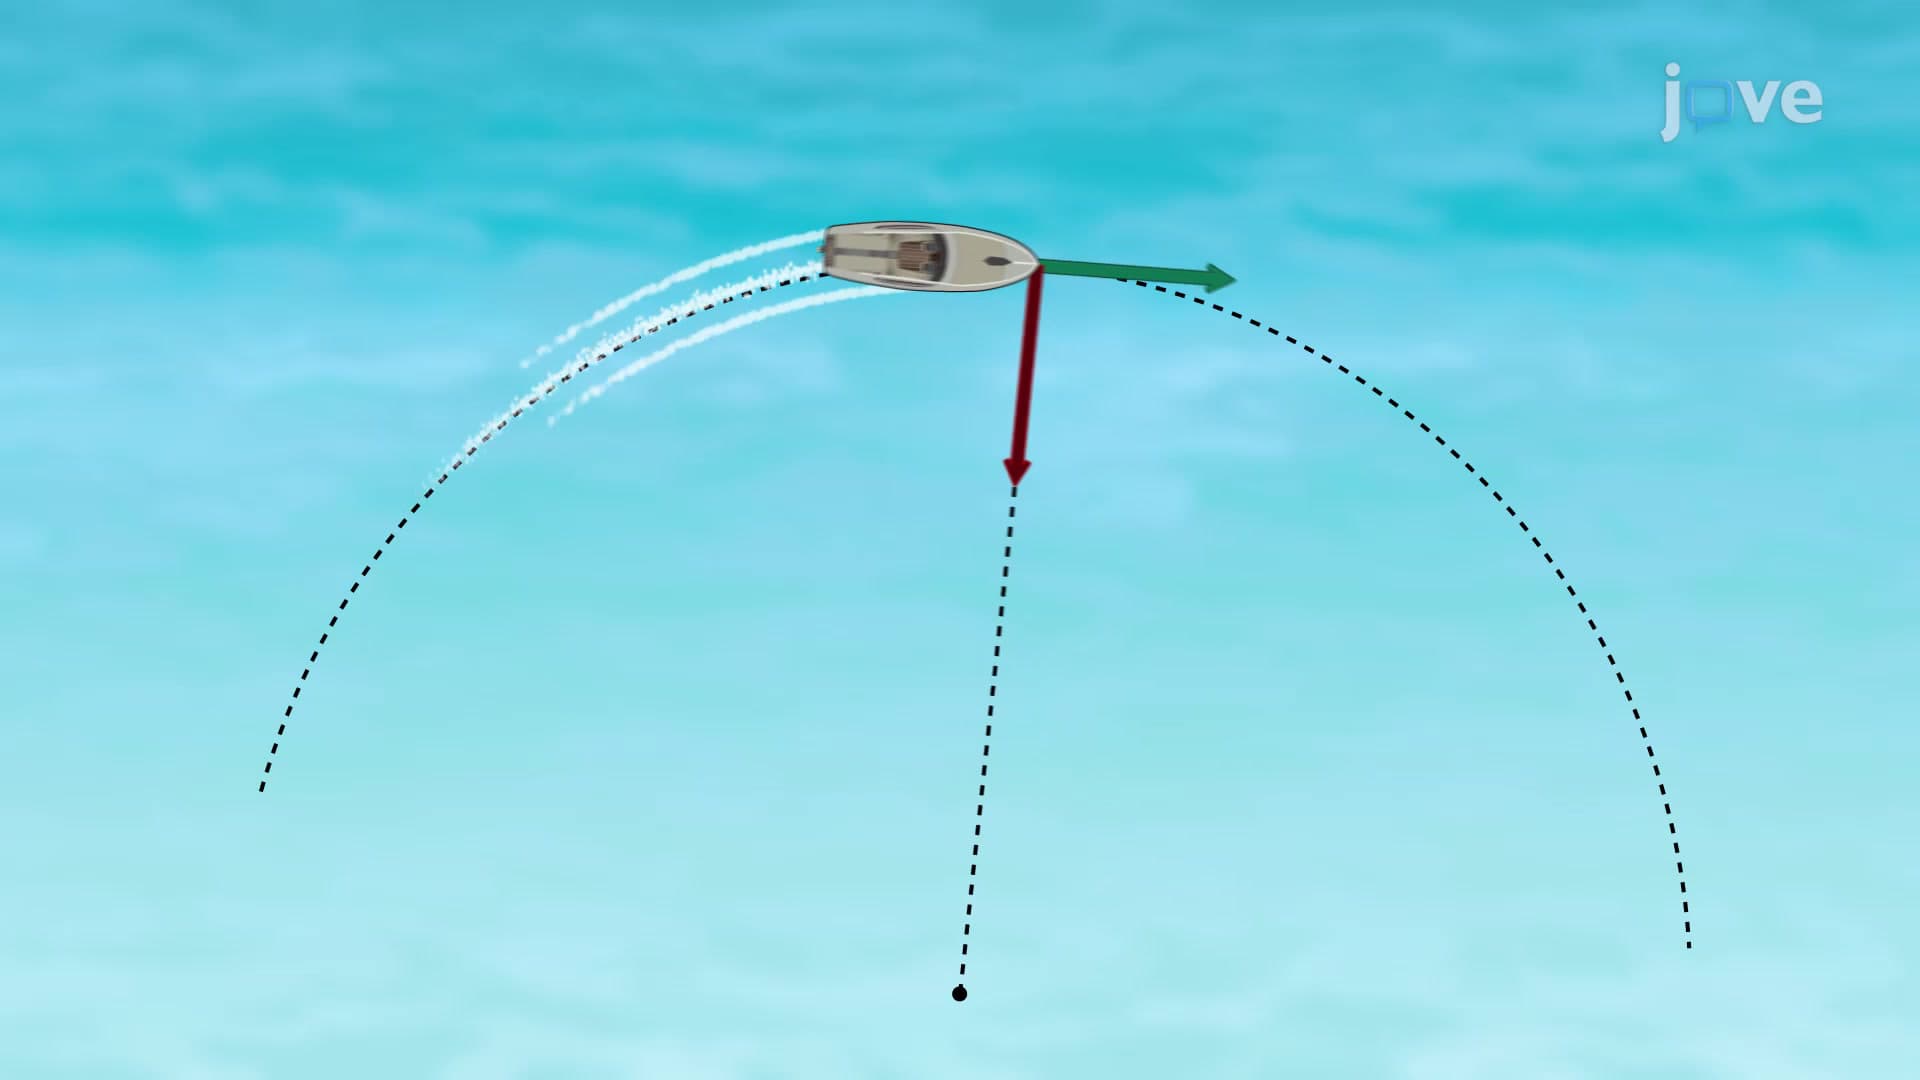
Direction of Acceleration Vectors