Related Experiment Video
Updated: Aug 19, 2025
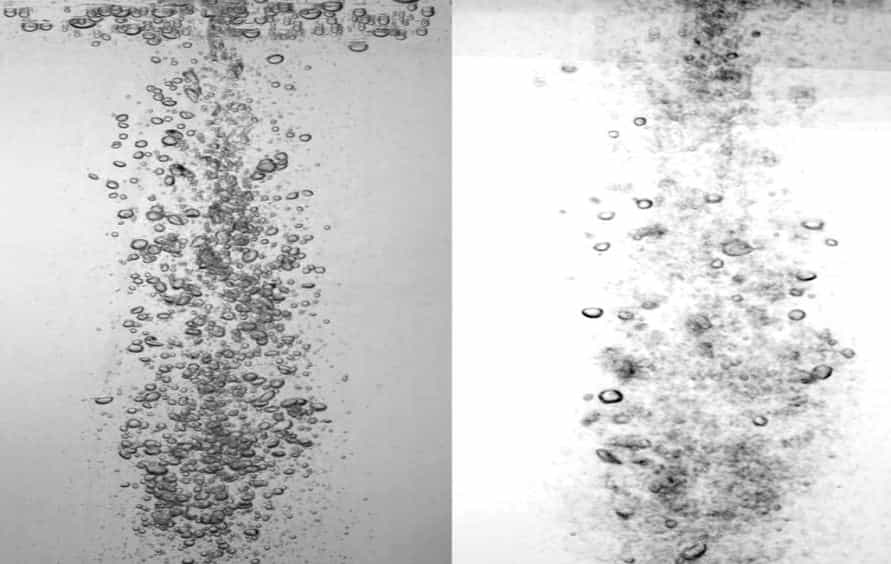

Determining 3D Flow Fields via Multi-camera Light Field Imaging
Published on: March 6, 2013
INV-Flow2PoseNet: Light-Resistant Rigid Object Pose from Optical Flow of RGB-D Images Using Images, Normals and
Torben Fetzer1, Gerd Reis2, Didier Stricker1,2
1Department of Computer Science, University of Kaiserslautern, 67663 Kaiserslautern, Germany.

Abstract:
This paper presents a novel architecture for simultaneous estimation of highly accurate optical flows and rigid scene transformations for difficult scenarios where the brightness assumption is violated by strong shading changes. In the case of rotating objects or moving light sources, such as those encountered for driving cars in the dark, the scene appearance often changes significantly from one view to the next. Unfortunately, standard methods for calculating optical flows or poses are based on the expectation that the appearance of features in the scene remains constant between views. These methods may fail frequently in the investigated cases. The presented method fuses texture and geometry information by combining image, vertex and normal data to compute an illumination-invariant optical flow. By using a coarse-to-fine strategy, globally anchored optical flows are learned, reducing the impact of erroneous shading-based pseudo-correspondences. Based on the learned optical flows, a second architecture is proposed that predicts robust rigid transformations from the warped vertex and normal maps. Particular attention is paid to situations with strong rotations, which often cause such shading changes. Therefore, a 3-step procedure is proposed that profitably exploits correlations between the normals and vertices. The method has been evaluated on a newly created dataset containing both synthetic and real data with strong rotations and shading effects. These data represent the typical use case in 3D reconstruction, where the object often rotates in large steps between the partial reconstructions. Additionally, we apply the method to the well-known Kitti Odometry dataset. Even if, due to fulfillment of the brightness assumption, this is not the typical use case of the method, the applicability to standard situations and the relation to other methods is therefore established.
More Related Videos
 06:25
Author Spotlight: Assessment of Visual Acuity in Central Vision Loss Through Motion-Based Peripheral Vision Testing
Published on: February 23, 2024
 08:25
Combining Eye-tracking Data with an Analysis of Video Content from Free-viewing a Video of a Walk in an Urban Park Environment
Published on: May 7, 2019
Related Concept Videos
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:27
Uniform Depth Channel Flow
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...