Related Experiment Video
Updated: Aug 19, 2025

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Event-Triggered Adaptive Neural Network Tracking Control for Uncertain Systems With Unknown Input Saturation Based on

Abstract:
This brief presents a modified event-triggered command filter backstepping tracking control scheme for a class of uncertain nonlinear systems with unknown input saturation based on the adaptive neural network (NN) technique. First, the virtual control functions are reconstructed to address the uncertainties in subsystems by using command filters. A piecewise continuous function is employed to deal with the unknown input saturation problem. Next, an event-triggered tracking controller is developed by utilizing the adaptive NN technique. Compared with standard NN control schemes based on multiple-function-approximators, our controller only requires a single NN. The closed-loop system stability is analyzed based on the Lyapunov stability theorem, and it is shown that the Zeno behavior is also avoided under the designed event-triggering mechanism. Simulation studies are performed to validate the effectiveness of our controller.
More Related Videos
 08:28
Automated Multimodal Stimulation and Simultaneous Neuronal Recording from Multiple Small Organisms
Published on: March 3, 2023
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:10
Control Systems
At the heart...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
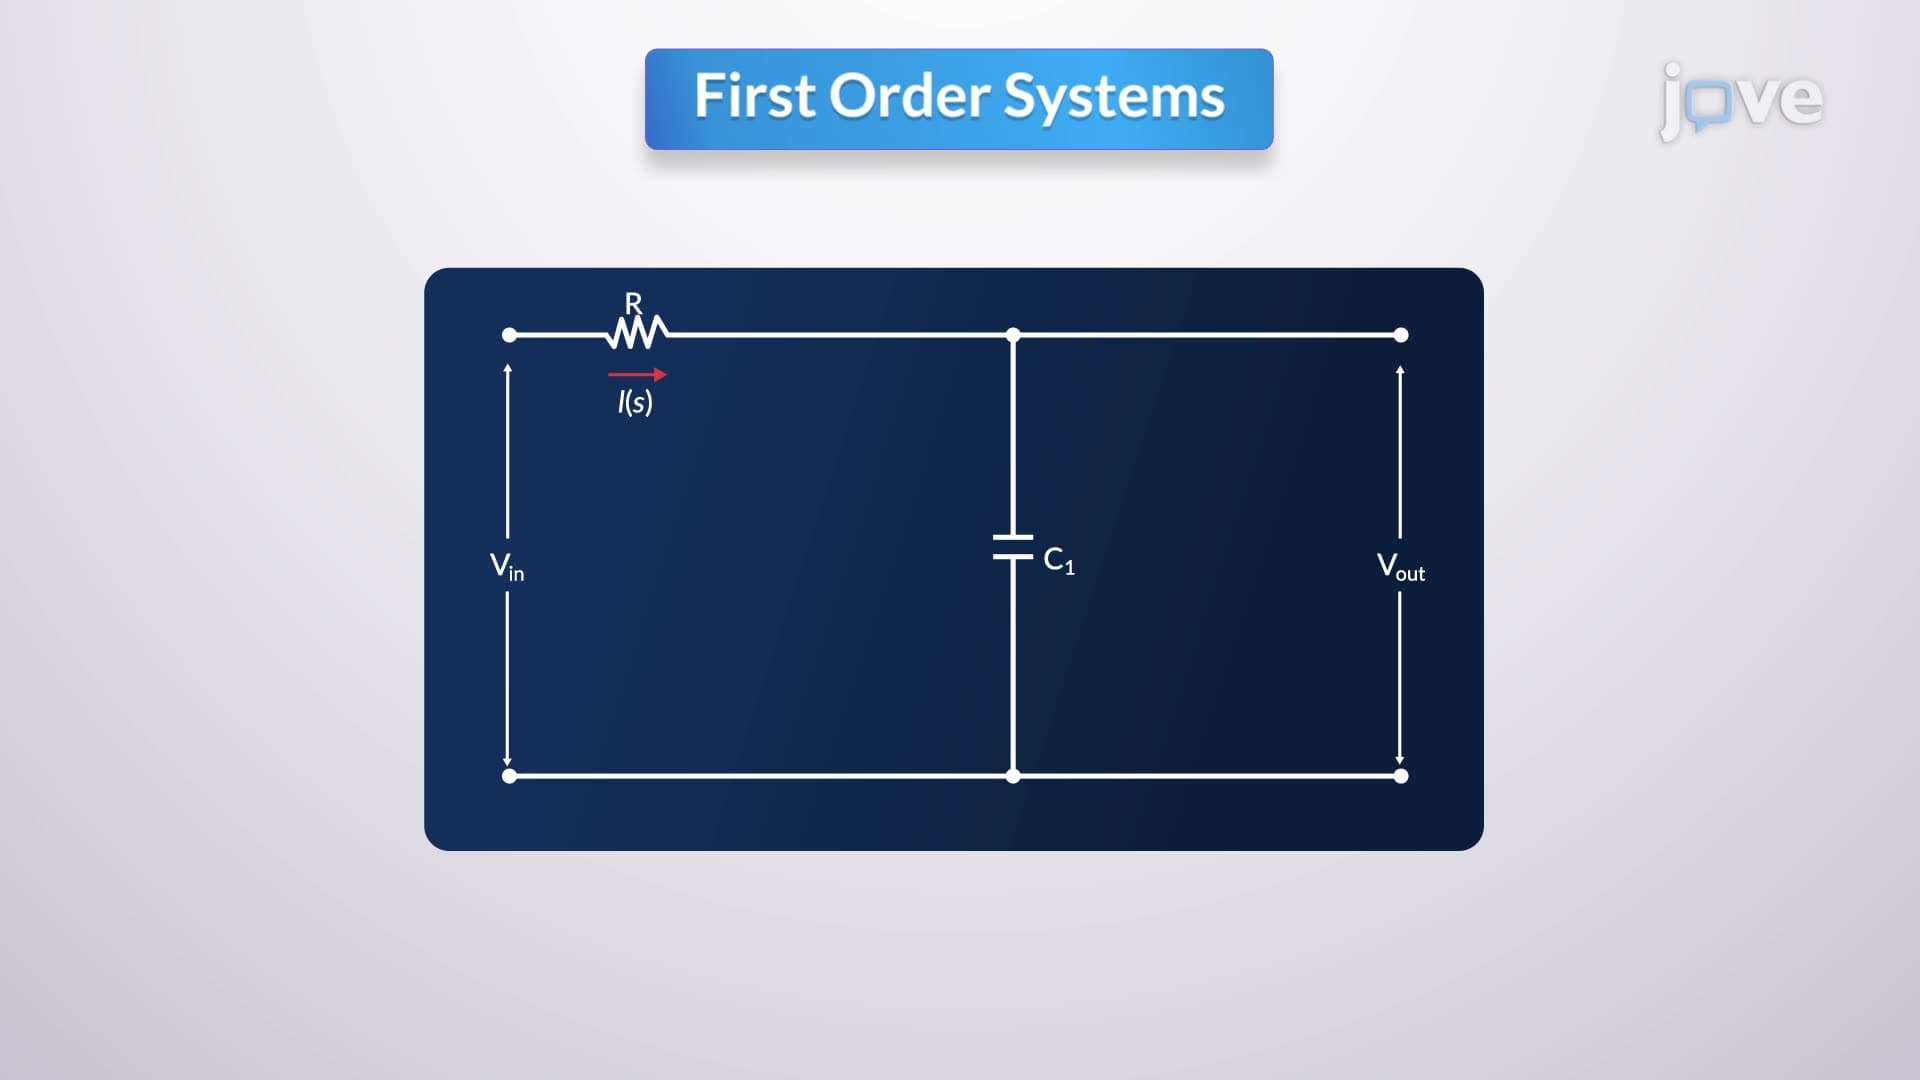
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
Transient and Steady-state Response
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state...