Model predictive and compensated ADRC for permanent magnet synchronous linear motors
Related Experiment Video
Updated: Aug 17, 2025

A Modeling and Simulation Method for Preliminary Design of an Electro-Variable Displacement Pump
Published on: June 1, 2022
Boyu Zhan1, Lanyu Zhang2, Yachao Liu1
1State Key Laboratory of Precision Electronic Manufacturing Technology and Equipment, Guangdong University of Technology, Guangzhou, 510006, China.

Abstract:
Traditional linear active disturbance rejection control (LADRC) may have difficulty to achieve a rapid precise disturbance rejection for a permanent magnet synchronous linear motor (PMSLM). By making use of model information, a model predictive and compensated LADRC (MPLADRC) method is proposed in this paper. In this method, a model compensated extended state observer (MESO) is designed to transform the controlled object into an established mathematical model through total disturbance compensation. Meanwhile, considering the delay problem of MESO, a phase advance module is designed to improve the estimation speed of MESO for system disturbance and state, thus the MESO can rapidly compensate various uncertainty disturbances to the controlled object in real time. The model predictive controller (MPC) is then designed based on the mathematical model, and its optimal control law is then obtained through a quadratic objective function to further suppress the disturbance unobserved by the designed MESO. The proposed method can thus realize a dual-degree-of-freedom disturbance rejection through the MESO and MPC. The simulation and experimental results validate the effectiveness of the proposed MPLADRC in rapid anti-disturbance and fast positioning for the motion control of the PMSLM.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 11:53
The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
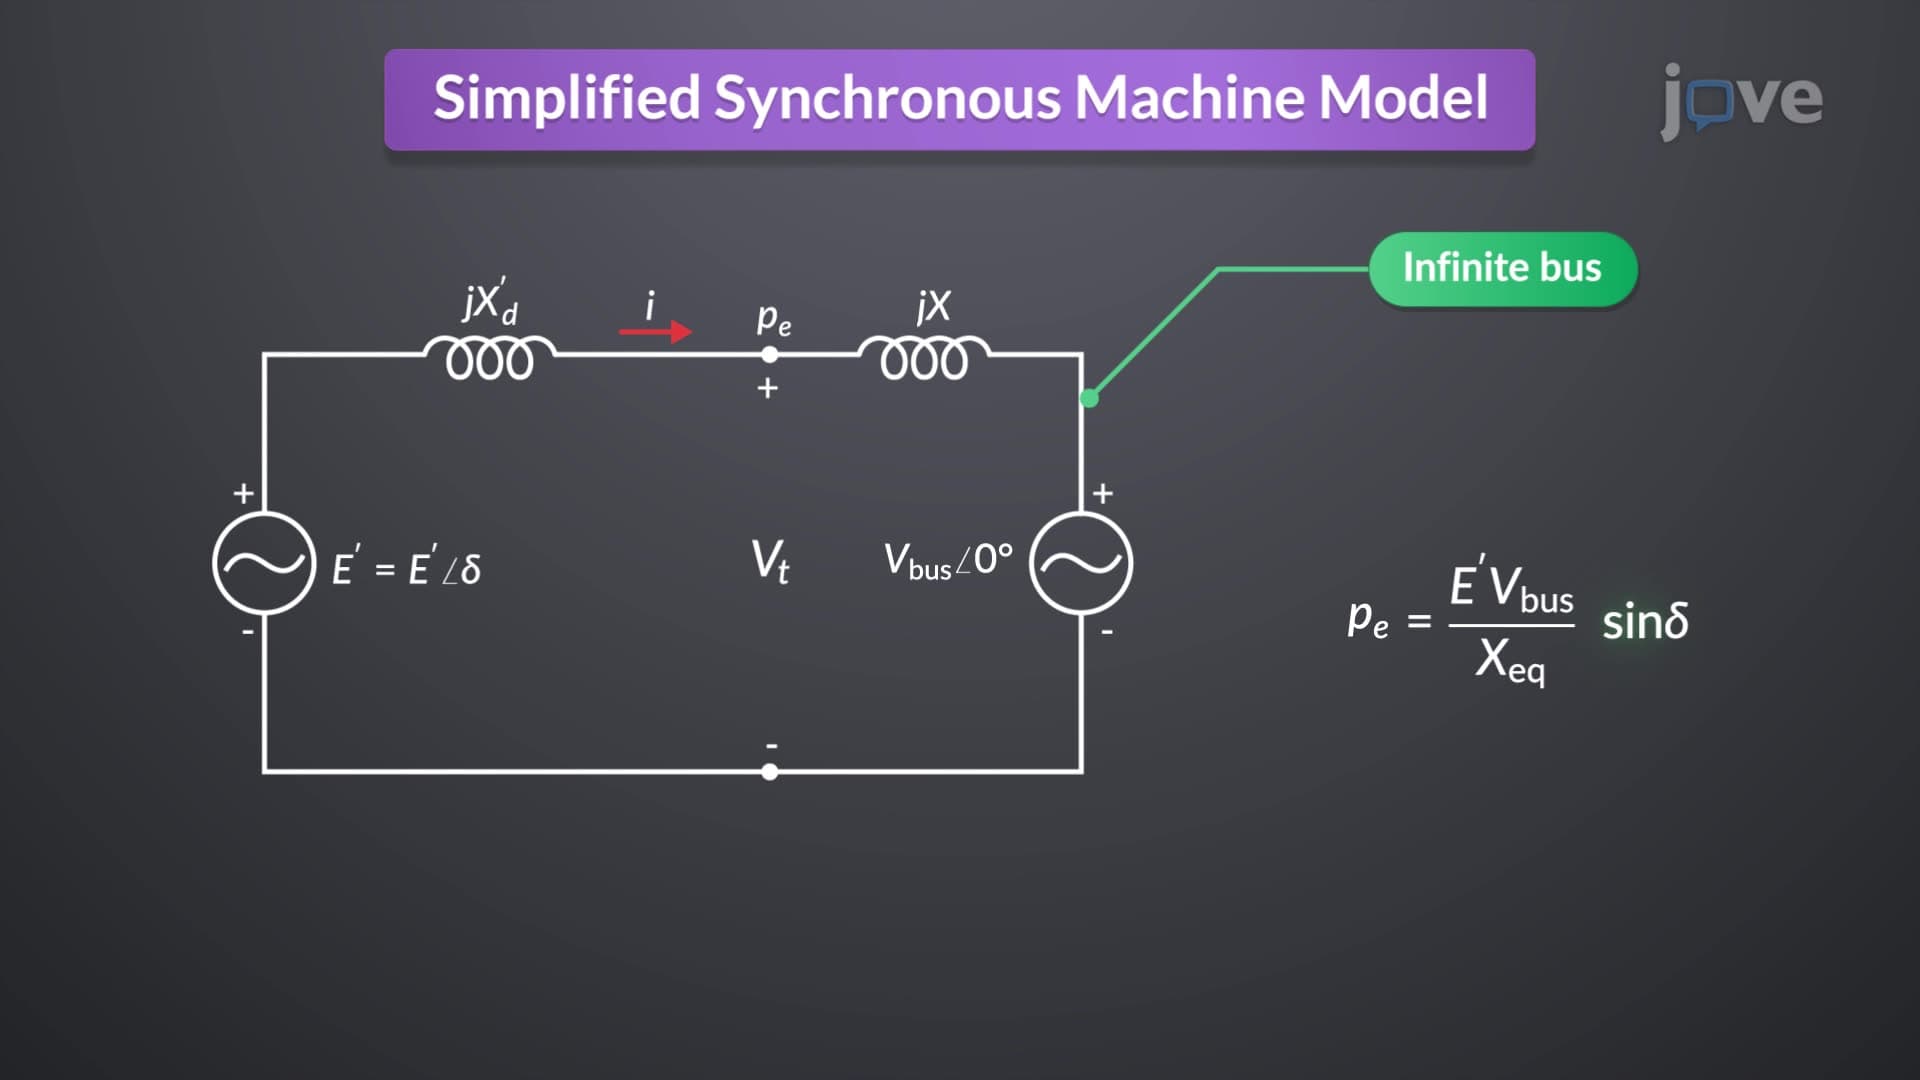 01:30
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:19
PID Controller
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by: