Related Experiment Video
Updated: Aug 17, 2025

Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Tracking approach of double pendulum cranes with variable rope lengths using sliding mode technique
Xinya Yao1, He Chen1, Yang Liu1
1School of Artificial Intelligence, Hebei University of Technology, Tianjin 300401, PR China; Control Engineering Technology Innovation Center of Hebei Province, Hebei University of Technology, Tianjin 300401, PR China.

Abstract:
Cranes are widely employed for transportation in many industrial fields. However, strong couplings and high nonlinearities increase difficulty of designing effective control methods for crane systems. Additionally, complex environments may bring uncertainties and unfavorable factors for the control problem. In this paper, we design an effective tracking approach for double pendulum cranes considering variable rope lengths problem by using sliding mode technique, to further improve the robustness and achieve the control objectives of accurate tracking, while effective suppression for double pendulum swing is also ensured. We design a proper sliding mode surface containing all state variables, which effectively suppresses swing angles of the payload and the hook. Then, the time delay estimator technique is used to estimate parameter uncertainty-related terms and the estimation errors are effectively tackled by using sliding mode technique. The effectiveness is rigorously proved by Lyapunov stability theory. At last, comprehensive simulations are implemented to show the proper performance.

Related Concept Videos
 01:24
Frames: Problem Solving I
 01:09
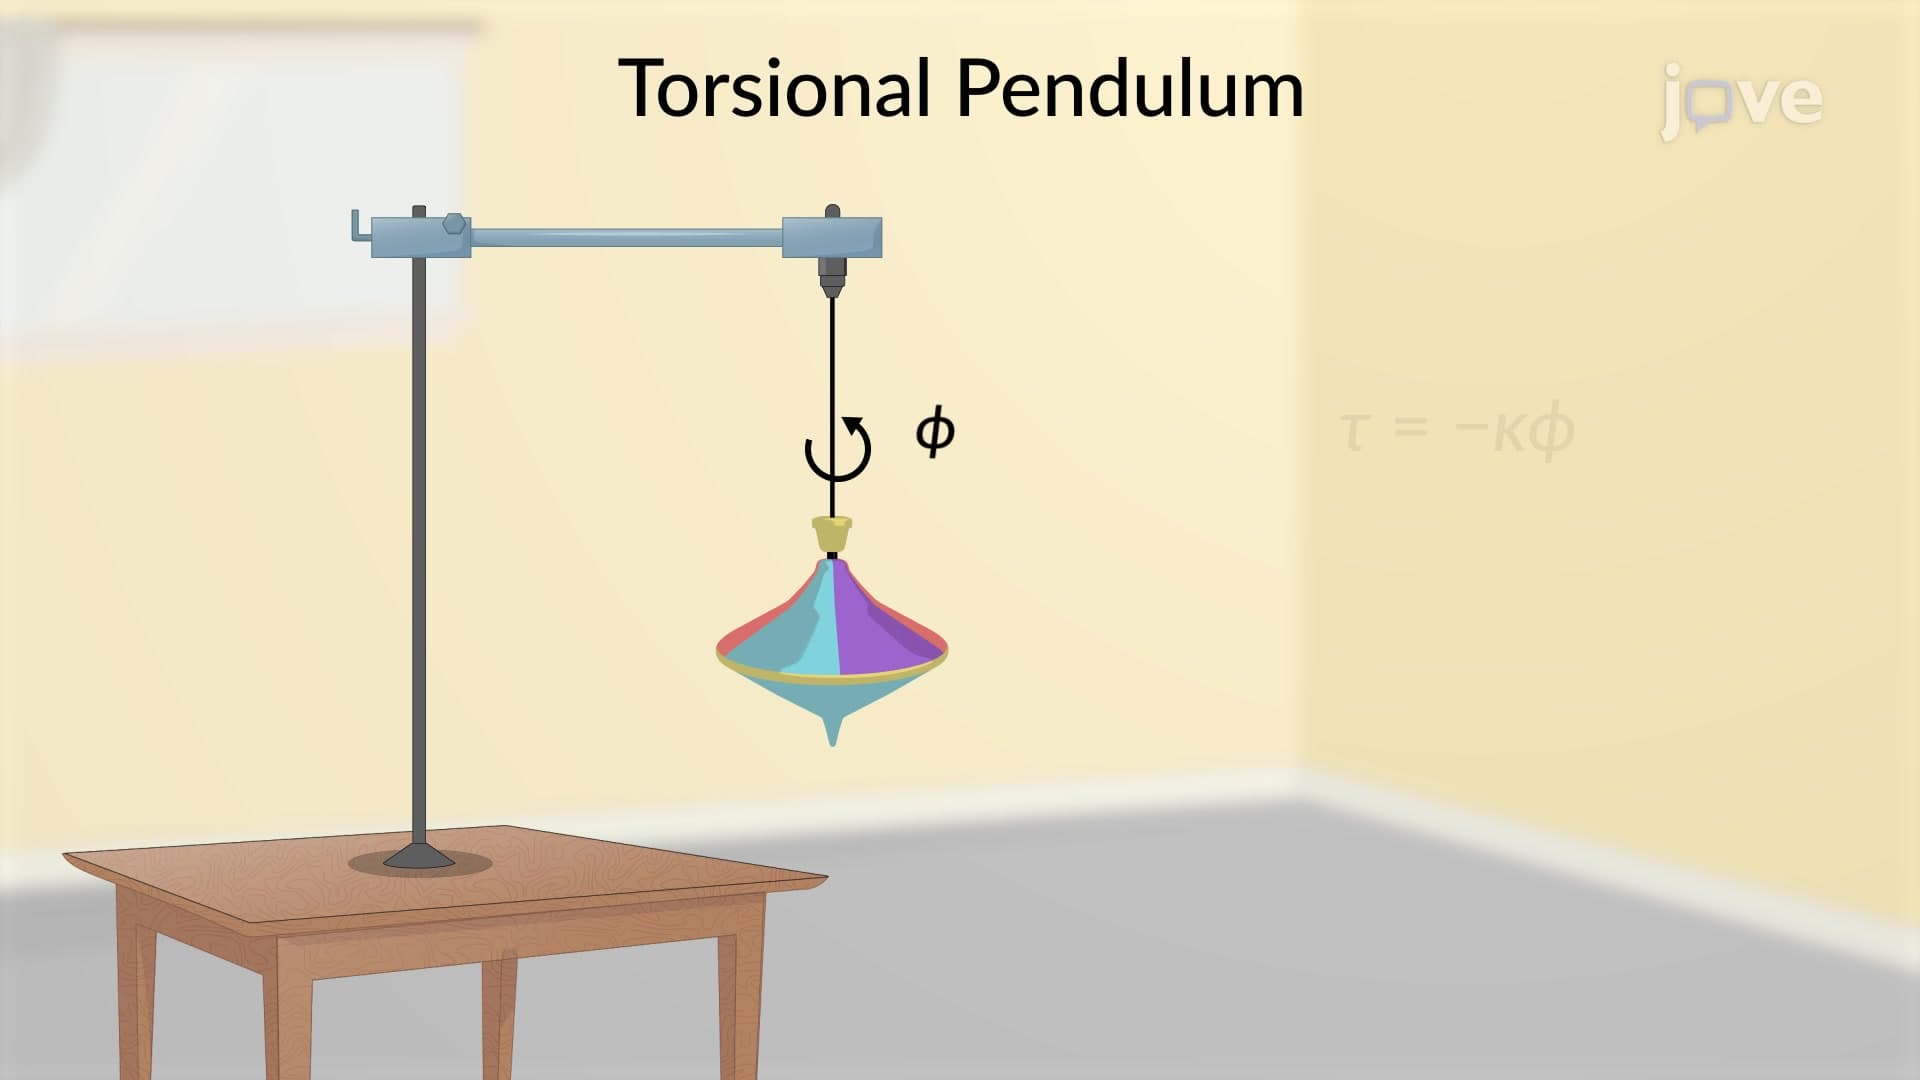
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:23
Principle of Linear Impulse and Momentum for a Single Particle: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum...