Related Experiment Video
Updated: Aug 16, 2025

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Kinematic Analysis of Bionic Elephant Trunk Robot Based on Flexible Series-Parallel Structure
Qitao Huang1, Peng Wang1, Yuhao Wang1
1Harbin Institute of Technology, School of Mechatronics Engineering, Harbin 150001, China.

Abstract:
Researchers borrow ideas from biological characteristics and behavior in design to make bionic robots that can meet unstructured and complex operating environments. The elephant trunk has been widely imitated by bionic robots because of its strong dexterity and stiffness adjustability. Due to the complex structure of the current elephant trunk robot, a series-parallel elephant trunk robot based on flexible rod actuation and a 6-degree-of-freedom (6-dof) parallel module is proposed in this paper. The bionic robot has a simple structure and redundant kinematics, which can realize the control of stiffness. This work focuses on the modeling of the flexible driving rod, the kinematics of a single parallel module, and the whole biomimetic robot. The kinematics are verified by simulation, which lays a foundation for future research on stiffness regulation.

Related Concept Videos
 01:30
Machines: Problem Solving II
 01:29
Space Trusses: Problem Solving
Consider a tripod consisting of a tetrahedral space truss with a ball-and-socket joint at C. Suppose the height and lengths of the horizontal and vertical...
 01:30
Method of Sections
 01:30
Method of Joints: Problem Solving I
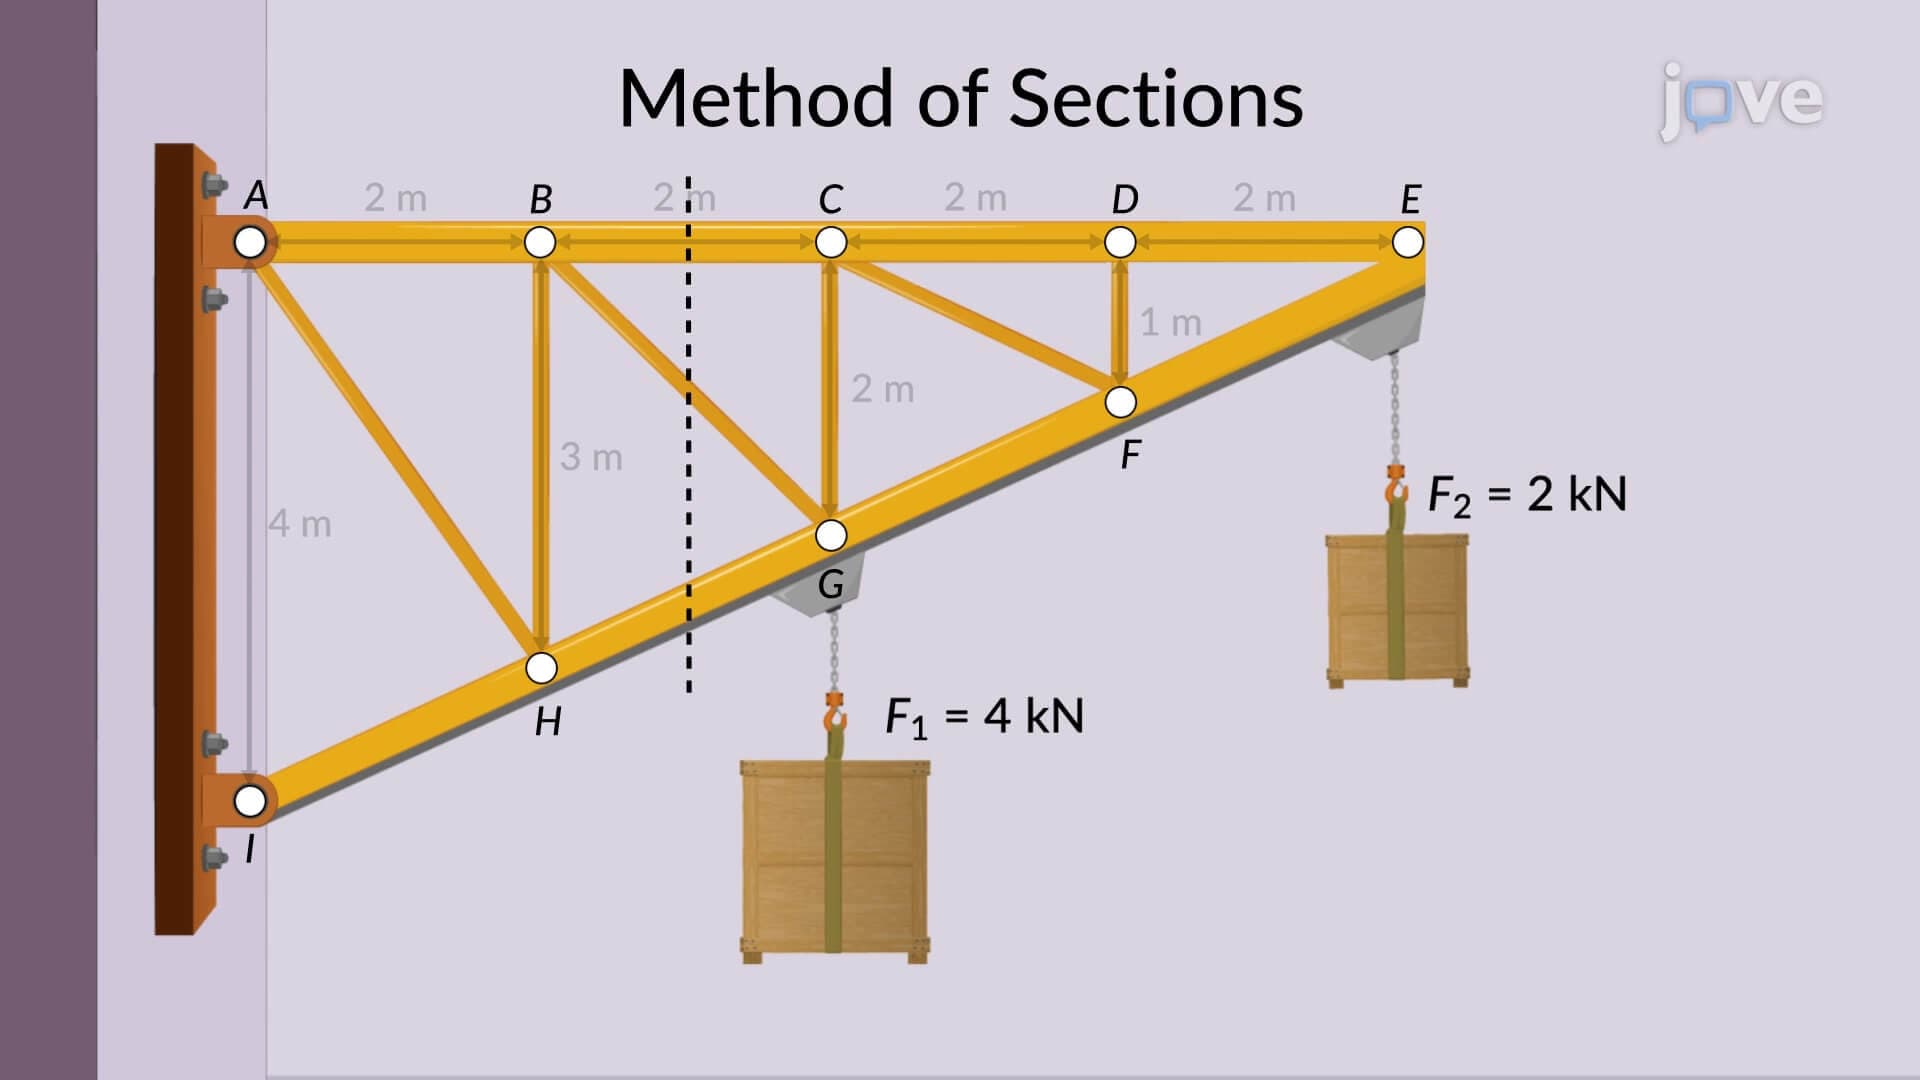 01:30
Method of Sections: Problem Solving II
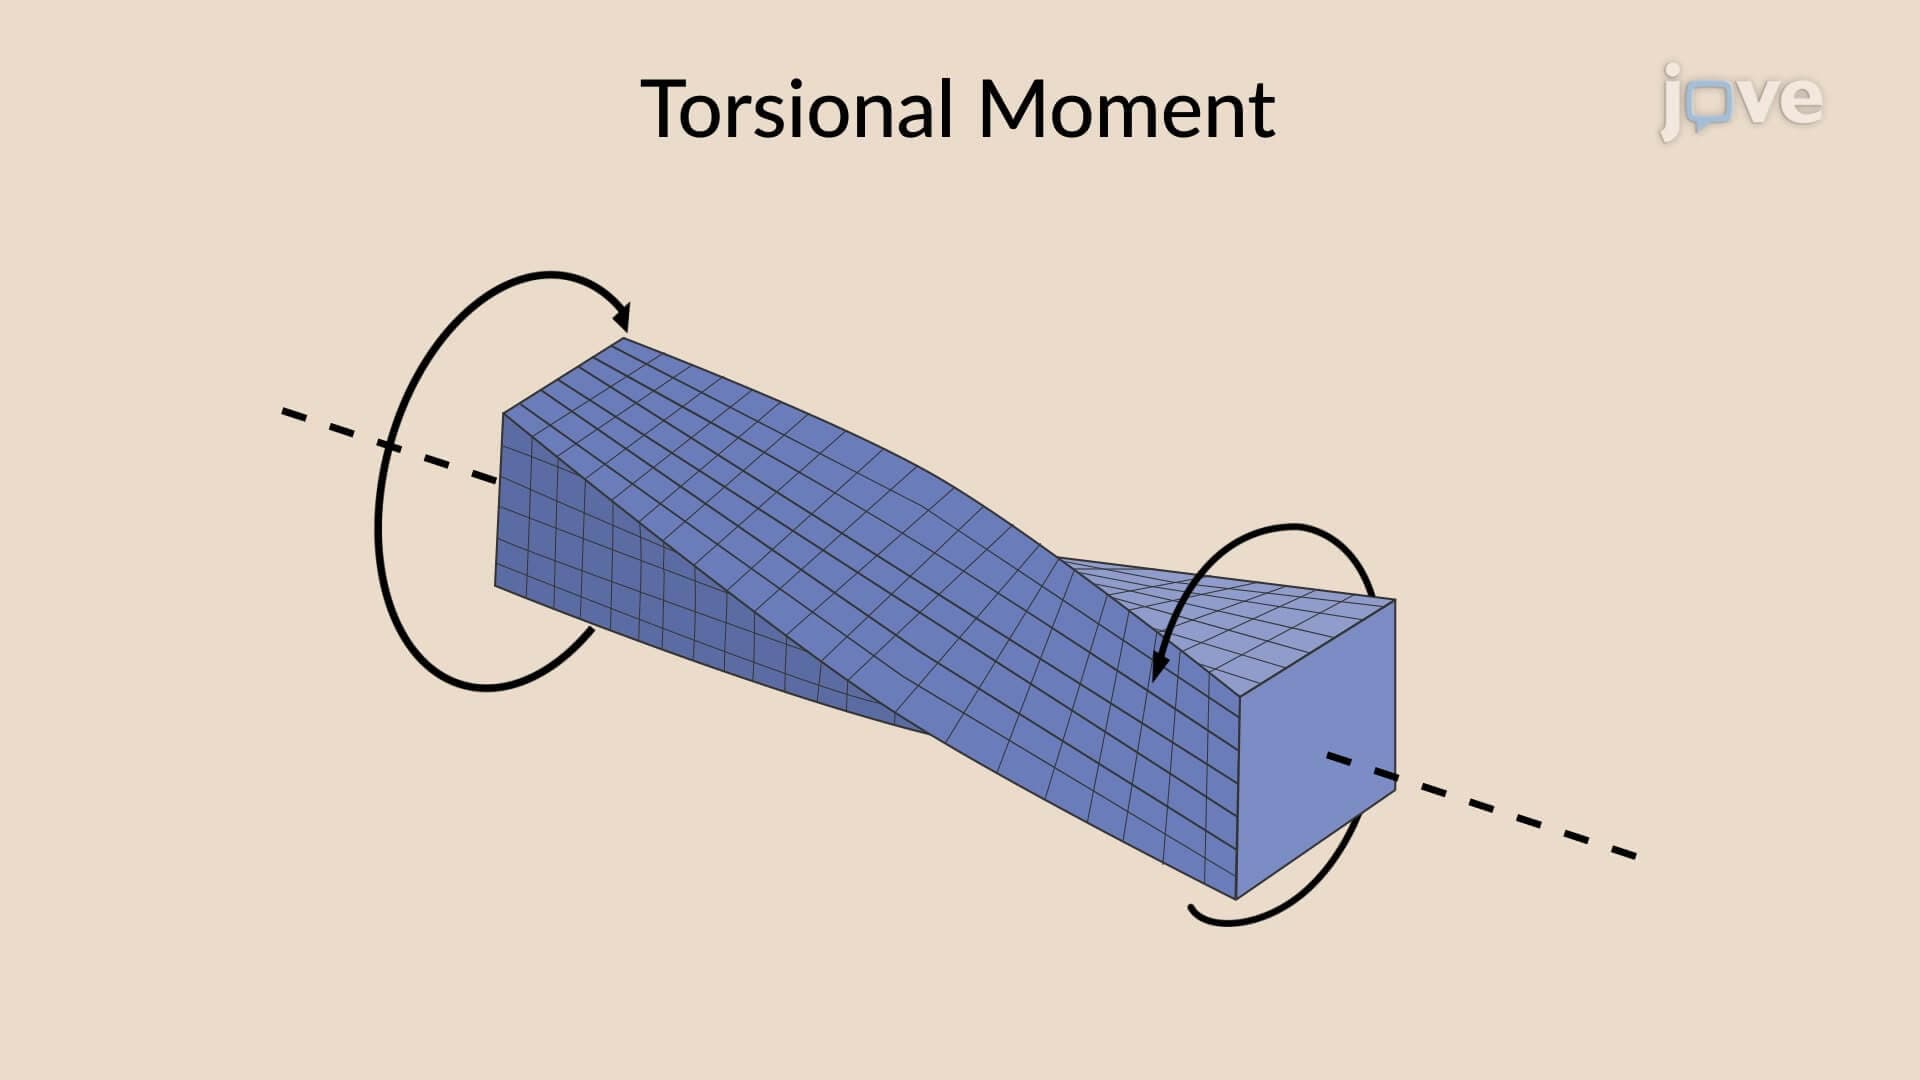 01:20
Bending and Torsional Moments
The reaction developed in a structural element when subjected to an external force causes the element to bend. When a structural element bends upwards, it creates compressive normal forces on the top and tensile normal forces on the bottom, resulting in a couple that determines the bending...