Related Experiment Video
Updated: Aug 15, 2025

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Skilled motor control of an inverted pendulum implies low entropy of states but high entropy of actions
Nicola Catenacci Volpi1, Martin Greaves1, Dari Trendafilov2
1Department of Computer Science, University of Hertfordshire, Hatfield, England, United Kingdom.

Abstract:
The mastery of skills, such as balancing an inverted pendulum, implies a very accurate control of movements to achieve the task goals. Traditional accounts of skilled action control that focus on either routinization or perceptual control make opposite predictions about the ways we achieve mastery. The notion of routinization emphasizes the decrease of the variance of our actions, whereas the notion of perceptual control emphasizes the decrease of the variance of the states we visit, but not of the actions we execute. Here, we studied how participants managed control tasks of varying levels of difficulty, which consisted of controlling inverted pendulums of different lengths. We used information-theoretic measures to compare the predictions of alternative accounts that focus on routinization and perceptual control, respectively. Our results indicate that the successful performance of the control task strongly correlates with the decrease of state variability and the increase of action variability. As postulated by perceptual control theory, the mastery of skilled pendulum control consists in achieving stable control of goals by flexible means.

Related Concept Videos
 01:05
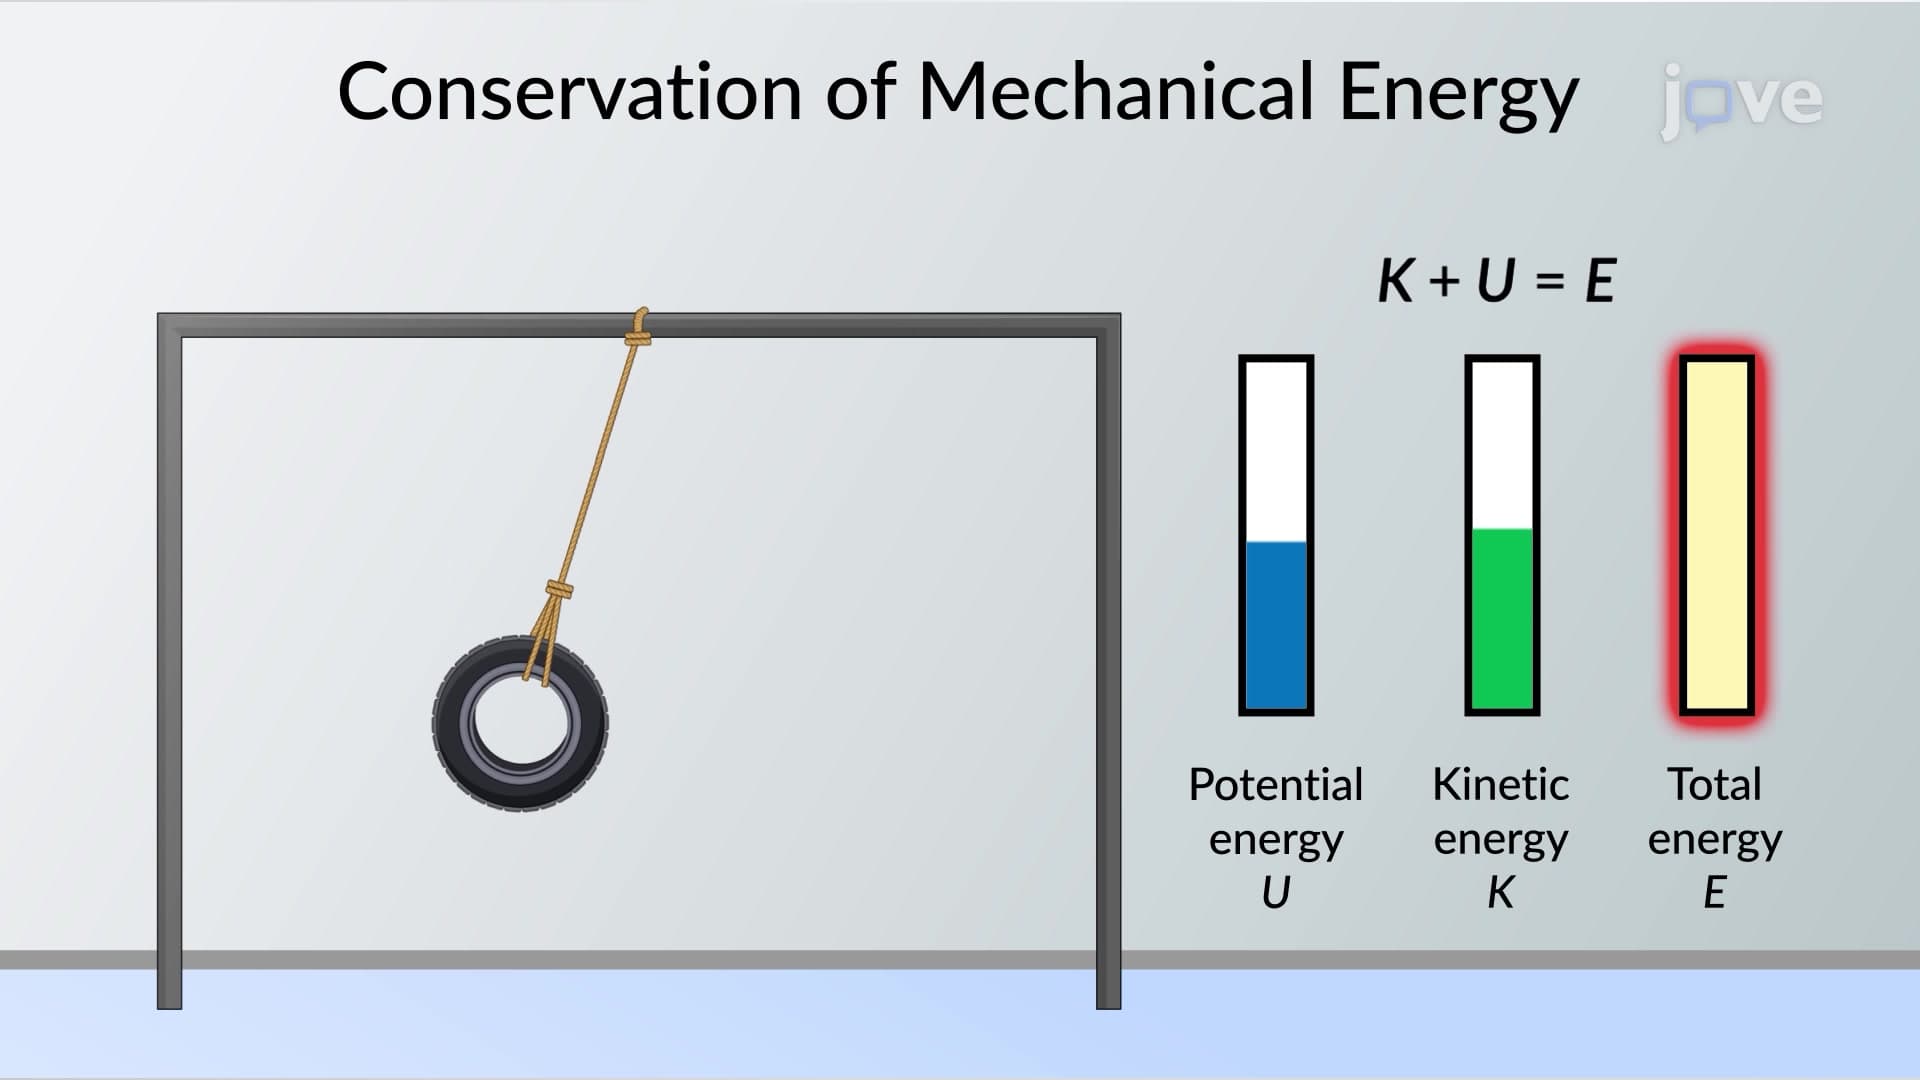
Conservation of Mechanical Energy
When a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:28
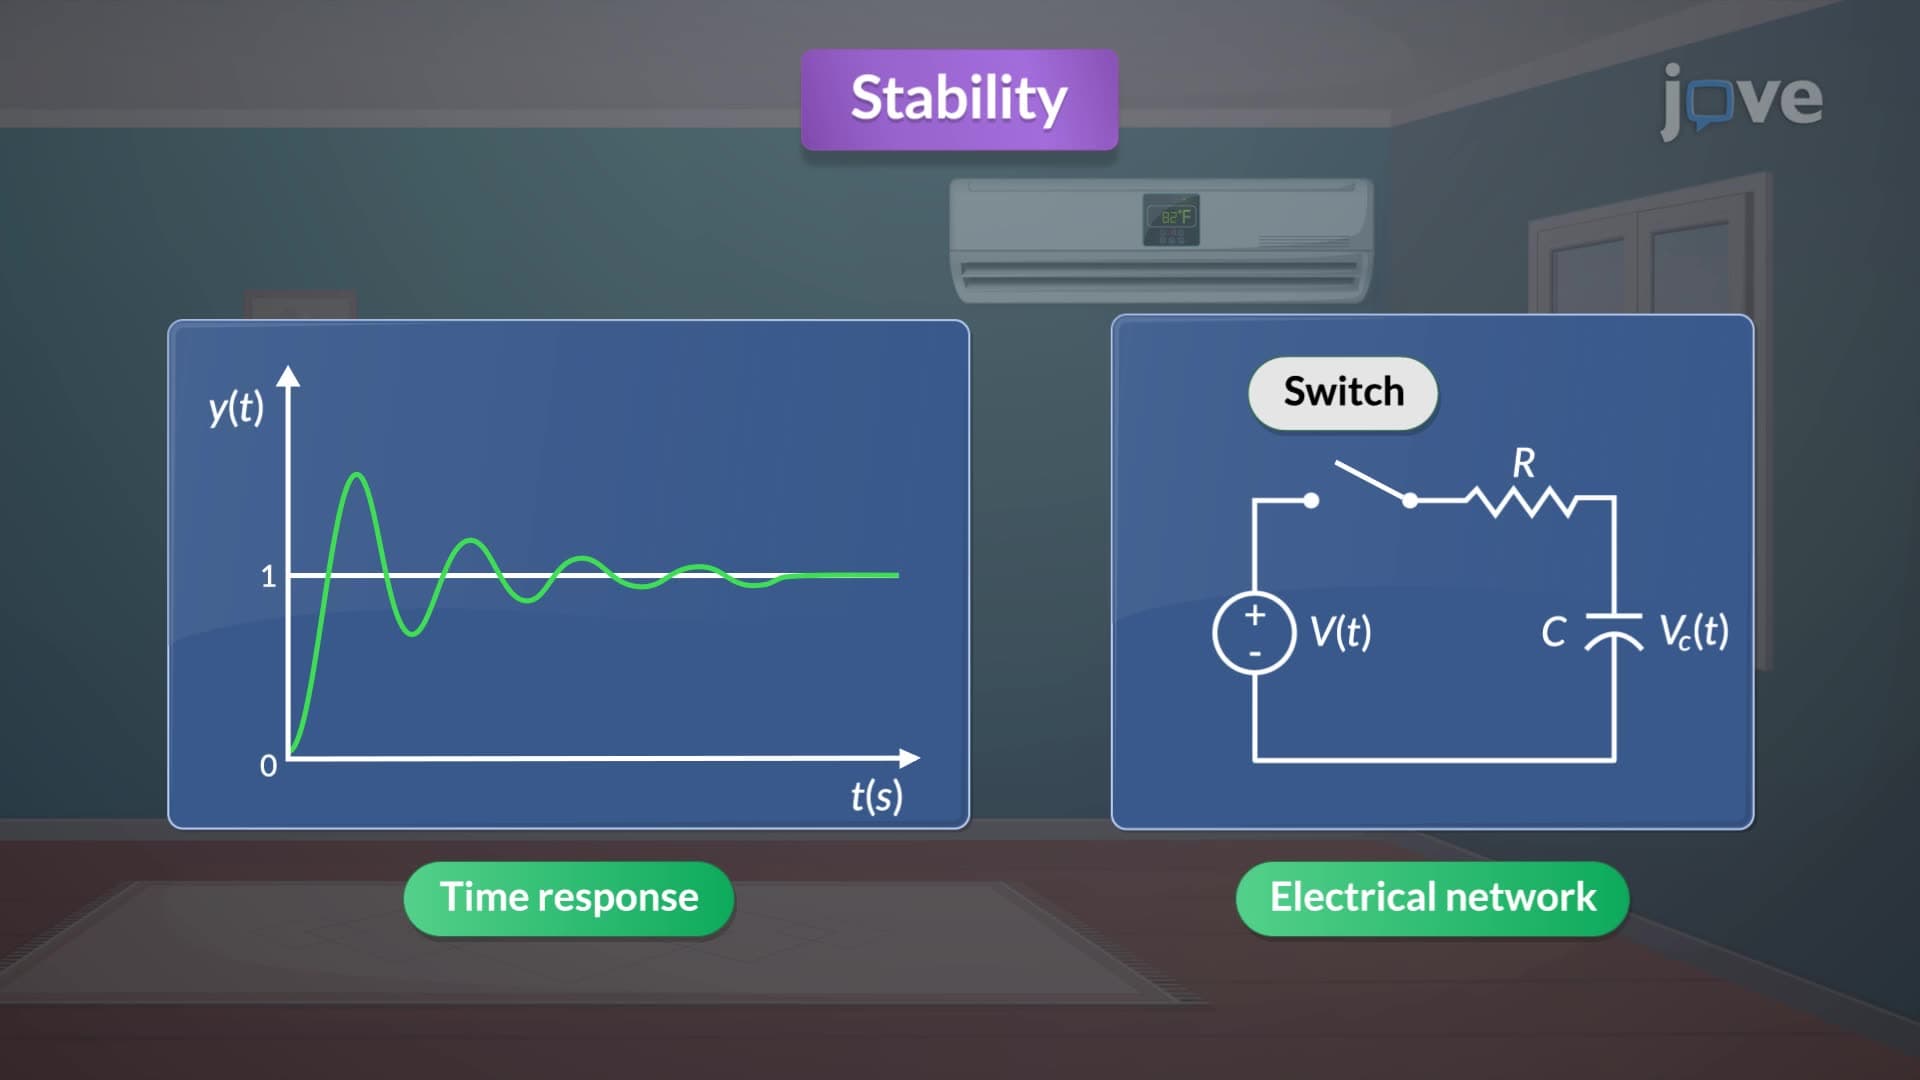
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...