Related Experiment Video
Updated: Oct 28, 2026
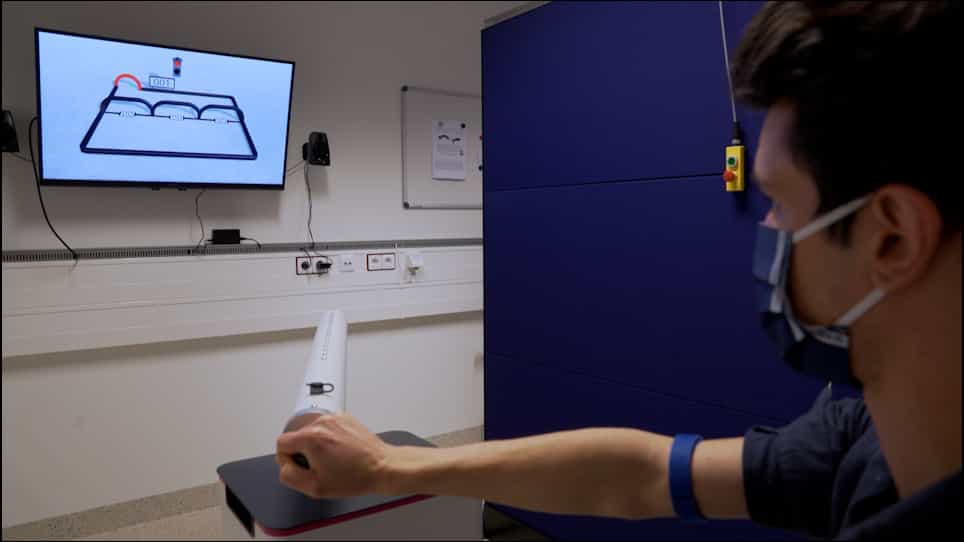
Investigating Pain-Related Avoidance Behavior using a Robotic Arm-Reaching Paradigm
Published on: October 3, 2020
An integrative computational approach for obstacle avoidance during action selection
Shan Zhong1,2, Nader Pouratian3, Paul Schrater4
1Alfred E.Mann Department of Biomedical Engineering, University of Southern California, Los Angeles, California, United States of America.

Abstract:
Action selection in cluttered environments, where individuals must simultaneously pursue goals and avoid obstacles, presents a significant challenge for the brain. To understand the underlying mechanisms of action selection in such contexts, we propose a computational model that extends stochastic optimal control theory through a novel framework for obstacle avoidance. The model decomposes action selection into a weighted combination of individual control policies, each generated for either target approach or obstacle avoidance. By integrating value information from goals, obstacles, and actions into a unified measure of "relative desirability", the model dynamically determines the contribution of each policy to the overall action selection process. We evaluated the framework using simulated target-reaching tasks in cluttered environments based on previous human studies. The results showed that the model qualitatively captures key features of human motor behavior, including the influence of obstacle properties on movement trajectories and the transient tendency to initiate movements toward obstacles before avoidance.This work offers new insights into the dynamic interaction between approach and avoidance behaviors, providing a basis for future studies of action selection in more complex and naturalistic settings.
Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:20
Frustration and Conflict: Approach-Approach, Approach-Avoidance
One common type of conflict is the Approach–Approach Conflict. In this case, a person faces two desirable options,...
 01:30
Vector Functions and Motion: Problem Solving