Related Experiment Video
Updated: Aug 15, 2025
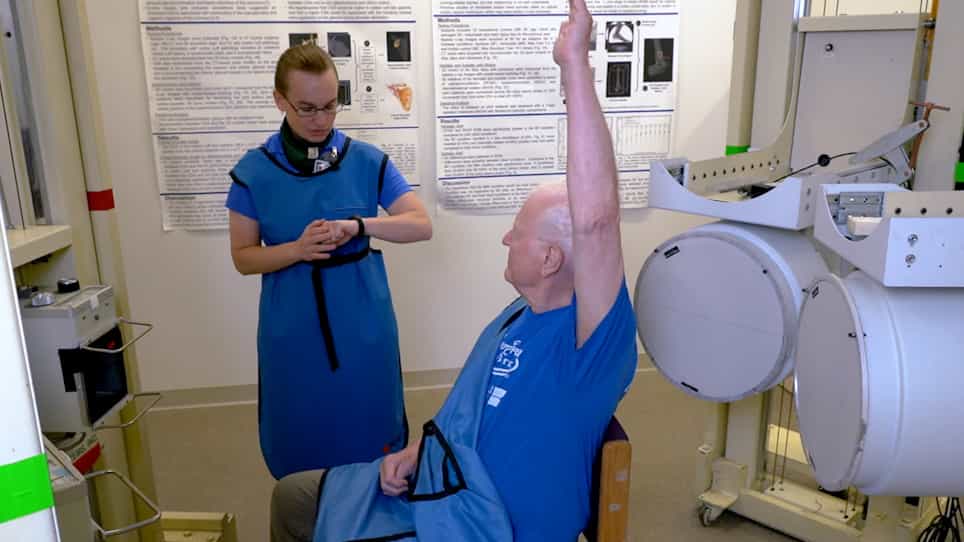

Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021
Towards Single Camera Human 3D-Kinematics
Marian Bittner1,2,3, Wei-Tse Yang2, Xucong Zhang2
1Vicarious Perception Technologies (VicarVision), 1015 AH Amsterdam, The Netherlands.

Abstract:
Markerless estimation of 3D Kinematics has the great potential to clinically diagnose and monitor movement disorders without referrals to expensive motion capture labs; however, current approaches are limited by performing multiple de-coupled steps to estimate the kinematics of a person from videos. Most current techniques work in a multi-step approach by first detecting the pose of the body and then fitting a musculoskeletal model to the data for accurate kinematic estimation. Errors in training data of the pose detection algorithms, model scaling, as well the requirement of multiple cameras limit the use of these techniques in a clinical setting. Our goal is to pave the way toward fast, easily applicable and accurate 3D kinematic estimation. To this end, we propose a novel approach for direct 3D human kinematic estimation D3KE from videos using deep neural networks. Our experiments demonstrate that the proposed end-to-end training is robust and outperforms 2D and 3D markerless motion capture based kinematic estimation pipelines in terms of joint angles error by a large margin (35% from 5.44 to 3.54 degrees). We show that D3KE is superior to the multi-step approach and can run at video framerate speeds. This technology shows the potential for clinical analysis from mobile devices in the future.
Related Concept Videos
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
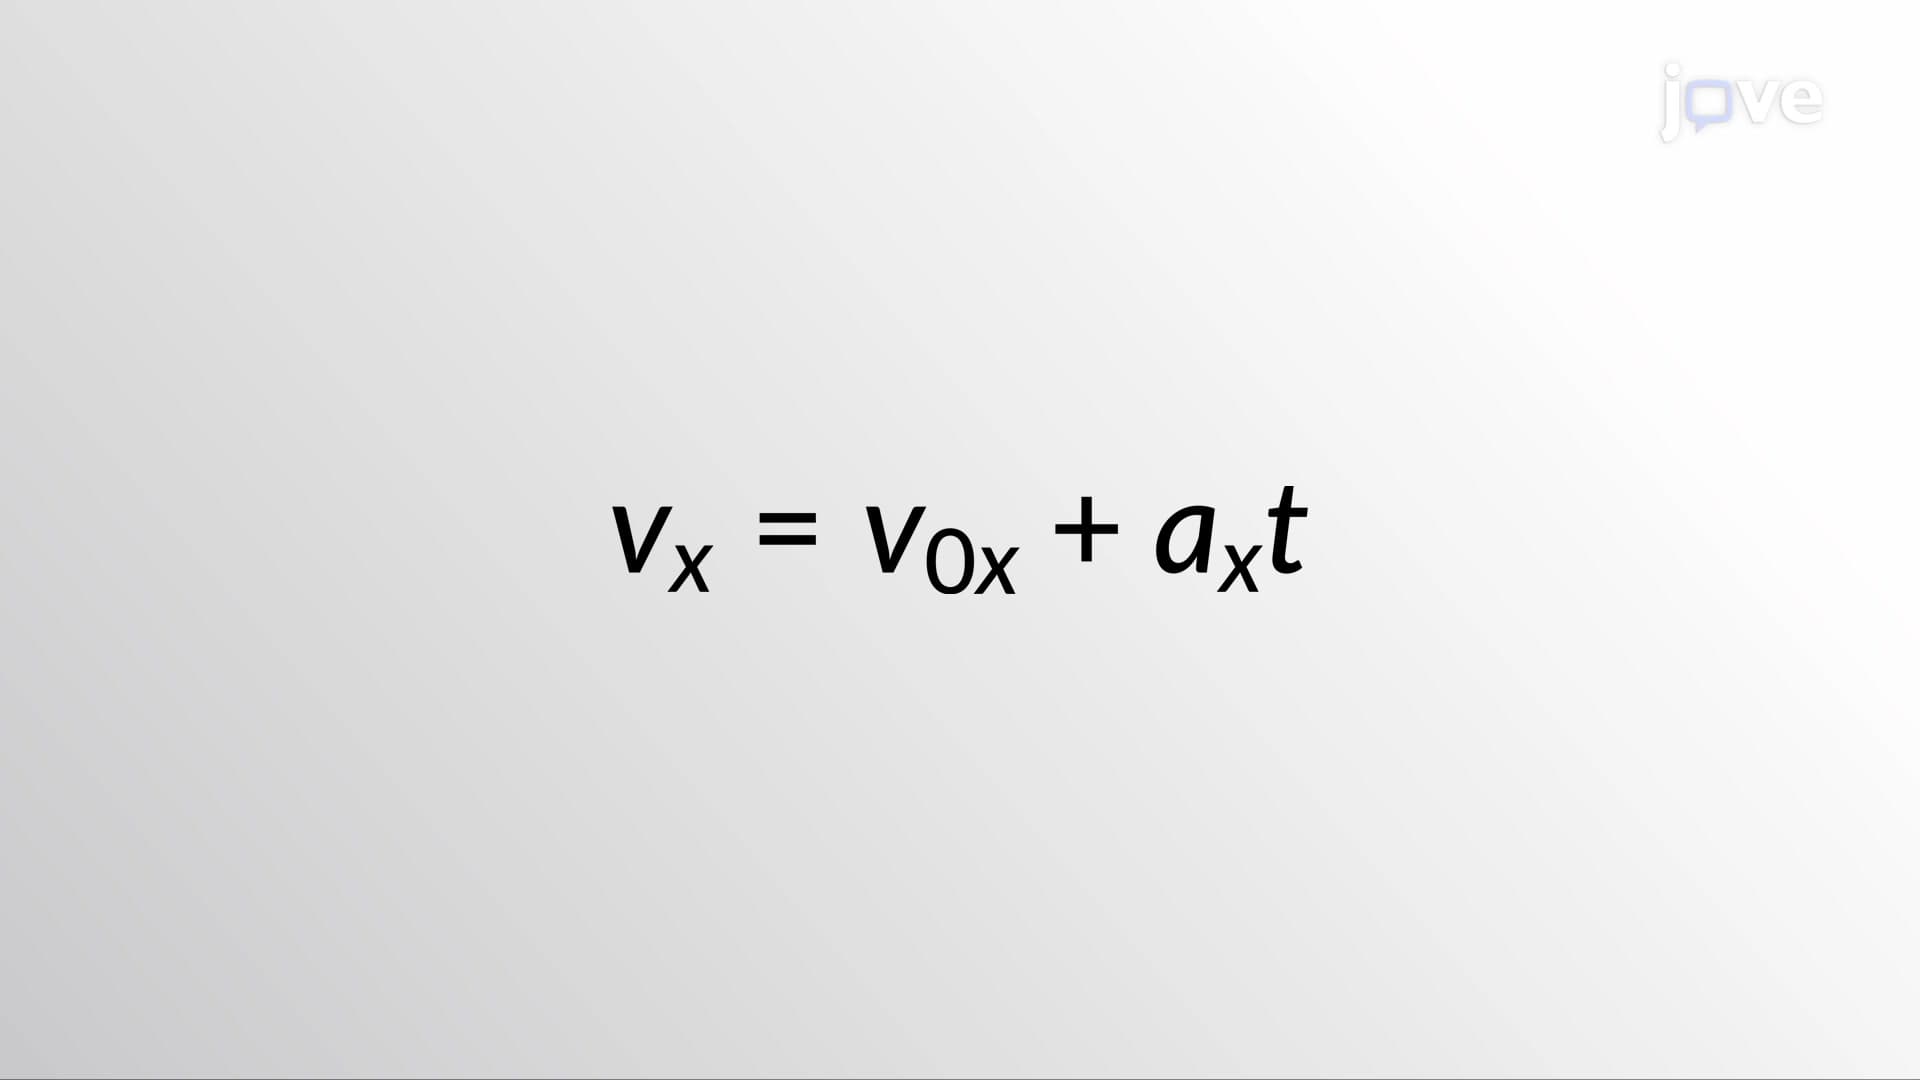 01:26
Kinematic Equations - I
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...