Related Experiment Video
Updated: Jun 27, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
A Tightly Coupled Multibody Dynamics and Multi-Sensor Fusion Algorithm for Simultaneous Kinematics and Kinetics
Hassan Osman1, Daan de Kanter1, Jelle Boelens1,2
1Department of Biomechanical Engineering, Delft University of Technology, 2628 CD Delft, The Netherlands.

Abstract:
Inertial Measurement Units (IMUs) enable portable, multibody motion capture in diverse environments beyond the laboratory, making them a desirable choice for diagnosing mobility disorders and supporting rehabilitation in clinical or home settings. However, challenges associated with IMU measurements, including magnetic distortions and errors due to integration drift, complicate their broader use for motion capture. In this work, we propose a tightly coupled motion-capture approach that directly integrates IMU measurements with multibody dynamic models via an iterated extended Kalman filter to simultaneously estimate the system's kinematics and kinetics. By enforcing the complete multibody system dynamics and utilizing only accelerometer and gyroscope data, our method accurately estimates joint kinematics and kinetics. Our algorithm is designed to fuse different sensor data, such as optical motion-capture measurements and joint torque readings, to further enhance estimation accuracy. We validated our approach using highly accurate ground-truth data from a 3-degree-of-freedom pendulum and a 6-degree-of-freedom collaborative robot. We demonstrate a maximum root-mean-square difference of 3.75° in the pendulum's computed joint angles with respect to the marker motion-capture inverse kinematics. For the robot, we observed a maximum joint angle root-mean-square difference of 3.24° with respect to the joint encoders, while the maximum joint angle root-mean-square difference of the optical motion-capture inverse kinematics with respect to the encoders was 1.16°. With regard to kinetic estimates, we report a maximum joint torque root-mean-square difference of 3.02 Nm in the pendulum with respect to the marker motion-capture inverse dynamics and 4.27 Nm in the robot relative to its joint torque sensors.
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
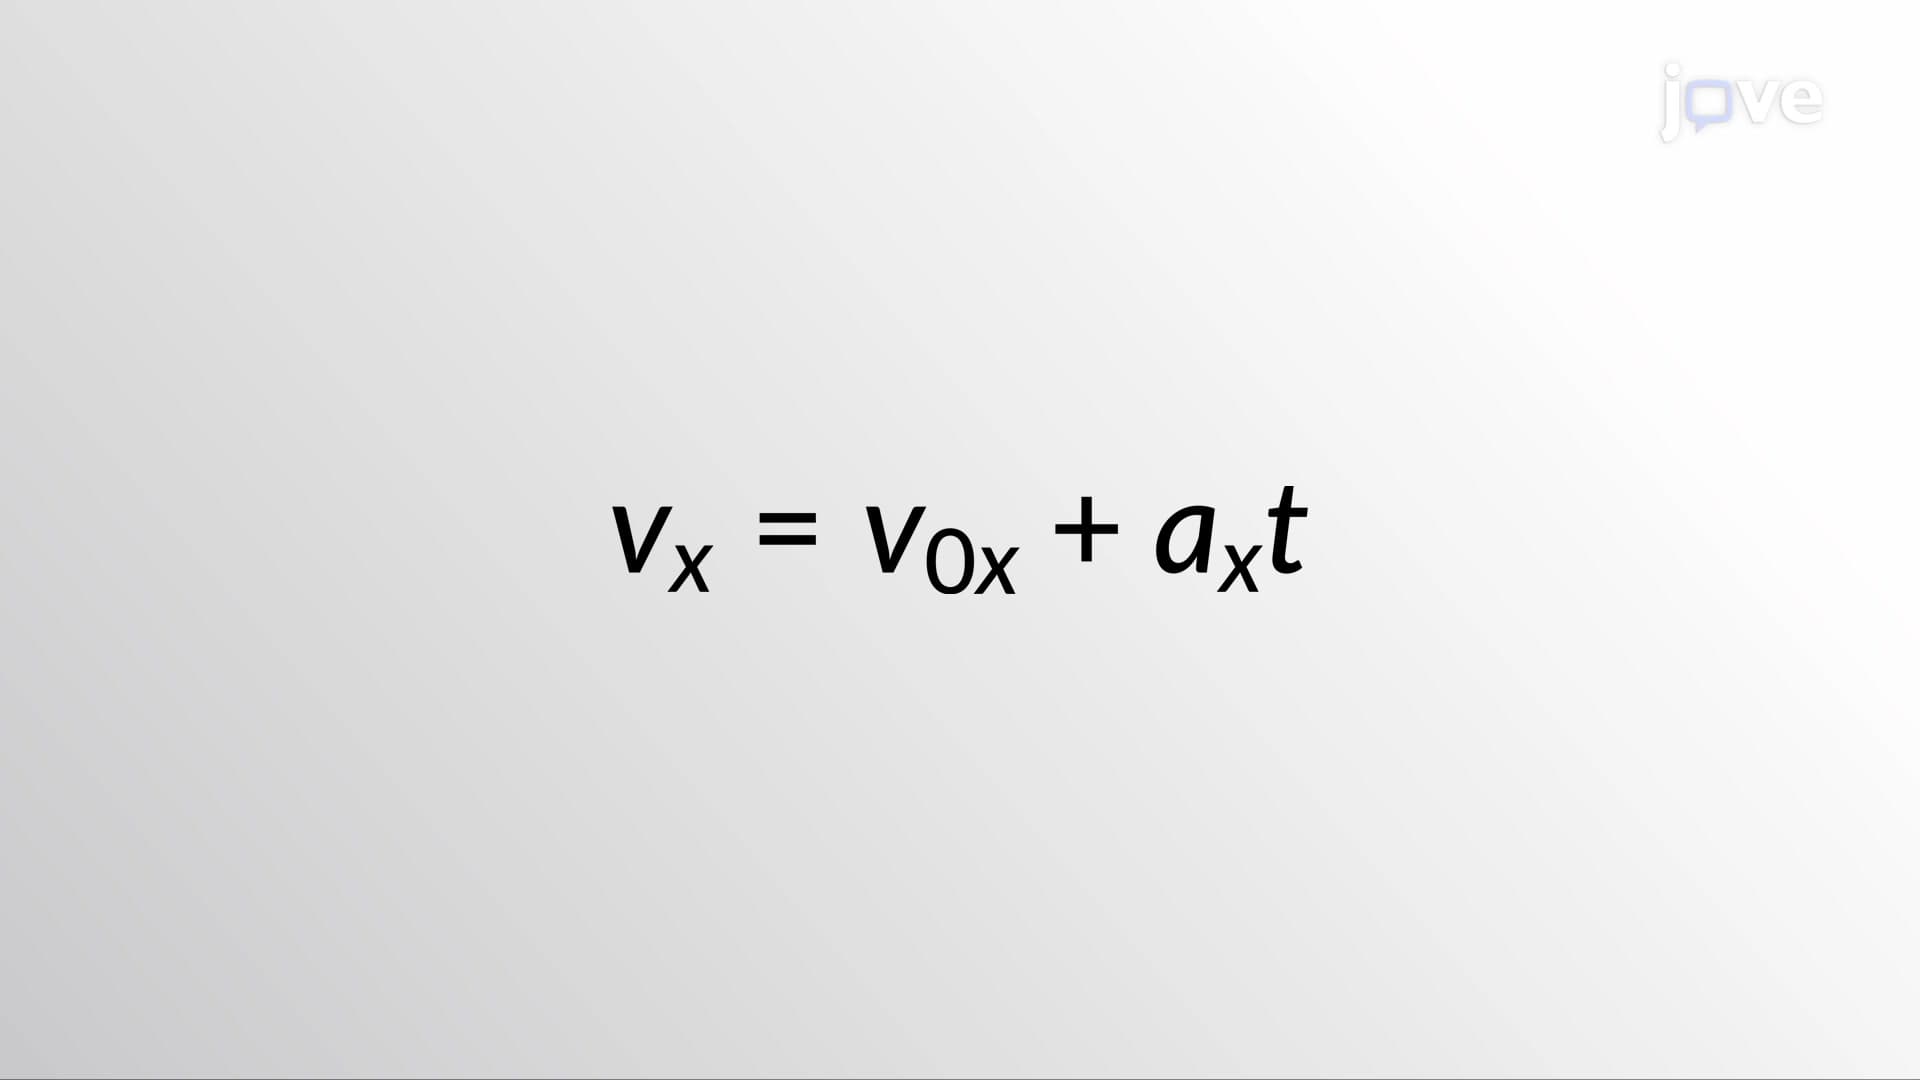 01:26
Kinematic Equations - I
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:13
Kinetic Energy for a Rigid Body