Related Experiment Video
Updated: Aug 14, 2025

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
A novel positioning method of anti-punching drilling robot based on the fusion of multi-IMUs and visual image
Lei Si1, Zhongbin Wang2, Jiahao Li2
1School of Mechatronic Engineering, China University of Mining and Technology, Xuzhou 221116, China; Hunan Provincial Key Laboratory of Health Maintenance for Mechanical Equipment, Hunan University of Science and Technology, Xiangtan, 411201, China.

Abstract:
Anti-punching drilling robot (APDR) is the key equipment for underground rock burst relief in coal mine and the accurate position and attitude determination is the basis and premise for realizing unmanned pressure relief operation. In this paper, a novel positioning method of APDR based on spatial array inertial measurement units (IMUs) and visual image is proposed. Firstly, the spatial array layout of multiple IMUs is displayed creatively, and the data fusion model and the posture calculation process of spatial array IMUs are constructed. The superiority of proposed spatial array IMUs is verified through the motion trajectory simulation analysis and mobile carrier simulation experiments. Then, an image enhancement method (SSR-AF) is designed to overcome the problems of atomization, glare, uneven illumination and noise interference in coal mine images, so as to improve the accuracy of image feature extraction and matching. Accordingly, the positioning estimation model based on continuous frame images is established. Furthermore, the fusion positioning process of APDR is presented by using the loose coupling mode based on Kalman filtering algorithm. The position and attitude monitoring experimental platform of APDR is built in a simulated coal mine tunnel. The experimental results indicate that the calculation errors of displacement and attitude based on the proposed fusion positioning method is superior to the competing methods, which meet the actual positioning requirements, and verify the feasibility and practicability of the proposed positioning method for APDR.
More Related Videos
 05:12
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
 09:46
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
 01:30
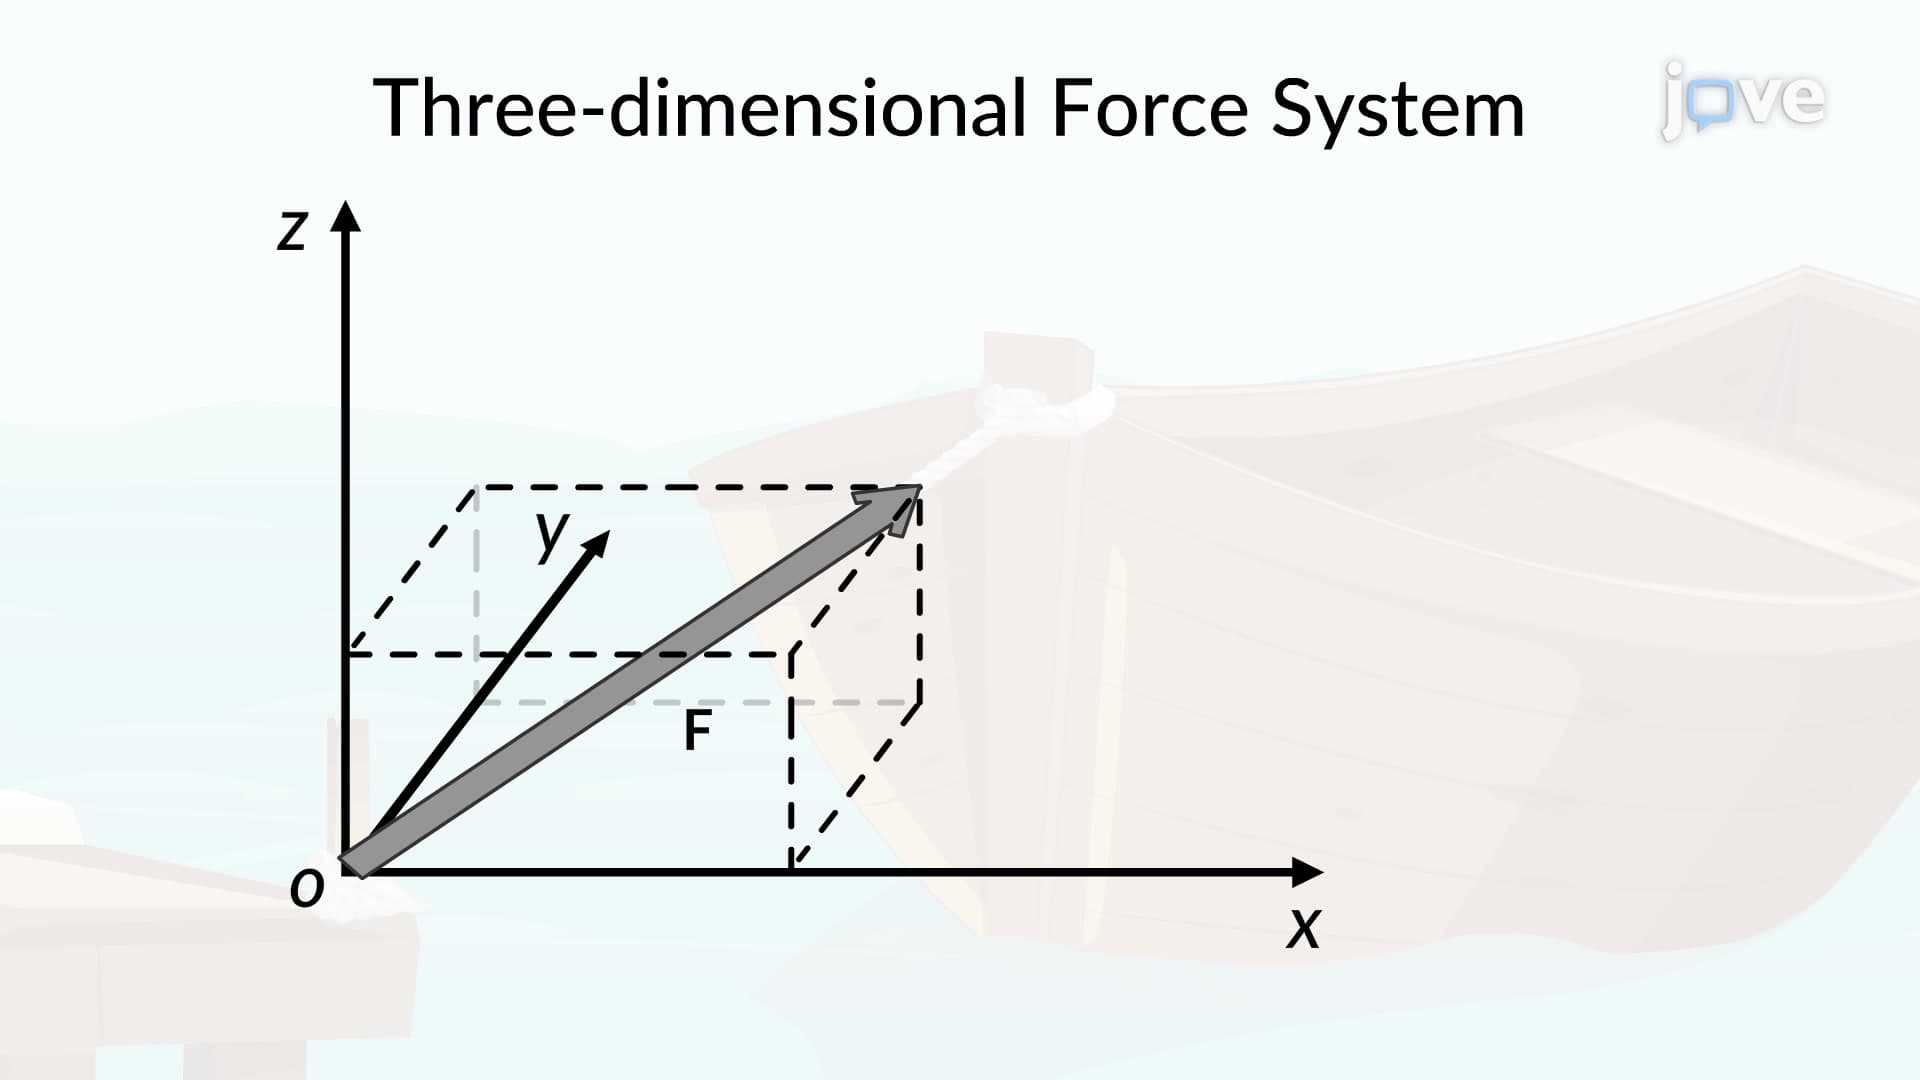
Three-Dimensional Force System