Related Experiment Video
Updated: Aug 14, 2025

Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
A Personalized Navigation Route Recommendation Strategy Based on Differential Perceptron Tracking User's Driving
Pengzhan Chen1, Jihua Wu1, Ning Li1
1Taizhou University, School of Intelligent Manufacture, Taizhou 318000, Zhejiang, China.

Abstract:
With the increasing frequency of autonomous driving, more and more attention is paid to personalized path planning. However, the path selection preferences of users will change with internal or external factors. Therefore, this paper proposes a personalized path recommendation strategy that can track and study user's path preference. First, we collect the data of the system, establish the relationship with the user preference factor, and get the user's initial preference weight vector by dichotomizing the K-means algorithm. The system then determines whether user preferences change based on a set threshold, and when the user's preference changes, the current preference weight vector can be obtained by redefining the preference factor or calling difference perception. Finally, the road network is quantized separately according to the user preference weight vector, and the optimal path is obtained by using Tabu search algorithm. The simulation results of two scenarios show that the proposed strategy can meet the requirements of autopilot even when user preferences change.
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 02:20
Routes of Persuasion
 01:19
Root-Locus Method
This system can be represented by a block...
 01:11
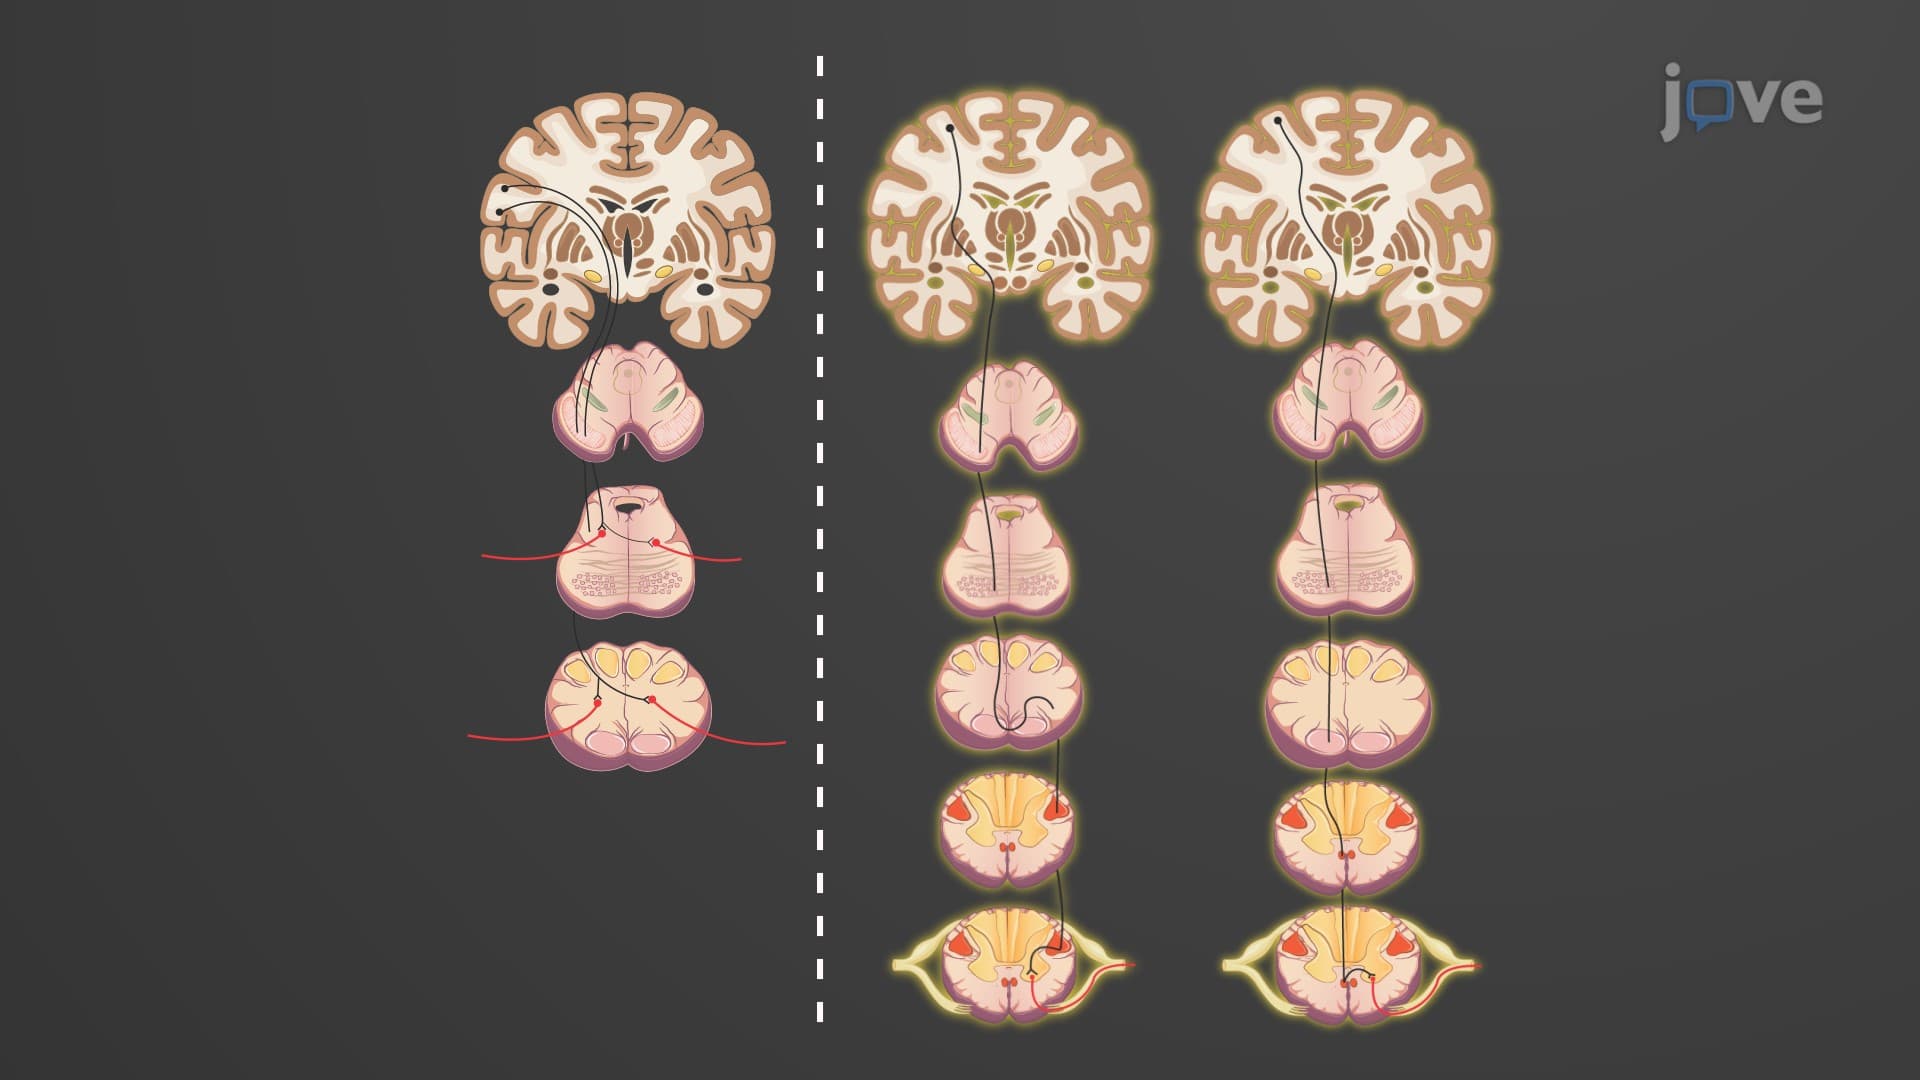
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:17
Rolling Resistance: Problem Solving
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...