Safety-boundary-aware time-varying formation control for multi-agent systems in unknown corridors
Related Experiment Videos
Dingqi Zhu1, Zhi Lian1, Mou Chen1
1College of Automation Engineering, Nanjing University of Aeronautics and Astronautics, Nanjing, 210016, China.

Abstract:
Safe traversal of multi-agent formations in constrained environments is essential for many cooperative robotic applications, yet existing methods often rely on accurate prior maps, which limit their applicability in unknown corridors. To overcome this challenge, this paper studies the safe traversal of multi-agent systems through unknown corridors using time-varying formations, where agents possess only coarse prior knowledge of the corridor and must rely on online perception to progressively refine environmental information. To ensure safety during traversal under such limited information, an online safety-boundary construction method is proposed to derive an inner safety envelope with an explicit margin that is theoretically guaranteed to lie within the true boundary. Unlike approaches that depend on local obstacle avoidance, we compute the time-varying formation parameters under the safety-boundary constraints to generate reference trajectories for all agents. Accurate tracking of the generated reference trajectories is achieved by designing a trajectory-tracking control law. Simulation results show that, while preserving the prescribed formation geometry with high accuracy, the proposed method efficiently utilizes the available corridor space, achieving an average corridor utilization rate of 96.2%.
Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:05
Collisions in Multiple Dimensions: Introduction
 01:19
Masking and Demasking Agents
There are many masking agents, such as cyanide, fluoride, triethanolamine, thiourea, and 2,3-bis(sulfanyl)propan-1-ol (formerly 2,3-dimercapto-1-propanol), with the masking agent chosen based on the metal...
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:13
Stability of Equilibrium Configuration: Problem Solving
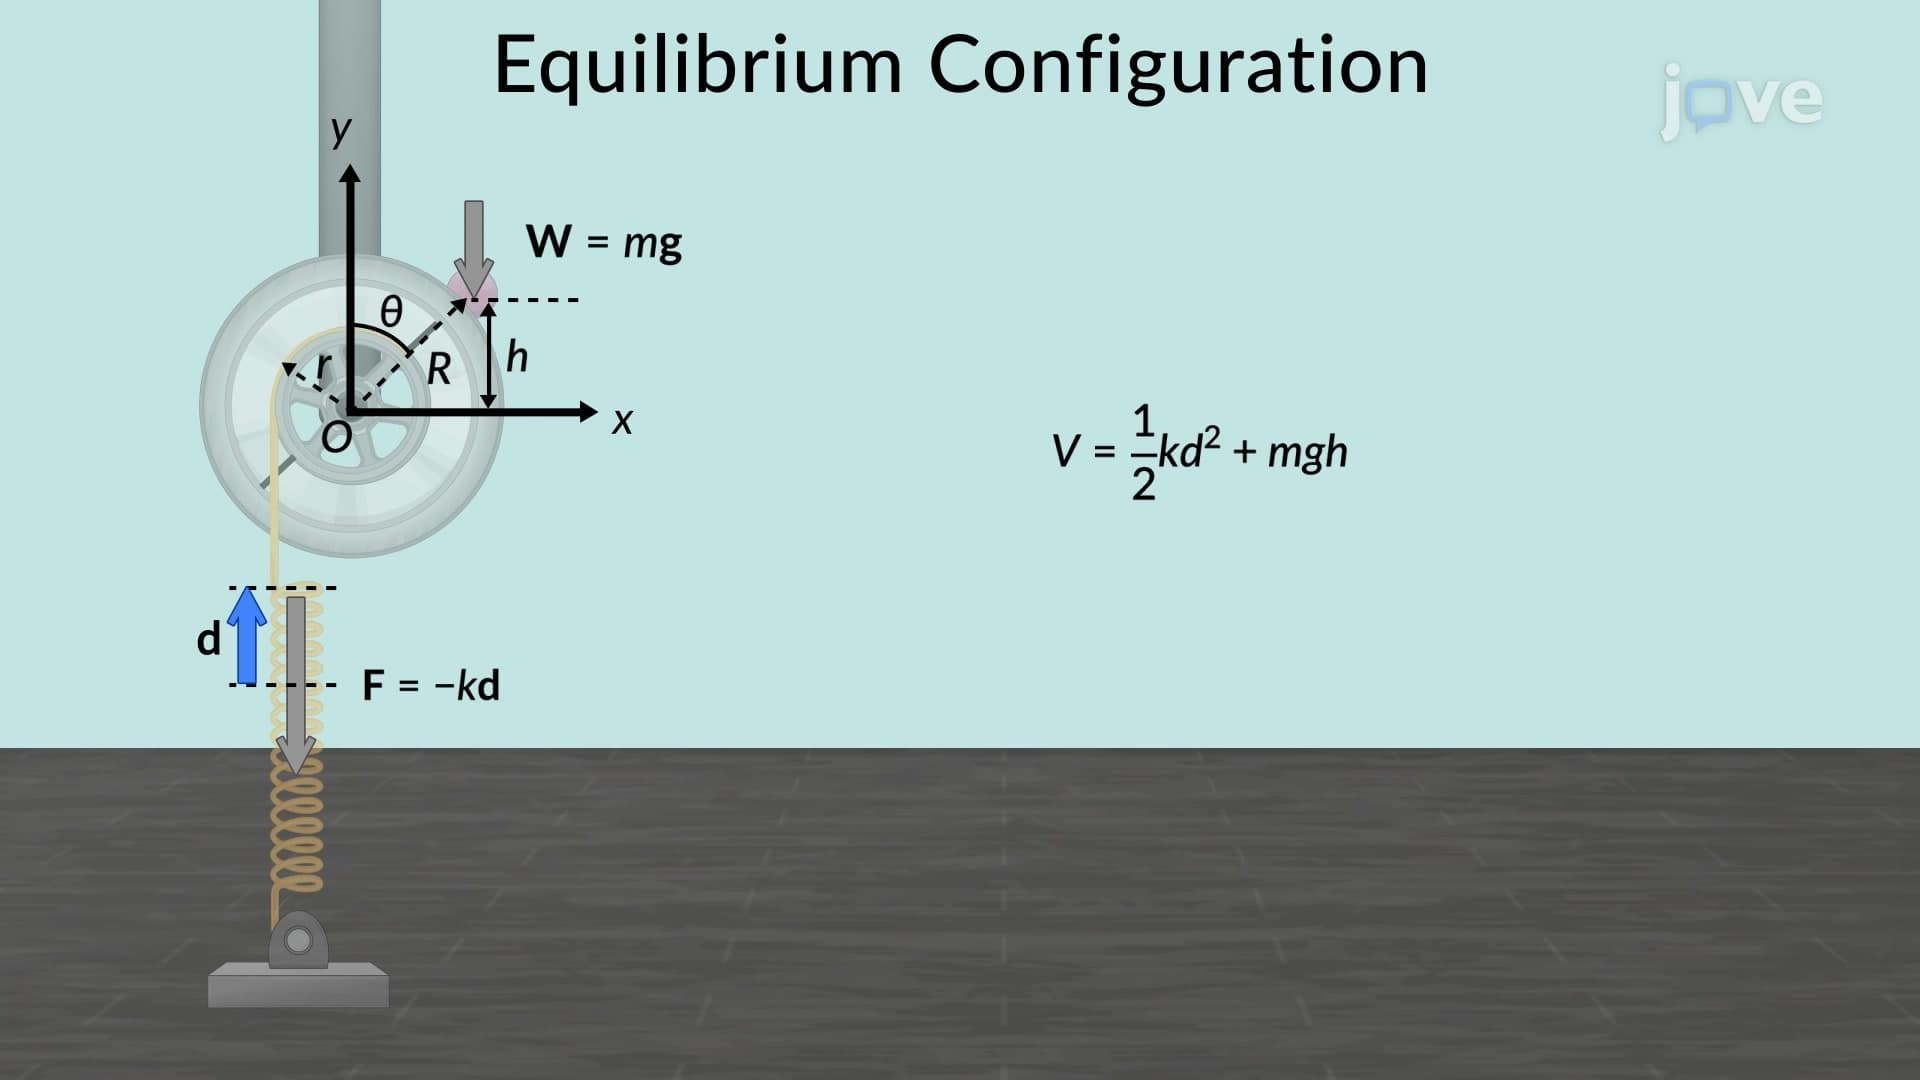
Problem-solving in the context of the stability of equilibrium configuration...