Improved H∞ control for singular Markovian jump systems via dynamic output-feedback
Related Experiment Video
Updated: Nov 7, 2026

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Chan-Eun Park1, Seok Young Lee2, Nam Kyu Kwon3
1School of Electronics Engineering, Kyungpook National University, Daegu, Republic of Korea.

Abstract:
This paper investigates the H∞ output-feedback admissibilization problem for singular Markovian jump systems (SMJSs) subject to disturbance-contaminated performance outputs. Most existing H∞ control results for SMJSs rely on the assumption that external disturbances do not directly affect the performance outputs, which significantly restricts their applicability. To address this limitation, a synthesis framework is developed that explicitly incorporates disturbance-to-output channels within the SMJS model. By introducing specially structured slack variables, the intractable nonconvex synthesis conditions arising from bilinear couplings between controller gains and Lyapunov variables are transformed into strict linear matrix inequalities. The resulting conditions enable the systematic design of dynamic output-feedback controllers while guaranteeing admissibility and prescribed H∞ performance. Two practical examples are provided to demonstrate the effectiveness of the proposed method. In these examples, the method handles disturbance-contaminated performance outputs that an existing output-feedback approach cannot handle. It also attains smaller attenuation levels than an existing state-feedback design.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:23
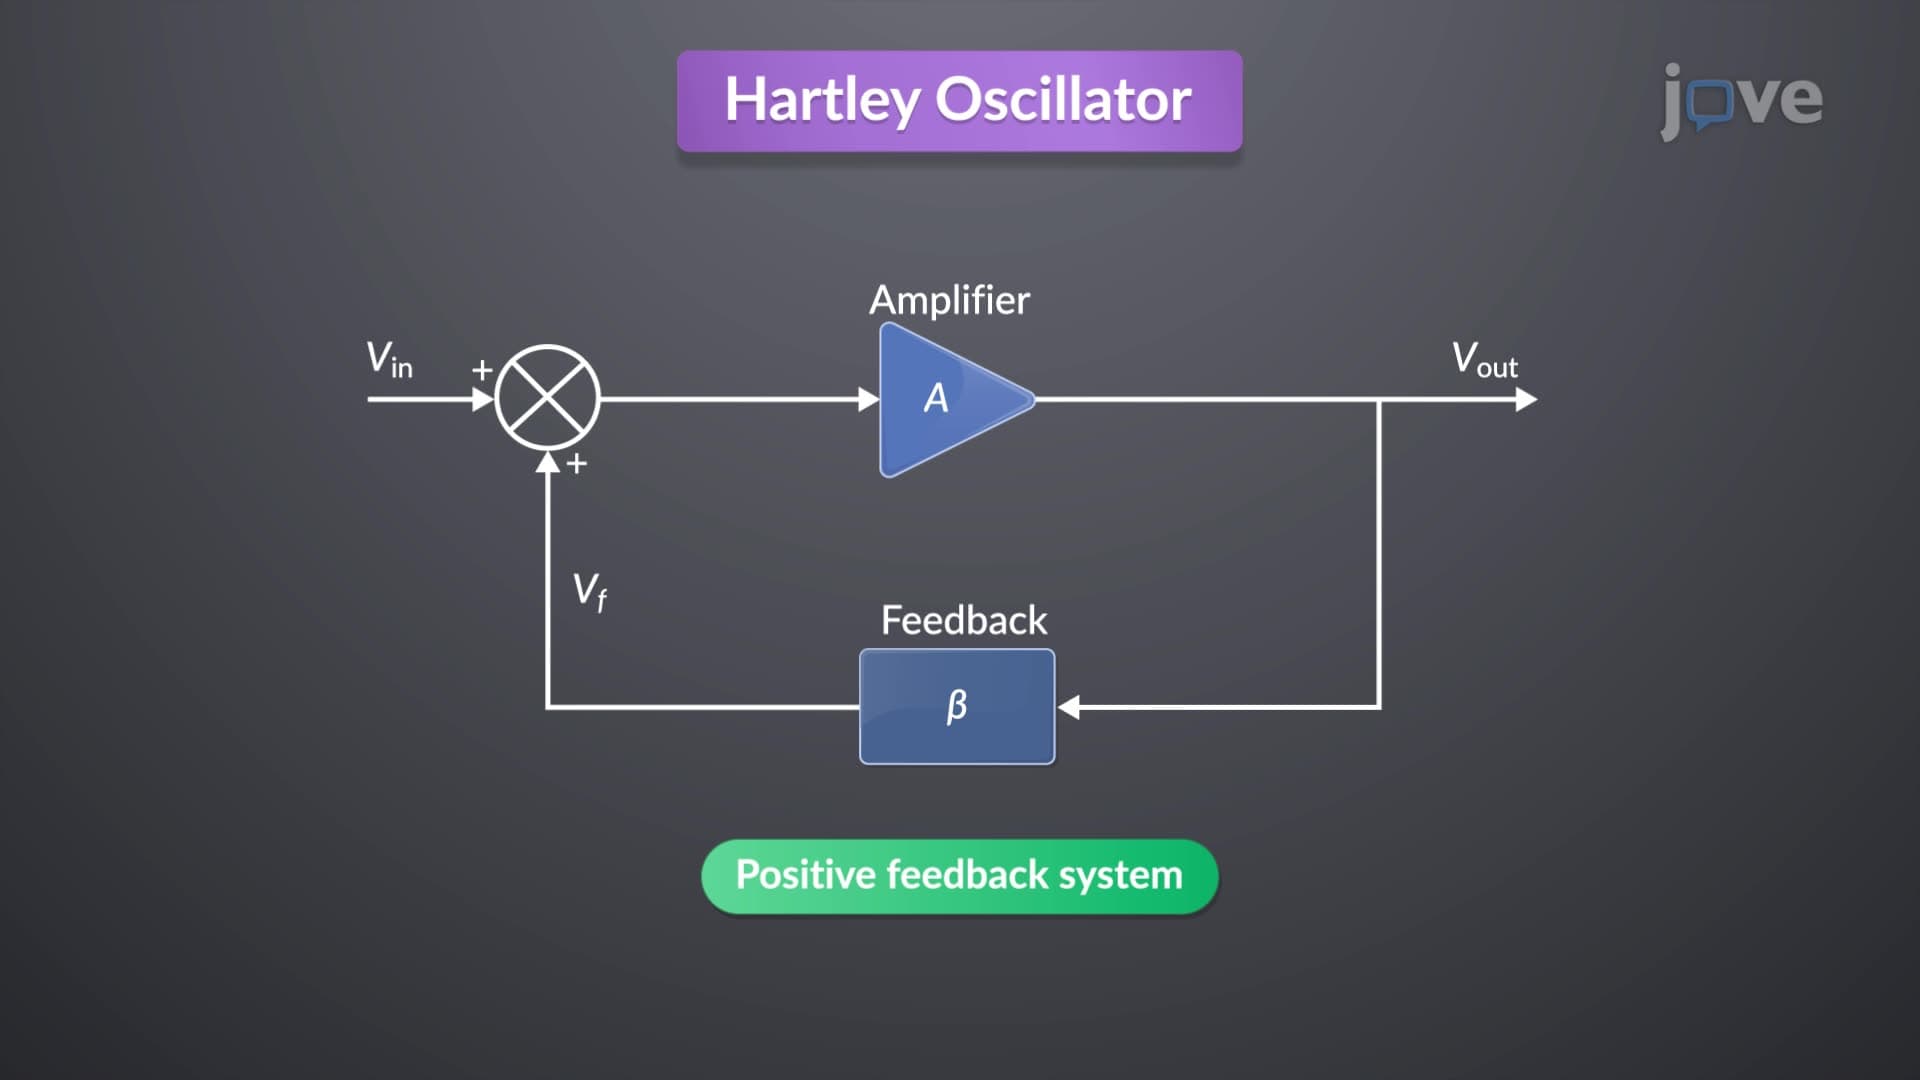
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:13
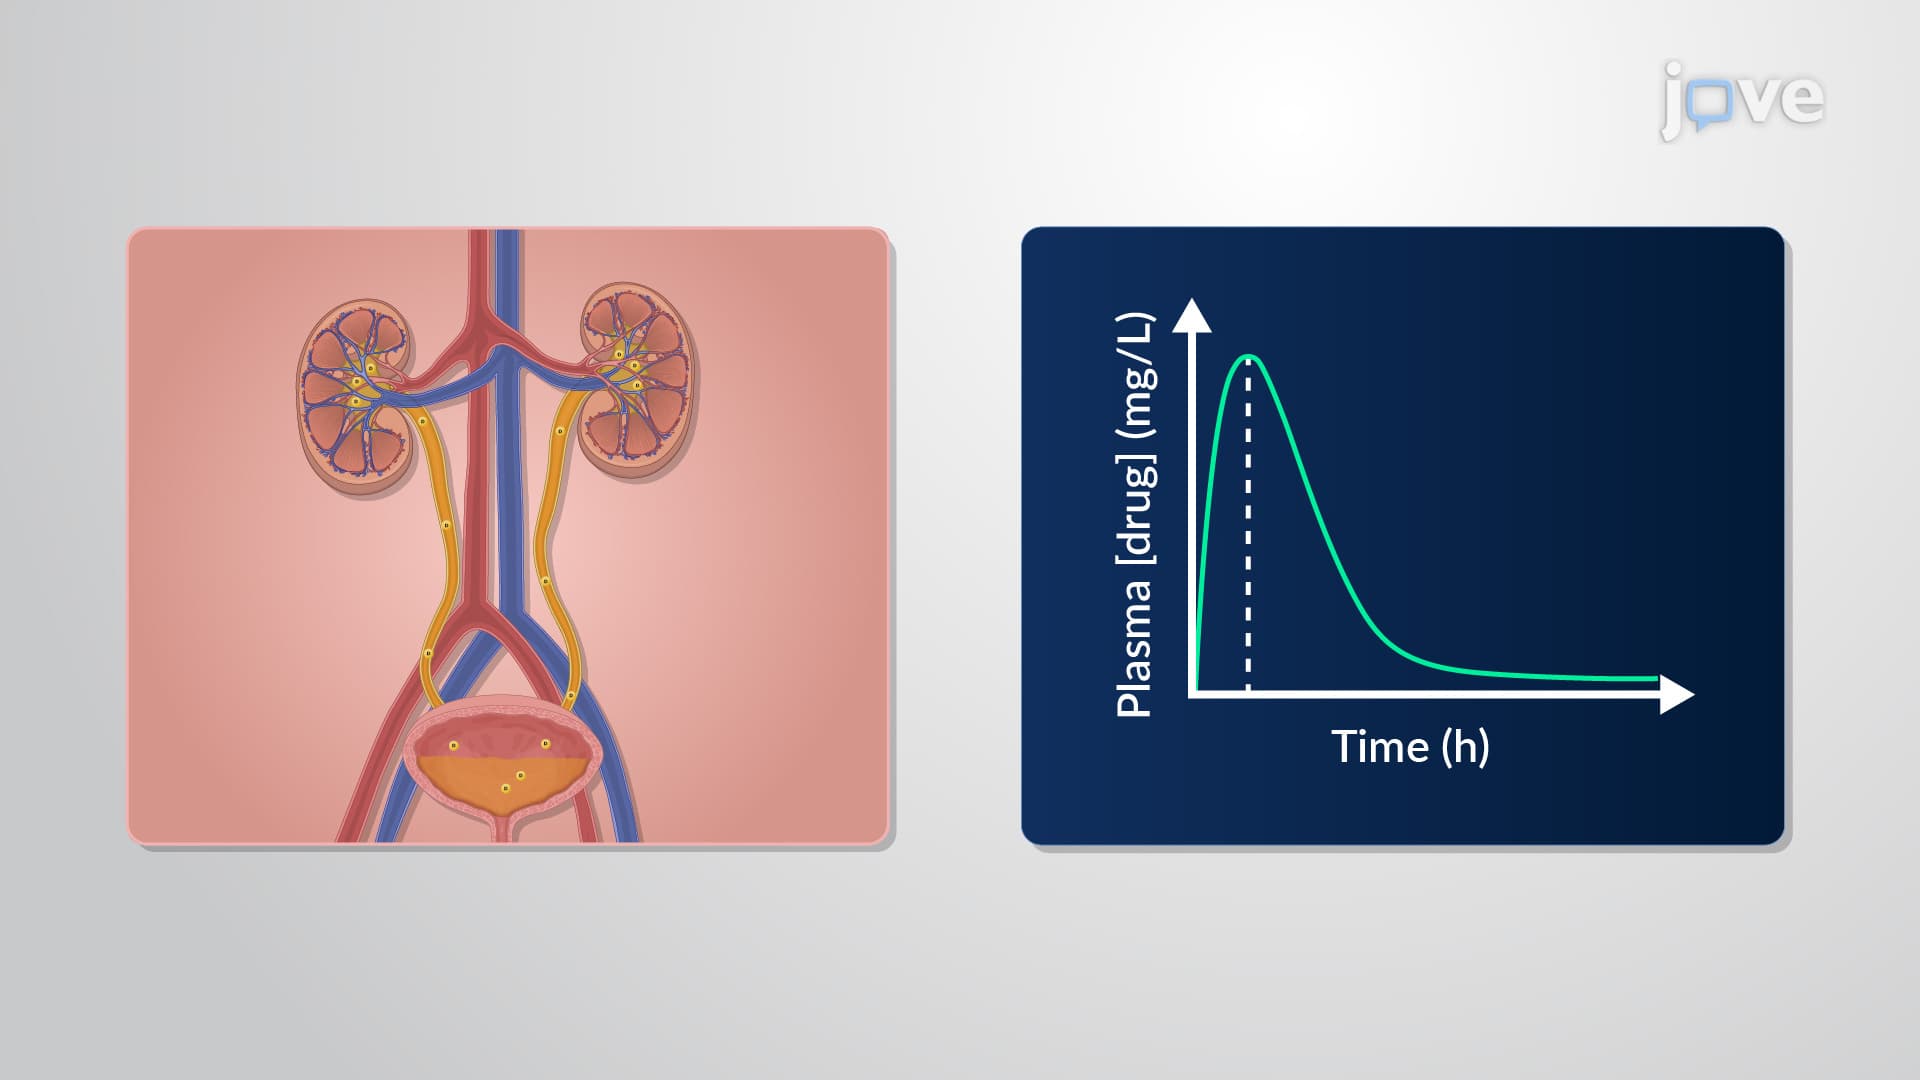
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...