Related Experiment Video
Updated: Aug 13, 2025
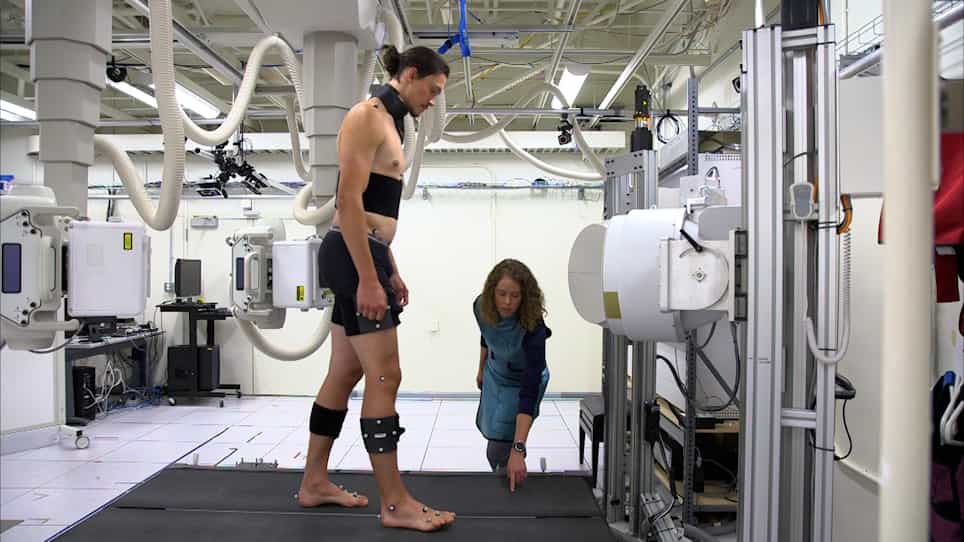

In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
Willow Catkin Optimization Algorithm Applied in the TDOA-FDOA Joint Location Problem
Jeng-Shyang Pan1,2, Si-Qi Zhang1, Shu-Chuan Chu1
1College of Computer Science and Engineering, Shandong University of Science and Technology, Qingdao 266590, China.

Abstract:
The heuristic optimization algorithm is a popular optimization method for solving optimization problems. A novel meta-heuristic algorithm was proposed in this paper, which is called the Willow Catkin Optimization (WCO) algorithm. It mainly consists of two processes: spreading seeds and aggregating seeds. In the first process, WCO tries to make the seeds explore the solution space to find the local optimal solutions. In the second process, it works to develop each optimal local solution and find the optimal global solution. In the experimental section, the performance of WCO is tested with 30 test functions from CEC 2017. WCO was applied in the Time Difference of Arrival and Frequency Difference of Arrival (TDOA-FDOA) co-localization problem of moving nodes in Wireless Sensor Networks (WSNs). Experimental results show the performance and applicability of the WCO algorithm.

Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:15
Kinematic Equations: Problem Solving