Related Experiment Video
Updated: Aug 3, 2026

Photopatterning Proteins and Cells in Aqueous Environment Using TiO2 Photocatalysis
Published on: October 26, 2015
Solitary and Collective Motion Behaviors of TiO2 Microrobots under the Coupling of Multiple Light Fields
Xinjian Fan1, Qihang Hu1, Xin Zhang1
1School of Mechanical and Electrical Engineering, Soochow University, No. 8, Jixue Road, Suzhou 215131, China.

Abstract:
Due to their fascinating solitary and collective behavior, photochemical microrobots have attracted extensive attention from researchers and have obtained a series of outstanding research progress in recent years. However, due to the limitation of using a single light source, the realization of reconfigurable and controllable motion behaviors of the photochemical microrobot is still facing a series of challenges. To release these restrictions, we reported a multi-light-field-coupling-based method for driving the photochemical microrobot or its swarm in a regulatable manner. Here, we first designed a control system for coupling multiple light sources to realize the programmable application of four light sources in different directions. Then a TiO2-based photochemical microrobot was prepared, with its surface electric field distribution under different lighting conditions estimated by modeling-based simulation, where the feasibility of regulating the microrobot's motion behavior via the proposed setup was verified. Furthermore, our experimental results show that under the action of the compound light fields, we can not only robustly control the motion behavior of a single TiO2 microrobot but also reconfigure its collective behaviors. For example, we realized the free switching of the single TiO2 microrobots' movement direction, and the controllable diffusion, aggregation, the locomotion and merging of TiO2 microrobot swarms. Our discovery would provide potential means to realize the leap-forward control and application of photochemical microrobots from individuals to swarms, as well as the creation of active materials and intelligent synthetic systems.
Related Concept Videos
 01:24
Microtubules in Cell Motility
 01:05
Mechanism of Ciliary Motion
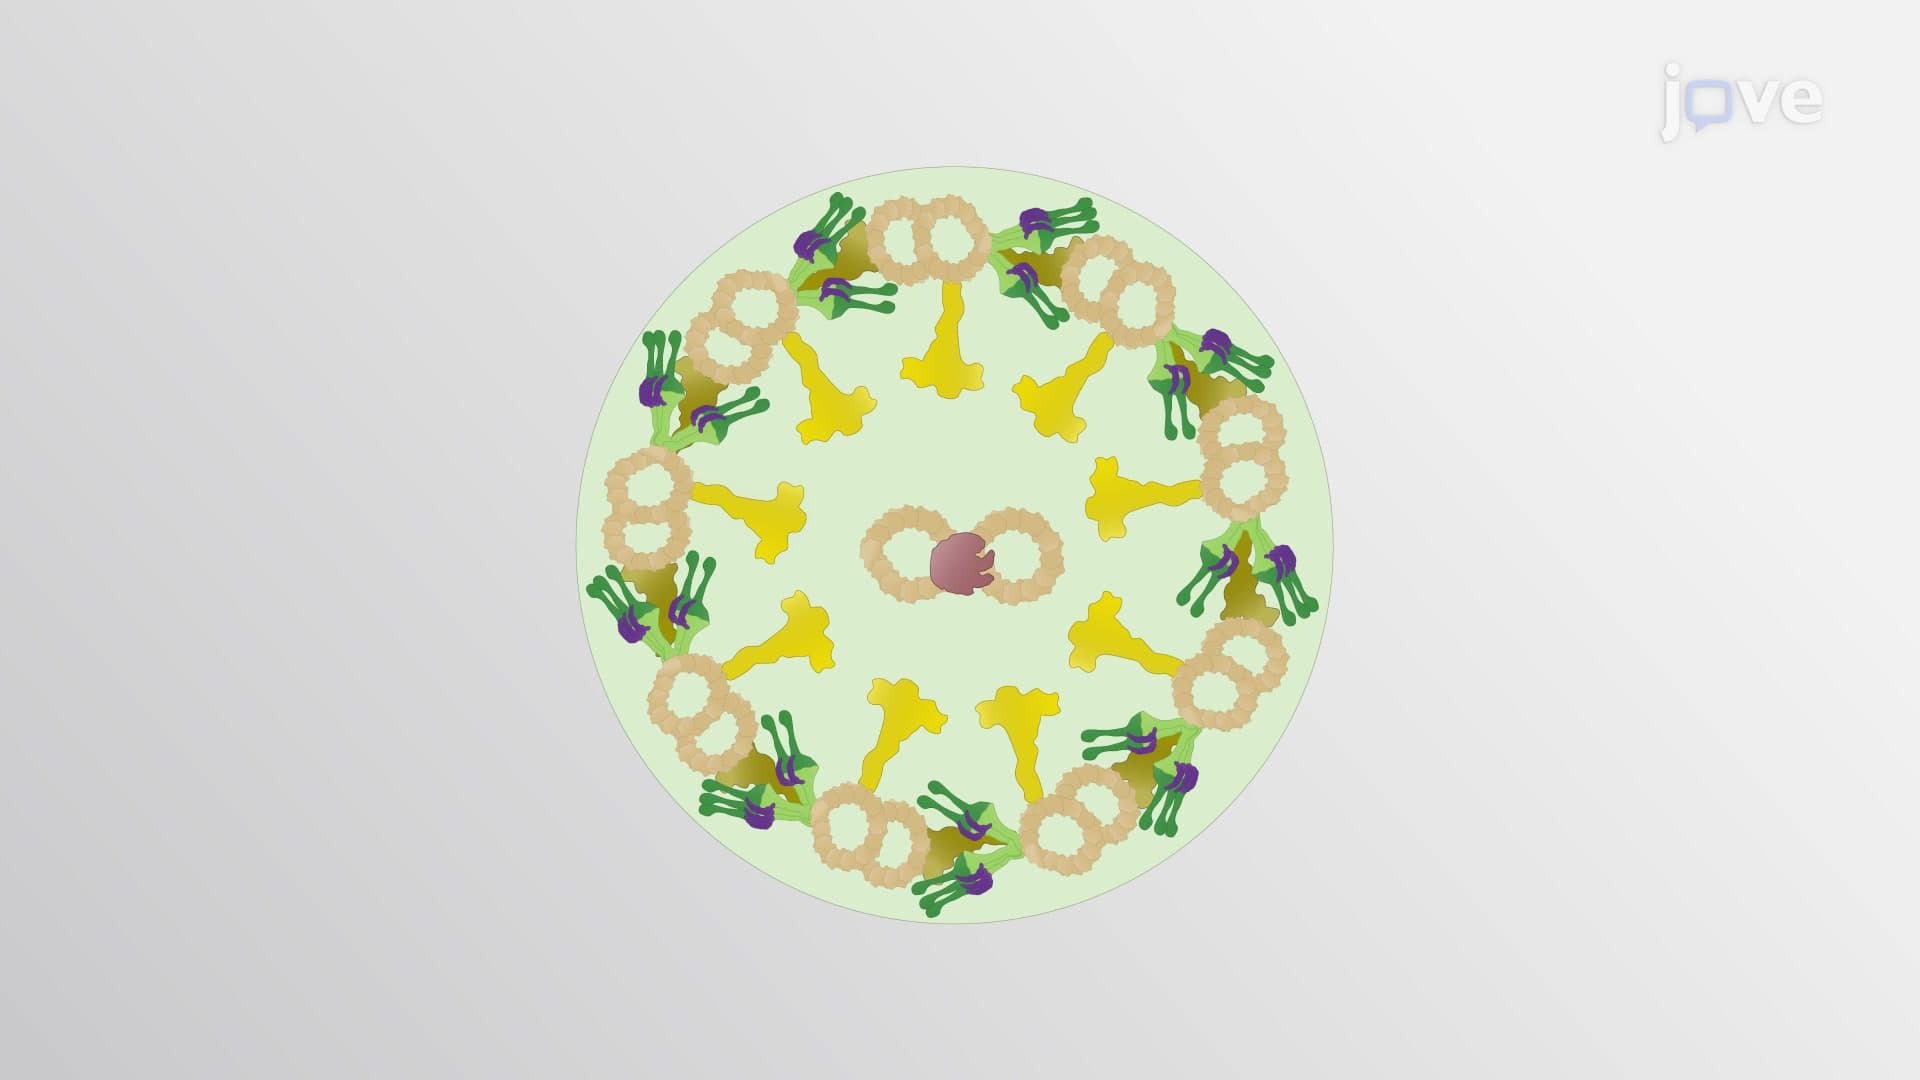
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
01:24Microtubules in Cell Motility
01:05Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...