Related Experiment Video
Updated: Aug 13, 2025
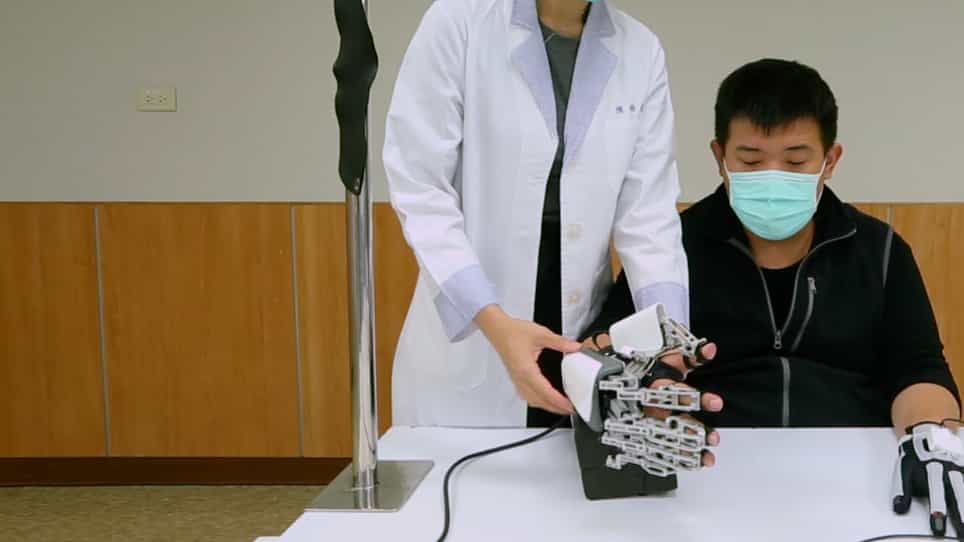
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Wrist autonomy based on upper-limb synergy: a pilot study
Chunhao Peng1, Dapeng Yang2,3, Zhe Ge1
1State Key Laboratory of Robotics and System, Harbin Institute of Technology, Harbin, 150080, China.

Abstract:
Incorporating an electrically powered wrist can largely improve the dexterity of a prosthetic hand when grasping various objects; however, it also intensifies the difficulty of the hand's operation due to the introduction of extra degrees of freedom (DOFs). The mechanism of multi-joint synergy in human body movements provides a new sight to solve this problem. In this paper, focusing on four typical manipulation activities of daily life (ADLs), 10 upper-limb joint angles were collected and analyzed first to verify the existence of synergy. Then, a linear regression model was established to predict the wrist rotation angle from the shoulder and elbow joints, which can be directly used as a control reference for achieving wrist autonomy. For both healthy and amputee subjects, experimental platforms were established and control tests were conducted, wherein the task completion time and compensatory movement during the four ADLs were evaluated. The results show that our synergy-based wrist autonomy method can effectively improve the completion efficiency of multiple ADLs without increasing the control complexity. Also, it can significantly reduce the compensatory movements of multiple joints compared to traditional prostheses using an idle wrist.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 05:28
Author Spotlight: Enhancing Upper Limb Rehabilitation in Stroke Patients Through Advanced Robotic and Neuromodulation Technologies
Published on: October 11, 2024