Related Experiment Video
Updated: Oct 27, 2026
Viscoelastic Characterization of Soft Tissue-Mimicking Gelatin Phantoms using Indentation and Magnetic Resonance Elastography
Published on: May 10, 2022
Force-Vision Multimodal Measurement of Model-Equivalent Elastic Parameters for Soft Tissue Modeling
Le Zhang1, Yi Liu1, Ziyu Liang1
1State Key Laboratory of Robotics and Systems, Harbin Institute of Technology, Harbin 150080, China.

Abstract:
In robotic manipulation, robot-assisted surgery, and other contact-rich interactions with deformable bodies, reliable prediction of contact force and deformation requires rapid determination of the effective mechanical parameters governing the soft-tissue model. However, these model-equivalent properties are difficult to obtain directly from physical interaction, particularly for human soft tissue with substantial variability in geometry and mechanical response. This work presents a force-vision multimodal framework for rapidly identifying effective elastic and contact-model parameters from measured force and deformation. The human breast is selected as a representative validation object because of its high compliance, pronounced geometric variability, and sensitivity of its deformation response to mechanical properties and contact conditions. A six-axis force/torque sensor and an eye-in-hand RGB-D camera provide time-synchronized measurements of three-dimensional contact force and surface-marker displacement. A finite-element contact model maps the probe pose and a parameter vector to the measured responses, while a multiobjective Bayesian optimization procedure identifies the parameter set under a limited simulation budget. Experiments using three breast-tissue-mimicking phantoms with different geometries and stiffnesses yield normalized force and displacement residuals of 4.93%-6.00% and 7.18%-12.33%, respectively, within 55 model evaluations. Force and displacement provide complementary constraints, and the Bayesian solver achieves residuals comparable to particle swarm optimization with a 5.5-fold reduction in the number of finite-element evaluations. Held-out indentation and controlled posture-change tests further support the predictive consistency of the identified model-equivalent parameters within the experimental protocol. The proposed framework provides an approach for rapid parameter identification of deformable-tissue contact models, with potential to support more consistent reproduction of contact force and deformation in soft-tissue simulation and future sim2real robotic manipulation with force-vision feedback.
Related Concept Videos
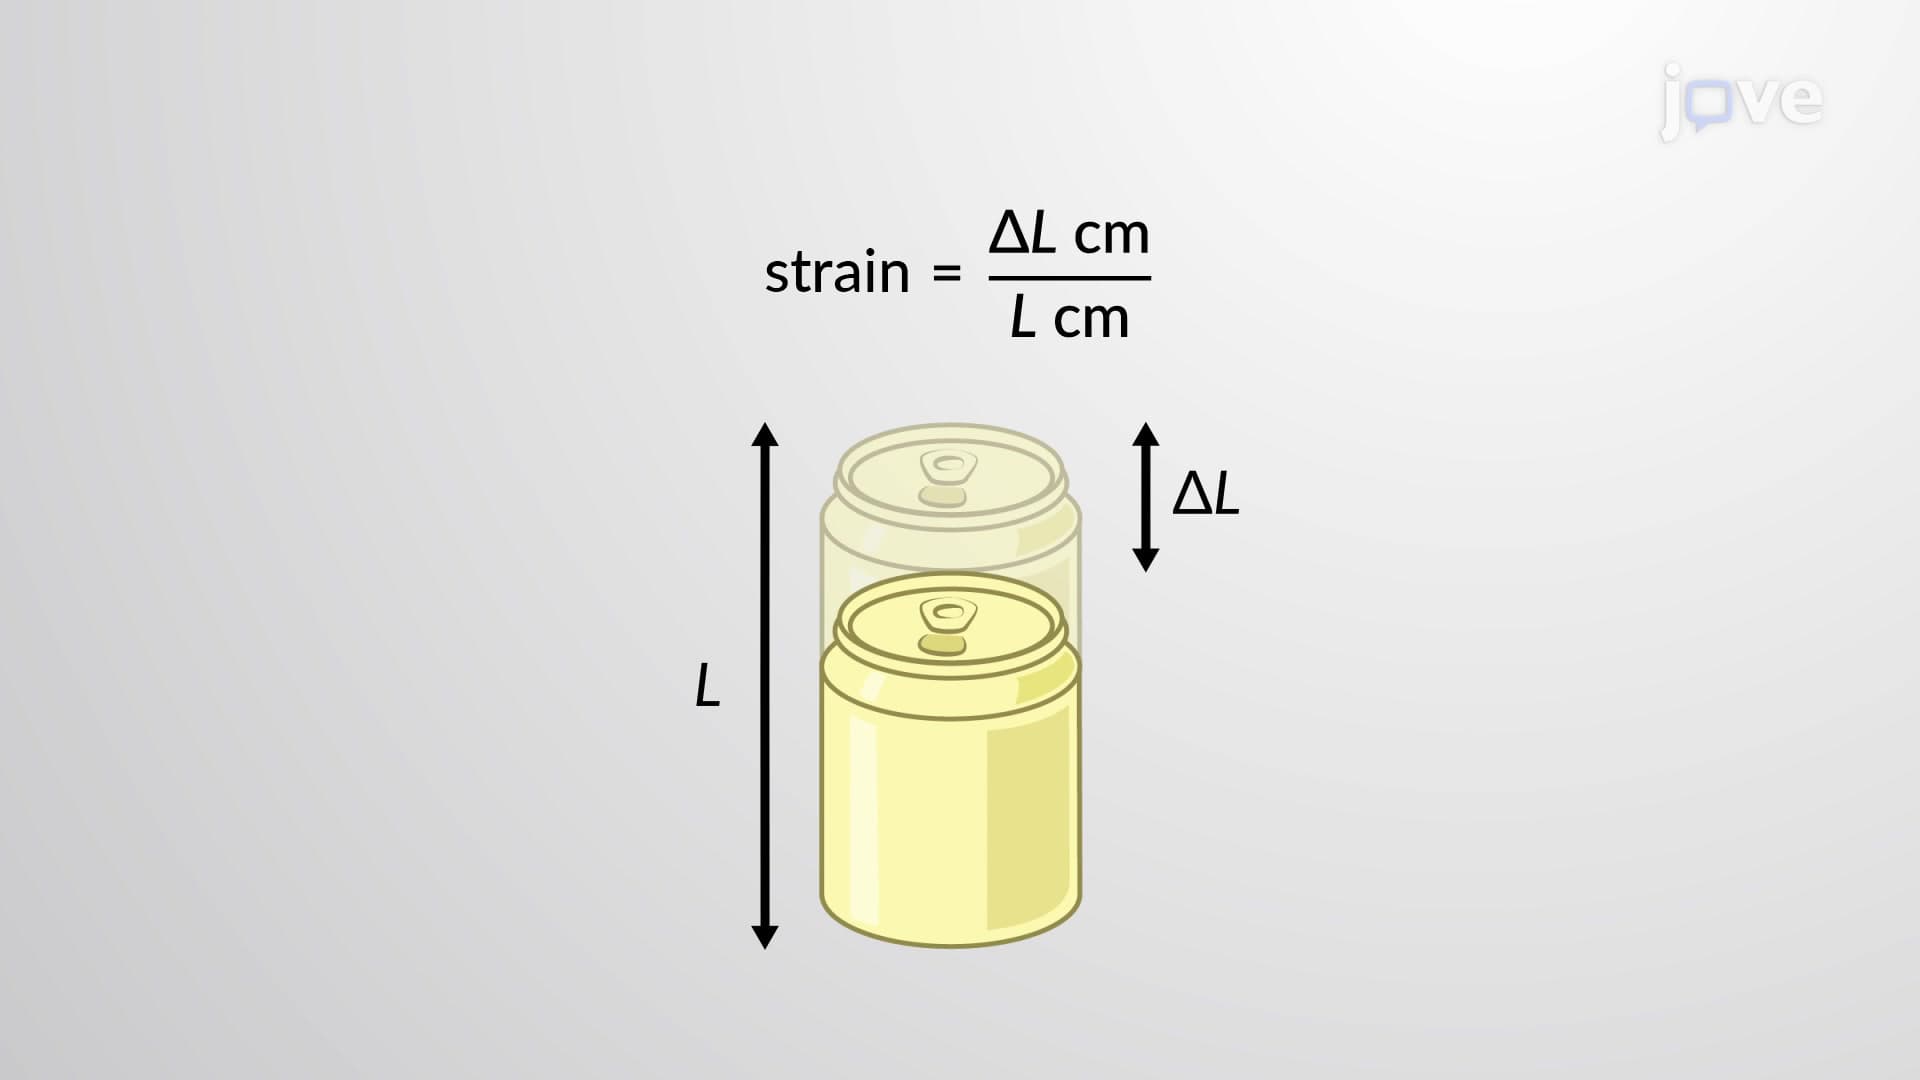 01:15
Strain and Elastic Modulus
 01:15
Relation between Poisson's ratio, Modulus of Elasticity and Modulus of Rigidity