Related Experiment Video
Updated: Aug 10, 2025
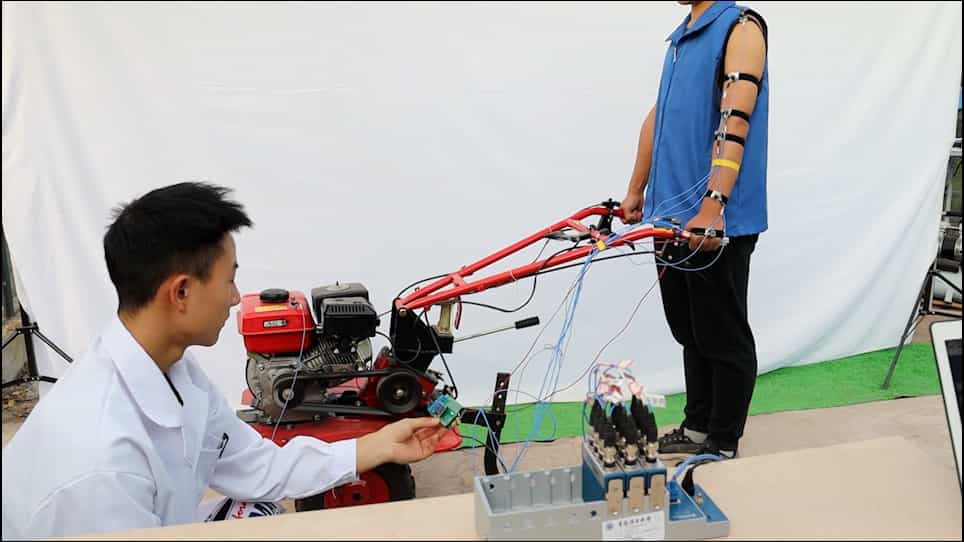
Measurement of the Hand Transmitted Vibration of the Human Hand Arm System During Operation of a Hand Tractor
Published on: June 16, 2021
Vibration Measurements on a Six-Axis Collaborative Robotic Arm-Part I
Vit Cernohlavek1, Frantisek Klimenda1, Pavel Houska1
1Faculty of Mechanical Engineering, University of Jan Evangelista Purkyne in Ustí nad Labem, Pasteurova 1, 40096 Ustí nad Labem, Czech Republic.

Abstract:
This article deals with the design of a methodology for vibration and noise measurement on a six-axis collaborative robotic arm. A vibration and noise measurement methodology is proposed for six robot positions. In each position, measurements were performed under defined equal boundary conditions. The boundary conditions were related to the velocities of the joints and the load on the robotic arm. The second part of the article is an evaluation of the initial experimental results. So far, only the acceleration of the sixth joint of the robotic arm-Wrist 3-has been measured. The aim of the measurements was to verify if the methodology presented can be used for vibration measurements. From the evaluation of the experimental measurements, it was determined that the given methodology can be used for vibration measurements. It was also found that the acceleration is transmitted in the axes other than the axis of motion of the robotic arm. In future experiments, the vibration at the other joints of the robotic arm will be measured and the noise of the robotic arm will be measured to confirm whether the proposed methodology is indeed functional.
More Related Videos

Related Concept Videos
 01:09
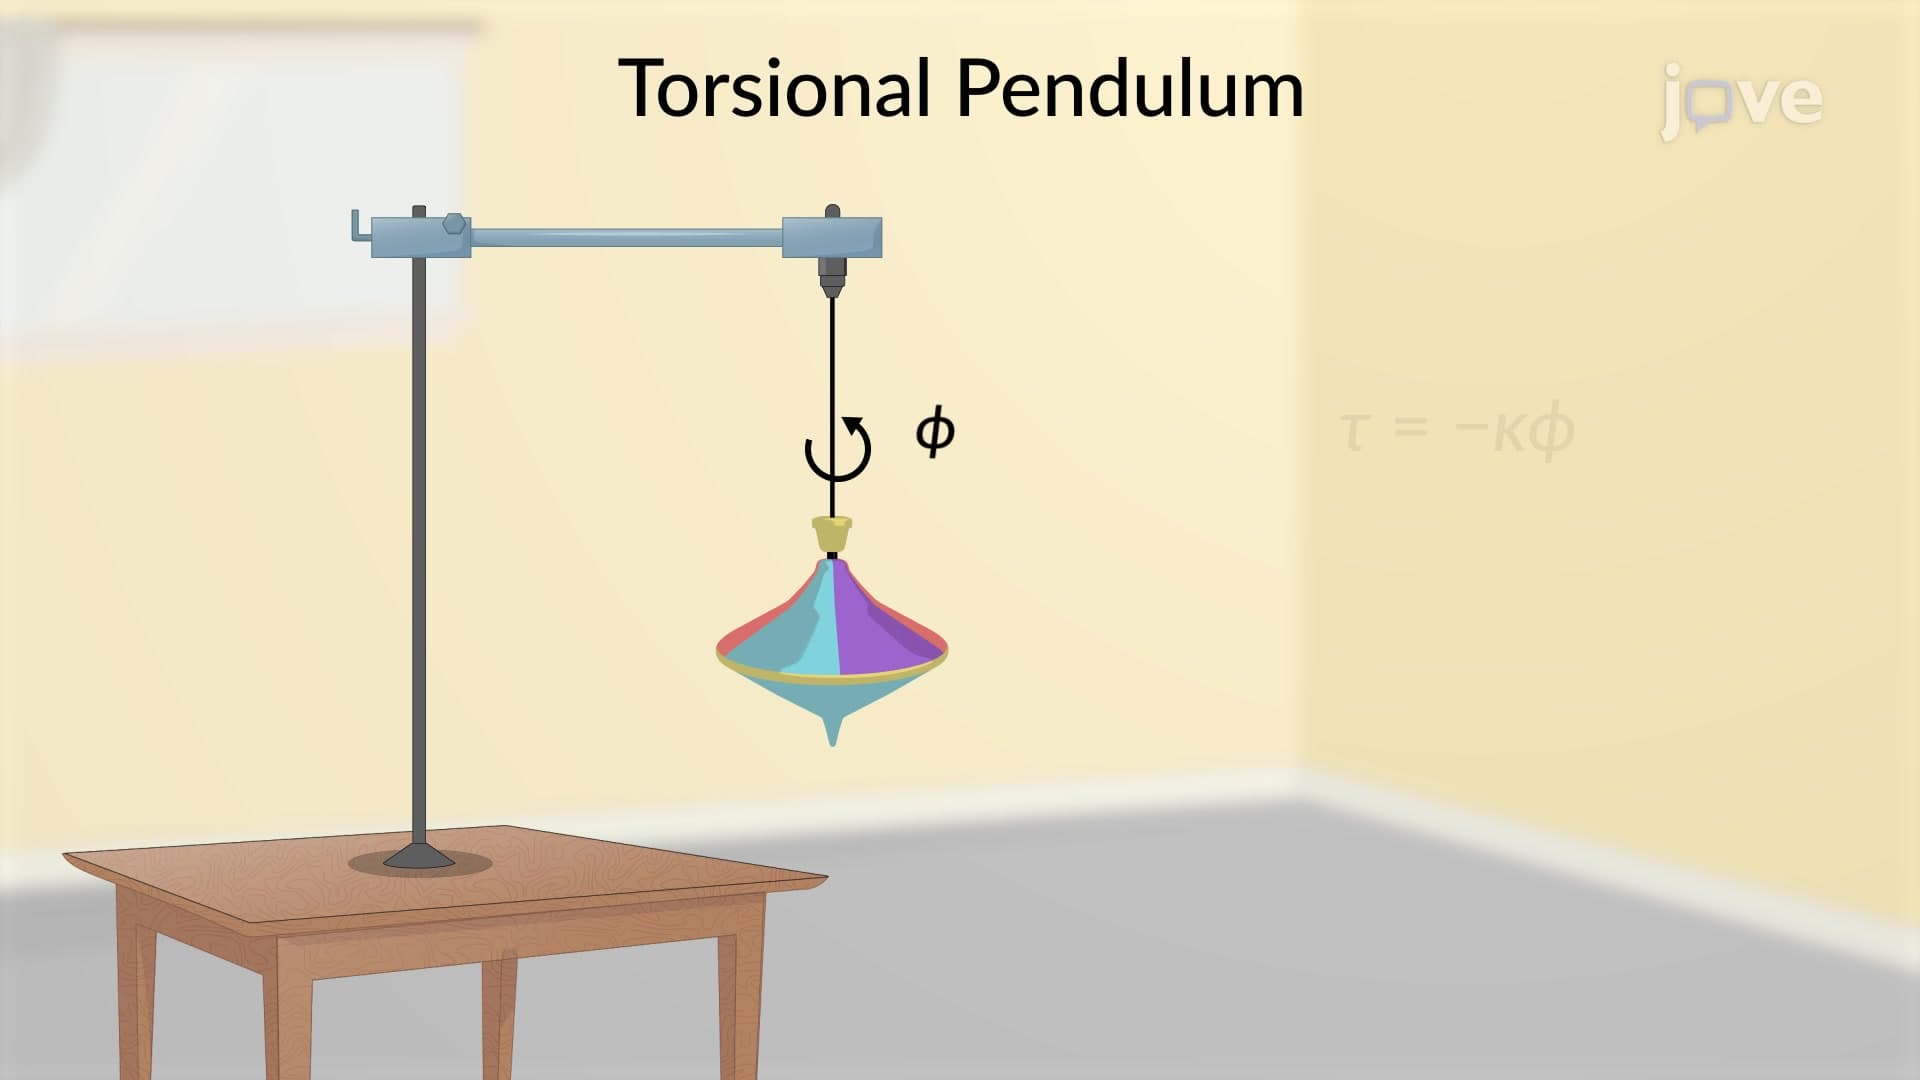
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:30
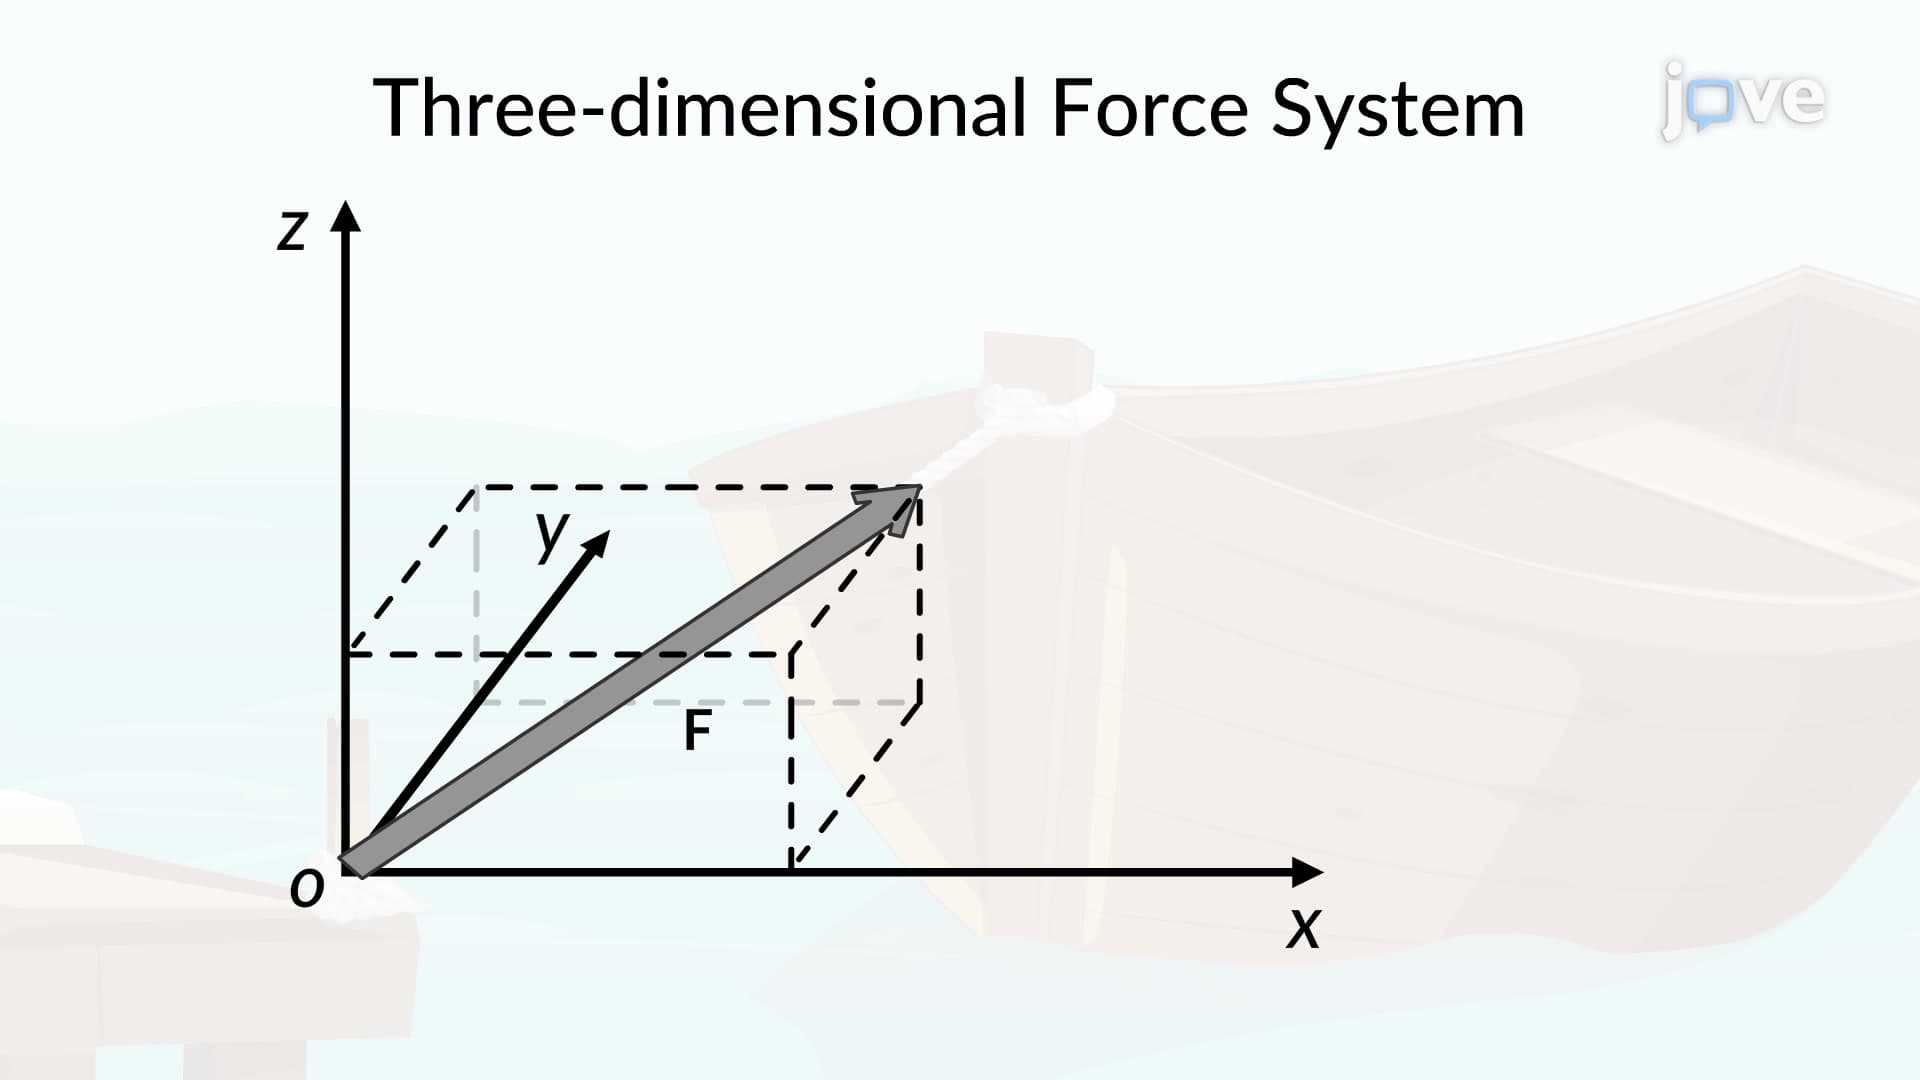
Three-Dimensional Force System
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:22
Mechanical Systems
 01:15
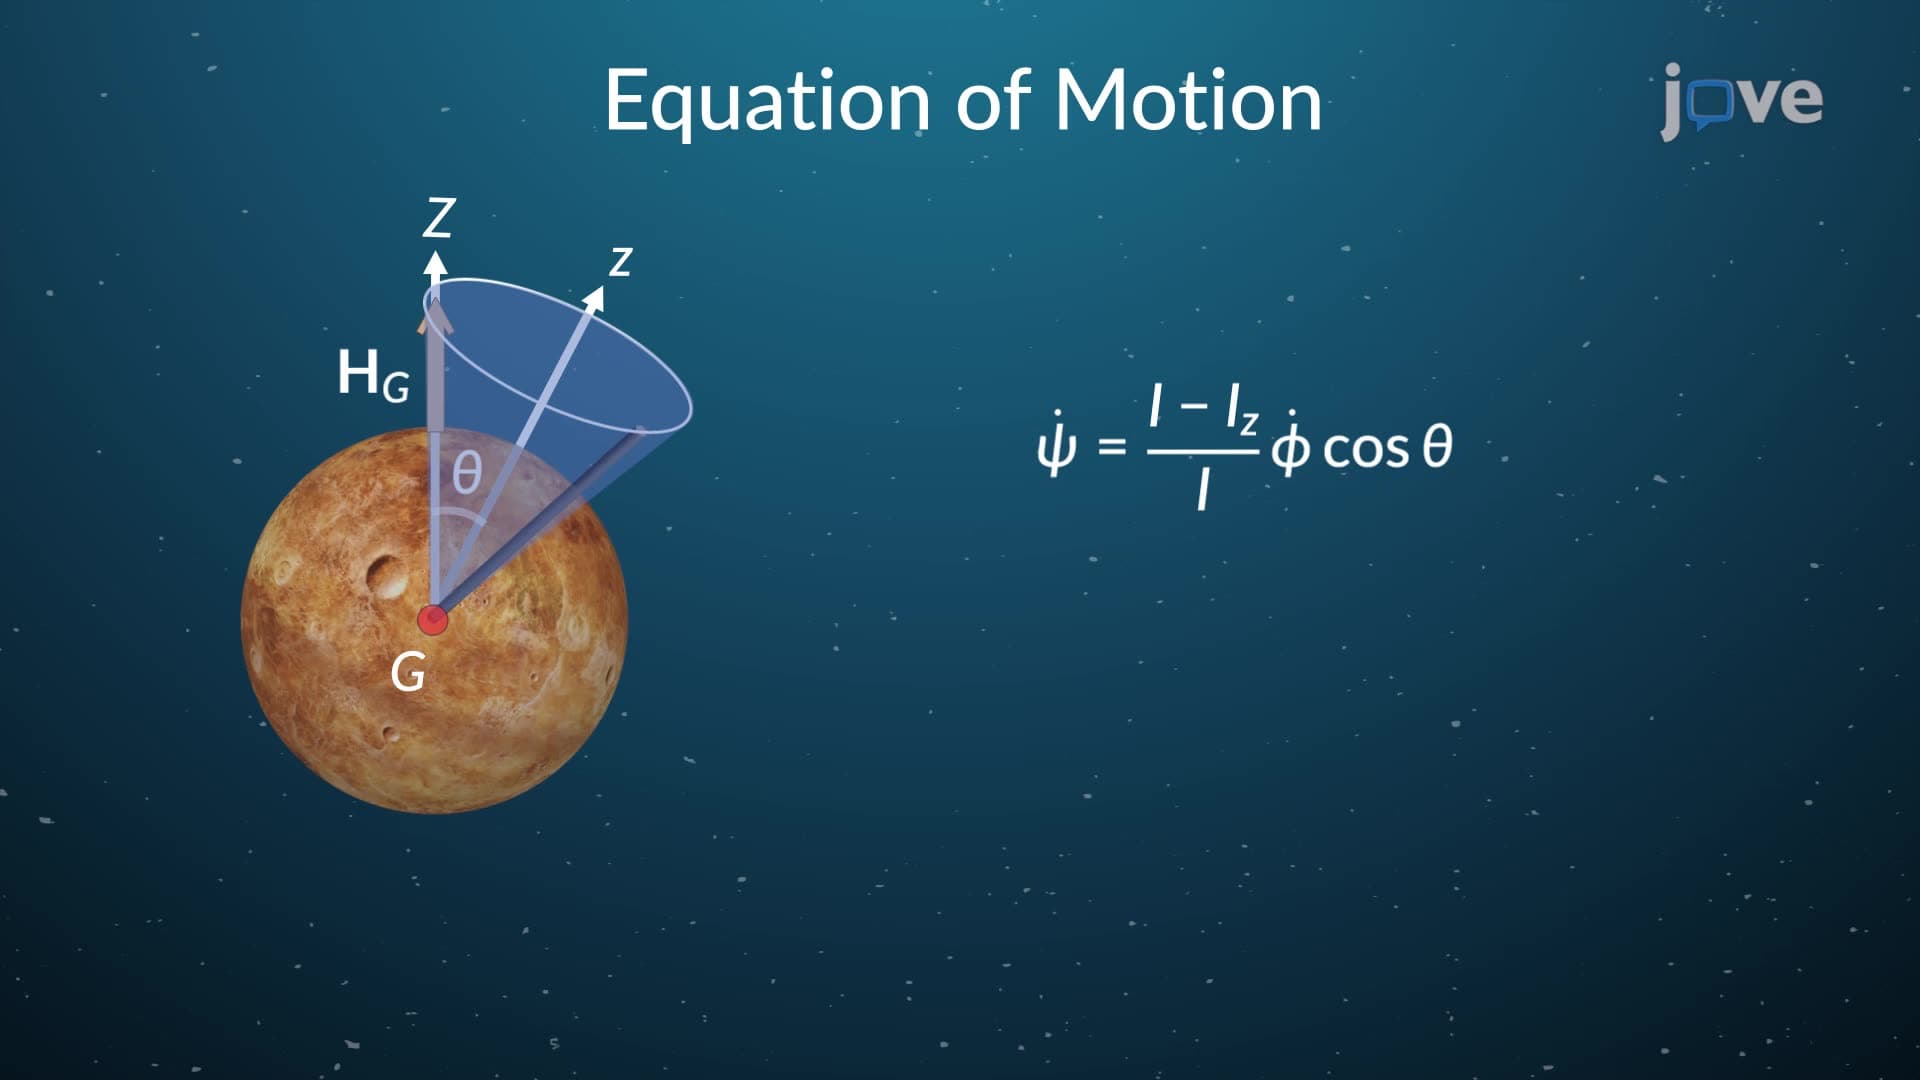
Torque Free Motion