Related Experiment Video
Updated: Aug 9, 2025

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
A Recognition Method for Soft Objects Based on the Fusion of Vision and Haptics
Teng Sun1, Zhe Zhang1, Zhonghua Miao1
1Intelligent Equipment and Robotics Lab, Department of Automation, School of Mechatronic Engineering and Automation, Shanghai University, Shangda Street No. 99, Baoshan District, Shanghai 200444, China.

Abstract:
For humans and animals to recognise an object, the integration of multiple sensing methods is essential when one sensing modality is only able to acquire limited information. Among the many sensing modalities, vision has been intensively studied and proven to have superior performance for many problems. Nevertheless, there are many problems which are difficult to solve by solitary vision, such as in a dark environment or for objects with a similar outlook but different inclusions. Haptic sensing is another commonly used means of perception, which can provide local contact information and physical features that are difficult to obtain by vision. Therefore, the fusion of vision and touch is beneficial to improve the robustness of object perception. To address this, an end-to-end visual-haptic fusion perceptual method has been proposed. In particular, the YOLO deep network is used to extract vision features, while haptic explorations are used to extract haptic features. Then, visual and haptic features are aggregated using a graph convolutional network, and the object is recognised based on a multi-layer perceptron. Experimental results show that the proposed method excels in distinguishing soft objects that have similar appearance but varied interior fillers, comparing a simple convolutional network and a Bayesian filter. The resultant average recognition accuracy was improved to 0.95 from vision only (mAP is 0.502). Moreover, the extracted physical features could be further used for manipulation tasks targeting soft objects.
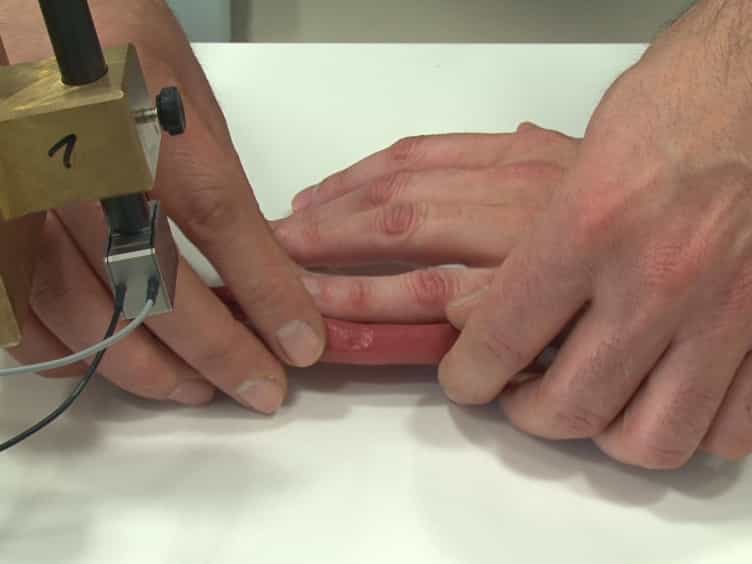
Related Concept Videos
 01:27
Tactile and Chemical Senses
 01:21
Association Areas of the Cortex
Prefrontal Association Area: This area is located in the frontal lobe and is involved in planning, decision-making, and moderating social behavior. It connects with primary motor areas,...
 01:33
Somatosensation
 01:24
Vision
 01:11
Sensory Perception: Organization of the Somatosensory System
The receptor level:
The receptor level is the first stage of sensation. It involves the detection of a stimulus by specialized sensory receptors. The stimulus must arrive within the receptor's receptive field. Next, the receptor converts the energy of the...
 01:26
Introduction to Special Senses