Related Experiment Video
Updated: Aug 8, 2025

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
A Control Method Based on a Simple Dynamic Optimizer: An Application to Micromachines with Friction
1Department of Mathematics, ESEIAAT-Universitat Politècnica de Catalunya, 08222 Terrassa, Spain.

Abstract:
In Micromachines, like any mechanical system, friction compensation is an important topic for control design application. In real applications, a nonlinear control scheme has proven to be an efficient method to mitigate the effects of friction. Therefore, a new regulation control method based on a simple dynamic optimizer is proposed. The used optimizer has a finite-time convergence to the optimal value of a given performance index. This dynamic process is then modified to produce a new control scheme to resolve the regulation control statement. A stability test is also provided along with numerical simulations to support our approach. We used the Lyapunov theory to confirm the stability, in finite-time, of the obtained closed-loop system. Furthermore, we tested this controller in a scenario where the reference signal was a time-varying function applied to a micromachine with friction. Numerical experiments showed acceptable performance in mitigating the effects of friction in the mechanism. In the simulations, the well-known LuGre friction model was invoked.
More Related Videos

Related Concept Videos
 01:14
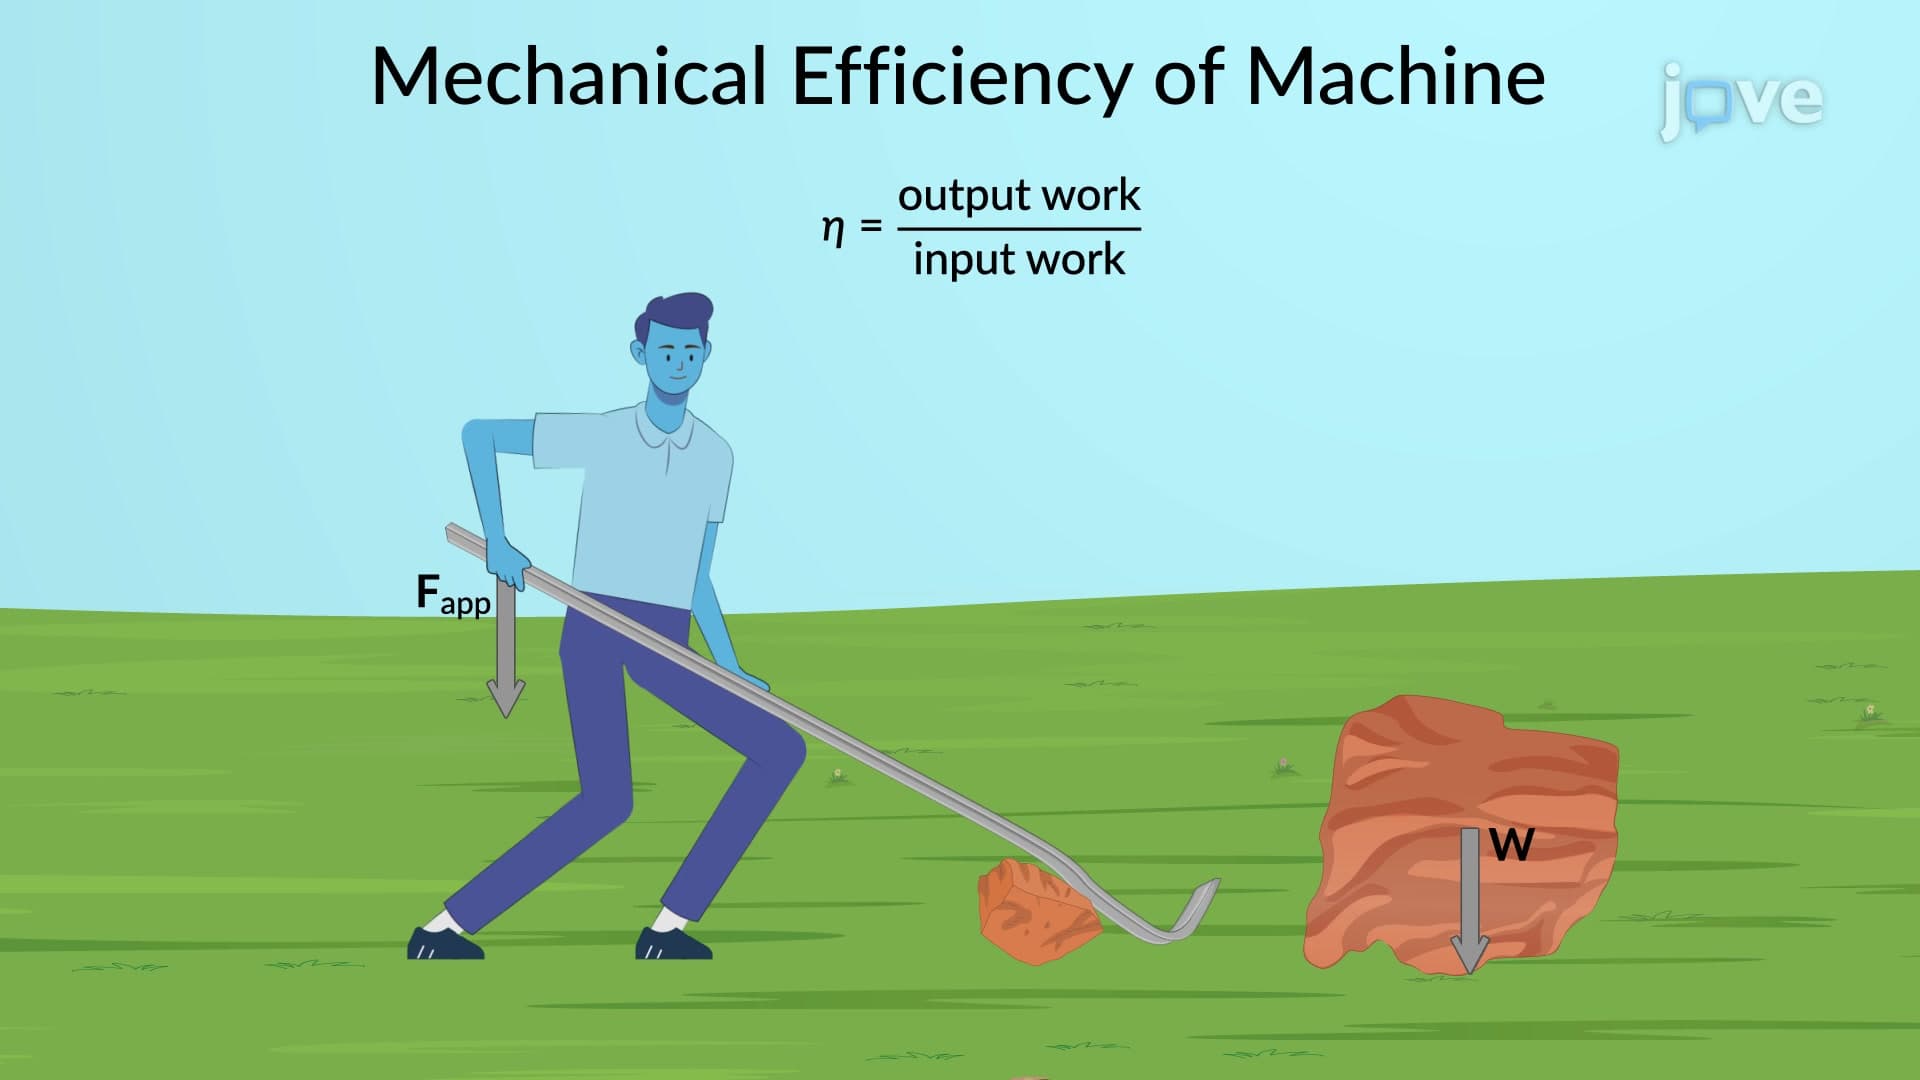
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:05
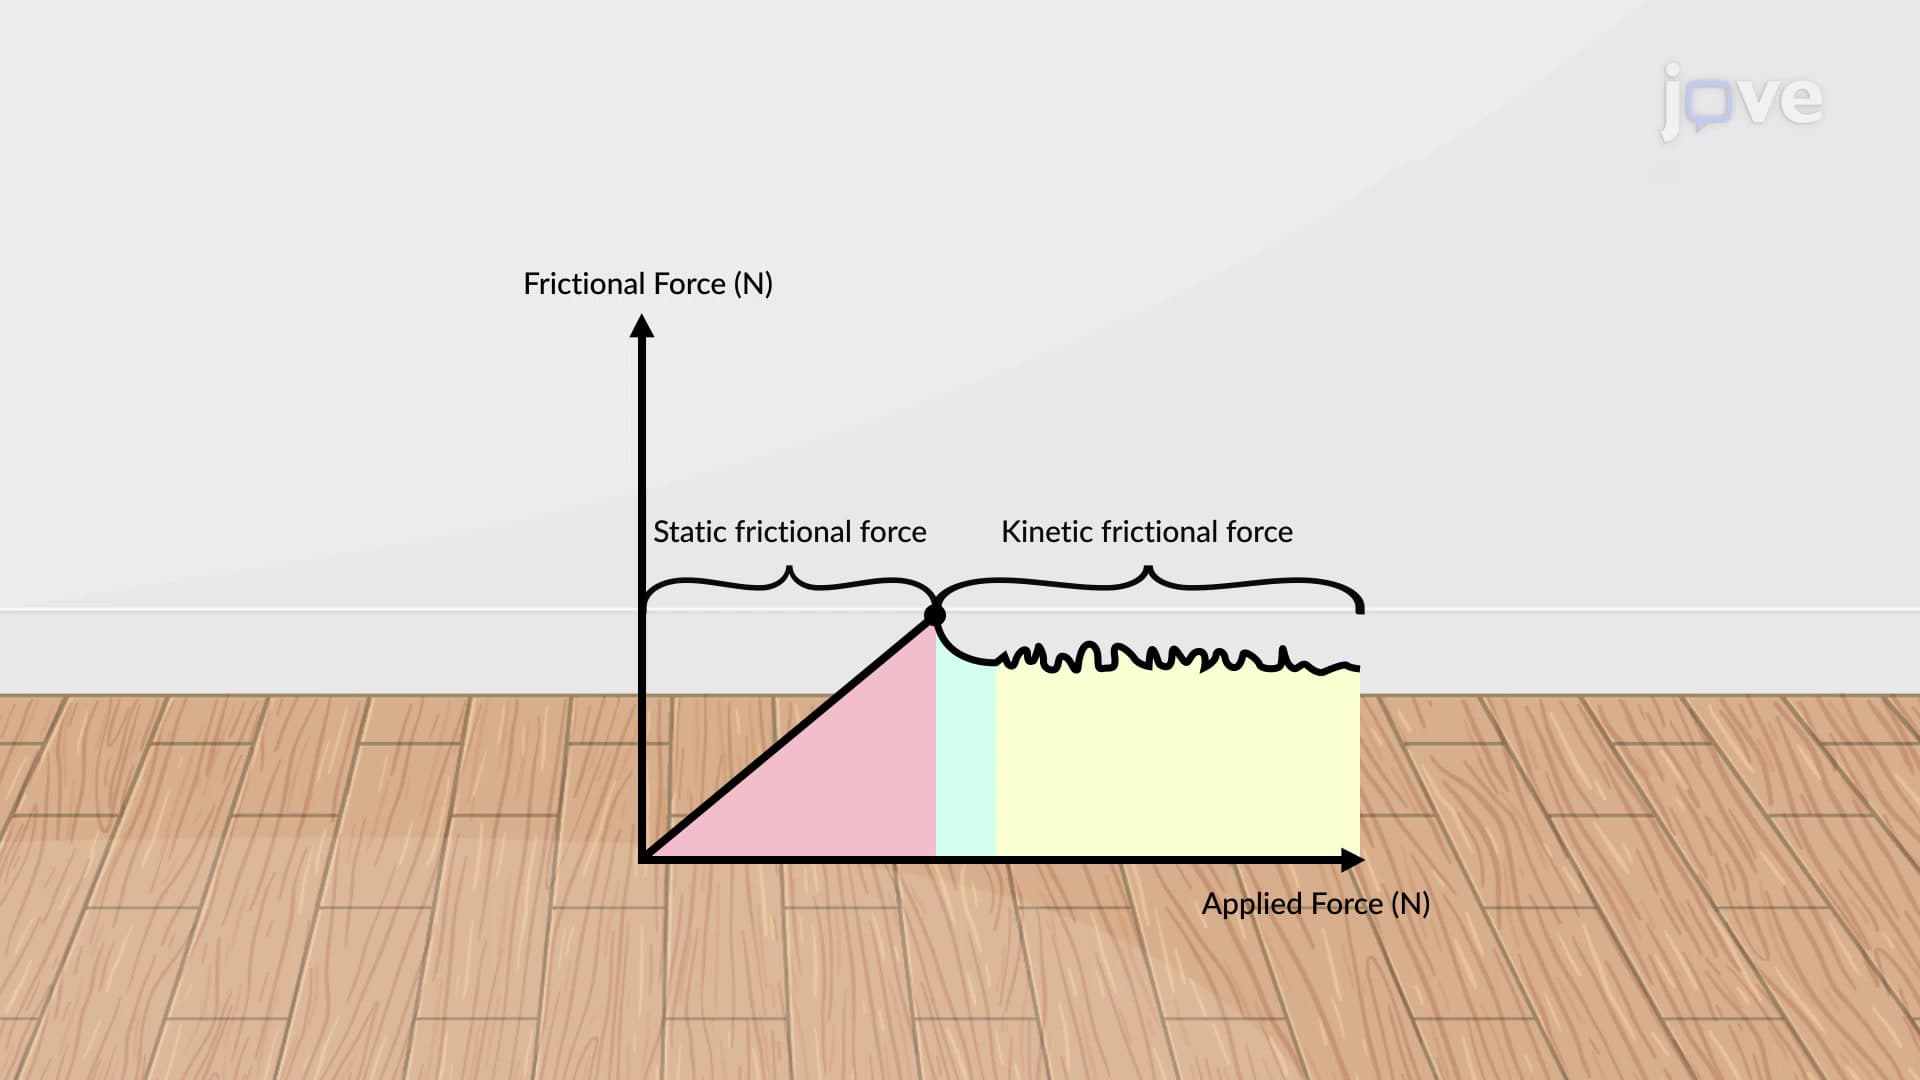
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion....
 01:17
Rolling Resistance: Problem Solving
 01:26
Kinetic Friction
 01:24
Bearings: Problem Solving