Related Experiment Video
Updated: Aug 7, 2025

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Research on Two-Round Self-Balancing Robot SLAM Based on the Gmapping Algorithm
Jianwei Zhao1, Jinyu Li1, Jiaxin Zhou1
1School of Mechanical Electronic & Information Engineering, China University of Mining and Technology, Beijing 100083, China.

Abstract:
Aiming at the inconvenience of inspection and monitoring of coal mine pump room equipment in a narrow and complex environment, this paper proposes and designs a two-wheel self-balancing inspection robot based on laser SLAM. Using SolidWorks, the three-dimensional mechanical structure of the robot is designed, and the overall structure of the robot is analyzed by finite element statics. The kinematics model of the two-wheel self-balancing robot was established, and the multi-closed-loop PID controller was used to design the two-wheel self-balancing control algorithm of the robot. The 2D LiDAR-based Gmapping algorithm was used to locate the robot and construct the map. Through the self-balancing test and anti-jamming test, it is verified that the self-balancing algorithm designed in this paper has a certain anti-jamming ability and good robustness. By using Gazebo to build a simulation comparison experiment, it is verified that the selection of the particle number is of great significance for improving the map accuracy. The actual test results show that the constructed map has high accuracy.


Related Concept Videos
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:16
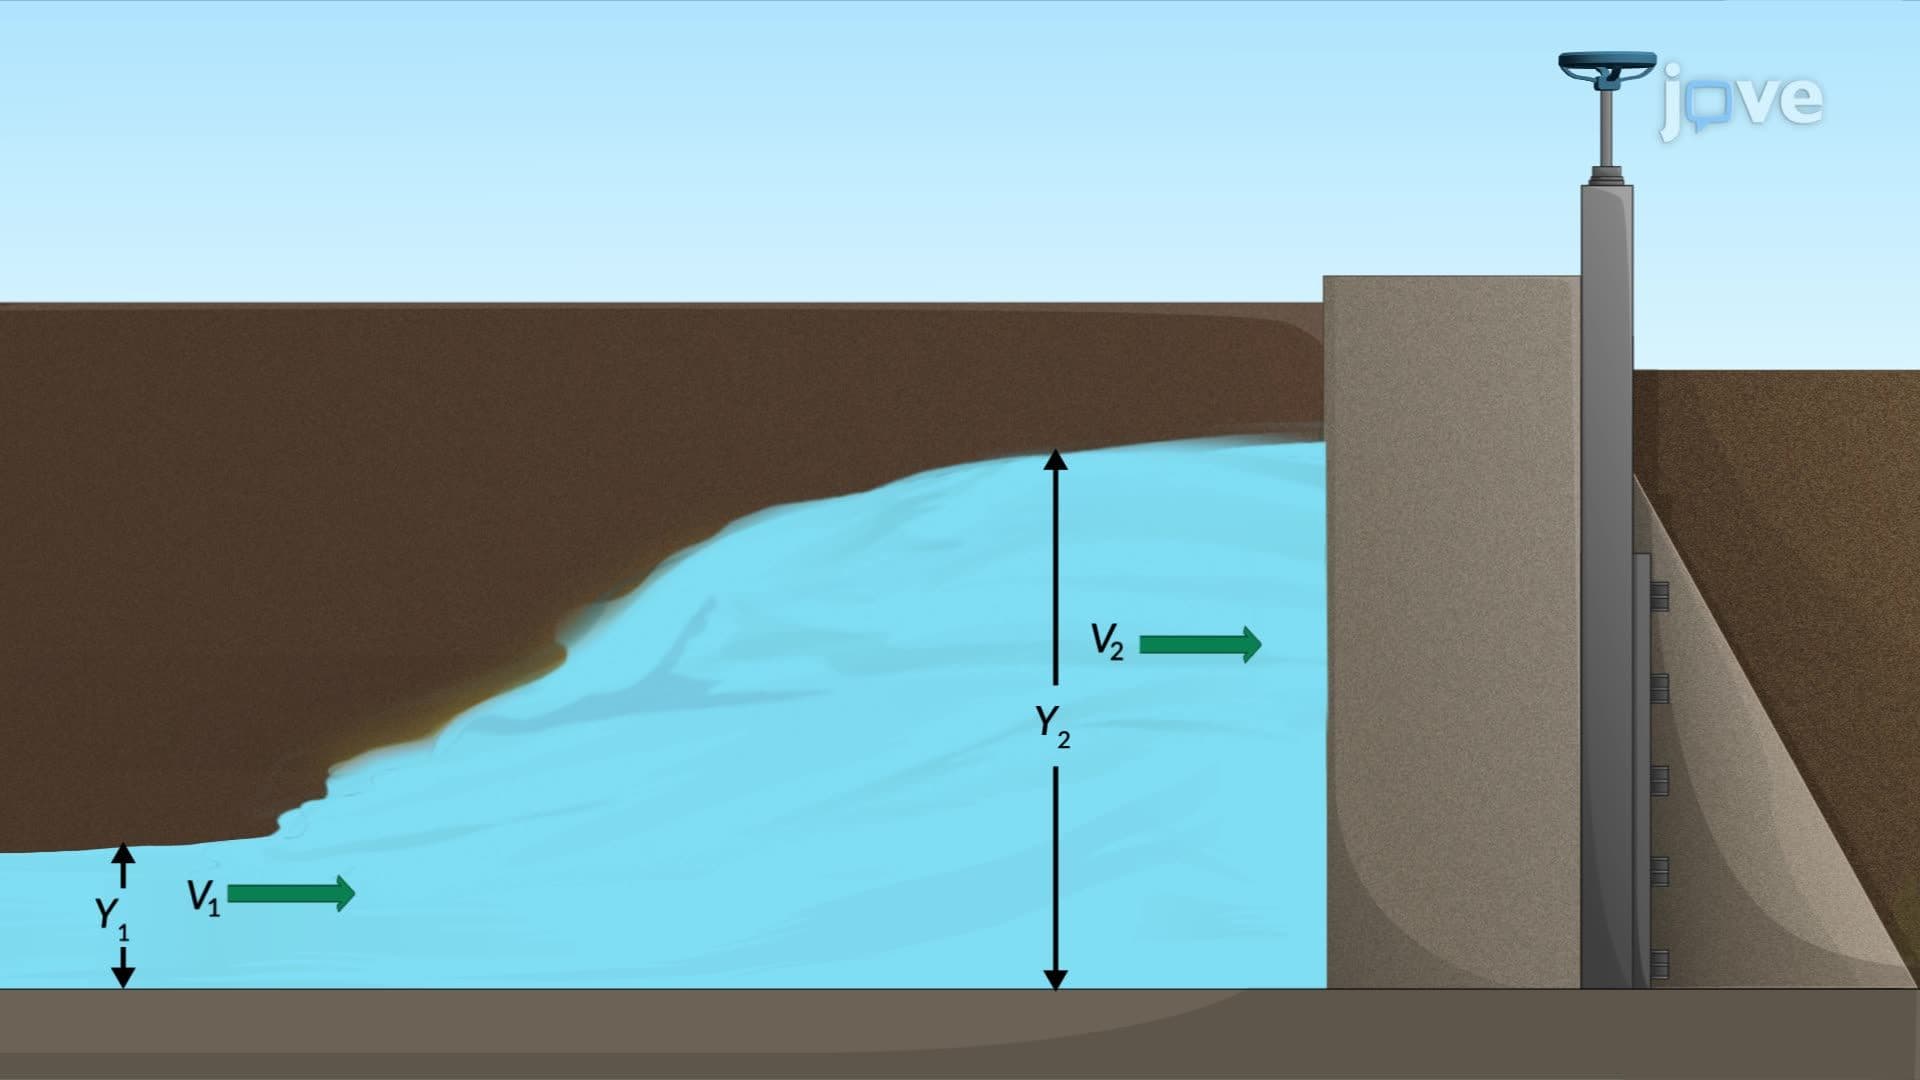
Hydraulic Jump: Problem Solving
 01:17
Rolling Resistance: Problem Solving
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...