

Sensorless force and displacement estimation in soft actuators
1Technische Universiteit Delft, Mekelweg 5, 2628 CD, Delft, The Netherlands. s.d.joshi@tudelft.nl.

Abstract:
Sensing forms an integral part of soft matter based robots due to their compliance, dependence on loading conditions, and virtually infinite degrees of freedom. Previous studies have developed several extrinsic sensors and embedded them into soft actuators for displacement and force estimation. What has not been investigated is whether soft robots themselves possess intrinsic sensing capabilities, especially in the case of pneumatically powered soft robots. Such an approach, that exploits the inherent properties of a system toward sensing is called sensorless estimation. Here, we introduce sensorless estimation for the first time in pneumatically powered soft actuators. Specifically, we show that the intrinsic properties of pressure and volume can be used to estimate the output force and displacement of soft actuators. On testing this approach with a bending actuator, we observed errors under 10% and 15% for force and displacement estimation respectively, with randomized and previously unseen test conditions. We also show that combining this approach with a conventional embedded sensor improves estimation accuracy due to sensing redundancy. By modelling soft actuators additionally as sensors, this work presents a new, readily implementable sensing modality that helps us better understand the highly complex behaviour of soft matter based robots.


Related Concept Videos
 01:05
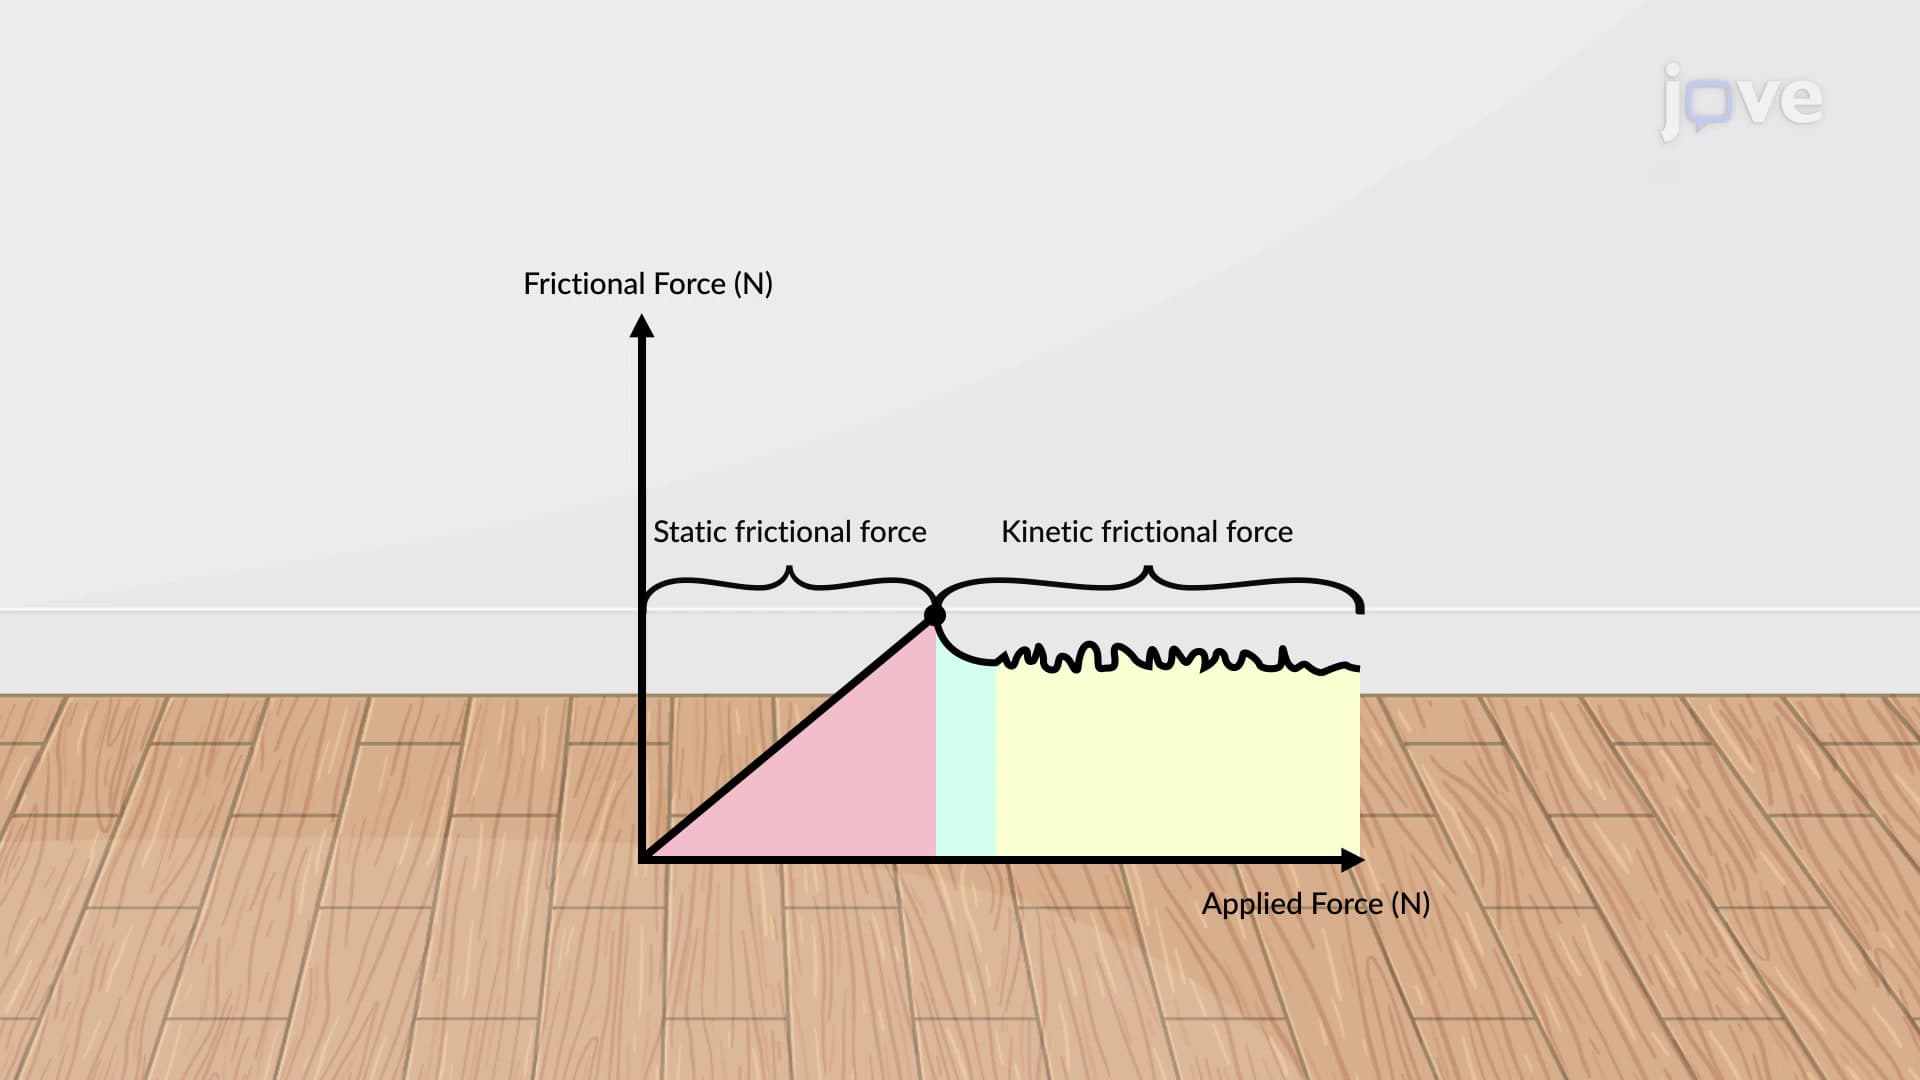
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:20
Two-Dimensional Force System
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...