Related Experiment Video
Updated: Aug 4, 2025
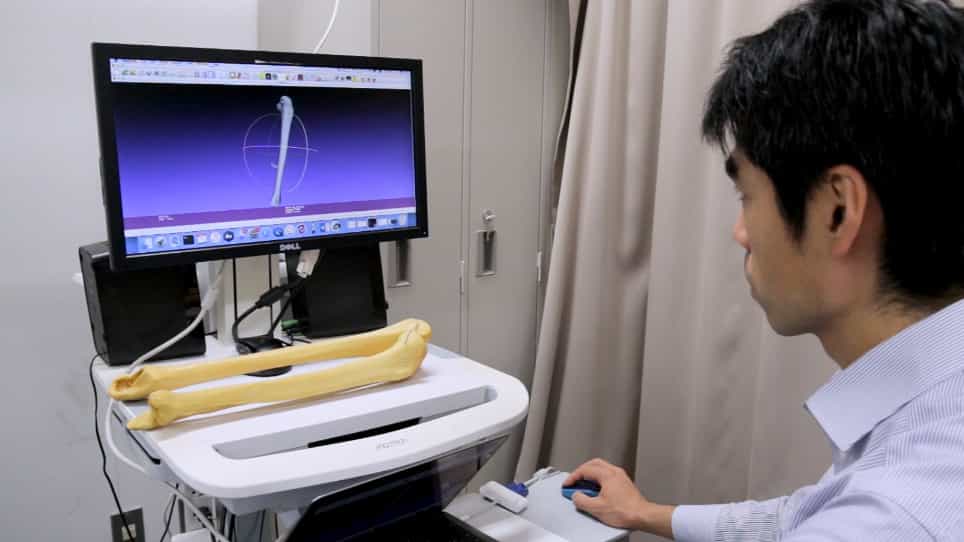
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
RoReg: Pairwise Point Cloud Registration With Oriented Descriptors and Local Rotations

Abstract:
We present RoReg, a novel point cloud registration framework that fully exploits oriented descriptors and estimated local rotations in the whole registration pipeline. Previous methods mainly focus on extracting rotation-invariant descriptors for registration but unanimously neglect the orientations of descriptors. In this paper, we show that the oriented descriptors and the estimated local rotations are very useful in the whole registration pipeline, including feature description, feature detection, feature matching, and transformation estimation. Consequently, we design a novel oriented descriptor RoReg-Desc and apply RoReg-Desc to estimate the local rotations. Such estimated local rotations enable us to develop a rotation-guided detector, a rotation coherence matcher, and a one-shot-estimation RANSAC, all of which greatly improve the registration performance. Extensive experiments demonstrate that RoReg achieves state-of-the-art performance on the widely-used 3DMatch and 3DLoMatch datasets, and also generalizes well to the outdoor ETH dataset. In particular, we also provide in-depth analysis on each component of RoReg, validating the improvements brought by oriented descriptors and the estimated local rotations. Source code and supplementary material are available at https://github.com/HpWang-whu/RoReg.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:23
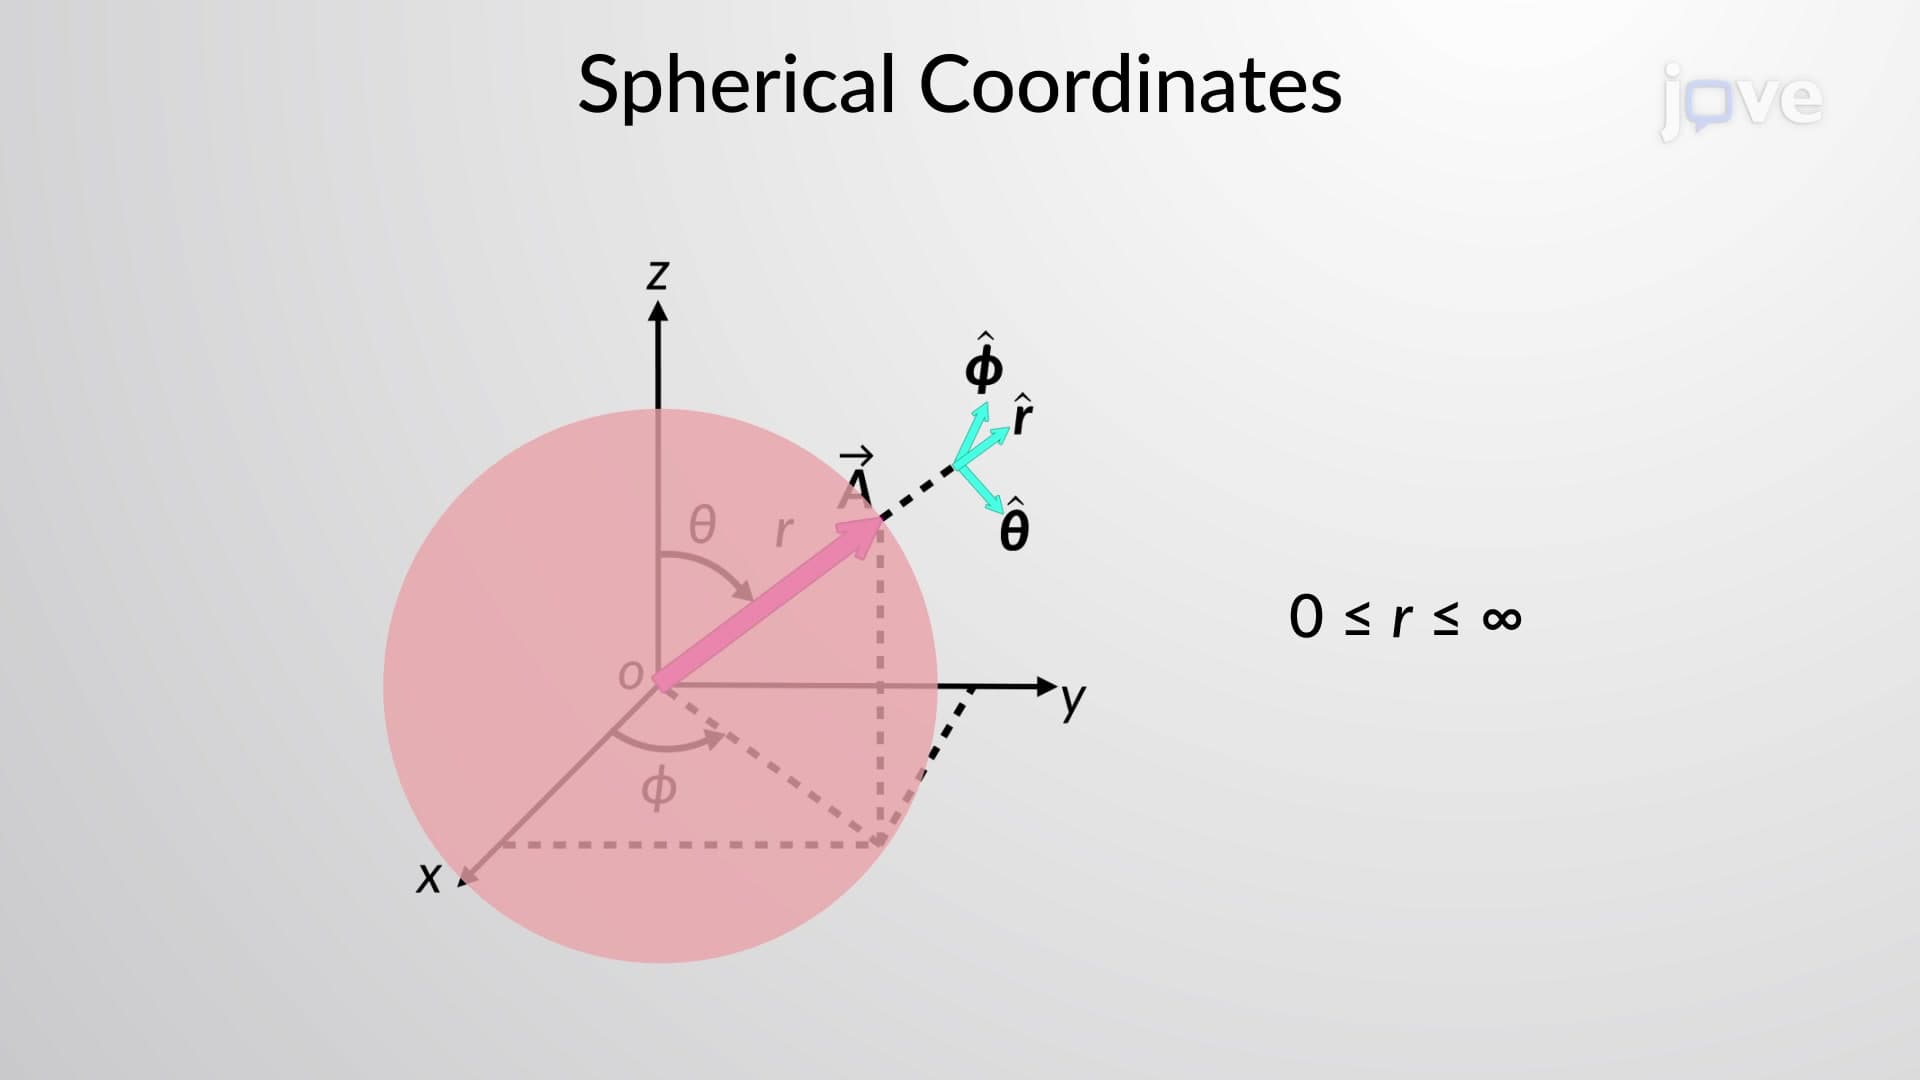
Spherical Coordinates
 01:16
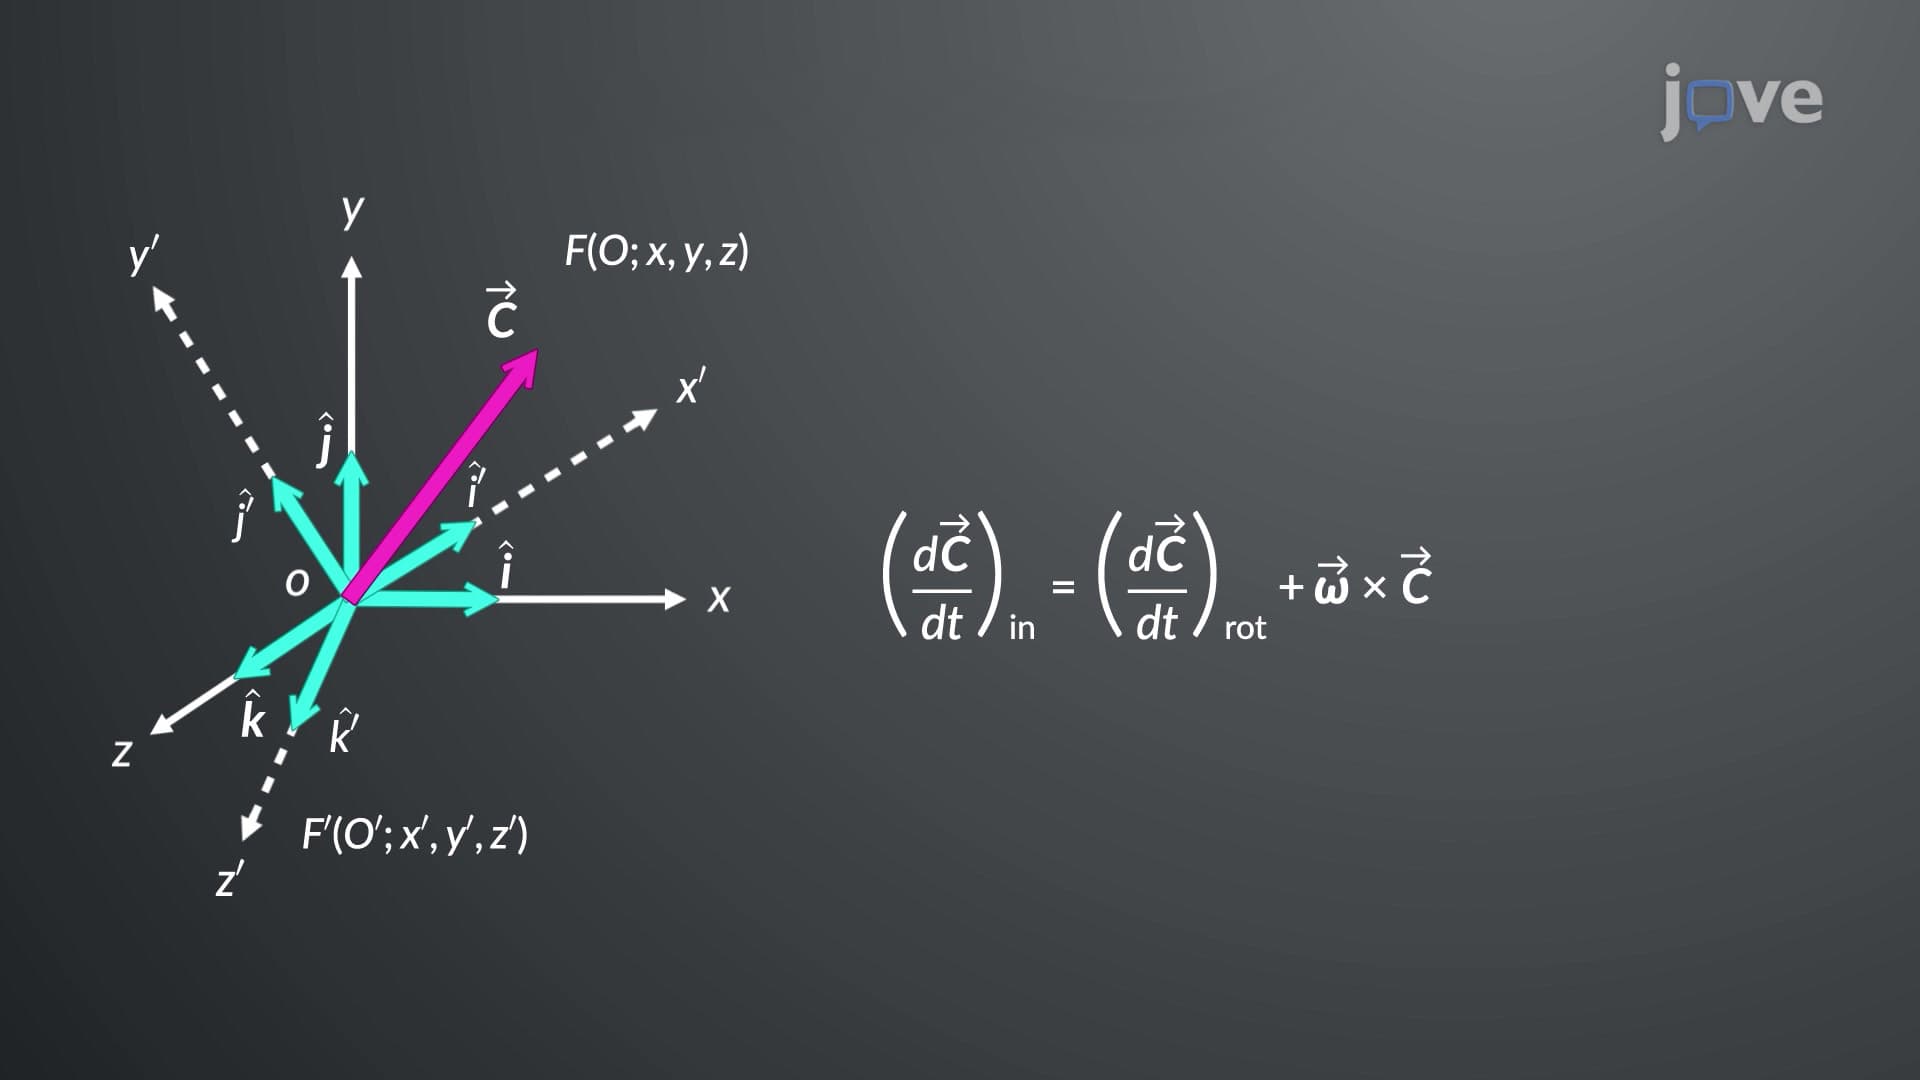
Vector Transformation in Rotating Coordinate Systems
 01:20
Structural Classification of Joints
A fibrous joint is where the adjacent bones are united by fibrous connective...