Related Experiment Video
Updated: Aug 3, 2025


Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
A Versatile Continuum Gripping Robot with a Concealable Gripper
Shuailong Zhang1,2, Fenggang Li1,2, Rongxin Fu3
1School of Mechatronical Engineering, Beijing Institute of Technology, Beijing 100081, China.

Abstract:
Continuum robots with their inherent compliance provide the potential for crossing narrow unstructured workspace and safely grasping various objects. However, the display gripper increases the size of the robots, and therefore, it tends to get stuck in constrained environments. This paper proposes a versatile continuum grasping robot (CGR) with a concealable gripper. The CGR can capture large objects with respect to the robot's scale using the continuum manipulator and can grasp various objects using the end concealable gripper especially in narrow and unstructured workspaces. To perform the cooperative operation of the concealable gripper and the continuum manipulator, a global kinematic model based on screw theory and a motion planning approach referred to as "multi-node synergy method" for the CGR are presented. The simulation and experimental results show that objects of different shapes and sizes can be captured by the same CGR even in complex and narrow environments. Finally, in the future, the CGR is expected to serve for satellite capture in harsh space environments such as high vacuum, strong radiation, and extreme temperatures.


Related Concept Videos
 01:22
Mechanical Systems
 01:15
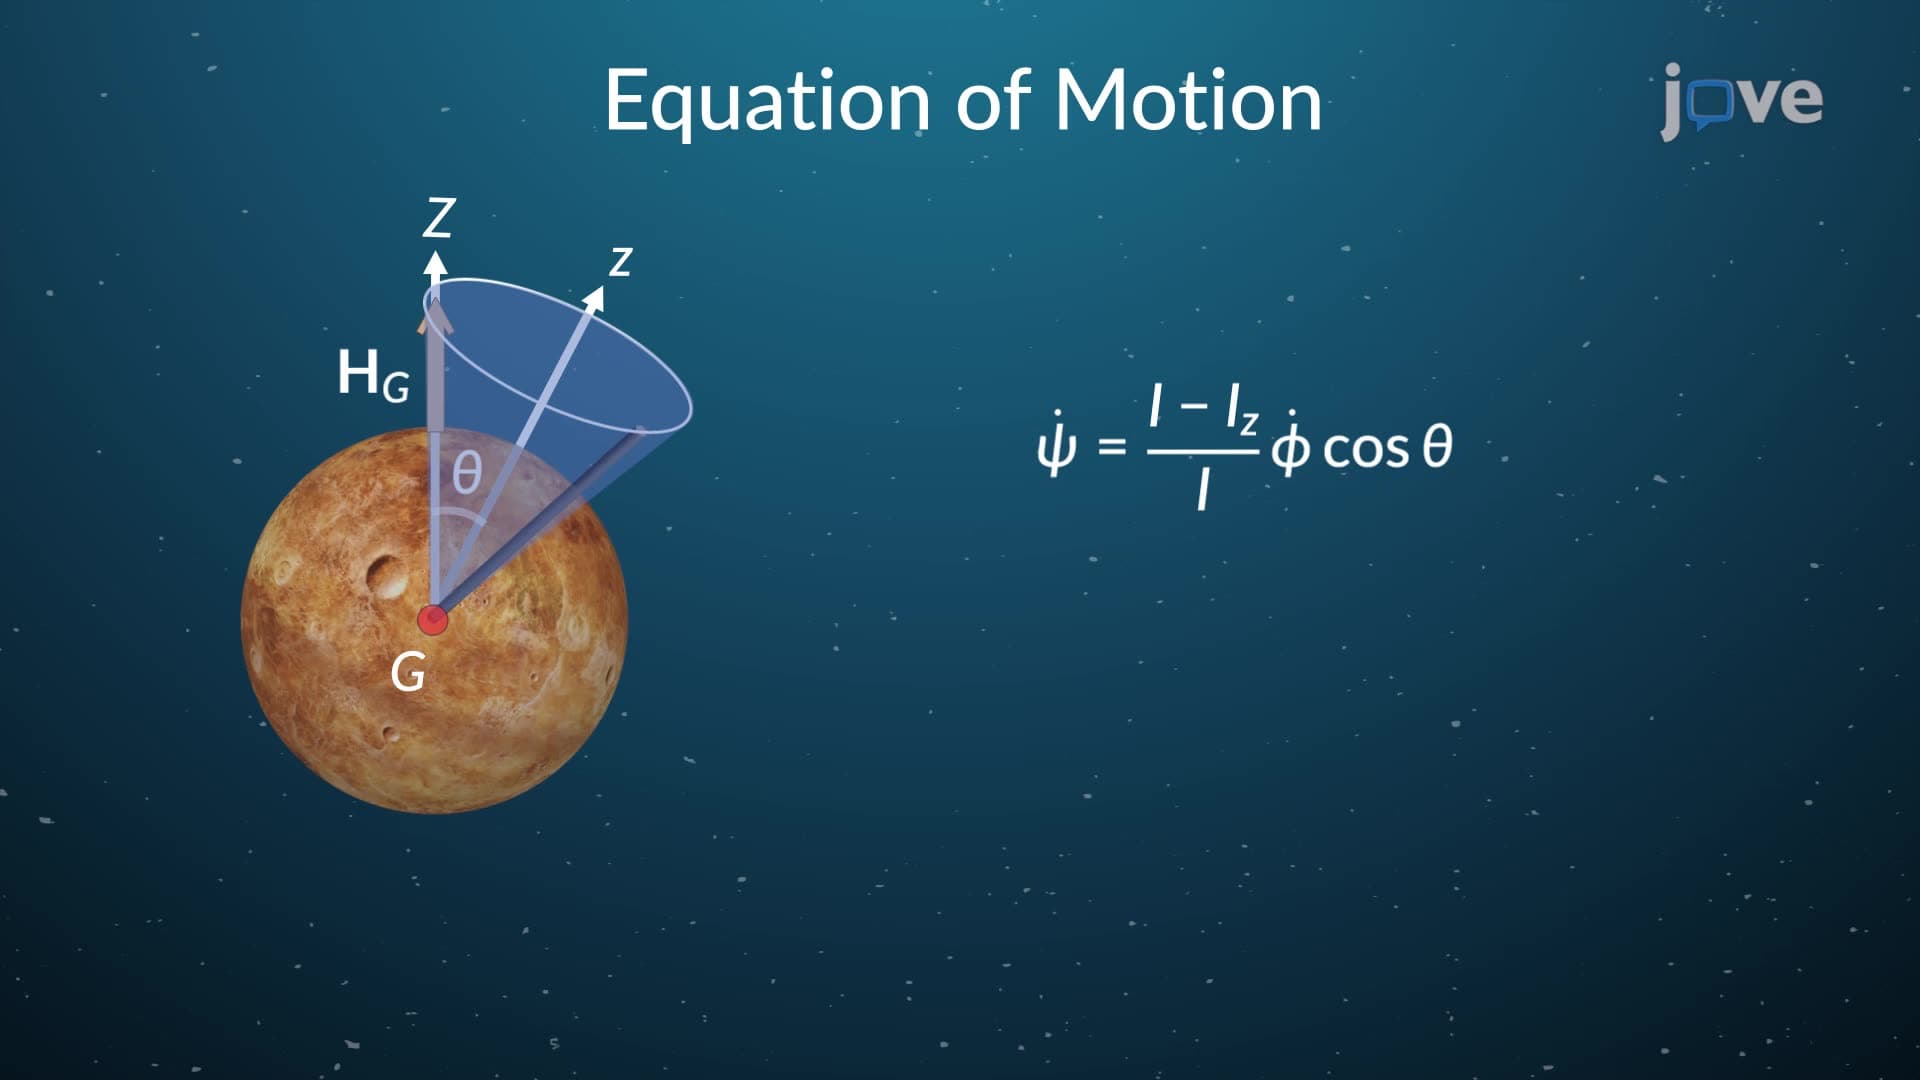
Torque Free Motion
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:10
Control Systems
At the heart...